

Remeshing#
PhysicsNeMo provides Warp-based surface remeshing on CPU and CUDA for 2D
triangle manifolds embedded in 3D. n_clusters is the global target number
of output vertices, not triangles. Cleanup can produce slightly fewer
vertices.
Remeshing can barycentrically interpolate selected point_data onto the new
vertices. A direct positive scalar tensor or an attached point-data field can
also specify relative linear resolution within the fixed vertex budget. Cell
data is discarded. Global data, point dtype, and device are preserved.
CPU and CUDA Example#
The output remains on the input device. The example below selects CUDA when it
is available and otherwise runs on CPU. The equivalent
remesh() convenience method accepts the same
high-level remeshing controls:
import torch

from physicsnemo.mesh.primitives.surfaces import sphere_icosahedral
from physicsnemo.mesh.remeshing import remesh

device = "cuda" if torch.cuda.is_available() else "cpu"
dense = sphere_icosahedral.load(subdivisions=6, device=device)
coarse = remesh(dense, n_clusters=4_096)

assert coarse.points.device == dense.points.device
assert 0 < coarse.n_points <= 4_096
Transfer Point Data#
Set transfer_point_data to a key, a nested key path, or a list of keys and
paths. True selects every point-data leaf. Selected fields must contain
real floating-point tensors:
dense.point_data["temperature"] = dense.points[:, 2]
dense.point_data["flow", "pressure"] = dense.points[:, 0].square()

coarse = dense.remesh(
    n_clusters=4_096,
    transfer_point_data=[
        "temperature",
        ("flow", "pressure"),
    ],
)

assert "temperature" in coarse.point_data
assert ("flow", "pressure") in coarse.point_data.keys(
    include_nested=True,
    leaves_only=True,
)
Warp records the closest source triangle and barycentric coordinates while it projects each final output vertex. PyTorch then interpolates the selected fields directly from the original mesh. This avoids a second spatial query and prevents cumulative interpolation drift.
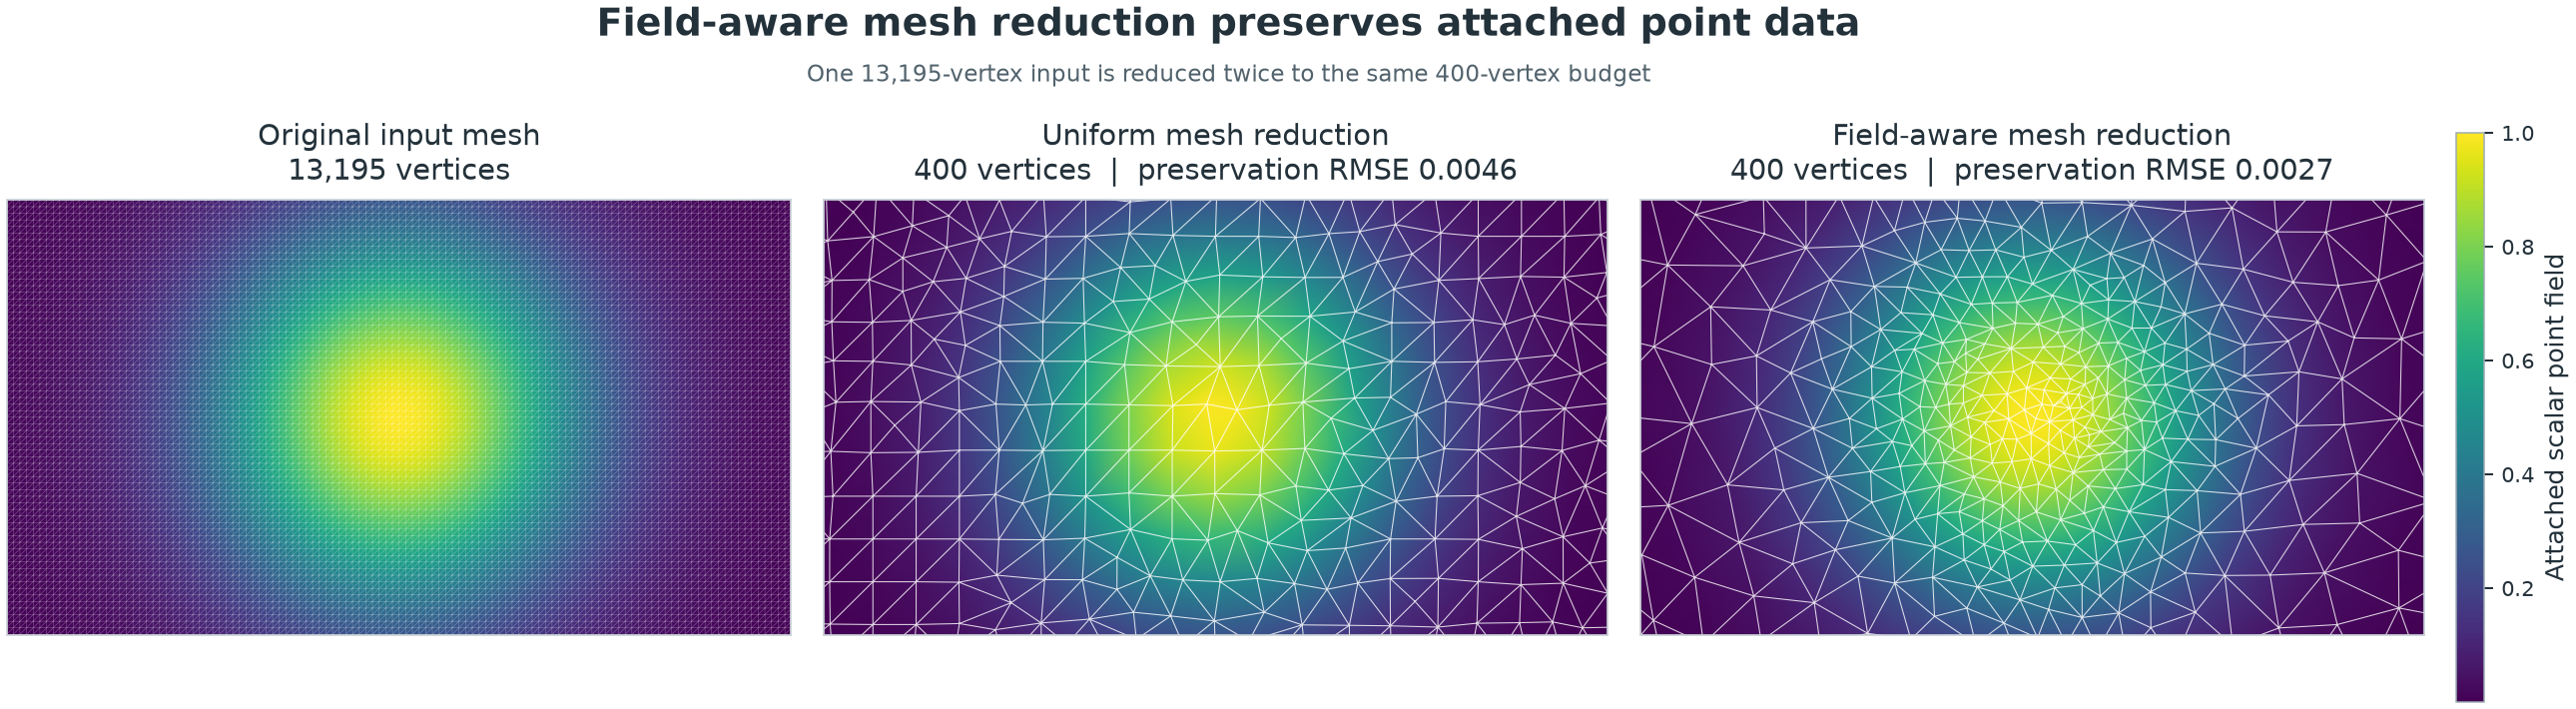
Transfer does not improve the source field or recover details that are absent from the input mesh. A reduced mesh has fewer degrees of freedom and generally loses some field information. Resolution control can reduce that loss by placing more of the fixed output budget where the attached field varies most.
The geometry, topology, source-triangle selection, and barycentric weights are non-differentiable. The interpolation remains differentiable with respect to the source field values. This is nodal interpolation, not a conservative remap. It does not guarantee preservation of a field integral or mean.
The figure shows one input mesh and two reductions of its attached scalar field. The field is one smooth sphere-like bump at the mesh center. The center panel uses uniform remeshing. The right panel uses a 1× to 4× resolution request derived from the field magnitude. Both reductions use the same 400-vertex output budget. Preservation RMSE compares each reduced piecewise-linear field with the input piecewise-linear field on a shared grid subset.
Control Local Resolution#
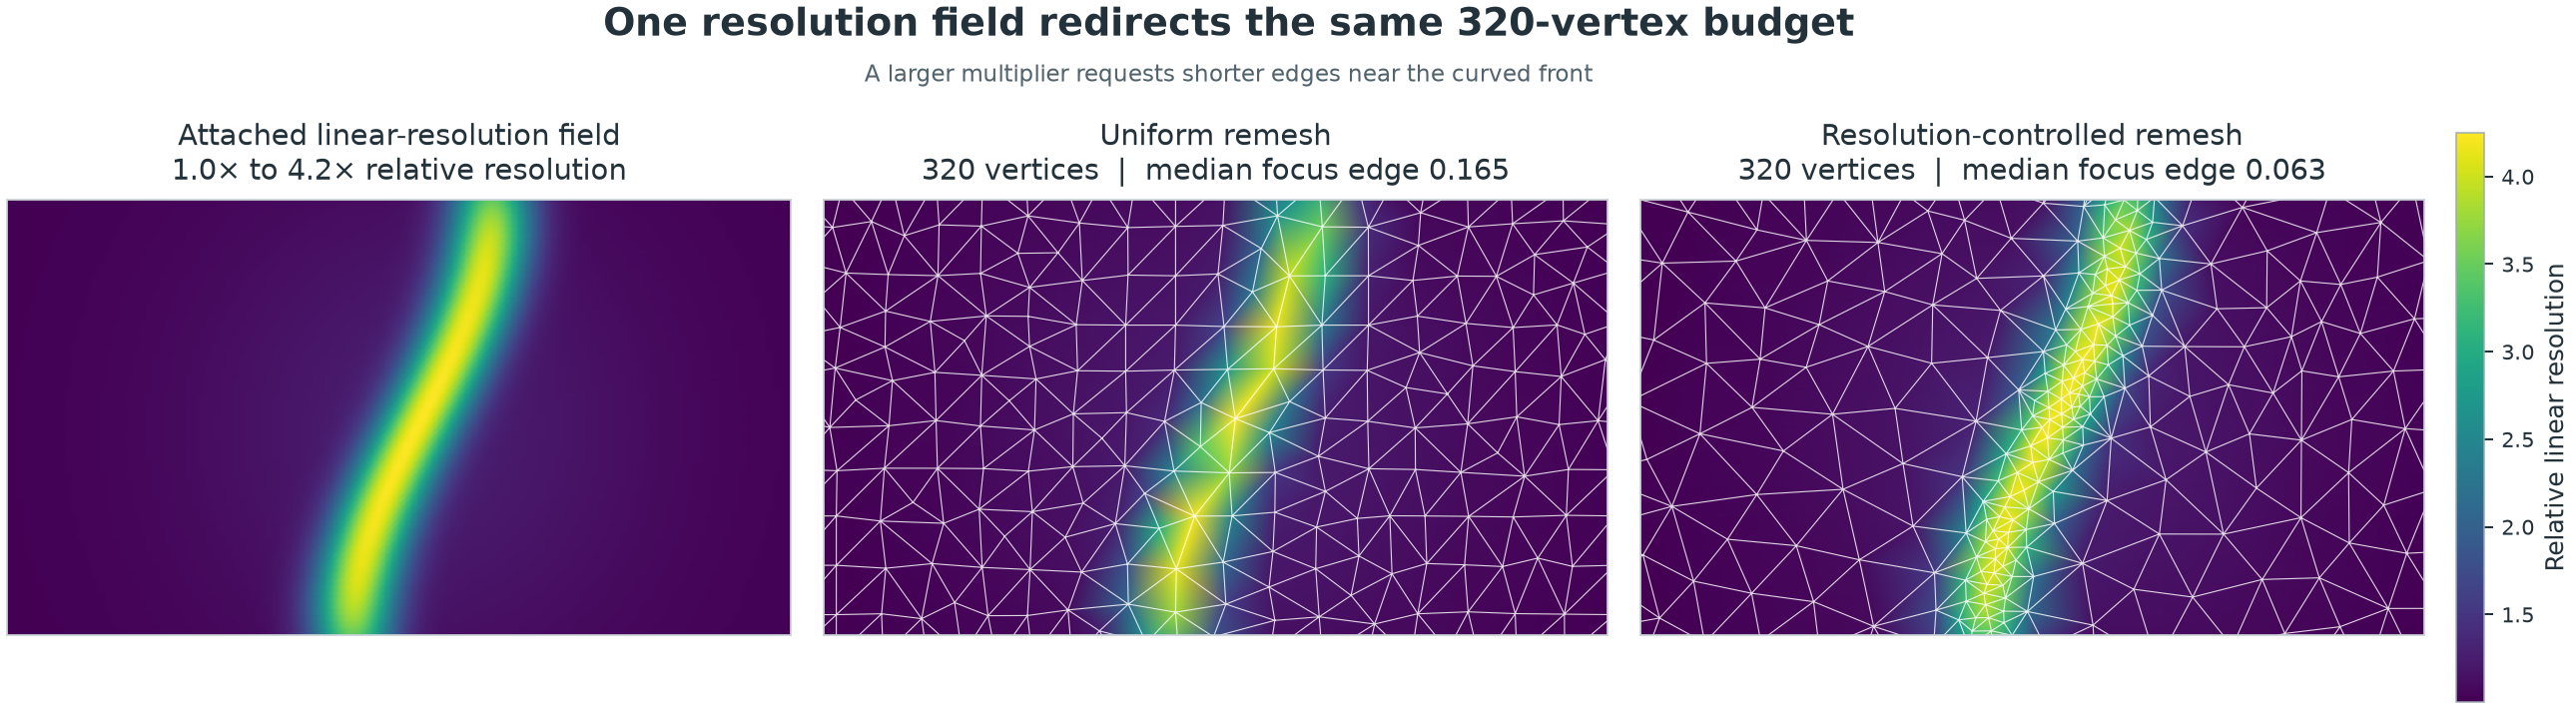
Pass a positive scalar tensor directly as resolution_field, or store it in
point_data and pass its key. Its values are relative linear-resolution
multipliers. A value twice another requests approximately half the local edge
spacing. The field must use a real floating-point dtype on the mesh device:
x = dense.points[:, 0]
resolution = 1.0 + 2.0 * torch.exp(
    -((x - 0.25) / 0.08).square()
)

adaptive = dense.remesh(
    n_clusters=4_096,
    resolution_field=resolution,
    transfer_point_data=["temperature"],
)
Direct tensor entries correspond to dense.points order. Passing the tensor
does not attach it to either mesh or transfer it to the output. Passing a
point_data key remains useful when the field is already attached.
Only relative values matter. Multiplying the entire resolution field by a
positive constant leaves the remeshing objective unchanged. The values are
relative inverse edge lengths, not exact edge lengths or guaranteed local
vertex counts. For the 2D squared-distance CVT objective, the implementation
converts linear resolution r to integration density r**4. Ideal local
point density therefore scales approximately as r**2. A constant field
follows the uniform remeshing path. n_clusters remains the global budget.
A resolution field can encode a region of interest, a solver error indicator, or an importance field derived from physical point data. The second figure shows the same output budget with and without this control:
Warp Tuning#
Advanced users can tune the backend search and initialization policy through the tensor functional. These backend-specific parameters may change as the implementation evolves:
from physicsnemo.nn.functional import remeshing

linear_resolution = resolution
if linear_resolution.element_size() < 4:
    linear_resolution = linear_resolution.to(torch.float32)
normalized_resolution = linear_resolution / linear_resolution.amax()
tuned_points, tuned_cells = remeshing(
    dense.points,
    dense.cells,
    n_clusters=4_096,
    vertex_density=normalized_resolution.pow(4),
    search_radius_scale=2.0,
    voxel_width_scale=1.0,
    hash_grid_resolution=192,
    farthest_point_threshold=512,
    farthest_point_oversampling=6,
)
These values are host-side controls or runtime kernel arguments. Changing them reuses the compiled Warp kernels rather than triggering JIT recompilation.
The tensor functional accepts raw CVT integration density through
vertex_density. It does not interpret that tensor as linear resolution.
Promote values smaller than float32, then normalize before raising the field
to the fourth power. This follows the conversion order used by Mesh.remesh
and avoids overflowing reduced-precision inputs.
The Warp implementation uses centroidal relaxation with a hash grid. Uniform
remeshing uses lumped vertex area as integration mass. Adaptive remeshing
multiplies that mass by vertex_density. Density-aware initialization biases
seeds toward the ideal 2D generator density. Large uniform targets retain the
baseline spatially uniform voxel selection. Adaptive remeshing also enlarges
the hash-grid query radius when needed to cover the wider spacing requested in
low-density regions.
Warp projects relaxed vertices onto the source surface using a bounding volume hierarchy (BVH), removes collapsed and duplicate faces, and compacts unused vertices. Small targets use farthest-point initialization for mesh quality. Large uniform targets use a linearithmic spatially stratified initializer. Large adaptive targets sample directly from the requested generator density. Both paths avoid quadratic setup cost.
Performance#
The checked-in ASV benchmark measures warmed, end-to-end GPU execution:
clustering
surface projection
topology reconstruction
cleanup
optional scalar-field interpolation
optional linear-resolution-field conversion
Timing includes an explicit CUDA synchronization.
On supported CUDA devices, remeshing can be up to 300× faster than a CPU baseline.
./benchmarks/run_benchmarks.sh -b remesh
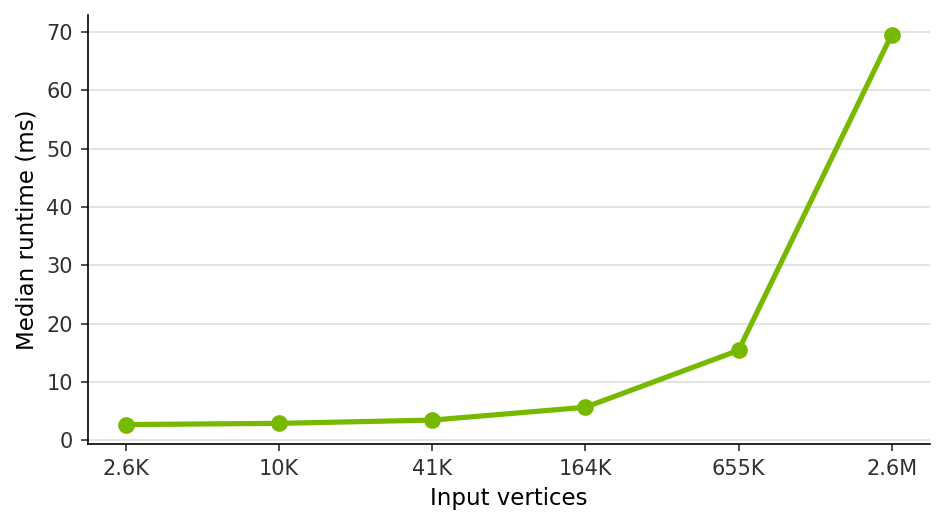
The figure below is a representative run of
docs/img/mesh/remeshing_performance.py on an NVIDIA RTX PRO 6000 Blackwell
Server Edition MIG 1g.24GB partition using Warp 1.14.0. Absolute timings depend
on hardware and software versions. Use the ASV benchmark above for measurements
in another environment.
Behavior and Limitations#
Remeshing is non-differentiable. The implementation centers and scales geometry before computing in
float32, then restores the input coordinate frame and point dtype on return. Resolution fields are detached before they affect clustering.Barycentric point-data transfer supports real floating-point tensors. It preserves trailing component dimensions and the source field dtype. Dtypes smaller than
float32accumulate infloat32before conversion back to the source dtype. Categorical integer, Boolean, and complex fields are not interpolated.Point-data transfer requires a valid closest source triangle for every output vertex. A surface feature that is numerically degenerate in the float32 Warp projection can still remesh geometrically, but field transfer raises
RuntimeErrorwhen its source-triangle provenance is unavailable.Warp floating-point atomics can introduce small run-to-run differences in vertex positions and, near assignment ties, topology, even though centroid sampling uses a fixed random seed. Do not rely on bitwise reproducibility.
Because clustering uses spatial distance rather than mesh connectivity, sheets or thin features separated by less than the mean cluster spacing can be assigned to a common cluster and welded together.
Projection can map distinct cluster centroids to the same surface position. Output vertices are compacted by connectivity but are not welded by position.
Open boundary vertices are not constrained. Centroid relaxation and projection can move the reconstructed boundary inward from the source boundary.
Strong resolution contrast can leave too few vertices in low-resolution regions. The fourth-power conversion intentionally amplifies linear resolution ratios. Use moderate resolution ratios and validate the resulting topology and field error for the application.
The optional
max_iterationsargument defaults to four centroid updates.
API Reference#
Mesh remeshing and cell partitioning.
This module provides two complementary algorithms for mesh coarsening:
- Cell partitioning (
partition_cells()): Assigns each cell of a fine mesh to its nearest seed point (by Euclidean centroid distance) and accumulates area, normal, and centroid per cluster. This is a single-step discrete approximation to the restricted Voronoi diagram on the surface. Pure PyTorch, no external dependencies.
- Surface remeshing (
remesh()): Creates new triangle topology on CPU or CUDA using Warp. Selected point data can be interpolated onto the result, and a direct or attached positive field can control local resolution.
partition_cells is also a natural building block for a pure-PyTorch
centroidal Voronoi tessellation (CVT): Lloyd’s algorithm iterates from
partitioning to moving seeds to cluster centroids, then repeats.
Example
>>> from physicsnemo.mesh.primitives.surfaces import sphere_icosahedral
>>> from physicsnemo.mesh.remeshing import remesh
>>> mesh = sphere_icosahedral.load(subdivisions=3)
>>> # Remesh a triangle mesh to approximately 100 vertices
>>> remeshed = remesh(mesh, n_clusters=100)
>>> assert remeshed.n_cells > 0
- class physicsnemo.mesh.remeshing.CellPartition(
- assignments: Int[Tensor, 'n_cells'],
- cluster_areas: Float[Tensor, 'n_seeds'],
- cluster_normals: Float[Tensor, 'n_seeds n_spatial_dims'],
- cluster_centroids: Float[Tensor, 'n_seeds n_spatial_dims'],
Bases:
NamedTupleResult of partitioning mesh cells by nearest seed point.
- Parameters:
assignments (Int[torch.Tensor, " n_cells"]) – Index of the nearest seed for each original cell.
cluster_areas (Float[torch.Tensor, " n_seeds"]) – Total cell area assigned to each seed. Sums to the total surface area of the original mesh by construction.
cluster_normals (Float[torch.Tensor, "n_seeds n_spatial_dims"]) – Area-weighted average unit normal per cluster.
cluster_centroids (Float[torch.Tensor, "n_seeds n_spatial_dims"]) – Area-weighted centroid per cluster. For a well-centered seed this is close to the seed itself. The difference measures how far the seed is from its Voronoi centroid (exactly the quantity that Lloyd’s algorithm drives to zero).
- assignments: Int[Tensor, 'n_cells']#
Alias for field number 0
- cluster_areas: Float[Tensor, 'n_seeds']#
Alias for field number 1
- cluster_centroids: Float[Tensor, 'n_seeds n_spatial_dims']#
Alias for field number 3
- cluster_normals: Float[Tensor, 'n_seeds n_spatial_dims']#
Alias for field number 2
- physicsnemo.mesh.remeshing.partition_cells(
- mesh: Mesh,
- seeds: Float[Tensor, 'n_seeds n_spatial_dims'],
Partition mesh cells into Voronoi regions around seed points.
Each cell is assigned to the seed whose Euclidean distance to the cell centroid is smallest. Aggregate geometric properties (area, normal, centroid) are then accumulated per cluster via
scatter_add.This is the discrete analog of a restricted Voronoi diagram: the original cells discretize the continuous surface, and their nearest-seed assignment approximates the Voronoi partition. The approximation is exact when the original mesh is infinitely fine relative to the seed spacing.
The nearest-neighbor search uses
knn()which auto-dispatches to the optimal backend (cuML on GPU, scipy KDTree on CPU) for O(M log N) query complexity.- Parameters:
mesh (Mesh) – Source mesh whose cells will be partitioned. For codimension-1 meshes (surfaces), cluster normals are computed from cell normals. For other meshes, cluster normals are zero vectors.
seeds (Float[torch.Tensor, "n_seeds n_spatial_dims"]) – Seed point positions.
n_spatial_dimsmust matchmesh.n_spatial_dims.
- Returns:
Named tuple with
assignments,cluster_areas,cluster_normals, andcluster_centroids.- Return type:
- Raises:
ValueError – If
seedsandmeshhave different devices or dtypes.
Examples
>>> import torch
>>> from physicsnemo.mesh import Mesh
>>> from physicsnemo.mesh.remeshing import partition_cells
>>> # Two triangles in 3D (codimension-1 surface)
>>> pts = torch.tensor([[0., 0., 0.], [1., 0., 0.], [0., 1., 0.], [1., 1., 0.]])
>>> cells = torch.tensor([[0, 1, 2], [1, 3, 2]])
>>> mesh = Mesh(points=pts, cells=cells)
>>> seeds = torch.tensor([[0.25, 0.25, 0.0], [0.75, 0.75, 0.0]])
>>> result = partition_cells(mesh, seeds)
>>> result.assignments.tolist()
[0, 1]
>>> abs(result.cluster_areas.sum().item() - mesh.cell_areas.sum().item()) < 1e-10
True
Notes
Uses Euclidean (ambient-space) distance, not geodesic distance. For smooth surfaces where inter-seed spacing is small relative to the radius of curvature, this is an excellent approximation.
Every original cell is assigned to exactly one cluster, so
cluster_areas.sum() == mesh.cell_areas.sum()by construction.If a cluster receives no cells (possible when seeds outnumber cells or cluster heavily), its area is 0, its normal is the zero vector, and its centroid falls back to the seed position.
- physicsnemo.mesh.remeshing.remesh(
- mesh: Mesh,
- n_clusters: int,
- *,
- max_iterations: int = 4,
- transfer_point_data: PointDataSelection = False,
- resolution_field: ResolutionField = None,
Remesh a triangle surface with point-data and resolution controls.
Warp performs integration-mass-weighted centroidal clustering, projects cluster centers back to the source surface with a bounding volume hierarchy, and reconstructs compact triangle connectivity. A direct positive tensor or an attached point-data field can specify relative local linear resolution.
- Parameters:
mesh (Mesh) – Input triangle surface. Only 2D triangle manifolds embedded in 3D are supported.
n_clusters (int) – Target output vertex count. Cleanup can produce slightly fewer vertices. Must be between 3 and the input point count, inclusive.
max_iterations (int, optional) – Maximum centroid-relaxation iterations. Default is
4. Values must be non-negative.transfer_point_data (bool, str, tuple, list, or None, optional) – Point-data fields to interpolate onto the output vertices.
FalseorNonetransfers no fields.Truetransfers every point-data leaf. A string or tuple selects one key or nested key path. A list selects several keys or paths. Selected fields must contain real floating-point tensors. Default isFalse.resolution_field (str, tuple, torch.Tensor, or None, optional) – Positive scalar tensor with shape
(n_points,), or a key or nested key path resolving to one inmesh.point_data. Values specify relative linear resolution. A value twice another requests approximately half the local edge spacing. The fixedn_clustersbudget and source geometry limit the realized spacing. The field must use a real floating-point dtype on the mesh device. Direct tensor entries correspond tomesh.pointsorder and are not attached to or transferred with the output mesh. Only relative values matter. Default isNonefor uniform remeshing.
- Returns:
Remeshed surface on the input device. Selected point data is barycentrically interpolated from the original source surface. Cell data and unselected point data are discarded. Global data is preserved.
- Return type:
- Raises:
TypeError – If counts, tuning parameters, point coordinates, a field selection, or a selected field has an invalid type.
ValueError – If a count is out of range or geometry, connectivity, or a selected field is invalid.
KeyError – If a requested point-data key or path does not exist.
NotImplementedError – If
meshis not a 2D triangle surface embedded in 3D.ImportError – If Warp is unavailable.
RuntimeError – If cleanup cannot reconstruct a nonempty manifold triangle surface or point-data transfer provenance is unavailable.
Notes
Remeshing, topology, projection choices, and resolution control are intentionally non-differentiable. Transferred fields remain differentiable with respect to their source values because the final barycentric interpolation uses PyTorch. Warp computes geometry in centered and scaled coordinates in float32, then restores the input point dtype and coordinate frame. For the 2D squared-distance CVT objective, the implementation converts linear resolution
rto integration densityr**4. Ideal local point density therefore scales approximately asr**2. These relationships guide allocation but do not guarantee exact edge lengths or local point counts. Because clustering uses spatial distance rather than mesh connectivity, sheets or thin features separated by less than the mean cluster spacing can be assigned to a common cluster and welded together. Projection can map distinct cluster centroids to the same surface position. Output vertices are compacted by connectivity but are not welded by position. Backend-specific tuning remains available throughphysicsnemo.nn.functional.remeshing(). These advanced parameters may change as the implementation evolves.