Detailed Description
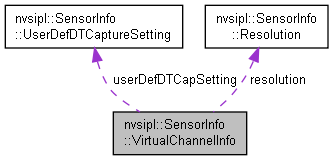
Defines the information of a virtual channel/single exposure.
Definition at line 165 of file NvSIPLDeviceBlockInfo.hpp.
Data Fields | |
| uint32_t | vcId {UINT32_MAX} |
| Holds the virtual channel id. More... | |
| uint32_t | vcIdDst {UINT32_MAX} |
| Holds the destination virtual channel id. More... | |
| uint32_t | cfa {0U} |
| Holds the Bayer color filter array order of the sensor. More... | |
| uint32_t | embeddedTopLines {UINT32_MAX} |
| Holds the number of top embedded lines. More... | |
| uint32_t | embeddedBottomLines {UINT32_MAX} |
| Holds the number of bottom embedded lines. More... | |
| NvSiplCapInputFormatType | inputFormat {NVSIPL_CAP_INPUT_FORMAT_TYPE_RAW12} |
| Holds the input format. More... | |
| Resolution | resolution |
| Holds the Resolution of the captured frame. More... | |
| float_t | fps {0.0F} |
| Holds the average number of frames per second. More... | |
| bool | isEmbeddedDataTypeEnabled {false} |
| Indicates whether the embedded data is coming in CSI packet with different data. More... | |
| uint32_t | embeddedDataOffset {0U} |
| Holds the byte offset from the buffer start to the first active pixel. More... | |
| UserDefDTCaptureSetting | userDefDTCapSetting |
| Holds the UserDefDTCaptureSetting for the virtual channel. More... | |
Field Documentation
◆ cfa
| uint32_t nvsipl::SensorInfo::VirtualChannelInfo::cfa {0U} |
Holds the Bayer color filter array order of the sensor.
NVIDIA recommends setting this element with the NVSIPL_PIXEL_ORDER_* family of macros, e.g. NVSIPL_PIXEL_ORDER_ALPHA.
Actual values will vary based on sensor HW and sensor driver support.
Valid value: [NVSIPL_PIXEL_ORDER_*]
Definition at line 193 of file NvSIPLDeviceBlockInfo.hpp.
◆ embeddedBottomLines
| uint32_t nvsipl::SensorInfo::VirtualChannelInfo::embeddedBottomLines {UINT32_MAX} |
Holds the number of bottom embedded lines.
Actual values will vary based on sensor HW and sensor driver support.
Valid value: [0, UINT32_MAX]
Definition at line 209 of file NvSIPLDeviceBlockInfo.hpp.
◆ embeddedDataOffset
| uint32_t nvsipl::SensorInfo::VirtualChannelInfo::embeddedDataOffset {0U} |
Holds the byte offset from the buffer start to the first active pixel.
Use this when the embedded data is not aligned to the image width so that the active pixels start in continuation of the embedded data (possibly in the middle of an image row). This value is the exact byte offset to the active pixel data, i.e. the byte size of the top embedded data region. When non-zero it directly sets the ISP input surface offset, instead of deriving it from the embedded line count and image pitch.
This value only applies when isEmbeddedDataTypeEnabled is false (the embedded data shares the pixel data type and is captured inline before the active pixels). When isEmbeddedDataTypeEnabled is true (embedded data captured as a separate data type), this value has no effect: the capture geometry and the ISP input offset are derived from the embedded line count and image pitch as usual.
embeddedTopLines and embeddedBottomLines continue to be used only for buffer allocation.
The value shifts the plane base address the ISP reads from, so it must be a multiple of the camera engine base address alignment (64 bytes) and must leave the cropped image inside the allocated surface. Otherwise ISP processing fails with NVSIPL_STATUS_BAD_ARGUMENT.
The default value is 0, which keeps the default line-count based offset.
Valid value: [0, UINT32_MAX], multiple of 64
Definition at line 265 of file NvSIPLDeviceBlockInfo.hpp.
◆ embeddedTopLines
| uint32_t nvsipl::SensorInfo::VirtualChannelInfo::embeddedTopLines {UINT32_MAX} |
Holds the number of top embedded lines.
Actual values will vary based on sensor HW and sensor driver support.
Valid value: [0, UINT32_MAX]
Definition at line 201 of file NvSIPLDeviceBlockInfo.hpp.
◆ fps
| float_t nvsipl::SensorInfo::VirtualChannelInfo::fps {0.0F} |
Holds the average number of frames per second.
Actual values will vary based on sensor HW and sensor driver support.
Valid value: [NVSIPL_CAP_MIN_FRAME_RATE, NVSIPL_CAP_MAX_FRAME_RATE].
Definition at line 229 of file NvSIPLDeviceBlockInfo.hpp.
◆ inputFormat
| NvSiplCapInputFormatType nvsipl::SensorInfo::VirtualChannelInfo::inputFormat {NVSIPL_CAP_INPUT_FORMAT_TYPE_RAW12} |
Holds the input format.
Actual values will vary based on sensor HW and sensor driver support.
Valid value: [NvSiplCapInputFormatType]
Definition at line 217 of file NvSIPLDeviceBlockInfo.hpp.
◆ isEmbeddedDataTypeEnabled
| bool nvsipl::SensorInfo::VirtualChannelInfo::isEmbeddedDataTypeEnabled {false} |
Indicates whether the embedded data is coming in CSI packet with different data.
Embedded data enablement will vary based on the sensor HW and sensor driver support.
The default value is false.
Definition at line 237 of file NvSIPLDeviceBlockInfo.hpp.
◆ resolution
| Resolution nvsipl::SensorInfo::VirtualChannelInfo::resolution |
Holds the Resolution of the captured frame.
Definition at line 221 of file NvSIPLDeviceBlockInfo.hpp.
◆ userDefDTCapSetting
| UserDefDTCaptureSetting nvsipl::SensorInfo::VirtualChannelInfo::userDefDTCapSetting |
Holds the UserDefDTCaptureSetting for the virtual channel.
Definition at line 269 of file NvSIPLDeviceBlockInfo.hpp.
◆ vcId
| uint32_t nvsipl::SensorInfo::VirtualChannelInfo::vcId {UINT32_MAX} |
Holds the virtual channel id.
Actual values will vary based on sensor HW and sensor driver support.
Valid value: [0, 15U]
Definition at line 174 of file NvSIPLDeviceBlockInfo.hpp.
◆ vcIdDst
| uint32_t nvsipl::SensorInfo::VirtualChannelInfo::vcIdDst {UINT32_MAX} |
Holds the destination virtual channel id.
Actual values will vary based on sensor HW and sensor driver support.
Valid value: [0, 15U]
Definition at line 182 of file NvSIPLDeviceBlockInfo.hpp.
The documentation for this struct was generated from the following file: