Detailed Description
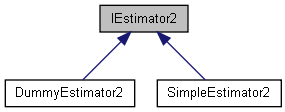
Define the interface for state estimators.
Definition at line 29 of file sources/libs/nvmultiobjecttracker/include/modules/Estimatorv2/IEstimator2.hpp.
Public Member Functions | |
| virtual | ~IEstimator2 () |
| Destroy the state-estimator interface. More... | |
| virtual Eigen::VectorXd | update (const float dT=1)=0 |
| Update without any measurement, using the prediction only. More... | |
| virtual Eigen::VectorXd | update (const std::vector< std::tuple< Eigen::VectorXd, Eigen::Matrix2d, bool > > &measurements, const float dT=1)=0 |
| Given a set of measurements and their covariances, update the estimator and returns the estimated states. More... | |
| virtual void | reset ()=0 |
| Reset the states and make the age to be zero. More... | |
| virtual Eigen::VectorXd | getStates () const =0 |
| Return the current estimated states. More... | |
| virtual Eigen::VectorXd | getPredictedStates (const float dT=1)=0 |
| Predict states without modifying the current estimate. More... | |
| virtual Eigen::MatrixXd | getMeasurementNoiseCovariance () const =0 |
| Return the measurement-noise covariance matrix. More... | |
| virtual std::tuple< Eigen::VectorXd, Eigen::MatrixXd > | getStatesWithCov () const =0 |
| Return the current states and their covariance. More... | |
| virtual std::tuple< Eigen::VectorXd, Eigen::MatrixXd > | getPredictedStatesWithCov (const float dT=1)=0 |
| Predict states and covariance without modifying the current estimate. More... | |
| virtual std::tuple< Eigen::VectorXd, Eigen::MatrixXd > | getPredictedMeasurementsWithCov (const float dT=1)=0 |
| Predict measurements and covariance without modifying the current estimate. More... | |
| virtual uint32_t | getAge () const =0 |
| Return the number of estimator updates. More... | |
| virtual const STATE_ESTIMATOR_TYPES | getStateEstimatorType ()=0 |
| Return the configured state-estimator type. More... | |
| virtual const bool | useAspectRatio () const =0 |
| Return whether the estimator represents size using aspect ratio. More... | |
| virtual void | overrideState (const Eigen::Vector2d &position, const Eigen::Vector2d &velocity)=0 |
| Overwrite the position and velocity components. More... | |
Constructor & Destructor Documentation
◆ ~IEstimator2() [1/2]
|
inlinevirtual |
Destroy the state-estimator interface.
Definition at line 33 of file sources/libs/nvmultiobjecttracker/include/modules/Estimatorv2/IEstimator2.hpp.
◆ ~IEstimator2() [2/2]
|
inlinevirtual |
Destroy the state-estimator interface.
Definition at line 33 of file 9.2/sources/libs/nvmultiobjecttracker/include/modules/Estimatorv2/IEstimator2.hpp.
Member Function Documentation
◆ getAge() [1/2]
|
pure virtual |
Return the number of estimator updates.
Implemented in SimpleEstimator2, SimpleEstimator2, DummyEstimator2, and DummyEstimator2.
◆ getAge() [2/2]
|
pure virtual |
Return the number of estimator updates.
Implemented in SimpleEstimator2, SimpleEstimator2, DummyEstimator2, and DummyEstimator2.
◆ getMeasurementNoiseCovariance() [1/2]
|
pure virtual |
Return the measurement-noise covariance matrix.
Implemented in SimpleEstimator2, SimpleEstimator2, DummyEstimator2, and DummyEstimator2.
◆ getMeasurementNoiseCovariance() [2/2]
|
pure virtual |
Return the measurement-noise covariance matrix.
Implemented in SimpleEstimator2, SimpleEstimator2, DummyEstimator2, and DummyEstimator2.
◆ getPredictedMeasurementsWithCov() [1/2]
|
pure virtual |
Predict measurements and covariance without modifying the current estimate.
- Parameters
-
[in] dT The time step.
Implemented in SimpleEstimator2, SimpleEstimator2, DummyEstimator2, and DummyEstimator2.
◆ getPredictedMeasurementsWithCov() [2/2]
|
pure virtual |
Predict measurements and covariance without modifying the current estimate.
- Parameters
-
[in] dT The time step.
Implemented in SimpleEstimator2, SimpleEstimator2, DummyEstimator2, and DummyEstimator2.
◆ getPredictedStates() [1/2]
|
pure virtual |
Predict states without modifying the current estimate.
- Parameters
-
[in] dT The time step.
Implemented in SimpleEstimator2, SimpleEstimator2, DummyEstimator2, and DummyEstimator2.
◆ getPredictedStates() [2/2]
|
pure virtual |
Predict states without modifying the current estimate.
- Parameters
-
[in] dT The time step.
Implemented in SimpleEstimator2, SimpleEstimator2, DummyEstimator2, and DummyEstimator2.
◆ getPredictedStatesWithCov() [1/2]
|
pure virtual |
Predict states and covariance without modifying the current estimate.
- Parameters
-
[in] dT The time step.
Implemented in SimpleEstimator2, SimpleEstimator2, DummyEstimator2, and DummyEstimator2.
◆ getPredictedStatesWithCov() [2/2]
|
pure virtual |
Predict states and covariance without modifying the current estimate.
- Parameters
-
[in] dT The time step.
Implemented in SimpleEstimator2, SimpleEstimator2, DummyEstimator2, and DummyEstimator2.
◆ getStateEstimatorType() [1/2]
|
pure virtual |
Return the configured state-estimator type.
Implemented in SimpleEstimator2, SimpleEstimator2, DummyEstimator2, and DummyEstimator2.
◆ getStateEstimatorType() [2/2]
|
pure virtual |
Return the configured state-estimator type.
Implemented in SimpleEstimator2, SimpleEstimator2, DummyEstimator2, and DummyEstimator2.
◆ getStates() [1/2]
|
pure virtual |
Return the current estimated states.
Implemented in SimpleEstimator2, SimpleEstimator2, DummyEstimator2, and DummyEstimator2.
◆ getStates() [2/2]
|
pure virtual |
Return the current estimated states.
Implemented in SimpleEstimator2, SimpleEstimator2, DummyEstimator2, and DummyEstimator2.
◆ getStatesWithCov() [1/2]
|
pure virtual |
Return the current states and their covariance.
Implemented in SimpleEstimator2, SimpleEstimator2, DummyEstimator2, and DummyEstimator2.
◆ getStatesWithCov() [2/2]
|
pure virtual |
Return the current states and their covariance.
Implemented in SimpleEstimator2, SimpleEstimator2, DummyEstimator2, and DummyEstimator2.
◆ overrideState() [1/2]
|
pure virtual |
Overwrite the position and velocity components.
- Parameters
-
[in] position The replacement position. [in] velocity The replacement velocity.
Implemented in SimpleEstimator2, SimpleEstimator2, DummyEstimator2, and DummyEstimator2.
◆ overrideState() [2/2]
|
pure virtual |
Overwrite the position and velocity components.
- Parameters
-
[in] position The replacement position. [in] velocity The replacement velocity.
Implemented in SimpleEstimator2, SimpleEstimator2, DummyEstimator2, and DummyEstimator2.
◆ reset() [1/2]
|
pure virtual |
Reset the states and make the age to be zero.
Implemented in SimpleEstimator2, SimpleEstimator2, DummyEstimator2, and DummyEstimator2.
◆ reset() [2/2]
|
pure virtual |
Reset the states and make the age to be zero.
Implemented in SimpleEstimator2, SimpleEstimator2, DummyEstimator2, and DummyEstimator2.
◆ update() [1/4]
|
pure virtual |
Update without any measurement, using the prediction only.
- Parameters
-
[in] dT The time step.
- Returns
- The estimated states.
Implemented in SimpleEstimator2, SimpleEstimator2, DummyEstimator2, and DummyEstimator2.
◆ update() [2/4]
|
pure virtual |
Update without any measurement, using the prediction only.
- Parameters
-
[in] dT The time step.
- Returns
- The estimated states.
Implemented in SimpleEstimator2, SimpleEstimator2, DummyEstimator2, and DummyEstimator2.
◆ update() [3/4]
|
pure virtual |
Given a set of measurements and their covariances, update the estimator and returns the estimated states.
- Parameters
-
[in] measurements A set of (measurement, covariance, isFromDetector) tuples. Pass a negative identity covariance to select the default measurement noise. A positive covariance(0,0) uses the provided noise. [in] dT The time step.
- Returns
- The estimated states.
Implemented in SimpleEstimator2, SimpleEstimator2, DummyEstimator2, and DummyEstimator2.
◆ update() [4/4]
|
pure virtual |
Given a set of measurements and their covariances, update the estimator and returns the estimated states.
- Parameters
-
[in] measurements A set of (measurement, covariance, isFromDetector) tuples. Pass a negative identity covariance to select the default measurement noise. A positive covariance(0,0) uses the provided noise. [in] dT The time step.
- Returns
- The estimated states.
Implemented in SimpleEstimator2, SimpleEstimator2, DummyEstimator2, and DummyEstimator2.
◆ useAspectRatio() [1/2]
|
pure virtual |
Return whether the estimator represents size using aspect ratio.
Implemented in SimpleEstimator2, SimpleEstimator2, DummyEstimator2, and DummyEstimator2.
◆ useAspectRatio() [2/2]
|
pure virtual |
Return whether the estimator represents size using aspect ratio.
Implemented in SimpleEstimator2, SimpleEstimator2, DummyEstimator2, and DummyEstimator2.
The documentation for this class was generated from the following file: