Detailed Description
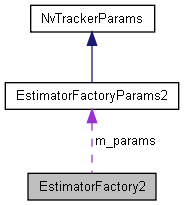
Singleton factory for state estimator objects.
Definition at line 92 of file sources/libs/nvmultiobjecttracker/include/modules/Estimatorv2/estimator_factory2.hpp.
Public Member Functions | |
| std::shared_ptr< IEstimator2 > | makeEstimator (const std::string configFilePath) |
| Create the configured state-estimator implementation. More... | |
| std::shared_ptr< IEstimator2 > | makeEstimator (const std::string configFilePath) |
| Create the configured state-estimator implementation. More... | |
Static Public Member Functions | |
| static EstimatorFactory2 & | getInstance () |
| Return the static instance reference to the factory. More... | |
| static EstimatorFactory2 & | getInstance () |
| Return the static instance reference to the factory. More... | |
Protected Attributes | |
| EstimatorFactoryParams2 | m_params |
| Stores configuration parameters for the state-estimation module. More... | |
Member Function Documentation
◆ getInstance() [1/2]
|
inlinestatic |
Return the static instance reference to the factory.
Definition at line 96 of file sources/libs/nvmultiobjecttracker/include/modules/Estimatorv2/estimator_factory2.hpp.
◆ getInstance() [2/2]
|
inlinestatic |
Return the static instance reference to the factory.
Definition at line 96 of file 9.2/sources/libs/nvmultiobjecttracker/include/modules/Estimatorv2/estimator_factory2.hpp.
◆ makeEstimator() [1/2]
|
inline |
Create the configured state-estimator implementation.
- Parameters
-
[in] configFilePath The path to a configuration file.
Parse config for state estimator module.
Same as LOCATION_ESTIMATOR_SIMPLE but uses covariance-based measurement noise.
Definition at line 106 of file 9.2/sources/libs/nvmultiobjecttracker/include/modules/Estimatorv2/estimator_factory2.hpp.
References BBOX_ESTIMATOR, BBOX_ESTIMATOR_SIMPLE, DUMMY_ESTIMATOR, LOCATION_ESTIMATOR_PROJECTIVE, LOCATION_ESTIMATOR_SIMPLE, m_params, and EstimatorFactoryParams2::m_stateEstimatorType.
◆ makeEstimator() [2/2]
|
inline |
Create the configured state-estimator implementation.
- Parameters
-
[in] configFilePath The path to a configuration file.
Parse config for state estimator module.
Same as LOCATION_ESTIMATOR_SIMPLE but uses covariance-based measurement noise.
Definition at line 106 of file sources/libs/nvmultiobjecttracker/include/modules/Estimatorv2/estimator_factory2.hpp.
References BBOX_ESTIMATOR, BBOX_ESTIMATOR_SIMPLE, DUMMY_ESTIMATOR, LOCATION_ESTIMATOR_PROJECTIVE, LOCATION_ESTIMATOR_SIMPLE, m_params, and EstimatorFactoryParams2::m_stateEstimatorType.
Field Documentation
◆ m_params
|
protected |
Stores configuration parameters for the state-estimation module.
Definition at line 141 of file sources/libs/nvmultiobjecttracker/include/modules/Estimatorv2/estimator_factory2.hpp.
Referenced by makeEstimator().
The documentation for this class was generated from the following file: