Detailed Description
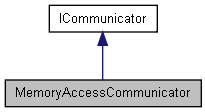
MemoryAccessCommunicator class is responsible for handling the communication between the MultiViewAssociator and the TargetManager (NvTrackedObjectManager).
Definition at line 104 of file sources/libs/nvmultiobjecttracker/include/modules/MultiViewAssociator/MemoryAccessCommunicator.hpp.
Public Member Functions | |
| MemoryAccessCommunicator () | |
| Construct an uninitialized memory-access communicator. More... | |
| MemoryAccessCommunicator (const std::string &configFilePath) | |
| Construct a memory-access communicator from configuration. More... | |
| ~MemoryAccessCommunicator () override | |
| Stop and destroy the memory-access communicator. More... | |
| bool | isInitialized () override |
| Return whether the communicator is initialized. More... | |
| void | initialize (const StreamId streamId, system_clock::time_point start, std::map< StreamId, std::shared_ptr< ICommunicator >> localInstanceCommunicators, const std::string &sensorName="") override |
| Initialize the communicator and start its processing loop. More... | |
| MessageType | available () override |
| Return the type of the next buffered message, or NONE when the buffer is empty. More... | |
| void | requestToSend (Payload payload) override |
| Request to send a message. More... | |
| void | requestToSend (const std::vector< Payload > &payloads) override |
| Request to send a message. More... | |
| void | get (Payload &payload) override |
| Get the message from buffer. More... | |
| void | processMessage (Payload payload) override |
| Process an incoming message. More... | |
| void | broadcast (Payload payload) override |
| Broadcast message. More... | |
| COMMUNICATOR_TYPES | getCommunicatorType () override |
| Return the communicator implementation type. More... | |
| std::vector< CamId > | getPeerCamIds () override |
| Return peer camera IDs from camera configuration. More... | |
| CamId | getEgoCamId () override |
| Return the ego camera ID from camera configuration. More... | |
Constructor & Destructor Documentation
◆ MemoryAccessCommunicator() [1/4]
| MemoryAccessCommunicator::MemoryAccessCommunicator | ( | ) |
Construct an uninitialized memory-access communicator.
◆ MemoryAccessCommunicator() [2/4]
| MemoryAccessCommunicator::MemoryAccessCommunicator | ( | const std::string & | configFilePath | ) |
Construct a memory-access communicator from configuration.
- Parameters
-
[in] configFilePath Path to the configuration file.
◆ ~MemoryAccessCommunicator() [1/2]
|
override |
Stop and destroy the memory-access communicator.
◆ MemoryAccessCommunicator() [3/4]
| MemoryAccessCommunicator::MemoryAccessCommunicator | ( | ) |
Construct an uninitialized memory-access communicator.
◆ MemoryAccessCommunicator() [4/4]
| MemoryAccessCommunicator::MemoryAccessCommunicator | ( | const std::string & | configFilePath | ) |
Construct a memory-access communicator from configuration.
- Parameters
-
[in] configFilePath Path to the configuration file.
◆ ~MemoryAccessCommunicator() [2/2]
|
override |
Stop and destroy the memory-access communicator.
Member Function Documentation
◆ available() [1/2]
|
overridevirtual |
Return the type of the next buffered message, or NONE when the buffer is empty.
Implements ICommunicator.
◆ available() [2/2]
|
overridevirtual |
Return the type of the next buffered message, or NONE when the buffer is empty.
Implements ICommunicator.
◆ broadcast() [1/2]
|
overridevirtual |
◆ broadcast() [2/2]
|
overridevirtual |
◆ get() [1/2]
|
overridevirtual |
Get the message from buffer.
- Parameters
-
[out] payload Message removed from the input buffer.
Implements ICommunicator.
◆ get() [2/2]
|
overridevirtual |
Get the message from buffer.
- Parameters
-
[out] payload Message removed from the input buffer.
Implements ICommunicator.
◆ getCommunicatorType() [1/2]
|
inlineoverridevirtual |
Return the communicator implementation type.
Implements ICommunicator.
Definition at line 169 of file sources/libs/nvmultiobjecttracker/include/modules/MultiViewAssociator/MemoryAccessCommunicator.hpp.
References MEMORY_ACCESS_COMMUNICATOR.
◆ getCommunicatorType() [2/2]
|
inlineoverridevirtual |
Return the communicator implementation type.
Implements ICommunicator.
Definition at line 169 of file 9.2/sources/libs/nvmultiobjecttracker/include/modules/MultiViewAssociator/MemoryAccessCommunicator.hpp.
References MEMORY_ACCESS_COMMUNICATOR.
◆ getEgoCamId() [1/2]
|
overridevirtual |
Return the ego camera ID from camera configuration.
Reimplemented from ICommunicator.
◆ getEgoCamId() [2/2]
|
overridevirtual |
Return the ego camera ID from camera configuration.
Reimplemented from ICommunicator.
◆ getPeerCamIds() [1/2]
|
overridevirtual |
Return peer camera IDs from camera configuration.
Reimplemented from ICommunicator.
◆ getPeerCamIds() [2/2]
|
overridevirtual |
Return peer camera IDs from camera configuration.
Reimplemented from ICommunicator.
◆ initialize() [1/2]
|
overridevirtual |
Initialize the communicator and start its processing loop.
- Parameters
-
[in] streamId Stream identifier for this communicator. [in] start Reference start time for timestamp conversion. [in] localInstanceCommunicators Communicators for local streams. [in] sensorName Sensor name used by external transports.
Implements ICommunicator.
◆ initialize() [2/2]
|
overridevirtual |
Initialize the communicator and start its processing loop.
- Parameters
-
[in] streamId Stream identifier for this communicator. [in] start Reference start time for timestamp conversion. [in] localInstanceCommunicators Communicators for local streams. [in] sensorName Sensor name used by external transports.
Implements ICommunicator.
◆ isInitialized() [1/2]
|
overridevirtual |
Return whether the communicator is initialized.
Implements ICommunicator.
◆ isInitialized() [2/2]
|
overridevirtual |
Return whether the communicator is initialized.
Implements ICommunicator.
◆ processMessage() [1/2]
|
overridevirtual |
Process an incoming message.
- Parameters
-
[in] payload Incoming message to place in the input buffers.
Implements ICommunicator.
◆ processMessage() [2/2]
|
overridevirtual |
Process an incoming message.
- Parameters
-
[in] payload Incoming message to place in the input buffers.
Implements ICommunicator.
◆ requestToSend() [1/4]
|
overridevirtual |
◆ requestToSend() [2/4]
|
overridevirtual |
◆ requestToSend() [3/4]
|
overridevirtual |
◆ requestToSend() [4/4]
|
overridevirtual |
The documentation for this class was generated from the following file: