Detailed Description
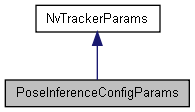
Stores configuration for pose inference.
Definition at line 38 of file sources/libs/nvmultiobjecttracker/include/modules/PoseEstimator/PoseInference.hpp.
Public Member Functions | |
| PoseInferenceConfigParams () | |
| Construct a PoseInferenceConfigParams instance. More... | |
| PoseInferenceConfigParams (const std::string &configFilePath, const std::string moduleName) | |
| Construct a PoseInferenceConfigParams instance. More... | |
| PoseInferenceConfigParams (const YAML::Node &fn) | |
| Construct a PoseInferenceConfigParams instance. More... | |
| void | read (const YAML::Node &fn) override |
| Load configuration values from a YAML node. More... | |
Static Public Member Functions | |
| static std::string | resolvePathRelativeToConfig (const std::string &configFilePath, const std::string &filePath) |
| Resolve a configured path relative to the tracker configuration file. More... | |
| static std::string | resolvePathRelativeToConfig (const std::string &configFilePath, const std::string &filePath) |
| Resolve a configured path relative to the tracker configuration file. More... | |
| static const YAML::Node | getConfigRoot (const std::string &configFilePath, const bool printMessage=false) |
| Load the root YAML node from a tracker configuration file. More... | |
| static const YAML::Node | getConfigRoot (const std::string &configFilePath, const bool printMessage=false) |
| Load the root YAML node from a tracker configuration file. More... | |
Data Fields | |
| POSEESTIMATOR_TYPES | m_poseEstimatorType |
| Type of pose estimator. More... | |
| int | m_hiddenDim |
| Size of each reid feature. More... | |
| std::vector< int > | m_inferDims |
| Reid input dimension. More... | |
| int | m_inputOrder |
| Input dimension order: 0: NCHW, 1: NHWC. More... | |
| int | m_encoderFeatureDim |
| Size of each encoder feature. More... | |
| int | m_width |
| Input image patch width. More... | |
| int | m_height |
| Input image patch height. More... | |
| int | m_channel |
| Input image patch channel. More... | |
| int | m_maxBatchSize |
| Maximum batch size for reid network. More... | |
| int | m_gpuId |
| Gpu id. More... | |
| int | m_poseInferenceInterval |
| Pose inference interval. More... | |
| float | m_netScaleFactor |
| Input normalization factor. More... | |
| std::vector< float > | m_offsets |
| List of mean values of color components to be subtracted from input. More... | |
| NvBufSurfaceColorFormat | m_colorFormat |
| Color format of input to reid network. More... | |
| bool | m_useVPICropScaler |
| Use VPI crop scaler instead of in built crop scaler. More... | |
| std::string | m_vizDir |
| Dir to save visualization dumps. More... | |
| int | m_debugVerboseLevel |
| Debug message verbose mode level. More... | |
| bool | m_saveFrameViz |
| Save overlay masks for each target in each frame. More... | |
| std::vector< int > | m_operateOnClassIds |
| Class IDs selected for pose estimation. More... | |
Constructor & Destructor Documentation
◆ PoseInferenceConfigParams() [1/6]
| PoseInferenceConfigParams::PoseInferenceConfigParams | ( | ) |
Construct a PoseInferenceConfigParams instance.
◆ PoseInferenceConfigParams() [2/6]
| PoseInferenceConfigParams::PoseInferenceConfigParams | ( | const std::string & | configFilePath, |
| const std::string | moduleName | ||
| ) |
Construct a PoseInferenceConfigParams instance.
- Parameters
-
[in] configFilePath Path to the tracker configuration file. [in] moduleName Configuration module name.
◆ PoseInferenceConfigParams() [3/6]
| PoseInferenceConfigParams::PoseInferenceConfigParams | ( | const YAML::Node & | fn | ) |
Construct a PoseInferenceConfigParams instance.
- Parameters
-
[in] fn Parsed YAML node.
◆ PoseInferenceConfigParams() [4/6]
| PoseInferenceConfigParams::PoseInferenceConfigParams | ( | ) |
Construct a PoseInferenceConfigParams instance.
◆ PoseInferenceConfigParams() [5/6]
| PoseInferenceConfigParams::PoseInferenceConfigParams | ( | const std::string & | configFilePath, |
| const std::string | moduleName | ||
| ) |
Construct a PoseInferenceConfigParams instance.
- Parameters
-
[in] configFilePath Path to the tracker configuration file. [in] moduleName Configuration module name.
◆ PoseInferenceConfigParams() [6/6]
| PoseInferenceConfigParams::PoseInferenceConfigParams | ( | const YAML::Node & | fn | ) |
Construct a PoseInferenceConfigParams instance.
- Parameters
-
[in] fn Parsed YAML node.
Member Function Documentation
◆ getConfigRoot() [1/2]
|
inlinestaticinherited |
Load the root YAML node from a tracker configuration file.
- Parameters
-
[in] configFilePath Path to the tracker configuration file. [in] printMessage Enables warning output when the configuration cannot be loaded.
- Returns
- Loaded YAML root node, or an empty node when loading fails.
Definition at line 121 of file sources/libs/nvmultiobjecttracker/include/modules/NvMultiObjectTracker/NvTrackerParams.hpp.
References CLOG.
Referenced by CommunicatorFactoryParams::CommunicatorFactoryParams(), CommunicatorParams::CommunicatorParams(), DataAssociatorFactoryParams::DataAssociatorFactoryParams(), EstimatorFactoryParams2::EstimatorFactoryParams2(), MqttCommunicatorParams::MqttCommunicatorParams(), MultiViewAssociatorFactoryParams::MultiViewAssociatorFactoryParams(), MultiViewAssociatorParams::MultiViewAssociatorParams(), PoseEstimatorFactoryParams::PoseEstimatorFactoryParams(), ReIDFactoryParams::ReIDFactoryParams(), ReIDServiceFactoryParams::ReIDServiceFactoryParams(), SegmenterFactoryParams::SegmenterFactoryParams(), and VisualTrackerFactoryParams::VisualTrackerFactoryParams().
◆ getConfigRoot() [2/2]
|
inlinestaticinherited |
Load the root YAML node from a tracker configuration file.
- Parameters
-
[in] configFilePath Path to the tracker configuration file. [in] printMessage Enables warning output when the configuration cannot be loaded.
- Returns
- Loaded YAML root node, or an empty node when loading fails.
Definition at line 121 of file 9.2/sources/libs/nvmultiobjecttracker/include/modules/NvMultiObjectTracker/NvTrackerParams.hpp.
References CLOG.
◆ read() [1/2]
|
overridevirtual |
Load configuration values from a YAML node.
- Parameters
-
[in] fn Parsed YAML node.
Implements NvTrackerParams.
◆ read() [2/2]
|
overridevirtual |
Load configuration values from a YAML node.
- Parameters
-
[in] fn Parsed YAML node.
Implements NvTrackerParams.
◆ resolvePathRelativeToConfig() [1/2]
|
inlinestaticinherited |
Resolve a configured path relative to the tracker configuration file.
Existing paths are canonicalized, while nonexistent relative paths remain joined to the configuration directory.
- Parameters
-
[in] configFilePath Path to the tracker configuration file. [in] filePath Absolute or configuration-relative path to resolve.
- Returns
- Resolved path, or the original path when the configuration path cannot be resolved.
Definition at line 55 of file sources/libs/nvmultiobjecttracker/include/modules/NvMultiObjectTracker/NvTrackerParams.hpp.
Referenced by CommunicatorParams::CommunicatorParams(), and MqttCommunicatorParams::MqttCommunicatorParams().
◆ resolvePathRelativeToConfig() [2/2]
|
inlinestaticinherited |
Resolve a configured path relative to the tracker configuration file.
Existing paths are canonicalized, while nonexistent relative paths remain joined to the configuration directory.
- Parameters
-
[in] configFilePath Path to the tracker configuration file. [in] filePath Absolute or configuration-relative path to resolve.
- Returns
- Resolved path, or the original path when the configuration path cannot be resolved.
Definition at line 55 of file 9.2/sources/libs/nvmultiobjecttracker/include/modules/NvMultiObjectTracker/NvTrackerParams.hpp.
Field Documentation
◆ m_channel
| int PoseInferenceConfigParams::m_channel |
Input image patch channel.
Definition at line 70 of file sources/libs/nvmultiobjecttracker/include/modules/PoseEstimator/PoseInference.hpp.
◆ m_colorFormat
| NvBufSurfaceColorFormat PoseInferenceConfigParams::m_colorFormat |
Color format of input to reid network.
Definition at line 76 of file sources/libs/nvmultiobjecttracker/include/modules/PoseEstimator/PoseInference.hpp.
◆ m_debugVerboseLevel
| int PoseInferenceConfigParams::m_debugVerboseLevel |
Debug message verbose mode level.
Definition at line 79 of file sources/libs/nvmultiobjecttracker/include/modules/PoseEstimator/PoseInference.hpp.
◆ m_encoderFeatureDim
| int PoseInferenceConfigParams::m_encoderFeatureDim |
Size of each encoder feature.
Definition at line 67 of file sources/libs/nvmultiobjecttracker/include/modules/PoseEstimator/PoseInference.hpp.
◆ m_gpuId
| int PoseInferenceConfigParams::m_gpuId |
Gpu id.
Definition at line 72 of file sources/libs/nvmultiobjecttracker/include/modules/PoseEstimator/PoseInference.hpp.
◆ m_height
| int PoseInferenceConfigParams::m_height |
Input image patch height.
Definition at line 69 of file sources/libs/nvmultiobjecttracker/include/modules/PoseEstimator/PoseInference.hpp.
◆ m_hiddenDim
| int PoseInferenceConfigParams::m_hiddenDim |
Size of each reid feature.
Definition at line 64 of file sources/libs/nvmultiobjecttracker/include/modules/PoseEstimator/PoseInference.hpp.
◆ m_inferDims
| std::vector< int > PoseInferenceConfigParams::m_inferDims |
Reid input dimension.
Definition at line 65 of file sources/libs/nvmultiobjecttracker/include/modules/PoseEstimator/PoseInference.hpp.
◆ m_inputOrder
| int PoseInferenceConfigParams::m_inputOrder |
Input dimension order: 0: NCHW, 1: NHWC.
Definition at line 66 of file sources/libs/nvmultiobjecttracker/include/modules/PoseEstimator/PoseInference.hpp.
◆ m_maxBatchSize
| int PoseInferenceConfigParams::m_maxBatchSize |
Maximum batch size for reid network.
Definition at line 71 of file sources/libs/nvmultiobjecttracker/include/modules/PoseEstimator/PoseInference.hpp.
◆ m_netScaleFactor
| float PoseInferenceConfigParams::m_netScaleFactor |
Input normalization factor.
Definition at line 74 of file sources/libs/nvmultiobjecttracker/include/modules/PoseEstimator/PoseInference.hpp.
◆ m_offsets
| std::vector< float > PoseInferenceConfigParams::m_offsets |
List of mean values of color components to be subtracted from input.
Definition at line 75 of file sources/libs/nvmultiobjecttracker/include/modules/PoseEstimator/PoseInference.hpp.
◆ m_operateOnClassIds
| std::vector< int > PoseInferenceConfigParams::m_operateOnClassIds |
Class IDs selected for pose estimation.
An empty list enables all classes, while [0] selects only the person class.
Definition at line 81 of file sources/libs/nvmultiobjecttracker/include/modules/PoseEstimator/PoseInference.hpp.
◆ m_poseEstimatorType
| POSEESTIMATOR_TYPES PoseInferenceConfigParams::m_poseEstimatorType |
Type of pose estimator.
Definition at line 63 of file sources/libs/nvmultiobjecttracker/include/modules/PoseEstimator/PoseInference.hpp.
Referenced by PoseInference::getPoseEstimatorType().
◆ m_poseInferenceInterval
| int PoseInferenceConfigParams::m_poseInferenceInterval |
Pose inference interval.
Definition at line 73 of file sources/libs/nvmultiobjecttracker/include/modules/PoseEstimator/PoseInference.hpp.
◆ m_saveFrameViz
| bool PoseInferenceConfigParams::m_saveFrameViz |
Save overlay masks for each target in each frame.
Definition at line 80 of file sources/libs/nvmultiobjecttracker/include/modules/PoseEstimator/PoseInference.hpp.
◆ m_useVPICropScaler
| bool PoseInferenceConfigParams::m_useVPICropScaler |
Use VPI crop scaler instead of in built crop scaler.
Definition at line 77 of file sources/libs/nvmultiobjecttracker/include/modules/PoseEstimator/PoseInference.hpp.
◆ m_vizDir
| std::string PoseInferenceConfigParams::m_vizDir |
Dir to save visualization dumps.
Definition at line 78 of file sources/libs/nvmultiobjecttracker/include/modules/PoseEstimator/PoseInference.hpp.
◆ m_width
| int PoseInferenceConfigParams::m_width |
Input image patch width.
Definition at line 68 of file sources/libs/nvmultiobjecttracker/include/modules/PoseEstimator/PoseInference.hpp.
The documentation for this class was generated from the following file: