Detailed Description
Renders and writes visual tracker debugging output.
Definition at line 43 of file sources/libs/nvmultiobjecttracker/include/modules/VisualTracker/vizOutput.hpp.
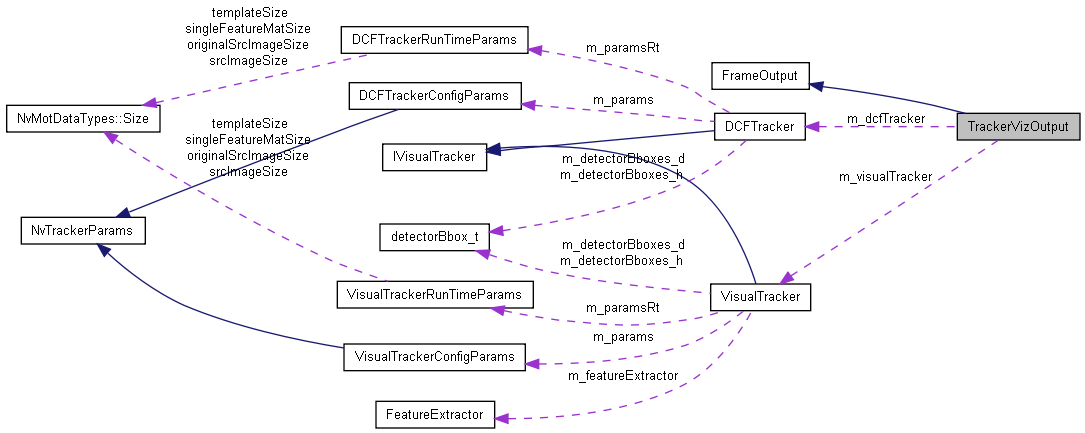
Public Member Functions | |
| TrackerVizOutput (VisualTracker *visTracker, const std::shared_ptr< NvTrackedObjectManager > targets) | |
| Construct output rendering for a CUDA visual tracker. More... | |
| TrackerVizOutput (DCFTracker *dcfTracker, const std::shared_ptr< NvTrackedObjectManager > targets) | |
| Construct output rendering for a VPI DCF tracker. More... | |
| ~TrackerVizOutput () | |
| Destroy the visualization output writer. More... | |
| cv::Mat | make_dist_colors (unsigned nb) |
| Generate visually distinct BGR colors by distributing shuffled hues. More... | |
| void | writeBirdsEyeView (const uint outputDirectoryKey=0) |
| Render and write a bird's-eye view for each available stream. More... | |
| void | writeAllTrajectoriesOnEveryFrame (const uint outputDirectoryKey=0) |
| Draw all current trajectories on each available source frame and write the results. More... | |
| void | writeEachCompletedTrajectory (const uint outputDirectoryKey=0) |
| Draw and write each trajectory after its track completes. More... | |
| void | writeSrcImagePatchesWithCorrResp (const uint outputDirectoryKey=0) |
| Write source image patches alongside their correlation-response visualizations. More... | |
| void | writeSrcImagePatchesWithMaskFilter (const uint outputDirectoryKey=0) |
| Write source image patches alongside their segmentation-filter masks. More... | |
| bool | isImageOutputEnabled (const uint outputDirectoryKey=0) |
| Report whether image output is enabled for a directory key. More... | |
| bool | isImageOutputEnabled (const uint outputDirectoryKey=0) |
| Report whether image output is enabled for a directory key. More... | |
| bool | isVideoOutputEnabled () |
| Report whether video output is enabled. More... | |
| bool | isVideoOutputEnabled () |
| Report whether video output is enabled. More... | |
| bool | enableVideoOutput (const std::string outputVideoDirectory, const std::string outputVideoName, cv::Size videoSize, const double fps=5.f) |
| Create an AVI writer and enable video output. More... | |
| bool | enableVideoOutput (const std::string outputVideoDirectory, const std::string outputVideoName, cv::Size videoSize, const double fps=5.f) |
| Create an AVI writer and enable video output. More... | |
| void | enableImageOutput (const std::string outputImageDirectory, const int compressionLevel=95, const uint outputDirectoryKey=0) |
| Configure a keyed directory for JPEG image output. More... | |
| void | enableImageOutput (const std::string outputImageDirectory, const int compressionLevel=95, const uint outputDirectoryKey=0) |
| Configure a keyed directory for JPEG image output. More... | |
| void | writeVideoOutput (const cv::Mat &img) |
| Append an image to the output video. More... | |
| void | writeVideoOutput (const cv::Mat &img) |
| Append an image to the output video. More... | |
| void | writeImageOutput (const cv::Mat &img, const std::string imgFilename, const uint outputDirectoryKey=0, const std::string subFolderName="") |
| Write an image to a keyed output directory. More... | |
| void | writeImageOutput (const cv::Mat &img, const std::string imgFilename, const uint outputDirectoryKey=0, const std::string subFolderName="") |
| Write an image to a keyed output directory. More... | |
Protected Member Functions | |
| void | writeSrcImagePatchesWithCorrResp_perTarget (const NvMOTStreamId streamId_, const int trackerInd, const uint outputDirectoryKey, cv::Mat srcImgPatch, cv::Mat corrRespMat) |
| Buffer a source patch paired with its correlation-response image for one target. More... | |
| void | writeSrcImagePatchesWithMaskFilter_perTarget (const NvMOTStreamId streamId_, const int trackerInd, const uint outputDirectoryKey, cv::Mat srcImgPatch, cv::Mat maskMat) |
| Buffer a source patch paired with its segmentation-filter mask for one target. More... | |
| void | addToWriteBuffer (const std::shared_ptr< NvTrackedObject > target, const cv::Mat &img, const uint frameNum, const uint outputDirectoryKey, const std::string subFolderName, const std::string fileNamePrefix="") |
| Add an image to a target's pending output buffer. More... | |
| void | writeFromWriteBuffer (const std::shared_ptr< NvTrackedObject > target) |
| Write and clear pending images after a target receives a persistent ID. More... | |
| cv::Mat | prepareCorrelationResponseImg (const NvMOTStreamId streamId_, const uint trackerInd, std::vector< cv::Mat > &corrRespMats, const cv::Size dstSize, const bool showPeakPoint=true, const bool showDetBboxes=true) |
| Prepare a color-mapped correlation response with optional target and detection markers. More... | |
| cv::Mat | prepareMaskFilterImg (const NvMOTStreamId streamId_, const uint trackerInd, std::vector< cv::Mat > &maskMats, const cv::Size dstSize) |
| Prepare an 8-bit BGR visualization of a target's segmentation-filter mask. More... | |
| void | drawFullTrajectory (const uint64_t targetID, const std::list< TargetInfo > &trajectory, cv::Mat &frame) |
| Draw a target's complete trajectory on a frame. More... | |
| void | drawRecentTrajectory (const std::shared_ptr< NvTrackedObject > tracker, cv::Mat &frame, const bool showCurrentDetBbox=true, const bool showCurrentTargetBbox=true, const bool showPrediction=false, const bool showPredictionUncertainty=false, const bool showTrajectoryOnFeet=false) |
| Draw a target's recent trajectory, current boxes, and optional predictions on a frame. More... | |
| void | drawUncertaintyEllipse (cv::Mat &frame, const cv::Mat P, const cv::Mat Pcov, cv::Scalar color, float scale=1.f) |
| Draw a covariance-derived uncertainty ellipse around a predicted position. More... | |
| void | drawProjectedTargetModel (const std::shared_ptr< NvTrackedObject > target, cv::Mat &frame) |
| Draw a target's projected human model on the camera frame. More... | |
| void | drawProjectedPeerTrajectory (const PeerTargetDB &peerTargetDB, cv::Mat &frame, const NvMOTStreamId &videoStreamID, const int &frameNum, const std::map< TargetId, cv::Scalar > &targetColorList) |
| Draw peer-camera target boxes and trajectories projected into the current camera frame. More... | |
Protected Attributes | |
| VisualTracker * | m_visualTracker = NULL |
| CUDA visual tracker that supplies visualization data. More... | |
| DCFTracker * | m_dcfTracker = NULL |
| VPI DCF tracker that supplies visualization data. More... | |
| const std::shared_ptr< NvTrackedObjectManager > | m_targets |
| Manager that supplies tracked objects. More... | |
| const int | m_displayWidth = 1920 |
| Display/screen width. More... | |
| const int | m_srcImgWH = 240 |
| Visualization width and height for source image patches. More... | |
| const int | m_featImgWH = 160 |
| Visualization width and height for feature images. More... | |
| std::map< uint32_t, std::deque< WriteBuffer_t > > | m_writeBuffer |
| Buffered outputs grouped by target index. More... | |
| std::map< NvMOTStreamId, uint64_t > | m_lastFrameMatchedInTrajectoryArchive |
| The target ID of the latest trajectory archived. More... | |
| std::map< NvMOTStreamId, cv::Mat > | m_lastFrames |
| The last source frame kept. More... | |
| cv::VideoWriter * | mOutputVideo |
| Video writer used when video output is enabled. More... | |
| bool | mIsVideoOutputEnabled |
| Indicates whether video output is enabled. More... | |
| std::vector< int > | compression_params |
| OpenCV image-encoding parameters. More... | |
| std::unordered_map< uint, std::string > | mOutputImageDirectory |
| Image output directories keyed by caller-defined values. More... | |
| std::unordered_map< uint, bool > | mIsImageOutputEnabled |
| Image-output enabled state for each directory key. More... | |
Constructor & Destructor Documentation
◆ TrackerVizOutput() [1/4]
|
inline |
Construct output rendering for a CUDA visual tracker.
- Parameters
-
[in] visTracker The CUDA visual tracker that supplies visualization data. [in] targets The manager that supplies tracked objects.
Definition at line 111 of file sources/libs/nvmultiobjecttracker/include/modules/VisualTracker/vizOutput.hpp.
◆ TrackerVizOutput() [2/4]
|
inline |
Construct output rendering for a VPI DCF tracker.
- Parameters
-
[in] dcfTracker The VPI DCF tracker that supplies visualization data. [in] targets The manager that supplies tracked objects.
Definition at line 121 of file sources/libs/nvmultiobjecttracker/include/modules/VisualTracker/vizOutput.hpp.
◆ ~TrackerVizOutput() [1/2]
|
inline |
Destroy the visualization output writer.
Definition at line 127 of file sources/libs/nvmultiobjecttracker/include/modules/VisualTracker/vizOutput.hpp.
◆ TrackerVizOutput() [3/4]
|
inline |
Construct output rendering for a CUDA visual tracker.
- Parameters
-
[in] visTracker The CUDA visual tracker that supplies visualization data. [in] targets The manager that supplies tracked objects.
Definition at line 111 of file 9.2/sources/libs/nvmultiobjecttracker/include/modules/VisualTracker/vizOutput.hpp.
◆ TrackerVizOutput() [4/4]
|
inline |
Construct output rendering for a VPI DCF tracker.
- Parameters
-
[in] dcfTracker The VPI DCF tracker that supplies visualization data. [in] targets The manager that supplies tracked objects.
Definition at line 121 of file 9.2/sources/libs/nvmultiobjecttracker/include/modules/VisualTracker/vizOutput.hpp.
◆ ~TrackerVizOutput() [2/2]
|
inline |
Destroy the visualization output writer.
Definition at line 127 of file 9.2/sources/libs/nvmultiobjecttracker/include/modules/VisualTracker/vizOutput.hpp.
Member Function Documentation
◆ addToWriteBuffer() [1/2]
|
inlineprotected |
Add an image to a target's pending output buffer.
- Parameters
-
[in] target The tracked object that owns the output. [in] img The image to buffer. [in] frameNum The associated frame number. [in] outputDirectoryKey The output directory selector. [in] subFolderName The output subfolder name. [in] fileNamePrefix The output filename prefix.
Clear any existing ones.
Definition at line 751 of file sources/libs/nvmultiobjecttracker/include/modules/VisualTracker/vizOutput.hpp.
References m_writeBuffer, and absl::move().
Referenced by writeSrcImagePatchesWithCorrResp_perTarget(), and writeSrcImagePatchesWithMaskFilter_perTarget().
◆ addToWriteBuffer() [2/2]
|
inlineprotected |
Add an image to a target's pending output buffer.
- Parameters
-
[in] target The tracked object that owns the output. [in] img The image to buffer. [in] frameNum The associated frame number. [in] outputDirectoryKey The output directory selector. [in] subFolderName The output subfolder name. [in] fileNamePrefix The output filename prefix.
Clear any existing ones.
Definition at line 751 of file 9.2/sources/libs/nvmultiobjecttracker/include/modules/VisualTracker/vizOutput.hpp.
References m_writeBuffer, and absl::move().
◆ drawFullTrajectory() [1/2]
|
inlineprotected |
Draw a target's complete trajectory on a frame.
- Parameters
-
[in] targetID The persistent target identifier. [in] trajectory The complete target trajectory. [in,out] frame The frame updated with the rendered trajectory.
Param to be configured.
Show target ID.
Definition at line 971 of file sources/libs/nvmultiobjecttracker/include/modules/VisualTracker/vizOutput.hpp.
References ACTIVE, max(), and PROJECTED.
Referenced by writeEachCompletedTrajectory().
◆ drawFullTrajectory() [2/2]
|
inlineprotected |
Draw a target's complete trajectory on a frame.
- Parameters
-
[in] targetID The persistent target identifier. [in] trajectory The complete target trajectory. [in,out] frame The frame updated with the rendered trajectory.
Param to be configured.
Show target ID.
Definition at line 971 of file 9.2/sources/libs/nvmultiobjecttracker/include/modules/VisualTracker/vizOutput.hpp.
◆ drawProjectedPeerTrajectory() [1/2]
|
inlineprotected |
Draw peer-camera target boxes and trajectories projected into the current camera frame.
- Parameters
-
[in] peerTargetDB The peer-camera target database. [in,out] frame The camera frame updated with peer trajectories. [in] videoStreamID The current video stream identifier. [in] frameNum The current frame number. [in] targetColorList Colors already assigned to local target identifiers.
Skip peers whose last frame is more than two frames behind.
Set target trajectory color.
Not the first point.
Definition at line 1354 of file sources/libs/nvmultiobjecttracker/include/modules/VisualTracker/vizOutput.hpp.
References PeerTarget::frameNum, m_targets, make_dist_colors(), PeerTarget::nextState, and PeerTarget::tracklet.
Referenced by writeAllTrajectoriesOnEveryFrame().
◆ drawProjectedPeerTrajectory() [2/2]
|
inlineprotected |
Draw peer-camera target boxes and trajectories projected into the current camera frame.
- Parameters
-
[in] peerTargetDB The peer-camera target database. [in,out] frame The camera frame updated with peer trajectories. [in] videoStreamID The current video stream identifier. [in] frameNum The current frame number. [in] targetColorList Colors already assigned to local target identifiers.
Skip peers whose last frame is more than two frames behind.
Set target trajectory color.
Not the first point.
Definition at line 1354 of file 9.2/sources/libs/nvmultiobjecttracker/include/modules/VisualTracker/vizOutput.hpp.
References PeerTarget::frameNum, m_targets, make_dist_colors(), PeerTarget::nextState, and PeerTarget::tracklet.
◆ drawProjectedTargetModel() [1/2]
|
inlineprotected |
Draw a target's projected human model on the camera frame.
- Parameters
-
[in] target The tracked object whose model is drawn. [in,out] frame The camera frame updated with the projected model.
If the last target state is not Active, then don't draw.
Draw the cylinderic human model.
Draw the feet location.
Definition at line 1292 of file sources/libs/nvmultiobjecttracker/include/modules/VisualTracker/vizOutput.hpp.
References ACTIVE, CV_FUNCS::convexHull(), TargetInfo::convexHull, TargetInfo::loc, TargetInfo::pt_img_feet, and TENTATIVE.
Referenced by writeAllTrajectoriesOnEveryFrame().
◆ drawProjectedTargetModel() [2/2]
|
inlineprotected |
Draw a target's projected human model on the camera frame.
- Parameters
-
[in] target The tracked object whose model is drawn. [in,out] frame The camera frame updated with the projected model.
If the last target state is not Active, then don't draw.
Draw the cylinderic human model.
Draw the feet location.
Definition at line 1292 of file 9.2/sources/libs/nvmultiobjecttracker/include/modules/VisualTracker/vizOutput.hpp.
References ACTIVE, CV_FUNCS::convexHull(), TargetInfo::convexHull, TargetInfo::loc, TargetInfo::pt_img_feet, and TENTATIVE.
◆ drawRecentTrajectory() [1/2]
|
inlineprotected |
Draw a target's recent trajectory, current boxes, and optional predictions on a frame.
- Parameters
-
[in] tracker The tracked object whose trajectory is drawn. [in,out] frame The frame updated with the rendered trajectory. [in] showCurrentDetBbox Whether to draw the current detector bounding box. [in] showCurrentTargetBbox Whether to draw the current target bounding box. [in] showPrediction Whether to draw predicted target positions. [in] showPredictionUncertainty Whether to draw prediction uncertainty. [in] showTrajectoryOnFeet Whether to anchor trajectory points at projected feet locations.
Param to be configured.
If the last target state is not Active, then don't draw.
Show target ID.
Consider only the latest N points.
Feet location.
Bbox center.
Bbox center.
Draw original detection bbox if there is.
Draw current bbox.
Draw the bbox center.
Time intervals for prediction.
The drawn radius is a fixed stand-in for uncertainty.
Two ellipses to show the prediction and uncertainty.
Draw the projected circle.
Time intervals for prediction.
Two ellipses to show the prediction and uncertainty.
Definition at line 1038 of file sources/libs/nvmultiobjecttracker/include/modules/VisualTracker/vizOutput.hpp.
References ACTIVE, _NvMOTObjToTrack::bbox, CV_FUNCS::constructRect2f(), drawUncertaintyEllipse(), _NvMOTRect::height, max(), TENTATIVE, _NvMOTRect::width, _NvMOTRect::x, and _NvMOTRect::y.
Referenced by writeAllTrajectoriesOnEveryFrame().
◆ drawRecentTrajectory() [2/2]
|
inlineprotected |
Draw a target's recent trajectory, current boxes, and optional predictions on a frame.
- Parameters
-
[in] tracker The tracked object whose trajectory is drawn. [in,out] frame The frame updated with the rendered trajectory. [in] showCurrentDetBbox Whether to draw the current detector bounding box. [in] showCurrentTargetBbox Whether to draw the current target bounding box. [in] showPrediction Whether to draw predicted target positions. [in] showPredictionUncertainty Whether to draw prediction uncertainty. [in] showTrajectoryOnFeet Whether to anchor trajectory points at projected feet locations.
Param to be configured.
If the last target state is not Active, then don't draw.
Show target ID.
Consider only the latest N points.
Feet location.
Bbox center.
Bbox center.
Draw original detection bbox if there is.
Draw current bbox.
Draw the bbox center.
Time intervals for prediction.
The drawn radius is a fixed stand-in for uncertainty.
Two ellipses to show the prediction and uncertainty.
Draw the projected circle.
Time intervals for prediction.
Two ellipses to show the prediction and uncertainty.
Definition at line 1038 of file 9.2/sources/libs/nvmultiobjecttracker/include/modules/VisualTracker/vizOutput.hpp.
References ACTIVE, _NvMOTObjToTrack::bbox, CV_FUNCS::constructRect2f(), drawUncertaintyEllipse(), _NvMOTRect::height, max(), TENTATIVE, _NvMOTRect::width, _NvMOTRect::x, and _NvMOTRect::y.
◆ drawUncertaintyEllipse() [1/2]
|
inlineprotected |
Draw a covariance-derived uncertainty ellipse around a predicted position.
- Parameters
-
[in,out] frame The frame updated with the rendered ellipse. [in] P The predicted position vector. [in] Pcov The predicted position covariance matrix. [in] color The ellipse color. [in] scale The ellipse-size scale factor.
Compute the vanishing correlation coefficient.
Compute the principal semi-diameters of the ellipse.
Compute the angle between the x1 axis and the semi-diameter of length p1.
Convert from Radian to Degree.
Drawing the ellipse.
Definition at line 1247 of file 9.2/sources/libs/nvmultiobjecttracker/include/modules/VisualTracker/vizOutput.hpp.
References half_float::atan(), half_float::cos(), half_float::pow(), half_float::sin(), half_float::detail::sqrt(), and width.
◆ drawUncertaintyEllipse() [2/2]
|
inlineprotected |
Draw a covariance-derived uncertainty ellipse around a predicted position.
- Parameters
-
[in,out] frame The frame updated with the rendered ellipse. [in] P The predicted position vector. [in] Pcov The predicted position covariance matrix. [in] color The ellipse color. [in] scale The ellipse-size scale factor.
Compute the vanishing correlation coefficient.
Compute the principal semi-diameters of the ellipse.
Compute the angle between the x1 axis and the semi-diameter of length p1.
Convert from Radian to Degree.
Drawing the ellipse.
Definition at line 1247 of file sources/libs/nvmultiobjecttracker/include/modules/VisualTracker/vizOutput.hpp.
References half_float::atan(), half_float::cos(), half_float::pow(), half_float::sin(), half_float::detail::sqrt(), and width.
Referenced by drawRecentTrajectory().
◆ enableImageOutput() [1/2]
|
inlineinherited |
Configure a keyed directory for JPEG image output.
- Parameters
-
[in] outputImageDirectory Directory in which images are written. [in] compressionLevel JPEG quality level. [in] outputDirectoryKey Key used to select the output directory.
Set the JPEG image quality.
Definition at line 116 of file sources/libs/nvmultiobjecttracker/include/modules/utility/FrameOutput.hpp.
References FrameOutput::compression_params, FrameOutput::mIsImageOutputEnabled, and FrameOutput::mOutputImageDirectory.
◆ enableImageOutput() [2/2]
|
inlineinherited |
Configure a keyed directory for JPEG image output.
- Parameters
-
[in] outputImageDirectory Directory in which images are written. [in] compressionLevel JPEG quality level. [in] outputDirectoryKey Key used to select the output directory.
Set the JPEG image quality.
Definition at line 116 of file 9.2/sources/libs/nvmultiobjecttracker/include/modules/utility/FrameOutput.hpp.
References FrameOutput::compression_params, FrameOutput::mIsImageOutputEnabled, and FrameOutput::mOutputImageDirectory.
◆ enableVideoOutput() [1/2]
|
inlineinherited |
Create an AVI writer and enable video output.
- Parameters
-
[in] outputVideoDirectory Directory in which the video is written. [in] outputVideoName Base name of the output video file. [in] videoSize Output video frame size. [in] fps Output video frame rate.
- Returns
- True when the output video is opened successfully.
Definition at line 78 of file sources/libs/nvmultiobjecttracker/include/modules/utility/FrameOutput.hpp.
References FrameOutput::mIsVideoOutputEnabled, and FrameOutput::mOutputVideo.
◆ enableVideoOutput() [2/2]
|
inlineinherited |
Create an AVI writer and enable video output.
- Parameters
-
[in] outputVideoDirectory Directory in which the video is written. [in] outputVideoName Base name of the output video file. [in] videoSize Output video frame size. [in] fps Output video frame rate.
- Returns
- True when the output video is opened successfully.
Definition at line 78 of file 9.2/sources/libs/nvmultiobjecttracker/include/modules/utility/FrameOutput.hpp.
References FrameOutput::mIsVideoOutputEnabled, and FrameOutput::mOutputVideo.
◆ isImageOutputEnabled() [1/2]
|
inlineinherited |
Report whether image output is enabled for a directory key.
- Parameters
-
[in] outputDirectoryKey Output directory key to query.
Definition at line 55 of file sources/libs/nvmultiobjecttracker/include/modules/utility/FrameOutput.hpp.
References FrameOutput::mIsImageOutputEnabled.
Referenced by FrameOutput::writeImageOutput().
◆ isImageOutputEnabled() [2/2]
|
inlineinherited |
Report whether image output is enabled for a directory key.
- Parameters
-
[in] outputDirectoryKey Output directory key to query.
Definition at line 55 of file 9.2/sources/libs/nvmultiobjecttracker/include/modules/utility/FrameOutput.hpp.
References FrameOutput::mIsImageOutputEnabled.
◆ isVideoOutputEnabled() [1/2]
|
inlineinherited |
Report whether video output is enabled.
Definition at line 68 of file sources/libs/nvmultiobjecttracker/include/modules/utility/FrameOutput.hpp.
References FrameOutput::mIsVideoOutputEnabled.
◆ isVideoOutputEnabled() [2/2]
|
inlineinherited |
Report whether video output is enabled.
Definition at line 68 of file 9.2/sources/libs/nvmultiobjecttracker/include/modules/utility/FrameOutput.hpp.
References FrameOutput::mIsVideoOutputEnabled.
◆ make_dist_colors() [1/2]
|
inline |
Generate visually distinct BGR colors by distributing shuffled hues.
- Parameters
-
[in] nb The number of colors to generate.
- Returns
- A single-row BGR matrix containing the generated colors.
Compute step to cover the whole hue range in OpenCV.
Generate hue values.
Shuffle the hue values randomly.
Build the HSV matrix with shuffled hues. High saturation and value for vivid colors.
Definition at line 134 of file sources/libs/nvmultiobjecttracker/include/modules/VisualTracker/vizOutput.hpp.
Referenced by drawProjectedPeerTrajectory().
◆ make_dist_colors() [2/2]
|
inline |
Generate visually distinct BGR colors by distributing shuffled hues.
- Parameters
-
[in] nb The number of colors to generate.
- Returns
- A single-row BGR matrix containing the generated colors.
Compute step to cover the whole hue range in OpenCV.
Generate hue values.
Shuffle the hue values randomly.
Build the HSV matrix with shuffled hues. High saturation and value for vivid colors.
Definition at line 134 of file 9.2/sources/libs/nvmultiobjecttracker/include/modules/VisualTracker/vizOutput.hpp.
◆ prepareCorrelationResponseImg() [1/2]
|
inlineprotected |
Prepare a color-mapped correlation response with optional target and detection markers.
- Parameters
-
[in] streamId_ The video stream identifier. [in] trackerInd The target's tracker index. [in] corrRespMats The correlation-response matrices for the tracker batch. [in] dstSize The requested output image size. [in] showPeakPoint Whether to draw the localized peak. [in] showDetBboxes Whether to draw nearby detector bounding-box centers.
- Returns
- The prepared BGR correlation-response image.
Normalize to a high-enough magnitude for better visualization.
Wrap around with the circular shifting.
Draw the peak point.
Draw the detector bbox points within the search region.
Convert the center point of the detector bbox into the tracker corr resp's coordinate system.
Convert the center point of the detector bbox into the tracker corr resp's coordinate system.
Definition at line 809 of file sources/libs/nvmultiobjecttracker/include/modules/VisualTracker/vizOutput.hpp.
References CV_FUNCS::circshift(), EMPTY, m_dcfTracker, DCFTracker::m_detectorBboxes_h, VisualTracker::m_detectorBboxes_h, DCFTracker::m_detectorBboxes_size_h, VisualTracker::m_detectorBboxes_size_h, VisualTracker::m_targetDisplacement2D_h, m_targets, m_visualTracker, normalize(), pydeepstreamdoc::tensor::TensorDoc::size, width, detectorBbox_t::x, and detectorBbox_t::y.
Referenced by writeSrcImagePatchesWithCorrResp().
◆ prepareCorrelationResponseImg() [2/2]
|
inlineprotected |
Prepare a color-mapped correlation response with optional target and detection markers.
- Parameters
-
[in] streamId_ The video stream identifier. [in] trackerInd The target's tracker index. [in] corrRespMats The correlation-response matrices for the tracker batch. [in] dstSize The requested output image size. [in] showPeakPoint Whether to draw the localized peak. [in] showDetBboxes Whether to draw nearby detector bounding-box centers.
- Returns
- The prepared BGR correlation-response image.
Normalize to a high-enough magnitude for better visualization.
Wrap around with the circular shifting.
Draw the peak point.
Draw the detector bbox points within the search region.
Convert the center point of the detector bbox into the tracker corr resp's coordinate system.
Convert the center point of the detector bbox into the tracker corr resp's coordinate system.
Definition at line 809 of file 9.2/sources/libs/nvmultiobjecttracker/include/modules/VisualTracker/vizOutput.hpp.
References CV_FUNCS::circshift(), EMPTY, m_dcfTracker, DCFTracker::m_detectorBboxes_h, VisualTracker::m_detectorBboxes_h, DCFTracker::m_detectorBboxes_size_h, VisualTracker::m_detectorBboxes_size_h, VisualTracker::m_targetDisplacement2D_h, m_targets, m_visualTracker, normalize(), pydeepstreamdoc::tensor::TensorDoc::size, width, detectorBbox_t::x, and detectorBbox_t::y.
◆ prepareMaskFilterImg() [1/2]
|
inlineprotected |
Prepare an 8-bit BGR visualization of a target's segmentation-filter mask.
- Parameters
-
[in] streamId_ The video stream identifier. [in] trackerInd The target's tracker index. [in] maskMats The segmentation-filter masks for the tracker batch. [in] dstSize The requested output image size.
- Returns
- The prepared BGR mask image.
Scale the mask from [0.0, 1.0] into 8-bit values.
Definition at line 931 of file sources/libs/nvmultiobjecttracker/include/modules/VisualTracker/vizOutput.hpp.
References EMPTY, m_targets, pydeepstreamdoc::tensor::TensorDoc::size, and width.
Referenced by writeSrcImagePatchesWithMaskFilter().
◆ prepareMaskFilterImg() [2/2]
|
inlineprotected |
Prepare an 8-bit BGR visualization of a target's segmentation-filter mask.
- Parameters
-
[in] streamId_ The video stream identifier. [in] trackerInd The target's tracker index. [in] maskMats The segmentation-filter masks for the tracker batch. [in] dstSize The requested output image size.
- Returns
- The prepared BGR mask image.
Scale the mask from [0.0, 1.0] into 8-bit values.
Definition at line 931 of file 9.2/sources/libs/nvmultiobjecttracker/include/modules/VisualTracker/vizOutput.hpp.
References EMPTY, m_targets, pydeepstreamdoc::tensor::TensorDoc::size, and width.
◆ writeAllTrajectoriesOnEveryFrame() [1/2]
|
inline |
Draw all current trajectories on each available source frame and write the results.
- Parameters
-
[in] outputDirectoryKey The output directory selector.
Get source image frames available at Host (made available only when m_params.m_doTrajectoryAnalysis is enabled). {videoStreamID, src image frame}.
Get source image patches to Host.
Write all the recent trajectories on the source frame.
Show frame number.
Draw recent trajectories.
Draw projected human models on the camera frame.
Definition at line 405 of file 9.2/sources/libs/nvmultiobjecttracker/include/modules/VisualTracker/vizOutput.hpp.
References CLOG, drawProjectedPeerTrajectory(), drawProjectedTargetModel(), drawRecentTrajectory(), m_dcfTracker, m_targets, m_visualTracker, and FrameOutput::writeImageOutput().
◆ writeAllTrajectoriesOnEveryFrame() [2/2]
|
inline |
Draw all current trajectories on each available source frame and write the results.
- Parameters
-
[in] outputDirectoryKey The output directory selector.
Get source image frames available at Host (made available only when m_params.m_doTrajectoryAnalysis is enabled). {videoStreamID, src image frame}.
Get source image patches to Host.
Write all the recent trajectories on the source frame.
Show frame number.
Draw recent trajectories.
Draw projected human models on the camera frame.
Definition at line 405 of file sources/libs/nvmultiobjecttracker/include/modules/VisualTracker/vizOutput.hpp.
References CLOG, drawProjectedPeerTrajectory(), drawProjectedTargetModel(), drawRecentTrajectory(), m_dcfTracker, m_targets, m_visualTracker, and FrameOutput::writeImageOutput().
◆ writeBirdsEyeView() [1/2]
|
inline |
Render and write a bird's-eye view for each available stream.
- Parameters
-
[in] outputDirectoryKey The output directory selector.
{videoStreamID, src image frame}.
{videoStreamID, world map coordinates}.
{videoStreamID, world-to-frame scale}.
Both frame dimensions use the source height.
Both frame dimensions use the source height.
Define the world map size.
If the last target state is not Active, then don't draw.
Check if a point in world coordinate is within the world map size. If not, adjust world map size to include the new point.
Param to be configured.
Draw the trajectories of each stream on its bird's-eye view frame.
Show frame number.
If the last target state is not Active, then don't draw.
Make the image coordinate axis align with the world coordinate axis in terms of orientations. The origin of the image coordinate is at the top-left, while the world coordinate origin is at the bottom-right.
Make the image coordinate axis align with the world coordinate axis in terms of orientations. The origin of the image coordinate is at the top-left, while the world coordinate origin is at the bottom-right.
Draw the bbox center.
Show target label (ID & Age).
Definition at line 163 of file sources/libs/nvmultiobjecttracker/include/modules/VisualTracker/vizOutput.hpp.
References ACTIVE, NvMotDataTypes::Size::height, m_dcfTracker, VisualTracker::m_paramsRt, DCFTracker::m_paramsRt, m_targets, m_visualTracker, max(), VisualTrackerRunTimeParams::srcImageSize, DCFTrackerRunTimeParams::srcImageSize, TENTATIVE, and FrameOutput::writeImageOutput().
◆ writeBirdsEyeView() [2/2]
|
inline |
Render and write a bird's-eye view for each available stream.
- Parameters
-
[in] outputDirectoryKey The output directory selector.
{videoStreamID, src image frame}.
{videoStreamID, world map coordinates}.
{videoStreamID, world-to-frame scale}.
Both frame dimensions use the source height.
Both frame dimensions use the source height.
Define the world map size.
If the last target state is not Active, then don't draw.
Check if a point in world coordinate is within the world map size. If not, adjust world map size to include the new point.
Param to be configured.
Draw the trajectories of each stream on its bird's-eye view frame.
Show frame number.
If the last target state is not Active, then don't draw.
Make the image coordinate axis align with the world coordinate axis in terms of orientations. The origin of the image coordinate is at the top-left, while the world coordinate origin is at the bottom-right.
Make the image coordinate axis align with the world coordinate axis in terms of orientations. The origin of the image coordinate is at the top-left, while the world coordinate origin is at the bottom-right.
Draw the bbox center.
Show target label (ID & Age).
Definition at line 163 of file 9.2/sources/libs/nvmultiobjecttracker/include/modules/VisualTracker/vizOutput.hpp.
References ACTIVE, NvMotDataTypes::Size::height, m_dcfTracker, VisualTracker::m_paramsRt, DCFTracker::m_paramsRt, m_targets, m_visualTracker, max(), VisualTrackerRunTimeParams::srcImageSize, DCFTrackerRunTimeParams::srcImageSize, TENTATIVE, and FrameOutput::writeImageOutput().
◆ writeEachCompletedTrajectory() [1/2]
|
inline |
Draw and write each trajectory after its track completes.
- Parameters
-
[in] outputDirectoryKey The output directory selector.
Get source image frames available at Host (made available only when m_params.m_doTrajectoryAnalysis is enabled). {videoStreamID, src image frame}.
Get source image patches to Host.
Keep the latest copy of the source frame.
Write a complete trajectory of a target when terminated.
{targetId, Trajectory4Archive}.
Write the processed tracklet for visualization.
Definition at line 500 of file sources/libs/nvmultiobjecttracker/include/modules/VisualTracker/vizOutput.hpp.
References CLOG, drawFullTrajectory(), m_dcfTracker, m_lastFrames, m_targets, m_visualTracker, and FrameOutput::writeImageOutput().
◆ writeEachCompletedTrajectory() [2/2]
|
inline |
Draw and write each trajectory after its track completes.
- Parameters
-
[in] outputDirectoryKey The output directory selector.
Get source image frames available at Host (made available only when m_params.m_doTrajectoryAnalysis is enabled). {videoStreamID, src image frame}.
Get source image patches to Host.
Keep the latest copy of the source frame.
Write a complete trajectory of a target when terminated.
{targetId, Trajectory4Archive}.
Write the processed tracklet for visualization.
Definition at line 500 of file 9.2/sources/libs/nvmultiobjecttracker/include/modules/VisualTracker/vizOutput.hpp.
References CLOG, drawFullTrajectory(), m_dcfTracker, m_lastFrames, m_targets, m_visualTracker, and FrameOutput::writeImageOutput().
◆ writeFromWriteBuffer() [1/2]
|
inlineprotected |
Write and clear pending images after a target receives a persistent ID.
- Parameters
-
[in] target The tracked object whose pending images are written.
FileName: Target_{targetID}_Frame_{FrameNum}.
Out folder name: Stream_{StreamID}.
Definition at line 772 of file 9.2/sources/libs/nvmultiobjecttracker/include/modules/VisualTracker/vizOutput.hpp.
References ACTIVE, INACTIVE, m_writeBuffer, pydeepstreamdoc::tensor::TensorDoc::size, and FrameOutput::writeImageOutput().
◆ writeFromWriteBuffer() [2/2]
|
inlineprotected |
Write and clear pending images after a target receives a persistent ID.
- Parameters
-
[in] target The tracked object whose pending images are written.
FileName: Target_{targetID}_Frame_{FrameNum}.
Out folder name: Stream_{StreamID}.
Definition at line 772 of file sources/libs/nvmultiobjecttracker/include/modules/VisualTracker/vizOutput.hpp.
References ACTIVE, INACTIVE, m_writeBuffer, pydeepstreamdoc::tensor::TensorDoc::size, and FrameOutput::writeImageOutput().
Referenced by writeSrcImagePatchesWithCorrResp_perTarget(), and writeSrcImagePatchesWithMaskFilter_perTarget().
◆ writeImageOutput() [1/2]
|
inlineinherited |
Write an image to a keyed output directory.
- Parameters
-
[in] img Image to write. [in] imgFilename Base name of the output image file. [in] outputDirectoryKey Key used to select the output directory. [in] subFolderName Optional subdirectory below the keyed output directory.
Create the output directory if it does not exist.
Definition at line 157 of file sources/libs/nvmultiobjecttracker/include/modules/utility/FrameOutput.hpp.
References FrameOutput::compression_params, FrameOutput::isImageOutputEnabled(), FrameOutput::mOutputImageDirectory, and pydeepstreamdoc::tensor::TensorDoc::size.
Referenced by writeAllTrajectoriesOnEveryFrame(), writeBirdsEyeView(), writeEachCompletedTrajectory(), and writeFromWriteBuffer().
◆ writeImageOutput() [2/2]
|
inlineinherited |
Write an image to a keyed output directory.
- Parameters
-
[in] img Image to write. [in] imgFilename Base name of the output image file. [in] outputDirectoryKey Key used to select the output directory. [in] subFolderName Optional subdirectory below the keyed output directory.
Create the output directory if it does not exist.
Definition at line 157 of file 9.2/sources/libs/nvmultiobjecttracker/include/modules/utility/FrameOutput.hpp.
References FrameOutput::compression_params, FrameOutput::isImageOutputEnabled(), FrameOutput::mOutputImageDirectory, and pydeepstreamdoc::tensor::TensorDoc::size.
◆ writeSrcImagePatchesWithCorrResp() [1/2]
|
inline |
Write source image patches alongside their correlation-response visualizations.
- Parameters
-
[in] outputDirectoryKey The output directory selector.
Get source image patches to Host.
Definition at line 569 of file 9.2/sources/libs/nvmultiobjecttracker/include/modules/VisualTracker/vizOutput.hpp.
References pydeepstreamdoc::tensor::TensorDoc::clone, DCFTracker::m_corrResponses_d, VisualTracker::m_corrResponses_d, m_dcfTracker, VisualTracker::m_featureExtractor, VisualTracker::m_params, DCFTracker::m_params, m_srcImgWH, m_targets, m_visualTracker, VisualTrackerConfigParams::m_vizDebugStreamId, DCFTrackerConfigParams::m_vizDebugStreamId, prepareCorrelationResponseImg(), and writeSrcImagePatchesWithCorrResp_perTarget().
◆ writeSrcImagePatchesWithCorrResp() [2/2]
|
inline |
Write source image patches alongside their correlation-response visualizations.
- Parameters
-
[in] outputDirectoryKey The output directory selector.
Get source image patches to Host.
Definition at line 569 of file sources/libs/nvmultiobjecttracker/include/modules/VisualTracker/vizOutput.hpp.
References pydeepstreamdoc::tensor::TensorDoc::clone, DCFTracker::m_corrResponses_d, VisualTracker::m_corrResponses_d, m_dcfTracker, VisualTracker::m_featureExtractor, VisualTracker::m_params, DCFTracker::m_params, m_srcImgWH, m_targets, m_visualTracker, VisualTrackerConfigParams::m_vizDebugStreamId, DCFTrackerConfigParams::m_vizDebugStreamId, prepareCorrelationResponseImg(), and writeSrcImagePatchesWithCorrResp_perTarget().
◆ writeSrcImagePatchesWithCorrResp_perTarget() [1/2]
|
inlineprotected |
Buffer a source patch paired with its correlation-response image for one target.
- Parameters
-
[in] streamId_ The video stream identifier. [in] trackerInd The target's tracker index. [in] outputDirectoryKey The output directory selector. [in] srcImgPatch The source image patch. [in] corrRespMat The correlation-response visualization.
Stack the two.
Put it into a buffer first because if target state is TENTATIVE, there is no ID assigned yet.
Write into file if ID is assigned.
Definition at line 658 of file sources/libs/nvmultiobjecttracker/include/modules/VisualTracker/vizOutput.hpp.
References addToWriteBuffer(), VisualTrackerRunTimeParams::colorFormat, EMPTY, VisualTracker::m_paramsRt, m_srcImgWH, m_targets, m_visualTracker, NVBUF_COLOR_FORMAT_RGBA, and writeFromWriteBuffer().
Referenced by writeSrcImagePatchesWithCorrResp().
◆ writeSrcImagePatchesWithCorrResp_perTarget() [2/2]
|
inlineprotected |
Buffer a source patch paired with its correlation-response image for one target.
- Parameters
-
[in] streamId_ The video stream identifier. [in] trackerInd The target's tracker index. [in] outputDirectoryKey The output directory selector. [in] srcImgPatch The source image patch. [in] corrRespMat The correlation-response visualization.
Stack the two.
Put it into a buffer first because if target state is TENTATIVE, there is no ID assigned yet.
Write into file if ID is assigned.
Definition at line 658 of file 9.2/sources/libs/nvmultiobjecttracker/include/modules/VisualTracker/vizOutput.hpp.
References addToWriteBuffer(), VisualTrackerRunTimeParams::colorFormat, EMPTY, VisualTracker::m_paramsRt, m_srcImgWH, m_targets, m_visualTracker, NVBUF_COLOR_FORMAT_RGBA, and writeFromWriteBuffer().
◆ writeSrcImagePatchesWithMaskFilter() [1/2]
|
inline |
Write source image patches alongside their segmentation-filter masks.
- Parameters
-
[in] outputDirectoryKey The output directory selector.
Get source image patches to Host.
Definition at line 611 of file 9.2/sources/libs/nvmultiobjecttracker/include/modules/VisualTracker/vizOutput.hpp.
References pydeepstreamdoc::tensor::TensorDoc::clone, VisualTracker::m_featureExtractor, VisualTracker::m_maskingSegWindow4Model, VisualTracker::m_params, m_srcImgWH, m_targets, m_visualTracker, VisualTrackerConfigParams::m_vizDebugStreamId, prepareMaskFilterImg(), and writeSrcImagePatchesWithMaskFilter_perTarget().
◆ writeSrcImagePatchesWithMaskFilter() [2/2]
|
inline |
Write source image patches alongside their segmentation-filter masks.
- Parameters
-
[in] outputDirectoryKey The output directory selector.
Get source image patches to Host.
Definition at line 611 of file sources/libs/nvmultiobjecttracker/include/modules/VisualTracker/vizOutput.hpp.
References pydeepstreamdoc::tensor::TensorDoc::clone, VisualTracker::m_featureExtractor, VisualTracker::m_maskingSegWindow4Model, VisualTracker::m_params, m_srcImgWH, m_targets, m_visualTracker, VisualTrackerConfigParams::m_vizDebugStreamId, prepareMaskFilterImg(), and writeSrcImagePatchesWithMaskFilter_perTarget().
◆ writeSrcImagePatchesWithMaskFilter_perTarget() [1/2]
|
inlineprotected |
Buffer a source patch paired with its segmentation-filter mask for one target.
- Parameters
-
[in] streamId_ The video stream identifier. [in] trackerInd The target's tracker index. [in] outputDirectoryKey The output directory selector. [in] srcImgPatch The source image patch. [in] maskMat The segmentation-filter mask visualization.
Stack the two.
Put it into a buffer first because if target state is TENTATIVE, there is no ID assigned yet.
Write into file if ID is assigned.
Definition at line 704 of file 9.2/sources/libs/nvmultiobjecttracker/include/modules/VisualTracker/vizOutput.hpp.
References addToWriteBuffer(), VisualTrackerRunTimeParams::colorFormat, EMPTY, VisualTracker::m_paramsRt, m_srcImgWH, m_targets, m_visualTracker, NVBUF_COLOR_FORMAT_RGBA, and writeFromWriteBuffer().
◆ writeSrcImagePatchesWithMaskFilter_perTarget() [2/2]
|
inlineprotected |
Buffer a source patch paired with its segmentation-filter mask for one target.
- Parameters
-
[in] streamId_ The video stream identifier. [in] trackerInd The target's tracker index. [in] outputDirectoryKey The output directory selector. [in] srcImgPatch The source image patch. [in] maskMat The segmentation-filter mask visualization.
Stack the two.
Put it into a buffer first because if target state is TENTATIVE, there is no ID assigned yet.
Write into file if ID is assigned.
Definition at line 704 of file sources/libs/nvmultiobjecttracker/include/modules/VisualTracker/vizOutput.hpp.
References addToWriteBuffer(), VisualTrackerRunTimeParams::colorFormat, EMPTY, VisualTracker::m_paramsRt, m_srcImgWH, m_targets, m_visualTracker, NVBUF_COLOR_FORMAT_RGBA, and writeFromWriteBuffer().
Referenced by writeSrcImagePatchesWithMaskFilter().
◆ writeVideoOutput() [1/2]
|
inlineinherited |
Append an image to the output video.
- Parameters
-
[in] img Image to write as the next video frame.
Definition at line 142 of file 9.2/sources/libs/nvmultiobjecttracker/include/modules/utility/FrameOutput.hpp.
References FrameOutput::mIsVideoOutputEnabled, and FrameOutput::mOutputVideo.
◆ writeVideoOutput() [2/2]
|
inlineinherited |
Append an image to the output video.
- Parameters
-
[in] img Image to write as the next video frame.
Definition at line 142 of file sources/libs/nvmultiobjecttracker/include/modules/utility/FrameOutput.hpp.
References FrameOutput::mIsVideoOutputEnabled, and FrameOutput::mOutputVideo.
Field Documentation
◆ compression_params
|
protectedinherited |
OpenCV image-encoding parameters.
Definition at line 195 of file sources/libs/nvmultiobjecttracker/include/modules/utility/FrameOutput.hpp.
Referenced by FrameOutput::enableImageOutput(), and FrameOutput::writeImageOutput().
◆ m_dcfTracker
|
protected |
VPI DCF tracker that supplies visualization data.
Definition at line 94 of file sources/libs/nvmultiobjecttracker/include/modules/VisualTracker/vizOutput.hpp.
Referenced by prepareCorrelationResponseImg(), writeAllTrajectoriesOnEveryFrame(), writeBirdsEyeView(), writeEachCompletedTrajectory(), and writeSrcImagePatchesWithCorrResp().
◆ m_displayWidth
|
protected |
Display/screen width.
Definition at line 98 of file sources/libs/nvmultiobjecttracker/include/modules/VisualTracker/vizOutput.hpp.
◆ m_featImgWH
|
protected |
Visualization width and height for feature images.
Definition at line 100 of file sources/libs/nvmultiobjecttracker/include/modules/VisualTracker/vizOutput.hpp.
◆ m_lastFrameMatchedInTrajectoryArchive
|
protected |
The target ID of the latest trajectory archived.
Definition at line 102 of file sources/libs/nvmultiobjecttracker/include/modules/VisualTracker/vizOutput.hpp.
◆ m_lastFrames
|
protected |
The last source frame kept.
Definition at line 103 of file sources/libs/nvmultiobjecttracker/include/modules/VisualTracker/vizOutput.hpp.
Referenced by writeEachCompletedTrajectory().
◆ m_srcImgWH
|
protected |
Visualization width and height for source image patches.
Definition at line 99 of file sources/libs/nvmultiobjecttracker/include/modules/VisualTracker/vizOutput.hpp.
Referenced by writeSrcImagePatchesWithCorrResp(), writeSrcImagePatchesWithCorrResp_perTarget(), writeSrcImagePatchesWithMaskFilter(), and writeSrcImagePatchesWithMaskFilter_perTarget().
◆ m_targets
|
protected |
Manager that supplies tracked objects.
Definition at line 95 of file sources/libs/nvmultiobjecttracker/include/modules/VisualTracker/vizOutput.hpp.
Referenced by drawProjectedPeerTrajectory(), prepareCorrelationResponseImg(), prepareMaskFilterImg(), writeAllTrajectoriesOnEveryFrame(), writeBirdsEyeView(), writeEachCompletedTrajectory(), writeSrcImagePatchesWithCorrResp(), writeSrcImagePatchesWithCorrResp_perTarget(), writeSrcImagePatchesWithMaskFilter(), and writeSrcImagePatchesWithMaskFilter_perTarget().
◆ m_visualTracker
|
protected |
CUDA visual tracker that supplies visualization data.
Definition at line 93 of file sources/libs/nvmultiobjecttracker/include/modules/VisualTracker/vizOutput.hpp.
Referenced by prepareCorrelationResponseImg(), writeAllTrajectoriesOnEveryFrame(), writeBirdsEyeView(), writeEachCompletedTrajectory(), writeSrcImagePatchesWithCorrResp(), writeSrcImagePatchesWithCorrResp_perTarget(), writeSrcImagePatchesWithMaskFilter(), and writeSrcImagePatchesWithMaskFilter_perTarget().
◆ m_writeBuffer
|
protected |
Buffered outputs grouped by target index.
Definition at line 101 of file sources/libs/nvmultiobjecttracker/include/modules/VisualTracker/vizOutput.hpp.
Referenced by addToWriteBuffer(), and writeFromWriteBuffer().
◆ mIsImageOutputEnabled
|
protectedinherited |
Image-output enabled state for each directory key.
Definition at line 197 of file sources/libs/nvmultiobjecttracker/include/modules/utility/FrameOutput.hpp.
Referenced by FrameOutput::enableImageOutput(), and FrameOutput::isImageOutputEnabled().
◆ mIsVideoOutputEnabled
|
protectedinherited |
Indicates whether video output is enabled.
Definition at line 194 of file sources/libs/nvmultiobjecttracker/include/modules/utility/FrameOutput.hpp.
Referenced by FrameOutput::enableVideoOutput(), FrameOutput::FrameOutput(), FrameOutput::isVideoOutputEnabled(), and FrameOutput::writeVideoOutput().
◆ mOutputImageDirectory
|
protectedinherited |
Image output directories keyed by caller-defined values.
Definition at line 196 of file sources/libs/nvmultiobjecttracker/include/modules/utility/FrameOutput.hpp.
Referenced by FrameOutput::enableImageOutput(), and FrameOutput::writeImageOutput().
◆ mOutputVideo
|
protectedinherited |
Video writer used when video output is enabled.
Definition at line 193 of file sources/libs/nvmultiobjecttracker/include/modules/utility/FrameOutput.hpp.
Referenced by FrameOutput::enableVideoOutput(), FrameOutput::FrameOutput(), FrameOutput::writeVideoOutput(), and FrameOutput::~FrameOutput().
The documentation for this class was generated from the following file: