Detailed Description
Project and recover target geometry using camera and object models.
Definition at line 184 of file sources/libs/nvmultiobjecttracker/include/modules/ObjectModelProjector/ObjectModelProjector.hpp.
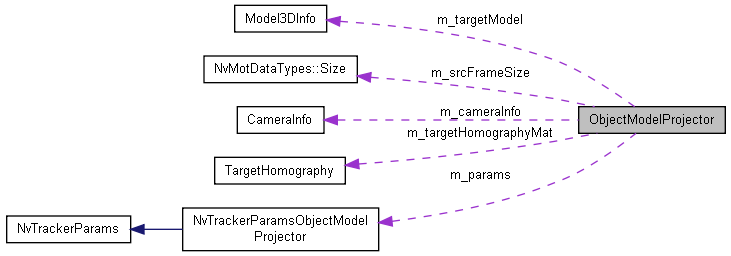
Public Member Functions | |
| ObjectModelProjector () | |
| Construct an uninitialized object-model projector. More... | |
| ObjectModelProjector (const std::string &configFilePath) | |
| Construct an object-model projector from configuration. More... | |
| ObjectModelProjector (const std::string &configFilePath, const NvMotDataTypes::Size imgSize, const NvMOTStreamId streamId) | |
| Construct and initialize a projector for a source stream. More... | |
| ObjectModelProjector (const std::string &configFilePath, const NvMotDataTypes::Size imgSize, const NvMOTStreamId streamId, const std::string &sensorName) | |
| Construct and initialize a projector for a named source sensor. More... | |
| virtual | ~ObjectModelProjector () |
| Destroy the object-model projector. More... | |
| void | queryParams (NvMOTQuery ¶msQuery) |
| Populate tracker query capabilities from projector configuration. More... | |
| bool | isInitialized () |
| Return whether the projector has been initialized. More... | |
| const std::string & | getSensorName () const |
| Return the source sensor name. More... | |
| RecoveredObjModel | getRecoveredObjectModelFromBbox (const NvMOTObjToTrack *detObj, const NvMOTFrameNum frameNum, const int targetInd, const bool isInitEstimation) |
| Recover an object model from a detector bounding box. More... | |
| RecoveredObjModel | getRecoveredObjectModelFromProj3DBbox (const NvMOTObjToTrack *detObj, const NvMOTFrameNum frameNum) |
| Recover an object model from externally projected three-dimensional bounding-box data. More... | |
| const NvMotDataTypes::Rect2f | getBboxOfProjectedCylinderFromImgFeet (const Eigen::Vector2d pt_img_head, const NvMOTClassId classId, const int targetInd) |
| Project a cylinder bounding box from an image-space feet point. More... | |
| const NvMotDataTypes::Rect2f | getBboxOfProjectedCylinderFromImgWaist (const Eigen::Vector2d pt_img_waist, const NvMOTClassId classId, const int targetInd) |
| Project a cylinder bounding box from an image-space waist point. More... | |
| const NvMotDataTypes::Rect2f | getBboxOfProjectedCylinderFromImgHead (const Eigen::Vector2d pt_img_head, const NvMOTClassId classId, const int targetInd) |
| Project a cylinder bounding box from an image-space head point. More... | |
| RecoveredObjModel | getRecoveredObjectModelWithAdaptiveHeight (const Eigen::Vector2d pt_img_head, const Eigen::Vector2d pt_img_waist, const Eigen::Vector2d pt_img_foot, const NvMotDataTypes::Rect2f &bbox, const TrackerIndex &targetInd, const NvMOTClassId classId, float conf_head, float conf_waist, float conf_foot) |
| Get recovered 3D cylinder model with dynamic height from pose keypoints. More... | |
| Eigen::Vector2d | computeHeightAndWorldFeetFromHeadAndWaist (const Eigen::Vector2d pt_img_head, const Eigen::Vector2d pt_img_waist, const TrackerIndex &targetInd, const NvMOTClassId classId) |
| Estimate target height and world feet position from image head and waist points. More... | |
| Eigen::Vector2d | computeHeightAndWorldFeetFromHeadAndFoot (const Eigen::Vector2d pt_img_head, const Eigen::Vector2d pt_img_foot, const TrackerIndex &targetInd, const NvMOTClassId classId) |
| Estimate target height and world feet position from image head and foot points. More... | |
| const NvMotDataTypes::Rect2f | getBboxOfProjectedCylinderFromWorldFeet (const Eigen::Vector2d pt_world_feet, const NvMOTClassId classId, const int targetInd) |
| Project a cylinder bounding box from world-space feet coordinates. More... | |
| const std::vector< Eigen::Vector2d > | getProjectedWorldGroundPts (const std::vector< Eigen::Vector2d > &pt_world_feet_list) |
| Project world-ground points into image coordinates. More... | |
| const Eigen::Vector2d | getCamHeadPtFromCamWaistPt (const Eigen::Vector2d imgWaistPt, const NvMOTClassId classId, const int targetInd) |
| Map an image waist point to the corresponding image head point. More... | |
| const Eigen::Vector2d | getCamWaistPtFromCamHeadPt (const Eigen::Vector2d imgHeadPt, const NvMOTClassId classId, const int targetInd) |
| Map an image head point to the corresponding image waist point. More... | |
| const Eigen::Vector2d | getCamWaistPtFromCamFeetPt (const Eigen::Vector2d imgWaistPt, const NvMOTClassId classId, const int targetInd) |
| Map an image feet point to the corresponding image waist point. More... | |
| const Eigen::Vector2d | getCamFeetPtFromCamWaistPt (const Eigen::Vector2d imgWaistPt, const NvMOTClassId classId, const int targetInd) |
| Map an image waist point to the corresponding image feet point. More... | |
| const Eigen::Vector2d | getWorldFeetPtOnGroundFromCamWaistPt (const Eigen::Vector2d imgWaistPt, const NvMOTClassId classId, const int targetInd) |
| Recover world-ground feet coordinates from an image waist point. More... | |
| const Eigen::Vector2d | getWorldFeetPtOnGroundFromCamFeetPt (const Eigen::Vector2d imgFeetPt, const NvMOTClassId classId, const int targetInd) |
| Recover world-ground feet coordinates from an image feet point. More... | |
| const NvDsObj3DBbox | getWorld3DBboxFromWorldFeet (const Eigen::Vector2d pt_world_feet, const NvMOTClassId classId, const int targetInd) |
| Build a world-space three-dimensional bounding box from feet coordinates. More... | |
| std::vector< Eigen::Vector2d > | calculateProjCornersOf3DBboxFromWorldFeet (const Eigen::Vector2d pt_world_feet, const NvMOTClassId classId, const int targetInd) |
| Project the eight corners of a world-space three-dimensional bounding box. More... | |
| const Eigen::Vector2d | projectWorldPt2ImgPt (const Eigen::Vector3d pt_world) |
| Project a world-space point into image coordinates. More... | |
| bool | isTargetVisibleInImage (const Eigen::Vector2d &pt_world_feet, float targetHeight) |
| Check if any point of a vertical target (from feet to head) projects into the camera FOV. More... | |
| std::vector< Eigen::Vector2d > | calculateProjectedCircleFromWorldFeet (const Eigen::Vector2d pt_world_feet, const float radius) |
| Project a horizontal circle centered at world-space feet coordinates. More... | |
| const bool | getOutputFootLocation () |
| Return whether foot-location output is enabled. More... | |
| const bool | getOutputConvexHull () |
| Return whether convex-hull output is enabled. More... | |
| float | getMinPoseConfidence () const |
| Return the minimum pose-keypoint confidence. More... | |
| Eigen::Matrix2d | computeGroundCovariance (const Eigen::Vector2d &pixel_pt, float pixel_sigma) |
| Compute ground plane position covariance from pixel uncertainty using Jacobian. More... | |
| float | getTargetHeight () const |
| Return the current target-model height. More... | |
| float | getHeightConfidence () const |
| Return the current height-estimation confidence. More... | |
| void | setTargetHeight (float height, float confidence, bool force=false) |
| Update target-model height when confidence permits. More... | |
| void | setTargetModelForClass (NvMOTClassId classId) |
| Select the target model for a class ID. More... | |
| NvMOTClassId | getTargetClassId () const |
| Return the current target-model class ID. More... | |
Protected Member Functions | |
| const Eigen::MatrixXd | convertYamlVec2EigenMatrixXd (YAML::Node yamlVec, const int rows, const int cols) |
| Convert a nested YAML sequence to an Eigen matrix. More... | |
| bool | importCameraModelInfo (const std::string filename) |
| Import camera-model calibration from a YAML file. More... | |
| bool | importExternalProj3DBboxInfo (const std::string filename) |
| Import externally projected three-dimensional bounding boxes. More... | |
| const Model3DInfo & | getDefaultModelByClass (const NvMOTClassId classId) |
| Return the default three-dimensional model for a class. More... | |
| const TargetHomography & | getDefaultHomographyMatByClass (const NvMOTClassId classId) |
| Return the default homographies for a class. More... | |
| void | deriveDataFromCameraProjMatrix (TargetHomography &homographyMat, const Model3DInfo &humanModel) |
| Derive target-plane homographies from the camera projection matrix. More... | |
| std::vector< Eigen::Vector2d > | calculateProjectedCylinderFromImgWaist (const Eigen::Vector2d pt_img_waist, const NvMOTClassId classId, const int targetInd) |
| Project a cylinder from an image-space waist point. More... | |
| std::vector< Eigen::Vector2d > | calculateProjectedCylinderFromImgHead (const Eigen::Vector2d pt_img_head, const NvMOTClassId classId, const int targetInd) |
| Project a cylinder from an image-space head point. More... | |
| std::vector< Eigen::Vector2d > | calculateProjectedCylinderFromImgFeet (const Eigen::Vector2d pt_img_feet, const NvMOTClassId classId, const int targetInd) |
| Project a cylinder from an image-space feet point. More... | |
| std::vector< Eigen::Vector2d > | calculateProjectedCylinderFromWorldFeet (const Eigen::Vector2d pt_world_feet, const NvMOTClassId classId, const int targetInd) |
| Project a cylinder from world-space feet coordinates. More... | |
| bool | isTargetModelValid (TrackerIndex targetInd, NvMOTClassId classId) |
| Return whether the current target model is valid for a target. More... | |
Protected Attributes | |
| bool | m_isInit |
| Indicates whether the projector has been initialized. More... | |
| uint | m_streamInd |
| Index of the corresponding source stream. More... | |
| std::string | m_sensorName |
| Sensor name of the corresponding source stream. More... | |
| const std::string | m_configFilePath |
| Path of the module config file. More... | |
| std::string | m_resolvedCameraModelFilepath |
| Resolved camera model filepath for this stream. More... | |
| NvTrackerParamsObjectModelProjector | m_params |
| Config params for target management. More... | |
| NvMotDataTypes::Size | m_srcFrameSize |
| Source video frame size where the bbox info is based on. More... | |
| CameraInfo | m_cameraInfo |
| Set camera parameters. More... | |
| std::vector< std::vector< Proj3DBboxInfo > > | m_externalProj3DBboxInfo |
| Store projected 3D bounding box info for all frames in the stream. More... | |
| Model3DInfo | m_targetModel |
| Each target's object model can be different in size. More... | |
| NvMOTClassId | m_targetClassId |
| Projector's current target model class ID. More... | |
| std::map< NvMOTClassId, Model3DInfo > | m_defaultModelByClass |
| Each class's object model. More... | |
| float | m_groundPlaneHeight |
| Specifies the world-space ground-plane height. More... | |
| CameraMatrix | m_ProjMat_World2Cam |
| Stores the world-to-camera projection matrix. More... | |
| IntrinsicMatrix | m_K |
| Intrinsic matrix. More... | |
| IntrinsicMatrix | m_K_inv |
| Inverse of intrinsic matrix. More... | |
| RotationMatrix | m_R |
| Rotation matrix (world to camera). More... | |
| RotationMatrix | m_R_T |
| Transpose of rotation matrix. More... | |
| TranslationMatrix | m_t |
| Translation vector. More... | |
| Eigen::Vector2d | m_pix2cam_offset |
| Shifts corner-origin pixels to the optical center for projectionMatrix_3x4. More... | |
| HomographyMatrix | m_H_ground |
| Ground-plane homography, independent of target height. More... | |
| HomographyMatrix | m_H_ground_inv |
| Inverse of ground plane homography. More... | |
| Eigen::Vector3d | m_r3 |
| Third row of R^T (for ground plane intersection). More... | |
| Eigen::Vector3d | m_P_z_col |
| P[:,2] - projection matrix Z column (height update direction). More... | |
| Eigen::Vector3d | m_H_inv_Pz |
| H_ground_inv * P_z_col (precomputed for Sherman-Morrison). More... | |
| TranslationMatrix | m_camLocation_World |
| Camera position in world coordinate system. More... | |
| TargetHomography | m_targetHomographyMat |
| Homography matrices for head, waist, and feet planes composed from the projection matrix. More... | |
| std::map< NvMOTClassId, TargetHomography > | m_defaultHomographyMatByClass |
| Stores default target homographies by class. More... | |
Constructor & Destructor Documentation
◆ ObjectModelProjector() [1/8]
| ObjectModelProjector::ObjectModelProjector | ( | ) |
Construct an uninitialized object-model projector.
◆ ObjectModelProjector() [2/8]
| ObjectModelProjector::ObjectModelProjector | ( | const std::string & | configFilePath | ) |
Construct an object-model projector from configuration.
- Parameters
-
[in] configFilePath Path to the configuration file.
◆ ObjectModelProjector() [3/8]
| ObjectModelProjector::ObjectModelProjector | ( | const std::string & | configFilePath, |
| const NvMotDataTypes::Size | imgSize, | ||
| const NvMOTStreamId | streamId | ||
| ) |
Construct and initialize a projector for a source stream.
- Parameters
-
[in] configFilePath Path to the configuration file. [in] imgSize Source image size. [in] streamId Source stream identifier.
◆ ObjectModelProjector() [4/8]
| ObjectModelProjector::ObjectModelProjector | ( | const std::string & | configFilePath, |
| const NvMotDataTypes::Size | imgSize, | ||
| const NvMOTStreamId | streamId, | ||
| const std::string & | sensorName | ||
| ) |
Construct and initialize a projector for a named source sensor.
- Parameters
-
[in] configFilePath Path to the configuration file. [in] imgSize Source image size. [in] streamId Source stream identifier. [in] sensorName Source sensor name.
◆ ~ObjectModelProjector() [1/2]
|
virtual |
Destroy the object-model projector.
◆ ObjectModelProjector() [5/8]
| ObjectModelProjector::ObjectModelProjector | ( | ) |
Construct an uninitialized object-model projector.
◆ ObjectModelProjector() [6/8]
| ObjectModelProjector::ObjectModelProjector | ( | const std::string & | configFilePath | ) |
Construct an object-model projector from configuration.
- Parameters
-
[in] configFilePath Path to the configuration file.
◆ ObjectModelProjector() [7/8]
| ObjectModelProjector::ObjectModelProjector | ( | const std::string & | configFilePath, |
| const NvMotDataTypes::Size | imgSize, | ||
| const NvMOTStreamId | streamId | ||
| ) |
Construct and initialize a projector for a source stream.
- Parameters
-
[in] configFilePath Path to the configuration file. [in] imgSize Source image size. [in] streamId Source stream identifier.
◆ ObjectModelProjector() [8/8]
| ObjectModelProjector::ObjectModelProjector | ( | const std::string & | configFilePath, |
| const NvMotDataTypes::Size | imgSize, | ||
| const NvMOTStreamId | streamId, | ||
| const std::string & | sensorName | ||
| ) |
Construct and initialize a projector for a named source sensor.
- Parameters
-
[in] configFilePath Path to the configuration file. [in] imgSize Source image size. [in] streamId Source stream identifier. [in] sensorName Source sensor name.
◆ ~ObjectModelProjector() [2/2]
|
virtual |
Destroy the object-model projector.
Member Function Documentation
◆ calculateProjCornersOf3DBboxFromWorldFeet() [1/2]
| std::vector<Eigen::Vector2d> ObjectModelProjector::calculateProjCornersOf3DBboxFromWorldFeet | ( | const Eigen::Vector2d | pt_world_feet, |
| const NvMOTClassId | classId, | ||
| const int | targetInd | ||
| ) |
Project the eight corners of a world-space three-dimensional bounding box.
- Parameters
-
[in] pt_world_feet World-space feet position. [in] classId Target class ID. [in] targetInd Target index.
◆ calculateProjCornersOf3DBboxFromWorldFeet() [2/2]
| std::vector<Eigen::Vector2d> ObjectModelProjector::calculateProjCornersOf3DBboxFromWorldFeet | ( | const Eigen::Vector2d | pt_world_feet, |
| const NvMOTClassId | classId, | ||
| const int | targetInd | ||
| ) |
Project the eight corners of a world-space three-dimensional bounding box.
- Parameters
-
[in] pt_world_feet World-space feet position. [in] classId Target class ID. [in] targetInd Target index.
◆ calculateProjectedCircleFromWorldFeet() [1/2]
| std::vector<Eigen::Vector2d> ObjectModelProjector::calculateProjectedCircleFromWorldFeet | ( | const Eigen::Vector2d | pt_world_feet, |
| const float | radius | ||
| ) |
Project a horizontal circle centered at world-space feet coordinates.
- Parameters
-
[in] pt_world_feet World-space feet position. [in] radius Circle radius.
◆ calculateProjectedCircleFromWorldFeet() [2/2]
| std::vector<Eigen::Vector2d> ObjectModelProjector::calculateProjectedCircleFromWorldFeet | ( | const Eigen::Vector2d | pt_world_feet, |
| const float | radius | ||
| ) |
Project a horizontal circle centered at world-space feet coordinates.
- Parameters
-
[in] pt_world_feet World-space feet position. [in] radius Circle radius.
◆ calculateProjectedCylinderFromImgFeet() [1/2]
|
protected |
Project a cylinder from an image-space feet point.
- Parameters
-
[in] pt_img_feet Image-space feet point. [in] classId Target class ID. [in] targetInd Target index.
◆ calculateProjectedCylinderFromImgFeet() [2/2]
|
protected |
Project a cylinder from an image-space feet point.
- Parameters
-
[in] pt_img_feet Image-space feet point. [in] classId Target class ID. [in] targetInd Target index.
◆ calculateProjectedCylinderFromImgHead() [1/2]
|
protected |
Project a cylinder from an image-space head point.
- Parameters
-
[in] pt_img_head Image-space head point. [in] classId Target class ID. [in] targetInd Target index.
◆ calculateProjectedCylinderFromImgHead() [2/2]
|
protected |
Project a cylinder from an image-space head point.
- Parameters
-
[in] pt_img_head Image-space head point. [in] classId Target class ID. [in] targetInd Target index.
◆ calculateProjectedCylinderFromImgWaist() [1/2]
|
protected |
Project a cylinder from an image-space waist point.
- Parameters
-
[in] pt_img_waist Image-space waist point. [in] classId Target class ID. [in] targetInd Target index.
◆ calculateProjectedCylinderFromImgWaist() [2/2]
|
protected |
Project a cylinder from an image-space waist point.
- Parameters
-
[in] pt_img_waist Image-space waist point. [in] classId Target class ID. [in] targetInd Target index.
◆ calculateProjectedCylinderFromWorldFeet() [1/2]
|
protected |
Project a cylinder from world-space feet coordinates.
- Parameters
-
[in] pt_world_feet World-space feet position. [in] classId Target class ID. [in] targetInd Target index.
◆ calculateProjectedCylinderFromWorldFeet() [2/2]
|
protected |
Project a cylinder from world-space feet coordinates.
- Parameters
-
[in] pt_world_feet World-space feet position. [in] classId Target class ID. [in] targetInd Target index.
◆ computeGroundCovariance() [1/2]
| Eigen::Matrix2d ObjectModelProjector::computeGroundCovariance | ( | const Eigen::Vector2d & | pixel_pt, |
| float | pixel_sigma | ||
| ) |
Compute ground plane position covariance from pixel uncertainty using Jacobian.
- Parameters
-
[in] pixel_pt The pixel coordinates (u, v). [in] pixel_sigma Standard deviation of pixel noise.
◆ computeGroundCovariance() [2/2]
| Eigen::Matrix2d ObjectModelProjector::computeGroundCovariance | ( | const Eigen::Vector2d & | pixel_pt, |
| float | pixel_sigma | ||
| ) |
Compute ground plane position covariance from pixel uncertainty using Jacobian.
- Parameters
-
[in] pixel_pt The pixel coordinates (u, v). [in] pixel_sigma Standard deviation of pixel noise.
◆ computeHeightAndWorldFeetFromHeadAndFoot() [1/2]
| Eigen::Vector2d ObjectModelProjector::computeHeightAndWorldFeetFromHeadAndFoot | ( | const Eigen::Vector2d | pt_img_head, |
| const Eigen::Vector2d | pt_img_foot, | ||
| const TrackerIndex & | targetInd, | ||
| const NvMOTClassId | classId | ||
| ) |
Estimate target height and world feet position from image head and foot points.
- Parameters
-
[in] pt_img_head Image-space head point. [in] pt_img_foot Image-space foot point. [in] targetInd Target index. [in] classId Target class ID.
◆ computeHeightAndWorldFeetFromHeadAndFoot() [2/2]
| Eigen::Vector2d ObjectModelProjector::computeHeightAndWorldFeetFromHeadAndFoot | ( | const Eigen::Vector2d | pt_img_head, |
| const Eigen::Vector2d | pt_img_foot, | ||
| const TrackerIndex & | targetInd, | ||
| const NvMOTClassId | classId | ||
| ) |
Estimate target height and world feet position from image head and foot points.
- Parameters
-
[in] pt_img_head Image-space head point. [in] pt_img_foot Image-space foot point. [in] targetInd Target index. [in] classId Target class ID.
◆ computeHeightAndWorldFeetFromHeadAndWaist() [1/2]
| Eigen::Vector2d ObjectModelProjector::computeHeightAndWorldFeetFromHeadAndWaist | ( | const Eigen::Vector2d | pt_img_head, |
| const Eigen::Vector2d | pt_img_waist, | ||
| const TrackerIndex & | targetInd, | ||
| const NvMOTClassId | classId | ||
| ) |
Estimate target height and world feet position from image head and waist points.
- Parameters
-
[in] pt_img_head Image-space head point. [in] pt_img_waist Image-space waist point. [in] targetInd Target index. [in] classId Target class ID.
◆ computeHeightAndWorldFeetFromHeadAndWaist() [2/2]
| Eigen::Vector2d ObjectModelProjector::computeHeightAndWorldFeetFromHeadAndWaist | ( | const Eigen::Vector2d | pt_img_head, |
| const Eigen::Vector2d | pt_img_waist, | ||
| const TrackerIndex & | targetInd, | ||
| const NvMOTClassId | classId | ||
| ) |
Estimate target height and world feet position from image head and waist points.
- Parameters
-
[in] pt_img_head Image-space head point. [in] pt_img_waist Image-space waist point. [in] targetInd Target index. [in] classId Target class ID.
◆ convertYamlVec2EigenMatrixXd() [1/2]
|
protected |
Convert a nested YAML sequence to an Eigen matrix.
- Parameters
-
[in] yamlVec YAML matrix values. [in] rows Matrix row count. [in] cols Matrix column count.
◆ convertYamlVec2EigenMatrixXd() [2/2]
|
protected |
Convert a nested YAML sequence to an Eigen matrix.
- Parameters
-
[in] yamlVec YAML matrix values. [in] rows Matrix row count. [in] cols Matrix column count.
◆ deriveDataFromCameraProjMatrix() [1/2]
|
protected |
Derive target-plane homographies from the camera projection matrix.
- Parameters
-
[out] homographyMat Target homographies to populate. [in] humanModel Target model dimensions.
Referenced by setTargetHeight().
◆ deriveDataFromCameraProjMatrix() [2/2]
|
protected |
Derive target-plane homographies from the camera projection matrix.
- Parameters
-
[out] homographyMat Target homographies to populate. [in] humanModel Target model dimensions.
◆ getBboxOfProjectedCylinderFromImgFeet() [1/2]
| const NvMotDataTypes::Rect2f ObjectModelProjector::getBboxOfProjectedCylinderFromImgFeet | ( | const Eigen::Vector2d | pt_img_head, |
| const NvMOTClassId | classId, | ||
| const int | targetInd | ||
| ) |
Project a cylinder bounding box from an image-space feet point.
- Parameters
-
[in] pt_img_head Image-space feet point. [in] classId Target class ID. [in] targetInd Target index.
◆ getBboxOfProjectedCylinderFromImgFeet() [2/2]
| const NvMotDataTypes::Rect2f ObjectModelProjector::getBboxOfProjectedCylinderFromImgFeet | ( | const Eigen::Vector2d | pt_img_head, |
| const NvMOTClassId | classId, | ||
| const int | targetInd | ||
| ) |
Project a cylinder bounding box from an image-space feet point.
- Parameters
-
[in] pt_img_head Image-space feet point. [in] classId Target class ID. [in] targetInd Target index.
◆ getBboxOfProjectedCylinderFromImgHead() [1/2]
| const NvMotDataTypes::Rect2f ObjectModelProjector::getBboxOfProjectedCylinderFromImgHead | ( | const Eigen::Vector2d | pt_img_head, |
| const NvMOTClassId | classId, | ||
| const int | targetInd | ||
| ) |
Project a cylinder bounding box from an image-space head point.
- Parameters
-
[in] pt_img_head Image-space head point. [in] classId Target class ID. [in] targetInd Target index.
◆ getBboxOfProjectedCylinderFromImgHead() [2/2]
| const NvMotDataTypes::Rect2f ObjectModelProjector::getBboxOfProjectedCylinderFromImgHead | ( | const Eigen::Vector2d | pt_img_head, |
| const NvMOTClassId | classId, | ||
| const int | targetInd | ||
| ) |
Project a cylinder bounding box from an image-space head point.
- Parameters
-
[in] pt_img_head Image-space head point. [in] classId Target class ID. [in] targetInd Target index.
◆ getBboxOfProjectedCylinderFromImgWaist() [1/2]
| const NvMotDataTypes::Rect2f ObjectModelProjector::getBboxOfProjectedCylinderFromImgWaist | ( | const Eigen::Vector2d | pt_img_waist, |
| const NvMOTClassId | classId, | ||
| const int | targetInd | ||
| ) |
Project a cylinder bounding box from an image-space waist point.
- Parameters
-
[in] pt_img_waist Image-space waist point. [in] classId Target class ID. [in] targetInd Target index.
◆ getBboxOfProjectedCylinderFromImgWaist() [2/2]
| const NvMotDataTypes::Rect2f ObjectModelProjector::getBboxOfProjectedCylinderFromImgWaist | ( | const Eigen::Vector2d | pt_img_waist, |
| const NvMOTClassId | classId, | ||
| const int | targetInd | ||
| ) |
Project a cylinder bounding box from an image-space waist point.
- Parameters
-
[in] pt_img_waist Image-space waist point. [in] classId Target class ID. [in] targetInd Target index.
◆ getBboxOfProjectedCylinderFromWorldFeet() [1/2]
| const NvMotDataTypes::Rect2f ObjectModelProjector::getBboxOfProjectedCylinderFromWorldFeet | ( | const Eigen::Vector2d | pt_world_feet, |
| const NvMOTClassId | classId, | ||
| const int | targetInd | ||
| ) |
Project a cylinder bounding box from world-space feet coordinates.
- Parameters
-
[in] pt_world_feet World-space feet position. [in] classId Target class ID. [in] targetInd Target index.
◆ getBboxOfProjectedCylinderFromWorldFeet() [2/2]
| const NvMotDataTypes::Rect2f ObjectModelProjector::getBboxOfProjectedCylinderFromWorldFeet | ( | const Eigen::Vector2d | pt_world_feet, |
| const NvMOTClassId | classId, | ||
| const int | targetInd | ||
| ) |
Project a cylinder bounding box from world-space feet coordinates.
- Parameters
-
[in] pt_world_feet World-space feet position. [in] classId Target class ID. [in] targetInd Target index.
◆ getCamFeetPtFromCamWaistPt() [1/2]
| const Eigen::Vector2d ObjectModelProjector::getCamFeetPtFromCamWaistPt | ( | const Eigen::Vector2d | imgWaistPt, |
| const NvMOTClassId | classId, | ||
| const int | targetInd | ||
| ) |
Map an image waist point to the corresponding image feet point.
- Parameters
-
[in] imgWaistPt Image-space waist point. [in] classId Target class ID. [in] targetInd Target index.
◆ getCamFeetPtFromCamWaistPt() [2/2]
| const Eigen::Vector2d ObjectModelProjector::getCamFeetPtFromCamWaistPt | ( | const Eigen::Vector2d | imgWaistPt, |
| const NvMOTClassId | classId, | ||
| const int | targetInd | ||
| ) |
Map an image waist point to the corresponding image feet point.
- Parameters
-
[in] imgWaistPt Image-space waist point. [in] classId Target class ID. [in] targetInd Target index.
◆ getCamHeadPtFromCamWaistPt() [1/2]
| const Eigen::Vector2d ObjectModelProjector::getCamHeadPtFromCamWaistPt | ( | const Eigen::Vector2d | imgWaistPt, |
| const NvMOTClassId | classId, | ||
| const int | targetInd | ||
| ) |
Map an image waist point to the corresponding image head point.
- Parameters
-
[in] imgWaistPt Image-space waist point. [in] classId Target class ID. [in] targetInd Target index.
◆ getCamHeadPtFromCamWaistPt() [2/2]
| const Eigen::Vector2d ObjectModelProjector::getCamHeadPtFromCamWaistPt | ( | const Eigen::Vector2d | imgWaistPt, |
| const NvMOTClassId | classId, | ||
| const int | targetInd | ||
| ) |
Map an image waist point to the corresponding image head point.
- Parameters
-
[in] imgWaistPt Image-space waist point. [in] classId Target class ID. [in] targetInd Target index.
◆ getCamWaistPtFromCamFeetPt() [1/2]
| const Eigen::Vector2d ObjectModelProjector::getCamWaistPtFromCamFeetPt | ( | const Eigen::Vector2d | imgWaistPt, |
| const NvMOTClassId | classId, | ||
| const int | targetInd | ||
| ) |
Map an image feet point to the corresponding image waist point.
- Parameters
-
[in] imgWaistPt Image-space feet point. [in] classId Target class ID. [in] targetInd Target index.
◆ getCamWaistPtFromCamFeetPt() [2/2]
| const Eigen::Vector2d ObjectModelProjector::getCamWaistPtFromCamFeetPt | ( | const Eigen::Vector2d | imgWaistPt, |
| const NvMOTClassId | classId, | ||
| const int | targetInd | ||
| ) |
Map an image feet point to the corresponding image waist point.
- Parameters
-
[in] imgWaistPt Image-space feet point. [in] classId Target class ID. [in] targetInd Target index.
◆ getCamWaistPtFromCamHeadPt() [1/2]
| const Eigen::Vector2d ObjectModelProjector::getCamWaistPtFromCamHeadPt | ( | const Eigen::Vector2d | imgHeadPt, |
| const NvMOTClassId | classId, | ||
| const int | targetInd | ||
| ) |
Map an image head point to the corresponding image waist point.
- Parameters
-
[in] imgHeadPt Image-space head point. [in] classId Target class ID. [in] targetInd Target index.
◆ getCamWaistPtFromCamHeadPt() [2/2]
| const Eigen::Vector2d ObjectModelProjector::getCamWaistPtFromCamHeadPt | ( | const Eigen::Vector2d | imgHeadPt, |
| const NvMOTClassId | classId, | ||
| const int | targetInd | ||
| ) |
Map an image head point to the corresponding image waist point.
- Parameters
-
[in] imgHeadPt Image-space head point. [in] classId Target class ID. [in] targetInd Target index.
◆ getDefaultHomographyMatByClass() [1/2]
|
inlineprotected |
Return the default homographies for a class.
- Parameters
-
[in] classId Target class ID.
Fallback to first available homography matrix if no homography matrix is defined for the given class ID and print a warning.
Definition at line 593 of file sources/libs/nvmultiobjecttracker/include/modules/ObjectModelProjector/ObjectModelProjector.hpp.
References NvTrackerParamsObjectModelProjector::m_debugVerboseLevel, m_defaultHomographyMatByClass, and m_params.
Referenced by setTargetModelForClass().
◆ getDefaultHomographyMatByClass() [2/2]
|
inlineprotected |
Return the default homographies for a class.
- Parameters
-
[in] classId Target class ID.
Fallback to first available homography matrix if no homography matrix is defined for the given class ID and print a warning.
Definition at line 593 of file 9.2/sources/libs/nvmultiobjecttracker/include/modules/ObjectModelProjector/ObjectModelProjector.hpp.
References NvTrackerParamsObjectModelProjector::m_debugVerboseLevel.
◆ getDefaultModelByClass() [1/2]
|
inlineprotected |
Return the default three-dimensional model for a class.
- Parameters
-
[in] classId Target class ID.
Fallback to first available model if no model is defined for the given class ID and print a warning.
Definition at line 571 of file sources/libs/nvmultiobjecttracker/include/modules/ObjectModelProjector/ObjectModelProjector.hpp.
References NvTrackerParamsObjectModelProjector::m_debugVerboseLevel, m_defaultModelByClass, and m_params.
Referenced by setTargetModelForClass().
◆ getDefaultModelByClass() [2/2]
|
inlineprotected |
Return the default three-dimensional model for a class.
- Parameters
-
[in] classId Target class ID.
Fallback to first available model if no model is defined for the given class ID and print a warning.
Definition at line 571 of file 9.2/sources/libs/nvmultiobjecttracker/include/modules/ObjectModelProjector/ObjectModelProjector.hpp.
References NvTrackerParamsObjectModelProjector::m_debugVerboseLevel.
◆ getHeightConfidence() [1/2]
|
inline |
Return the current height-estimation confidence.
Definition at line 467 of file 9.2/sources/libs/nvmultiobjecttracker/include/modules/ObjectModelProjector/ObjectModelProjector.hpp.
◆ getHeightConfidence() [2/2]
|
inline |
Return the current height-estimation confidence.
Definition at line 467 of file sources/libs/nvmultiobjecttracker/include/modules/ObjectModelProjector/ObjectModelProjector.hpp.
References Model3DInfo::heightConfidence, and m_targetModel.
◆ getMinPoseConfidence() [1/2]
|
inline |
Return the minimum pose-keypoint confidence.
Definition at line 454 of file 9.2/sources/libs/nvmultiobjecttracker/include/modules/ObjectModelProjector/ObjectModelProjector.hpp.
◆ getMinPoseConfidence() [2/2]
|
inline |
Return the minimum pose-keypoint confidence.
Definition at line 454 of file sources/libs/nvmultiobjecttracker/include/modules/ObjectModelProjector/ObjectModelProjector.hpp.
References NvTrackerParamsObjectModelProjector::m_minPoseConfidence, and m_params.
◆ getOutputConvexHull() [1/2]
|
inline |
Return whether convex-hull output is enabled.
Definition at line 451 of file 9.2/sources/libs/nvmultiobjecttracker/include/modules/ObjectModelProjector/ObjectModelProjector.hpp.
◆ getOutputConvexHull() [2/2]
|
inline |
Return whether convex-hull output is enabled.
Definition at line 451 of file sources/libs/nvmultiobjecttracker/include/modules/ObjectModelProjector/ObjectModelProjector.hpp.
References NvTrackerParamsObjectModelProjector::m_outputConvexHull, and m_params.
◆ getOutputFootLocation() [1/2]
|
inline |
Return whether foot-location output is enabled.
Definition at line 448 of file 9.2/sources/libs/nvmultiobjecttracker/include/modules/ObjectModelProjector/ObjectModelProjector.hpp.
◆ getOutputFootLocation() [2/2]
|
inline |
Return whether foot-location output is enabled.
Definition at line 448 of file sources/libs/nvmultiobjecttracker/include/modules/ObjectModelProjector/ObjectModelProjector.hpp.
References NvTrackerParamsObjectModelProjector::m_outputFootLocation, and m_params.
◆ getProjectedWorldGroundPts() [1/2]
| const std::vector<Eigen::Vector2d> ObjectModelProjector::getProjectedWorldGroundPts | ( | const std::vector< Eigen::Vector2d > & | pt_world_feet_list | ) |
Project world-ground points into image coordinates.
- Parameters
-
[in] pt_world_feet_list World-ground points to project.
◆ getProjectedWorldGroundPts() [2/2]
| const std::vector<Eigen::Vector2d> ObjectModelProjector::getProjectedWorldGroundPts | ( | const std::vector< Eigen::Vector2d > & | pt_world_feet_list | ) |
Project world-ground points into image coordinates.
- Parameters
-
[in] pt_world_feet_list World-ground points to project.
◆ getRecoveredObjectModelFromBbox() [1/2]
| RecoveredObjModel ObjectModelProjector::getRecoveredObjectModelFromBbox | ( | const NvMOTObjToTrack * | detObj, |
| const NvMOTFrameNum | frameNum, | ||
| const int | targetInd, | ||
| const bool | isInitEstimation | ||
| ) |
Recover an object model from a detector bounding box.
- Parameters
-
[in] detObj Detected object to project. [in] frameNum Current frame number. [in] targetInd Target index, or a negative value when unavailable. [in] isInitEstimation Whether this is the target's initial estimate.
◆ getRecoveredObjectModelFromBbox() [2/2]
| RecoveredObjModel ObjectModelProjector::getRecoveredObjectModelFromBbox | ( | const NvMOTObjToTrack * | detObj, |
| const NvMOTFrameNum | frameNum, | ||
| const int | targetInd, | ||
| const bool | isInitEstimation | ||
| ) |
Recover an object model from a detector bounding box.
- Parameters
-
[in] detObj Detected object to project. [in] frameNum Current frame number. [in] targetInd Target index, or a negative value when unavailable. [in] isInitEstimation Whether this is the target's initial estimate.
◆ getRecoveredObjectModelFromProj3DBbox() [1/2]
| RecoveredObjModel ObjectModelProjector::getRecoveredObjectModelFromProj3DBbox | ( | const NvMOTObjToTrack * | detObj, |
| const NvMOTFrameNum | frameNum | ||
| ) |
Recover an object model from externally projected three-dimensional bounding-box data.
- Parameters
-
[in] detObj Detected object to match. [in] frameNum Current frame number.
◆ getRecoveredObjectModelFromProj3DBbox() [2/2]
| RecoveredObjModel ObjectModelProjector::getRecoveredObjectModelFromProj3DBbox | ( | const NvMOTObjToTrack * | detObj, |
| const NvMOTFrameNum | frameNum | ||
| ) |
Recover an object model from externally projected three-dimensional bounding-box data.
- Parameters
-
[in] detObj Detected object to match. [in] frameNum Current frame number.
◆ getRecoveredObjectModelWithAdaptiveHeight() [1/2]
| RecoveredObjModel ObjectModelProjector::getRecoveredObjectModelWithAdaptiveHeight | ( | const Eigen::Vector2d | pt_img_head, |
| const Eigen::Vector2d | pt_img_waist, | ||
| const Eigen::Vector2d | pt_img_foot, | ||
| const NvMotDataTypes::Rect2f & | bbox, | ||
| const TrackerIndex & | targetInd, | ||
| const NvMOTClassId | classId, | ||
| float | conf_head, | ||
| float | conf_waist, | ||
| float | conf_foot | ||
| ) |
Get recovered 3D cylinder model with dynamic height from pose keypoints.
- Parameters
-
[in] pt_img_head The head location on the image. [in] pt_img_waist The waist location on the image. [in] pt_img_foot The foot location on the image. [in] bbox The bounding box. [in] targetInd The target index. [in] classId The class ID. [in] conf_head Confidence of the head keypoint. [in] conf_waist Confidence of the waist keypoint. [in] conf_foot Confidence of the foot keypoint.
- Returns
- Recovered 3D cylinder model with dynamic height.
◆ getRecoveredObjectModelWithAdaptiveHeight() [2/2]
| RecoveredObjModel ObjectModelProjector::getRecoveredObjectModelWithAdaptiveHeight | ( | const Eigen::Vector2d | pt_img_head, |
| const Eigen::Vector2d | pt_img_waist, | ||
| const Eigen::Vector2d | pt_img_foot, | ||
| const NvMotDataTypes::Rect2f & | bbox, | ||
| const TrackerIndex & | targetInd, | ||
| const NvMOTClassId | classId, | ||
| float | conf_head, | ||
| float | conf_waist, | ||
| float | conf_foot | ||
| ) |
Get recovered 3D cylinder model with dynamic height from pose keypoints.
- Parameters
-
[in] pt_img_head The head location on the image. [in] pt_img_waist The waist location on the image. [in] pt_img_foot The foot location on the image. [in] bbox The bounding box. [in] targetInd The target index. [in] classId The class ID. [in] conf_head Confidence of the head keypoint. [in] conf_waist Confidence of the waist keypoint. [in] conf_foot Confidence of the foot keypoint.
- Returns
- Recovered 3D cylinder model with dynamic height.
◆ getSensorName() [1/2]
|
inline |
Return the source sensor name.
Definition at line 231 of file sources/libs/nvmultiobjecttracker/include/modules/ObjectModelProjector/ObjectModelProjector.hpp.
References m_sensorName.
◆ getSensorName() [2/2]
|
inline |
Return the source sensor name.
Definition at line 231 of file 9.2/sources/libs/nvmultiobjecttracker/include/modules/ObjectModelProjector/ObjectModelProjector.hpp.
◆ getTargetClassId() [1/2]
|
inline |
Return the current target-model class ID.
Definition at line 505 of file sources/libs/nvmultiobjecttracker/include/modules/ObjectModelProjector/ObjectModelProjector.hpp.
References m_targetClassId.
◆ getTargetClassId() [2/2]
|
inline |
Return the current target-model class ID.
Definition at line 505 of file 9.2/sources/libs/nvmultiobjecttracker/include/modules/ObjectModelProjector/ObjectModelProjector.hpp.
◆ getTargetHeight() [1/2]
|
inline |
Return the current target-model height.
Definition at line 464 of file 9.2/sources/libs/nvmultiobjecttracker/include/modules/ObjectModelProjector/ObjectModelProjector.hpp.
◆ getTargetHeight() [2/2]
|
inline |
Return the current target-model height.
Definition at line 464 of file sources/libs/nvmultiobjecttracker/include/modules/ObjectModelProjector/ObjectModelProjector.hpp.
References Model3DInfo::height, and m_targetModel.
◆ getWorld3DBboxFromWorldFeet() [1/2]
| const NvDsObj3DBbox ObjectModelProjector::getWorld3DBboxFromWorldFeet | ( | const Eigen::Vector2d | pt_world_feet, |
| const NvMOTClassId | classId, | ||
| const int | targetInd | ||
| ) |
Build a world-space three-dimensional bounding box from feet coordinates.
- Parameters
-
[in] pt_world_feet World-space feet position. [in] classId Target class ID. [in] targetInd Target index.
◆ getWorld3DBboxFromWorldFeet() [2/2]
| const NvDsObj3DBbox ObjectModelProjector::getWorld3DBboxFromWorldFeet | ( | const Eigen::Vector2d | pt_world_feet, |
| const NvMOTClassId | classId, | ||
| const int | targetInd | ||
| ) |
Build a world-space three-dimensional bounding box from feet coordinates.
- Parameters
-
[in] pt_world_feet World-space feet position. [in] classId Target class ID. [in] targetInd Target index.
◆ getWorldFeetPtOnGroundFromCamFeetPt() [1/2]
| const Eigen::Vector2d ObjectModelProjector::getWorldFeetPtOnGroundFromCamFeetPt | ( | const Eigen::Vector2d | imgFeetPt, |
| const NvMOTClassId | classId, | ||
| const int | targetInd | ||
| ) |
Recover world-ground feet coordinates from an image feet point.
- Parameters
-
[in] imgFeetPt Image-space feet point. [in] classId Target class ID. [in] targetInd Target index.
◆ getWorldFeetPtOnGroundFromCamFeetPt() [2/2]
| const Eigen::Vector2d ObjectModelProjector::getWorldFeetPtOnGroundFromCamFeetPt | ( | const Eigen::Vector2d | imgFeetPt, |
| const NvMOTClassId | classId, | ||
| const int | targetInd | ||
| ) |
Recover world-ground feet coordinates from an image feet point.
- Parameters
-
[in] imgFeetPt Image-space feet point. [in] classId Target class ID. [in] targetInd Target index.
◆ getWorldFeetPtOnGroundFromCamWaistPt() [1/2]
| const Eigen::Vector2d ObjectModelProjector::getWorldFeetPtOnGroundFromCamWaistPt | ( | const Eigen::Vector2d | imgWaistPt, |
| const NvMOTClassId | classId, | ||
| const int | targetInd | ||
| ) |
Recover world-ground feet coordinates from an image waist point.
- Parameters
-
[in] imgWaistPt Image-space waist point. [in] classId Target class ID. [in] targetInd Target index.
◆ getWorldFeetPtOnGroundFromCamWaistPt() [2/2]
| const Eigen::Vector2d ObjectModelProjector::getWorldFeetPtOnGroundFromCamWaistPt | ( | const Eigen::Vector2d | imgWaistPt, |
| const NvMOTClassId | classId, | ||
| const int | targetInd | ||
| ) |
Recover world-ground feet coordinates from an image waist point.
- Parameters
-
[in] imgWaistPt Image-space waist point. [in] classId Target class ID. [in] targetInd Target index.
◆ importCameraModelInfo() [1/2]
|
protected |
Import camera-model calibration from a YAML file.
- Parameters
-
[in] filename Camera-model file path.
- Returns
- True when the camera model is imported successfully.
◆ importCameraModelInfo() [2/2]
|
protected |
Import camera-model calibration from a YAML file.
- Parameters
-
[in] filename Camera-model file path.
- Returns
- True when the camera model is imported successfully.
◆ importExternalProj3DBboxInfo() [1/2]
|
protected |
Import externally projected three-dimensional bounding boxes.
- Parameters
-
[in] filename Projected bounding-box file path.
- Returns
- True when the bounding boxes are imported successfully.
◆ importExternalProj3DBboxInfo() [2/2]
|
protected |
Import externally projected three-dimensional bounding boxes.
- Parameters
-
[in] filename Projected bounding-box file path.
- Returns
- True when the bounding boxes are imported successfully.
◆ isInitialized() [1/2]
|
inline |
Return whether the projector has been initialized.
Definition at line 228 of file sources/libs/nvmultiobjecttracker/include/modules/ObjectModelProjector/ObjectModelProjector.hpp.
References m_isInit.
◆ isInitialized() [2/2]
|
inline |
Return whether the projector has been initialized.
Definition at line 228 of file 9.2/sources/libs/nvmultiobjecttracker/include/modules/ObjectModelProjector/ObjectModelProjector.hpp.
◆ isTargetModelValid() [1/2]
|
inlineprotected |
Return whether the current target model is valid for a target.
- Parameters
-
[in] targetInd Target index. [in] classId Target class ID.
Definition at line 663 of file 9.2/sources/libs/nvmultiobjecttracker/include/modules/ObjectModelProjector/ObjectModelProjector.hpp.
References Model3DInfo::height, and Model3DInfo::radius.
◆ isTargetModelValid() [2/2]
|
inlineprotected |
Return whether the current target model is valid for a target.
- Parameters
-
[in] targetInd Target index. [in] classId Target class ID.
Definition at line 663 of file sources/libs/nvmultiobjecttracker/include/modules/ObjectModelProjector/ObjectModelProjector.hpp.
References Model3DInfo::height, m_targetClassId, m_targetModel, and Model3DInfo::radius.
◆ isTargetVisibleInImage() [1/2]
| bool ObjectModelProjector::isTargetVisibleInImage | ( | const Eigen::Vector2d & | pt_world_feet, |
| float | targetHeight | ||
| ) |
Check if any point of a vertical target (from feet to head) projects into the camera FOV.
- Parameters
-
[in] pt_world_feet World coordinates of feet (X, Y on ground plane). [in] targetHeight Actual height of the target (uses adaptive height if available).
- Returns
- True if any part of the target's vertical extent is visible in the image.
◆ isTargetVisibleInImage() [2/2]
| bool ObjectModelProjector::isTargetVisibleInImage | ( | const Eigen::Vector2d & | pt_world_feet, |
| float | targetHeight | ||
| ) |
Check if any point of a vertical target (from feet to head) projects into the camera FOV.
- Parameters
-
[in] pt_world_feet World coordinates of feet (X, Y on ground plane). [in] targetHeight Actual height of the target (uses adaptive height if available).
- Returns
- True if any part of the target's vertical extent is visible in the image.
◆ projectWorldPt2ImgPt() [1/2]
| const Eigen::Vector2d ObjectModelProjector::projectWorldPt2ImgPt | ( | const Eigen::Vector3d | pt_world | ) |
Project a world-space point into image coordinates.
- Parameters
-
[in] pt_world World-space point.
◆ projectWorldPt2ImgPt() [2/2]
| const Eigen::Vector2d ObjectModelProjector::projectWorldPt2ImgPt | ( | const Eigen::Vector3d | pt_world | ) |
Project a world-space point into image coordinates.
- Parameters
-
[in] pt_world World-space point.
◆ queryParams() [1/2]
| void ObjectModelProjector::queryParams | ( | NvMOTQuery & | paramsQuery | ) |
Populate tracker query capabilities from projector configuration.
- Parameters
-
[out] paramsQuery Tracker query structure to update.
◆ queryParams() [2/2]
| void ObjectModelProjector::queryParams | ( | NvMOTQuery & | paramsQuery | ) |
Populate tracker query capabilities from projector configuration.
- Parameters
-
[out] paramsQuery Tracker query structure to update.
◆ setTargetHeight() [1/2]
|
inline |
Update target-model height when confidence permits.
- Parameters
-
[in] height New target height. [in] confidence Confidence of the new height. [in] force Whether to update regardless of confidence.
Only update if new confidence >= current (or force is true).
Definition at line 475 of file 9.2/sources/libs/nvmultiobjecttracker/include/modules/ObjectModelProjector/ObjectModelProjector.hpp.
◆ setTargetHeight() [2/2]
|
inline |
Update target-model height when confidence permits.
- Parameters
-
[in] height New target height. [in] confidence Confidence of the new height. [in] force Whether to update regardless of confidence.
Only update if new confidence >= current (or force is true).
Definition at line 475 of file sources/libs/nvmultiobjecttracker/include/modules/ObjectModelProjector/ObjectModelProjector.hpp.
References deriveDataFromCameraProjMatrix(), Model3DInfo::height, Model3DInfo::heightConfidence, m_targetHomographyMat, and m_targetModel.
◆ setTargetModelForClass() [1/2]
|
inline |
Select the target model for a class ID.
- Parameters
-
[in] classId Target class ID.
Early return if current class matches the new class.
Definition at line 489 of file sources/libs/nvmultiobjecttracker/include/modules/ObjectModelProjector/ObjectModelProjector.hpp.
References getDefaultHomographyMatByClass(), getDefaultModelByClass(), Model3DInfo::height, NvTrackerParamsObjectModelProjector::m_debugVerboseLevel, m_params, m_targetClassId, m_targetHomographyMat, m_targetModel, and Model3DInfo::radius.
◆ setTargetModelForClass() [2/2]
|
inline |
Select the target model for a class ID.
- Parameters
-
[in] classId Target class ID.
Early return if current class matches the new class.
Definition at line 489 of file 9.2/sources/libs/nvmultiobjecttracker/include/modules/ObjectModelProjector/ObjectModelProjector.hpp.
Field Documentation
◆ m_cameraInfo
|
protected |
Set camera parameters.
Definition at line 518 of file sources/libs/nvmultiobjecttracker/include/modules/ObjectModelProjector/ObjectModelProjector.hpp.
◆ m_camLocation_World
|
protected |
Camera position in world coordinate system.
Definition at line 541 of file sources/libs/nvmultiobjecttracker/include/modules/ObjectModelProjector/ObjectModelProjector.hpp.
◆ m_configFilePath
|
protected |
Path of the module config file.
Definition at line 514 of file sources/libs/nvmultiobjecttracker/include/modules/ObjectModelProjector/ObjectModelProjector.hpp.
◆ m_defaultHomographyMatByClass
|
protected |
Stores default target homographies by class.
Definition at line 543 of file sources/libs/nvmultiobjecttracker/include/modules/ObjectModelProjector/ObjectModelProjector.hpp.
Referenced by getDefaultHomographyMatByClass().
◆ m_defaultModelByClass
|
protected |
Each class's object model.
Definition at line 522 of file sources/libs/nvmultiobjecttracker/include/modules/ObjectModelProjector/ObjectModelProjector.hpp.
Referenced by getDefaultModelByClass().
◆ m_externalProj3DBboxInfo
|
protected |
Store projected 3D bounding box info for all frames in the stream.
Definition at line 519 of file sources/libs/nvmultiobjecttracker/include/modules/ObjectModelProjector/ObjectModelProjector.hpp.
◆ m_groundPlaneHeight
|
protected |
Specifies the world-space ground-plane height.
Definition at line 523 of file sources/libs/nvmultiobjecttracker/include/modules/ObjectModelProjector/ObjectModelProjector.hpp.
◆ m_H_ground
|
protected |
Ground-plane homography, independent of target height.
Definition at line 536 of file sources/libs/nvmultiobjecttracker/include/modules/ObjectModelProjector/ObjectModelProjector.hpp.
◆ m_H_ground_inv
|
protected |
Inverse of ground plane homography.
Definition at line 537 of file sources/libs/nvmultiobjecttracker/include/modules/ObjectModelProjector/ObjectModelProjector.hpp.
◆ m_H_inv_Pz
|
protected |
H_ground_inv * P_z_col (precomputed for Sherman-Morrison).
Definition at line 540 of file sources/libs/nvmultiobjecttracker/include/modules/ObjectModelProjector/ObjectModelProjector.hpp.
◆ m_isInit
|
protected |
Indicates whether the projector has been initialized.
Definition at line 509 of file sources/libs/nvmultiobjecttracker/include/modules/ObjectModelProjector/ObjectModelProjector.hpp.
Referenced by isInitialized().
◆ m_K
|
protected |
Intrinsic matrix.
Definition at line 527 of file sources/libs/nvmultiobjecttracker/include/modules/ObjectModelProjector/ObjectModelProjector.hpp.
◆ m_K_inv
|
protected |
Inverse of intrinsic matrix.
Definition at line 528 of file sources/libs/nvmultiobjecttracker/include/modules/ObjectModelProjector/ObjectModelProjector.hpp.
◆ m_P_z_col
|
protected |
P[:,2] - projection matrix Z column (height update direction).
Definition at line 539 of file sources/libs/nvmultiobjecttracker/include/modules/ObjectModelProjector/ObjectModelProjector.hpp.
◆ m_params
|
protected |
Config params for target management.
Definition at line 516 of file sources/libs/nvmultiobjecttracker/include/modules/ObjectModelProjector/ObjectModelProjector.hpp.
Referenced by getDefaultHomographyMatByClass(), getDefaultModelByClass(), getMinPoseConfidence(), getOutputConvexHull(), getOutputFootLocation(), and setTargetModelForClass().
◆ m_pix2cam_offset
|
protected |
Shifts corner-origin pixels to the optical center for projectionMatrix_3x4.
Zero when projectionMatrix_3x4_w2p already maps into pixel coordinates.
Definition at line 532 of file sources/libs/nvmultiobjecttracker/include/modules/ObjectModelProjector/ObjectModelProjector.hpp.
◆ m_ProjMat_World2Cam
|
protected |
Stores the world-to-camera projection matrix.
Definition at line 524 of file sources/libs/nvmultiobjecttracker/include/modules/ObjectModelProjector/ObjectModelProjector.hpp.
◆ m_R
|
protected |
Rotation matrix (world to camera).
Definition at line 529 of file sources/libs/nvmultiobjecttracker/include/modules/ObjectModelProjector/ObjectModelProjector.hpp.
◆ m_r3
|
protected |
Third row of R^T (for ground plane intersection).
Definition at line 538 of file sources/libs/nvmultiobjecttracker/include/modules/ObjectModelProjector/ObjectModelProjector.hpp.
◆ m_R_T
|
protected |
Transpose of rotation matrix.
Definition at line 530 of file sources/libs/nvmultiobjecttracker/include/modules/ObjectModelProjector/ObjectModelProjector.hpp.
◆ m_resolvedCameraModelFilepath
|
protected |
Resolved camera model filepath for this stream.
Definition at line 515 of file sources/libs/nvmultiobjecttracker/include/modules/ObjectModelProjector/ObjectModelProjector.hpp.
◆ m_sensorName
|
protected |
Sensor name of the corresponding source stream.
Definition at line 511 of file sources/libs/nvmultiobjecttracker/include/modules/ObjectModelProjector/ObjectModelProjector.hpp.
Referenced by getSensorName().
◆ m_srcFrameSize
|
protected |
Source video frame size where the bbox info is based on.
Definition at line 517 of file sources/libs/nvmultiobjecttracker/include/modules/ObjectModelProjector/ObjectModelProjector.hpp.
◆ m_streamInd
|
protected |
Index of the corresponding source stream.
Definition at line 510 of file sources/libs/nvmultiobjecttracker/include/modules/ObjectModelProjector/ObjectModelProjector.hpp.
◆ m_t
|
protected |
Translation vector.
Definition at line 531 of file sources/libs/nvmultiobjecttracker/include/modules/ObjectModelProjector/ObjectModelProjector.hpp.
◆ m_targetClassId
|
protected |
Projector's current target model class ID.
Definition at line 521 of file sources/libs/nvmultiobjecttracker/include/modules/ObjectModelProjector/ObjectModelProjector.hpp.
Referenced by getTargetClassId(), isTargetModelValid(), and setTargetModelForClass().
◆ m_targetHomographyMat
|
protected |
Homography matrices for head, waist, and feet planes composed from the projection matrix.
Definition at line 542 of file sources/libs/nvmultiobjecttracker/include/modules/ObjectModelProjector/ObjectModelProjector.hpp.
Referenced by setTargetHeight(), and setTargetModelForClass().
◆ m_targetModel
|
protected |
Each target's object model can be different in size.
Definition at line 520 of file sources/libs/nvmultiobjecttracker/include/modules/ObjectModelProjector/ObjectModelProjector.hpp.
Referenced by getHeightConfidence(), getTargetHeight(), isTargetModelValid(), setTargetHeight(), and setTargetModelForClass().
The documentation for this class was generated from the following file: