Isaac Lab and Newton#
In Newton Fundamentals we drove robots with raw Newton APIs. Now we’ll use Isaac Lab, NVIDIA’s framework for robot learning, and use Newton as its physics engine. We’ll build a complete reinforcement learning (RL) pipeline that teaches a Franka robot to pick up a cube, then watch a trained policy do the job.
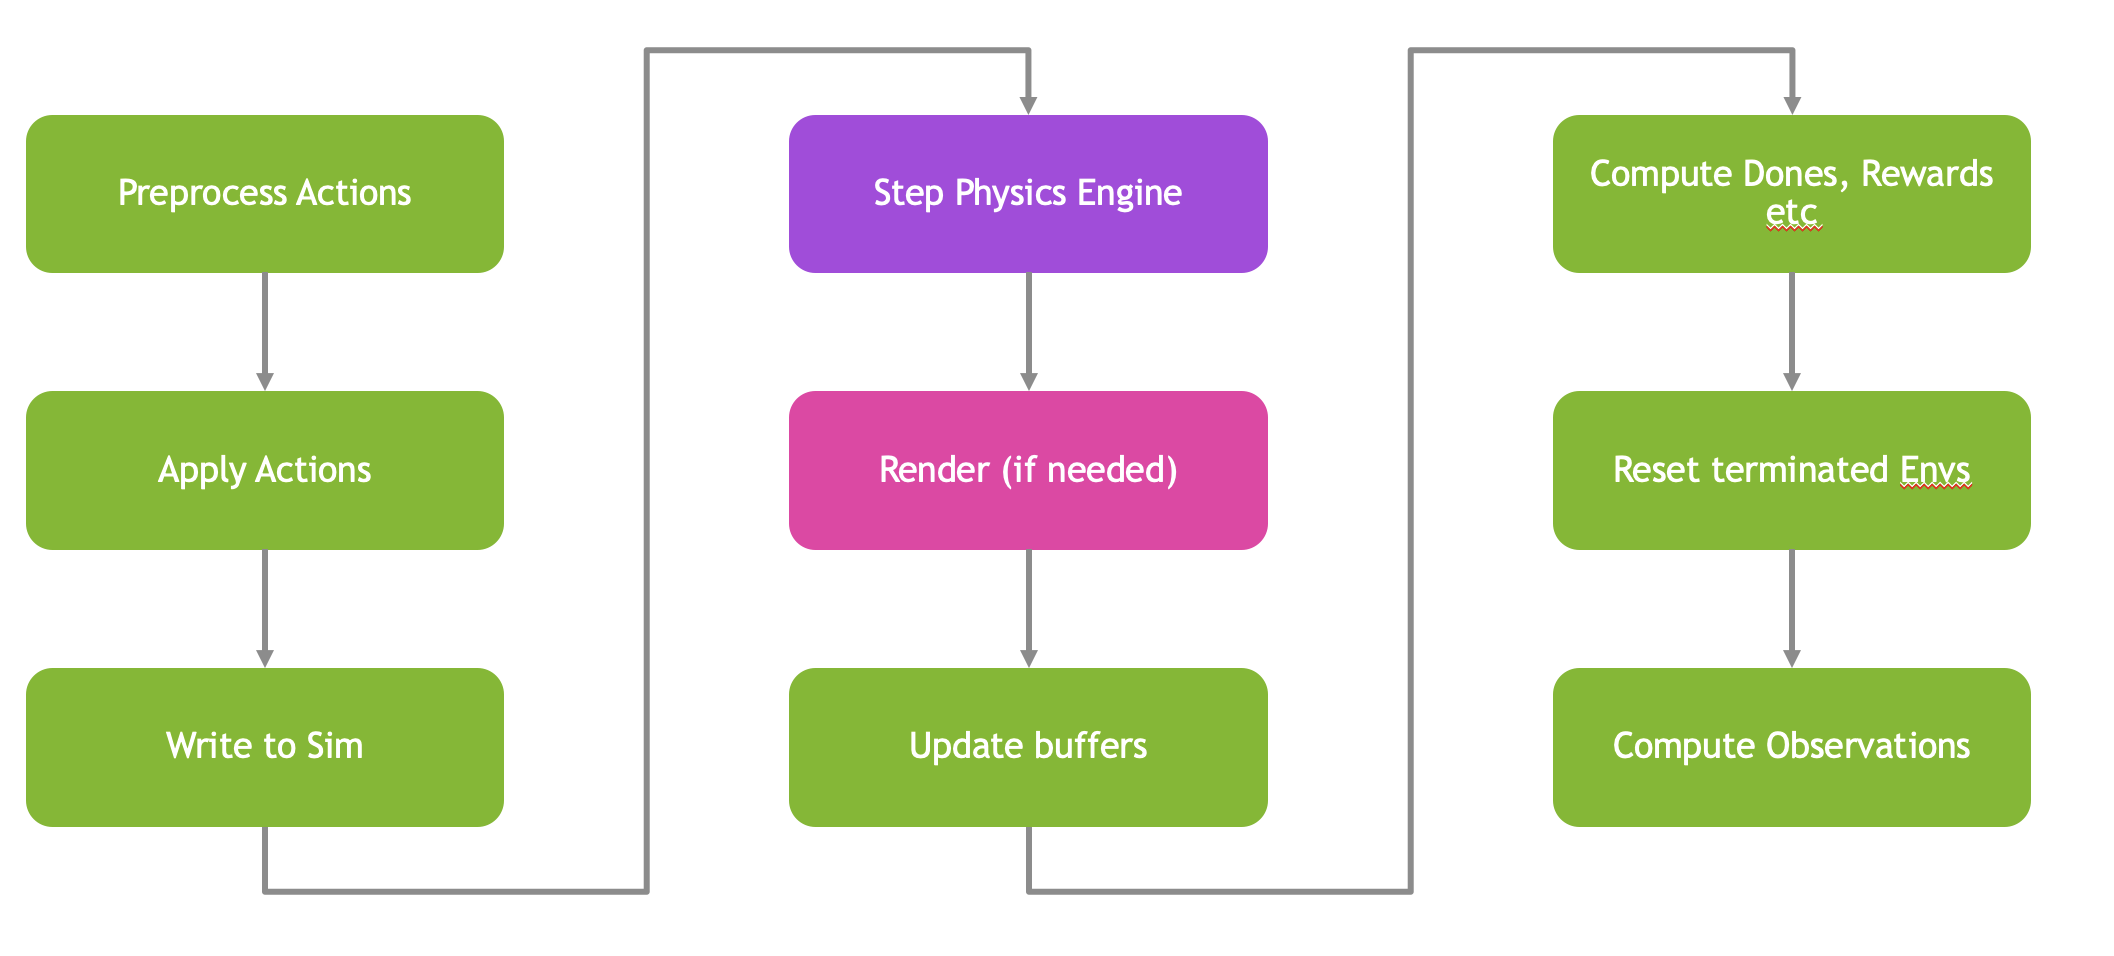
Isaac Lab handles the environment plumbing (vectorized environments, resets, observations, rewards, and the gym API), while Newton provides the fast, GPU-accelerated physics underneath. Understanding how the two fit together is the payoff for everything you learned in the previous module.
This module should take about 90 minutes to complete.
Learning Objectives#
By the end of this module, you’ll be able to:
Configure Newton as the Isaac Lab physics engine with the three-layer solver configuration.
Describe how a Direct RL environment defines a scene, actions, observations, rewards, and resets.
Run a vectorized environment loop and interpret its statistics.
Load and play back a trained PPO policy and compare it to random behavior.
How This Module Runs#
Choose the NVIDIA Brev or local setup in Getting Started: Isaac Lab and Newton.
Note
The complete, canonical implementation lives in the franka_cube extension under source/franka_cube/. Use the snippets to learn each concept, and the extension source as the runnable reference.