Detailed Description
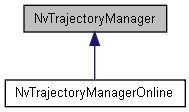
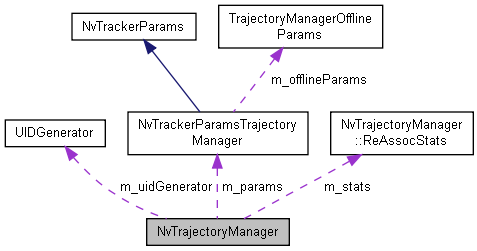
Manage target IDs, archived trajectories, and trajectory reassociation.
Definition at line 229 of file sources/libs/nvmultiobjecttracker/include/modules/TrajectoryManager/NvTrajectoryManager.hpp.
Data Structures | |
| struct | ReAssocStats |
| Re-association pipeline counters: dumped to stderr at destructor time. More... | |
Public Member Functions | |
| NvTrajectoryManager (const std::string &configFilePath) | |
| Construct a trajectory manager from configuration. More... | |
| virtual | ~NvTrajectoryManager () |
| Report statistics and destroy the trajectory manager. More... | |
| void | archiveTrajectory (const std::shared_ptr< NvTrackedObject > target) |
| Store the trajectories of the terminated objects up to a certain time. More... | |
| void | assignTargetIDs (const NvTrackedObjectList &targetList, std::map< std::shared_ptr< NvTrackedObject >, std::shared_ptr< NvTrackedObject > > &toBeTerminated, const NvMOTTimeMeta &timeMeta) |
| Assign target IDs and set targetIDTimeStamp. More... | |
| void | cleanUpArchivedTrajectories (const std::map< NvMOTStreamId, NvMOTFrame * > &inputMeta) |
| Remove expired archived trajectories for all input streams. More... | |
| void | cleanUpArchivedTrajectories_perStream (const NvMOTStreamId streamId, const uint32_t currFrameNum, const bool doPurge=false) |
| Remove expired archived trajectories for one stream. More... | |
| void | resetIDs () |
| Reset the unique-ID generator with a new random prefix. More... | |
| void | purgeArchivedTrajectories () |
| Purge all archived trajectories. More... | |
| virtual std::deque< DetectedObjInfo > | generateTrackedObjects4ReidPerStream (const NvMOTStreamId streamId, const NvTrackedObjectList &targetList) |
| Generate target detections that require ReID extraction for one stream. More... | |
| void | updateStreamIds (const std::vector< NvMOTStreamId > &streamIdsToAdd={}, const std::vector< NvMOTStreamId > &streamIdsToDel={}) |
| Update per-stream trajectory state when streams are added or removed. More... | |
| void | updateParams (const YAML::Node &fn) |
| Update dynamic parameters during runtime. More... | |
| void | setSrcFrameInfo (const NvMotDataTypes::Rect2f originalSrcImageBox, const NvMotDataTypes::Rect2f srcImageBox) |
| Set source-frame geometry used for trajectory output. More... | |
| void | setMultiViewAssociators (std::map< NvMOTStreamId, std::shared_ptr< IMultiViewAssociator >> multiViewAssociators) |
| Set the multi-view associators. More... | |
| const Trajectory4Archive & | getArchivedTrajectory (const NvMOTStreamId videoStreamId, const uint64_t targetId) |
| Return an archived trajectory by stream and target ID. More... | |
| const NvTrackerParamsTrajectoryManager | getParams () |
| Return a copy of trajectory-manager parameters. More... | |
| const float | getMinVisibility4TrajDump () |
| Return the minimum visibility required for trajectory dumping. More... | |
| const bool | getDumpDetectorBboxes () |
| Return whether detector bounding boxes are dumped. More... | |
Protected Member Functions | |
| bool | tryReAssoc (const std::shared_ptr< NvTrackedObject > target, std::map< std::shared_ptr< NvTrackedObject >, std::shared_ptr< NvTrackedObject >> &toBeFused) |
| Try to perform the re-assoc with the targets in the temporary DB that stores projected trajectories. More... | |
| bool | processTrajectory (const uint64_t targetId, const NvMOTStreamId streamId, std::list< TargetInfo > &tracklet) |
| Trim the tracklet by removing the last un-validated trajectory points. More... | |
| std::list< TargetInfo > | createProjectedTrajectories (const uint64_t targetId, const NvMOTStreamId streamId, const std::list< TargetInfo > &tracklet, int overrideShadowAge=-1) |
| Trim the tracklet by removing the last un-validated trajectory points and return the projected trajectory points only. More... | |
| void | add2ProjectedTrajectoryDB (std::shared_ptr< NvTrackedObject > target) |
| Add the projected trajectory to the temporary DB so that it can be re-associated. More... | |
| void | removeFromProjectedTrajectoryDB (std::shared_ptr< NvTrackedObject > target) |
| Remove from the projected trajectory DB. More... | |
| virtual std::list< TargetInfo > | getTrimmedTraj4ReAssoc (const std::list< TargetInfo > &newTraj, const std::list< TargetInfo > &peerTraj, const NvMOTFrameNum lastTrackedFrameNum_peer) |
| Get the trimmed new trajectory for reassociation with peer trajectory. More... | |
| bool | findMatch4ReAssoc (const std::shared_ptr< NvTrackedObject > target, std::shared_ptr< NvTrackedObject > &bestMatchPeer) |
| Find the best live projected-trajectory match for a target. More... | |
| bool | findArchiveMatch4ReAssoc (const std::shared_ptr< NvTrackedObject > newTarget) |
| Fallback re-association against terminated tracks in m_trajectoryArchive. More... | |
| bool | try3DReAssoc (const std::shared_ptr< NvTrackedObject > newTarget) |
| Perform archive-only world-distance and frame-gap re-association. More... | |
| virtual float | calculateSizeSimilarityScore (const std::list< TargetInfo > &traj, const std::list< TargetInfo > &peerTraj) |
| Calculate bounding-box size similarity between two trajectories. More... | |
| const std::tuple< float, int, float, float, float, float > | calculateSimilarityBtwTracklets (const std::list< TargetInfo > &traj, const std::list< TargetInfo > &peerTraj, const float peerTrajCov) |
| Calculate tracklet, direction, speed, and size similarity metrics. More... | |
| const std::tuple< float, int, float, float, float > | calculateAssocScore4QuasiDTW (const std::list< TargetInfo > &traj, const std::list< TargetInfo > &peerTraj, const float peerTrajCov) |
| Calculate quasi-DTW association metrics between two trajectories. More... | |
| const float | computeAngleInDegree (const Eigen::Vector2f &vec1, const Eigen::Vector2f &vec2) |
| Compute the angle between the two tracklets direction [degree]. More... | |
| const float | computeSpeedSimilarity (const Eigen::Vector2f &vec1, const Eigen::Vector2f &vec2) |
| Compute the speed similarity between the two tracklets. More... | |
| const bool | detectMotion (const Eigen::Vector2f &vec, float threshold) |
| Detect if a tracklet is in motion, that is, if its speed is at least the threshold. More... | |
| void | fuseTracklets (std::shared_ptr< NvTrackedObject > targetToBeKept, std::shared_ptr< NvTrackedObject > targetToBeFused) |
| Fuse two tracklets. More... | |
| bool | checkDuplicateTracklet (const uint64_t targetId, std::map< uint64_t, Trajectory4Archive > &tracklets, std::set< uint64_t > &peersToBeDeleted) |
| Check if the tracklet is a duplicate to another existing tracklet. More... | |
| int | calculateTrackletInclusionScore (const std::list< TargetInfo > &tracklet, const std::list< TargetInfo > &peerTracklet) |
| Calculate the number of duplicate bboxes between the two tracklets. More... | |
| void | fuseArchivedTracklets (const uint64_t targetId, const uint64_t peerId, std::map< uint64_t, Trajectory4Archive > &tracklets) |
| Fuse the peer's tracklet into the target's. More... | |
| void | dumpTrajectoryIntoFile (const NvMOTStreamId streamId, const TargetId targetId, const Trajectory4Archive &traj) |
| Dump the trajectory data into a file in a specified format. More... | |
| const uint64_t | generateNewTargetID () |
| Generate a thread-safe target ID according to the configured ID mode. More... | |
| const uint64_t | peekNewTargetID () const |
| Return the next target ID without consuming it. More... | |
Protected Attributes | |
| NvTrackerParamsTrajectoryManager | m_params |
| Config params for target management. More... | |
| const std::string | m_configFilePath |
| Config file path. More... | |
| std::map< NvMOTStreamId, std::shared_ptr< Trajectory4ArchiveList > > | m_trajectoryArchive |
| Archive of past trajectories up to a configured age, modified on the main thread and read by workers. More... | |
| std::map< NvMOTStreamId, std::shared_ptr< ProjectedTrajectoryList > > | m_projectedTrajectories |
| Temporary buffer of the projected trajectories to be re-associated. More... | |
| std::map< NvMOTStreamId, std::shared_ptr< TrackedObjectsReidIndList > > | m_trackedObjectsReidInd |
| Target's index in reid batch. More... | |
| std::map< NvMOTStreamId, bool > | m_isFileTrajectoryDumpCreated |
| Post-processing: dump trajectories into a file: only accessed in main thread. More... | |
| std::map< NvMOTStreamId, std::ofstream > | m_fileTrajectoryDump |
| Per-stream trajectory dump file, accessed only on the main thread. More... | |
| std::map< NvMOTStreamId, std::shared_ptr< IEstimator2 > > | m_trajProjector |
| Per-stream state estimator used to project trajectories for re-association. More... | |
| std::map< NvMOTStreamId, std::shared_ptr< IMultiViewAssociator > > | m_multiViewAssociators |
| Multi-view associators. More... | |
| std::map< uint64_t, NvMOTFrameNum > | m_usedPeerTargetIds |
| Claimed peer target id mapped to the frame of the claim. More... | |
| UIDGenerator | m_uidGenerator |
| ID generator. More... | |
| bool | m_isOffline = false |
| Boolean to indicate if the trajectory manager is used for offline processing. More... | |
| struct NvTrajectoryManager::ReAssocStats | m_stats |
| Stores trajectory-reassociation counters. More... | |
Constructor & Destructor Documentation
◆ NvTrajectoryManager() [1/2]
| NvTrajectoryManager::NvTrajectoryManager | ( | const std::string & | configFilePath | ) |
Construct a trajectory manager from configuration.
- Parameters
-
[in] configFilePath Path to the configuration file.
◆ ~NvTrajectoryManager() [1/2]
|
virtual |
Report statistics and destroy the trajectory manager.
◆ NvTrajectoryManager() [2/2]
| NvTrajectoryManager::NvTrajectoryManager | ( | const std::string & | configFilePath | ) |
Construct a trajectory manager from configuration.
- Parameters
-
[in] configFilePath Path to the configuration file.
◆ ~NvTrajectoryManager() [2/2]
|
virtual |
Report statistics and destroy the trajectory manager.
Member Function Documentation
◆ add2ProjectedTrajectoryDB() [1/2]
|
protected |
Add the projected trajectory to the temporary DB so that it can be re-associated.
- Parameters
-
[in] target Shadow track whose projected trajectory is stored.
◆ add2ProjectedTrajectoryDB() [2/2]
|
protected |
Add the projected trajectory to the temporary DB so that it can be re-associated.
- Parameters
-
[in] target Shadow track whose projected trajectory is stored.
◆ archiveTrajectory() [1/2]
| void NvTrajectoryManager::archiveTrajectory | ( | const std::shared_ptr< NvTrackedObject > | target | ) |
Store the trajectories of the terminated objects up to a certain time.
- Parameters
-
[in] target Terminated object whose trajectory is stored.
◆ archiveTrajectory() [2/2]
| void NvTrajectoryManager::archiveTrajectory | ( | const std::shared_ptr< NvTrackedObject > | target | ) |
Store the trajectories of the terminated objects up to a certain time.
- Parameters
-
[in] target Terminated object whose trajectory is stored.
◆ assignTargetIDs() [1/2]
| void NvTrajectoryManager::assignTargetIDs | ( | const NvTrackedObjectList & | targetList, |
| std::map< std::shared_ptr< NvTrackedObject >, std::shared_ptr< NvTrackedObject > > & | toBeTerminated, | ||
| const NvMOTTimeMeta & | timeMeta | ||
| ) |
Assign target IDs and set targetIDTimeStamp.
- Parameters
-
[in] targetList Tracked objects that may receive target IDs. [out] toBeTerminated Map from a terminated target to its peer. [in] timeMeta Timing metadata from association.
◆ assignTargetIDs() [2/2]
| void NvTrajectoryManager::assignTargetIDs | ( | const NvTrackedObjectList & | targetList, |
| std::map< std::shared_ptr< NvTrackedObject >, std::shared_ptr< NvTrackedObject > > & | toBeTerminated, | ||
| const NvMOTTimeMeta & | timeMeta | ||
| ) |
Assign target IDs and set targetIDTimeStamp.
- Parameters
-
[in] targetList Tracked objects that may receive target IDs. [out] toBeTerminated Map from a terminated target to its peer. [in] timeMeta Timing metadata from association.
◆ calculateAssocScore4QuasiDTW() [1/2]
|
protected |
Calculate quasi-DTW association metrics between two trajectories.
- Parameters
-
[in] traj First trajectory. [in] peerTraj Peer trajectory. [in] peerTrajCov Peer trajectory covariance.
- Returns
- Tuple of average IOU, frame difference, angle, speed similarity, and speed unit magnitude.
◆ calculateAssocScore4QuasiDTW() [2/2]
|
protected |
Calculate quasi-DTW association metrics between two trajectories.
- Parameters
-
[in] traj First trajectory. [in] peerTraj Peer trajectory. [in] peerTrajCov Peer trajectory covariance.
- Returns
- Tuple of average IOU, frame difference, angle, speed similarity, and speed unit magnitude.
◆ calculateSimilarityBtwTracklets() [1/2]
|
protected |
Calculate tracklet, direction, speed, and size similarity metrics.
- Parameters
-
[in] traj First trajectory. [in] peerTraj Peer trajectory. [in] peerTrajCov Peer trajectory covariance.
- Returns
- Tuple of tracklet score, frame difference, angle, speed similarity, speed unit magnitude, and size similarity.
◆ calculateSimilarityBtwTracklets() [2/2]
|
protected |
Calculate tracklet, direction, speed, and size similarity metrics.
- Parameters
-
[in] traj First trajectory. [in] peerTraj Peer trajectory. [in] peerTrajCov Peer trajectory covariance.
- Returns
- Tuple of tracklet score, frame difference, angle, speed similarity, speed unit magnitude, and size similarity.
◆ calculateSizeSimilarityScore() [1/2]
|
protectedvirtual |
Calculate bounding-box size similarity between two trajectories.
- Parameters
-
[in] traj First trajectory. [in] peerTraj Peer trajectory.
- Returns
- Average bounding-box size similarity.
◆ calculateSizeSimilarityScore() [2/2]
|
protectedvirtual |
Calculate bounding-box size similarity between two trajectories.
- Parameters
-
[in] traj First trajectory. [in] peerTraj Peer trajectory.
- Returns
- Average bounding-box size similarity.
◆ calculateTrackletInclusionScore() [1/2]
|
protected |
Calculate the number of duplicate bboxes between the two tracklets.
- Parameters
-
[in] tracklet Tracklet being compared. [in] peerTracklet Peer tracklet being compared.
- Returns
- Number of duplicate boxes, or -1 when a tracklet is empty or the tracklets do not overlap in time.
◆ calculateTrackletInclusionScore() [2/2]
|
protected |
Calculate the number of duplicate bboxes between the two tracklets.
- Parameters
-
[in] tracklet Tracklet being compared. [in] peerTracklet Peer tracklet being compared.
- Returns
- Number of duplicate boxes, or -1 when a tracklet is empty or the tracklets do not overlap in time.
◆ checkDuplicateTracklet() [1/2]
|
protected |
Check if the tracklet is a duplicate to another existing tracklet.
- Parameters
-
[in] targetId ID of the tracklet to check. [in,out] tracklets Archived tracklets for the stream; a duplicate may be fused into its peer. [in,out] peersToBeDeleted Peer IDs already marked for deletion; a duplicate peer is inserted here.
- Returns
- True when this tracklet is a duplicate of a peer.
◆ checkDuplicateTracklet() [2/2]
|
protected |
Check if the tracklet is a duplicate to another existing tracklet.
- Parameters
-
[in] targetId ID of the tracklet to check. [in,out] tracklets Archived tracklets for the stream; a duplicate may be fused into its peer. [in,out] peersToBeDeleted Peer IDs already marked for deletion; a duplicate peer is inserted here.
- Returns
- True when this tracklet is a duplicate of a peer.
◆ cleanUpArchivedTrajectories() [1/2]
| void NvTrajectoryManager::cleanUpArchivedTrajectories | ( | const std::map< NvMOTStreamId, NvMOTFrame * > & | inputMeta | ) |
Remove expired archived trajectories for all input streams.
- Parameters
-
[in] inputMeta Current input metadata by stream.
◆ cleanUpArchivedTrajectories() [2/2]
| void NvTrajectoryManager::cleanUpArchivedTrajectories | ( | const std::map< NvMOTStreamId, NvMOTFrame * > & | inputMeta | ) |
Remove expired archived trajectories for all input streams.
- Parameters
-
[in] inputMeta Current input metadata by stream.
◆ cleanUpArchivedTrajectories_perStream() [1/2]
| void NvTrajectoryManager::cleanUpArchivedTrajectories_perStream | ( | const NvMOTStreamId | streamId, |
| const uint32_t | currFrameNum, | ||
| const bool | doPurge = false |
||
| ) |
Remove expired archived trajectories for one stream.
- Parameters
-
[in] streamId Source stream identifier. [in] currFrameNum Current frame number. [in] doPurge Whether to remove every archived trajectory.
◆ cleanUpArchivedTrajectories_perStream() [2/2]
| void NvTrajectoryManager::cleanUpArchivedTrajectories_perStream | ( | const NvMOTStreamId | streamId, |
| const uint32_t | currFrameNum, | ||
| const bool | doPurge = false |
||
| ) |
Remove expired archived trajectories for one stream.
- Parameters
-
[in] streamId Source stream identifier. [in] currFrameNum Current frame number. [in] doPurge Whether to remove every archived trajectory.
◆ computeAngleInDegree() [1/2]
|
protected |
Compute the angle between the two tracklets direction [degree].
- Parameters
-
[in] vec1 Direction vector of the first tracklet. [in] vec2 Direction vector of the second tracklet.
- Returns
- Angle between the two directions in degrees.
◆ computeAngleInDegree() [2/2]
|
protected |
Compute the angle between the two tracklets direction [degree].
- Parameters
-
[in] vec1 Direction vector of the first tracklet. [in] vec2 Direction vector of the second tracklet.
- Returns
- Angle between the two directions in degrees.
◆ computeSpeedSimilarity() [1/2]
|
protected |
Compute the speed similarity between the two tracklets.
- Parameters
-
[in] vec1 Velocity vector of the first tracklet. [in] vec2 Velocity vector of the second tracklet.
- Returns
- Speed similarity, where a higher value means a closer match.
◆ computeSpeedSimilarity() [2/2]
|
protected |
Compute the speed similarity between the two tracklets.
- Parameters
-
[in] vec1 Velocity vector of the first tracklet. [in] vec2 Velocity vector of the second tracklet.
- Returns
- Speed similarity, where a higher value means a closer match.
◆ createProjectedTrajectories() [1/2]
|
protected |
Trim the tracklet by removing the last un-validated trajectory points and return the projected trajectory points only.
- Parameters
-
[in] targetId ID of the tracklet. [in] streamId Stream that owns the tracklet. [in] tracklet Tracklet to project. [in] overrideShadowAge Shadow age to use when non-negative; a negative value counts INACTIVE frames at the tail.
- Returns
- Projected trajectory points.
◆ createProjectedTrajectories() [2/2]
|
protected |
Trim the tracklet by removing the last un-validated trajectory points and return the projected trajectory points only.
- Parameters
-
[in] targetId ID of the tracklet. [in] streamId Stream that owns the tracklet. [in] tracklet Tracklet to project. [in] overrideShadowAge Shadow age to use when non-negative; a negative value counts INACTIVE frames at the tail.
- Returns
- Projected trajectory points.
◆ detectMotion() [1/2]
|
protected |
Detect if a tracklet is in motion, that is, if its speed is at least the threshold.
- Parameters
-
[in] vec Velocity vector of the tracklet. [in] threshold Minimum speed treated as motion.
- Returns
- True when the vector speed is at least the threshold.
◆ detectMotion() [2/2]
|
protected |
Detect if a tracklet is in motion, that is, if its speed is at least the threshold.
- Parameters
-
[in] vec Velocity vector of the tracklet. [in] threshold Minimum speed treated as motion.
- Returns
- True when the vector speed is at least the threshold.
◆ dumpTrajectoryIntoFile() [1/2]
|
protected |
Dump the trajectory data into a file in a specified format.
- Parameters
-
[in] streamId Stream that owns the trajectory. [in] targetId ID of the trajectory to dump. [in] traj Archived trajectory to write.
◆ dumpTrajectoryIntoFile() [2/2]
|
protected |
Dump the trajectory data into a file in a specified format.
- Parameters
-
[in] streamId Stream that owns the trajectory. [in] targetId ID of the trajectory to dump. [in] traj Archived trajectory to write.
◆ findArchiveMatch4ReAssoc() [1/2]
|
protected |
Fallback re-association against terminated tracks in m_trajectoryArchive.
- Parameters
-
[in] newTarget Newly appearing track needing an ID.
- Returns
- True if a match above minMatchingScore4Overall was found.
◆ findArchiveMatch4ReAssoc() [2/2]
|
protected |
Fallback re-association against terminated tracks in m_trajectoryArchive.
- Parameters
-
[in] newTarget Newly appearing track needing an ID.
- Returns
- True if a match above minMatchingScore4Overall was found.
◆ findMatch4ReAssoc() [1/2]
|
protected |
Find the best live projected-trajectory match for a target.
- Parameters
-
[in] target Target to reassociate. [out] bestMatchPeer Best matching peer target.
- Returns
- True when a match meets the reassociation threshold.
◆ findMatch4ReAssoc() [2/2]
|
protected |
Find the best live projected-trajectory match for a target.
- Parameters
-
[in] target Target to reassociate. [out] bestMatchPeer Best matching peer target.
- Returns
- True when a match meets the reassociation threshold.
◆ fuseArchivedTracklets() [1/2]
|
protected |
Fuse the peer's tracklet into the target's.
- Parameters
-
[in] targetId ID of the tracklet that is kept. [in] peerId ID of the peer tracklet that is merged in. [in,out] tracklets Archived tracklets; the kept tracklet is replaced by the fused result.
◆ fuseArchivedTracklets() [2/2]
|
protected |
Fuse the peer's tracklet into the target's.
- Parameters
-
[in] targetId ID of the tracklet that is kept. [in] peerId ID of the peer tracklet that is merged in. [in,out] tracklets Archived tracklets; the kept tracklet is replaced by the fused result.
◆ fuseTracklets() [1/2]
|
protected |
Fuse two tracklets.
- Parameters
-
[in] targetToBeKept Track that is kept and receives the fused trajectory. [in] targetToBeFused Track whose trajectory is copied into the kept track.
◆ fuseTracklets() [2/2]
|
protected |
Fuse two tracklets.
- Parameters
-
[in] targetToBeKept Track that is kept and receives the fused trajectory. [in] targetToBeFused Track whose trajectory is copied into the kept track.
◆ generateNewTargetID() [1/2]
|
protected |
Generate a thread-safe target ID according to the configured ID mode.
◆ generateNewTargetID() [2/2]
|
protected |
Generate a thread-safe target ID according to the configured ID mode.
◆ generateTrackedObjects4ReidPerStream() [1/2]
|
virtual |
Generate target detections that require ReID extraction for one stream.
- Parameters
-
[in] streamId Source stream identifier. [in] targetList Tracked targets to inspect.
◆ generateTrackedObjects4ReidPerStream() [2/2]
|
virtual |
Generate target detections that require ReID extraction for one stream.
- Parameters
-
[in] streamId Source stream identifier. [in] targetList Tracked targets to inspect.
◆ getArchivedTrajectory() [1/2]
|
inline |
Return an archived trajectory by stream and target ID.
- Parameters
-
[in] videoStreamId Source stream identifier. [in] targetId Target ID.
Definition at line 323 of file sources/libs/nvmultiobjecttracker/include/modules/TrajectoryManager/NvTrajectoryManager.hpp.
References m_trajectoryArchive.
◆ getArchivedTrajectory() [2/2]
|
inline |
Return an archived trajectory by stream and target ID.
- Parameters
-
[in] videoStreamId Source stream identifier. [in] targetId Target ID.
Definition at line 323 of file 9.2/sources/libs/nvmultiobjecttracker/include/modules/TrajectoryManager/NvTrajectoryManager.hpp.
References m_trajectoryArchive.
◆ getDumpDetectorBboxes() [1/2]
|
inline |
Return whether detector bounding boxes are dumped.
Definition at line 335 of file sources/libs/nvmultiobjecttracker/include/modules/TrajectoryManager/NvTrajectoryManager.hpp.
References NvTrackerParamsTrajectoryManager::m_dumpDetectorBboxes, and m_params.
◆ getDumpDetectorBboxes() [2/2]
|
inline |
Return whether detector bounding boxes are dumped.
Definition at line 335 of file 9.2/sources/libs/nvmultiobjecttracker/include/modules/TrajectoryManager/NvTrajectoryManager.hpp.
References NvTrackerParamsTrajectoryManager::m_dumpDetectorBboxes, and m_params.
◆ getMinVisibility4TrajDump() [1/2]
|
inline |
Return the minimum visibility required for trajectory dumping.
Definition at line 332 of file sources/libs/nvmultiobjecttracker/include/modules/TrajectoryManager/NvTrajectoryManager.hpp.
References NvTrackerParamsTrajectoryManager::m_minVisibility4TrajDump, and m_params.
◆ getMinVisibility4TrajDump() [2/2]
|
inline |
Return the minimum visibility required for trajectory dumping.
Definition at line 332 of file 9.2/sources/libs/nvmultiobjecttracker/include/modules/TrajectoryManager/NvTrajectoryManager.hpp.
References NvTrackerParamsTrajectoryManager::m_minVisibility4TrajDump, and m_params.
◆ getParams() [1/2]
|
inline |
Return a copy of trajectory-manager parameters.
Definition at line 329 of file 9.2/sources/libs/nvmultiobjecttracker/include/modules/TrajectoryManager/NvTrajectoryManager.hpp.
References m_params.
◆ getParams() [2/2]
|
inline |
Return a copy of trajectory-manager parameters.
Definition at line 329 of file sources/libs/nvmultiobjecttracker/include/modules/TrajectoryManager/NvTrajectoryManager.hpp.
References m_params.
◆ getTrimmedTraj4ReAssoc() [1/2]
|
protectedvirtual |
Get the trimmed new trajectory for reassociation with peer trajectory.
- Parameters
-
[in] newTraj Trajectory to be trimmed. [in] peerTraj Peer trajectory to reassociate against. [in] lastTrackedFrameNum_peer Last tracked frame number of the peer.
- Returns
- The trimmed new trajectory.
◆ getTrimmedTraj4ReAssoc() [2/2]
|
protectedvirtual |
Get the trimmed new trajectory for reassociation with peer trajectory.
- Parameters
-
[in] newTraj Trajectory to be trimmed. [in] peerTraj Peer trajectory to reassociate against. [in] lastTrackedFrameNum_peer Last tracked frame number of the peer.
- Returns
- The trimmed new trajectory.
◆ peekNewTargetID() [1/2]
|
protected |
Return the next target ID without consuming it.
◆ peekNewTargetID() [2/2]
|
protected |
Return the next target ID without consuming it.
◆ processTrajectory() [1/2]
|
protected |
Trim the tracklet by removing the last un-validated trajectory points.
- Parameters
-
[in] targetId ID of the tracklet. [in] streamId Stream that owns the tracklet. [in,out] tracklet Tracklet trimmed in place by removing unvalidated tail points.
- Returns
- True when the tracklet is valid to archive.
◆ processTrajectory() [2/2]
|
protected |
Trim the tracklet by removing the last un-validated trajectory points.
- Parameters
-
[in] targetId ID of the tracklet. [in] streamId Stream that owns the tracklet. [in,out] tracklet Tracklet trimmed in place by removing unvalidated tail points.
- Returns
- True when the tracklet is valid to archive.
◆ purgeArchivedTrajectories() [1/2]
| void NvTrajectoryManager::purgeArchivedTrajectories | ( | ) |
Purge all archived trajectories.
◆ purgeArchivedTrajectories() [2/2]
| void NvTrajectoryManager::purgeArchivedTrajectories | ( | ) |
Purge all archived trajectories.
◆ removeFromProjectedTrajectoryDB() [1/2]
|
protected |
Remove from the projected trajectory DB.
- Parameters
-
[in] target Track to remove from the projected trajectory database.
◆ removeFromProjectedTrajectoryDB() [2/2]
|
protected |
Remove from the projected trajectory DB.
- Parameters
-
[in] target Track to remove from the projected trajectory database.
◆ resetIDs() [1/2]
|
inline |
Reset the unique-ID generator with a new random prefix.
Definition at line 276 of file sources/libs/nvmultiobjecttracker/include/modules/TrajectoryManager/NvTrajectoryManager.hpp.
References m_uidGenerator, and UIDGenerator::reset().
◆ resetIDs() [2/2]
|
inline |
Reset the unique-ID generator with a new random prefix.
Definition at line 276 of file 9.2/sources/libs/nvmultiobjecttracker/include/modules/TrajectoryManager/NvTrajectoryManager.hpp.
References m_uidGenerator, and UIDGenerator::reset().
◆ setMultiViewAssociators() [1/2]
| void NvTrajectoryManager::setMultiViewAssociators | ( | std::map< NvMOTStreamId, std::shared_ptr< IMultiViewAssociator >> | multiViewAssociators | ) |
Set the multi-view associators.
- Parameters
-
[in] multiViewAssociators Per-stream multi-view associators.
◆ setMultiViewAssociators() [2/2]
| void NvTrajectoryManager::setMultiViewAssociators | ( | std::map< NvMOTStreamId, std::shared_ptr< IMultiViewAssociator >> | multiViewAssociators | ) |
Set the multi-view associators.
- Parameters
-
[in] multiViewAssociators Per-stream multi-view associators.
◆ setSrcFrameInfo() [1/2]
| void NvTrajectoryManager::setSrcFrameInfo | ( | const NvMotDataTypes::Rect2f | originalSrcImageBox, |
| const NvMotDataTypes::Rect2f | srcImageBox | ||
| ) |
Set source-frame geometry used for trajectory output.
- Parameters
-
[in] originalSrcImageBox Original source image bounds. [in] srcImageBox Tracker source image bounds.
◆ setSrcFrameInfo() [2/2]
| void NvTrajectoryManager::setSrcFrameInfo | ( | const NvMotDataTypes::Rect2f | originalSrcImageBox, |
| const NvMotDataTypes::Rect2f | srcImageBox | ||
| ) |
Set source-frame geometry used for trajectory output.
- Parameters
-
[in] originalSrcImageBox Original source image bounds. [in] srcImageBox Tracker source image bounds.
◆ try3DReAssoc() [1/2]
|
protected |
Perform archive-only world-distance and frame-gap re-association.
Searches m_trajectoryArchive for terminated tracks within maxFrameGap4WorldDistReAssoc whose last valid world foot point is within maxWorldDist4ArchiveReAssoc of the new track and whose bbox similarity is at least 0.5.
- Parameters
-
[in] newTarget Newly appearing track needing an ID.
- Returns
- True if a match above minMatchingScore4Overall was found.
◆ try3DReAssoc() [2/2]
|
protected |
Perform archive-only world-distance and frame-gap re-association.
Searches m_trajectoryArchive for terminated tracks within maxFrameGap4WorldDistReAssoc whose last valid world foot point is within maxWorldDist4ArchiveReAssoc of the new track and whose bbox similarity is at least 0.5.
- Parameters
-
[in] newTarget Newly appearing track needing an ID.
- Returns
- True if a match above minMatchingScore4Overall was found.
◆ tryReAssoc() [1/2]
|
protected |
Try to perform the re-assoc with the targets in the temporary DB that stores projected trajectories.
- Parameters
-
[in] target Target to reassociate. [out] toBeFused Map from a terminated target to its peer.
- Returns
- True when reassociation succeeds.
◆ tryReAssoc() [2/2]
|
protected |
Try to perform the re-assoc with the targets in the temporary DB that stores projected trajectories.
- Parameters
-
[in] target Target to reassociate. [out] toBeFused Map from a terminated target to its peer.
- Returns
- True when reassociation succeeds.
◆ updateParams() [1/2]
| void NvTrajectoryManager::updateParams | ( | const YAML::Node & | fn | ) |
Update dynamic parameters during runtime.
- Parameters
-
[in] fn Parsed YAML structure of config to update.
◆ updateParams() [2/2]
| void NvTrajectoryManager::updateParams | ( | const YAML::Node & | fn | ) |
Update dynamic parameters during runtime.
- Parameters
-
[in] fn Parsed YAML structure of config to update.
◆ updateStreamIds() [1/2]
| void NvTrajectoryManager::updateStreamIds | ( | const std::vector< NvMOTStreamId > & | streamIdsToAdd = {}, |
| const std::vector< NvMOTStreamId > & | streamIdsToDel = {} |
||
| ) |
Update per-stream trajectory state when streams are added or removed.
- Parameters
-
[in] streamIdsToAdd Stream identifiers to add. [in] streamIdsToDel Stream identifiers to remove.
◆ updateStreamIds() [2/2]
| void NvTrajectoryManager::updateStreamIds | ( | const std::vector< NvMOTStreamId > & | streamIdsToAdd = {}, |
| const std::vector< NvMOTStreamId > & | streamIdsToDel = {} |
||
| ) |
Update per-stream trajectory state when streams are added or removed.
- Parameters
-
[in] streamIdsToAdd Stream identifiers to add. [in] streamIdsToDel Stream identifiers to remove.
Field Documentation
◆ m_configFilePath
|
protected |
Config file path.
Definition at line 339 of file sources/libs/nvmultiobjecttracker/include/modules/TrajectoryManager/NvTrajectoryManager.hpp.
◆ m_fileTrajectoryDump
|
protected |
Per-stream trajectory dump file, accessed only on the main thread.
Definition at line 346 of file sources/libs/nvmultiobjecttracker/include/modules/TrajectoryManager/NvTrajectoryManager.hpp.
◆ m_isFileTrajectoryDumpCreated
|
protected |
Post-processing: dump trajectories into a file: only accessed in main thread.
Definition at line 345 of file sources/libs/nvmultiobjecttracker/include/modules/TrajectoryManager/NvTrajectoryManager.hpp.
◆ m_isOffline
|
protected |
Boolean to indicate if the trajectory manager is used for offline processing.
Definition at line 360 of file sources/libs/nvmultiobjecttracker/include/modules/TrajectoryManager/NvTrajectoryManager.hpp.
◆ m_multiViewAssociators
|
protected |
Multi-view associators.
Definition at line 350 of file sources/libs/nvmultiobjecttracker/include/modules/TrajectoryManager/NvTrajectoryManager.hpp.
◆ m_params
|
protected |
Config params for target management.
Definition at line 338 of file sources/libs/nvmultiobjecttracker/include/modules/TrajectoryManager/NvTrajectoryManager.hpp.
Referenced by getDumpDetectorBboxes(), getMinVisibility4TrajDump(), and getParams().
◆ m_projectedTrajectories
|
protected |
Temporary buffer of the projected trajectories to be re-associated.
Definition at line 343 of file sources/libs/nvmultiobjecttracker/include/modules/TrajectoryManager/NvTrajectoryManager.hpp.
◆ m_stats
|
protected |
Stores trajectory-reassociation counters.
◆ m_trackedObjectsReidInd
|
protected |
Target's index in reid batch.
Definition at line 344 of file sources/libs/nvmultiobjecttracker/include/modules/TrajectoryManager/NvTrajectoryManager.hpp.
◆ m_trajectoryArchive
|
protected |
Archive of past trajectories up to a configured age, modified on the main thread and read by workers.
Definition at line 342 of file sources/libs/nvmultiobjecttracker/include/modules/TrajectoryManager/NvTrajectoryManager.hpp.
Referenced by getArchivedTrajectory().
◆ m_trajProjector
|
protected |
Per-stream state estimator used to project trajectories for re-association.
Definition at line 349 of file sources/libs/nvmultiobjecttracker/include/modules/TrajectoryManager/NvTrajectoryManager.hpp.
◆ m_uidGenerator
|
protected |
ID generator.
Definition at line 357 of file sources/libs/nvmultiobjecttracker/include/modules/TrajectoryManager/NvTrajectoryManager.hpp.
Referenced by resetIDs().
◆ m_usedPeerTargetIds
|
protected |
Claimed peer target id mapped to the frame of the claim.
The claim blocks reuse for m_maxAge4TrackletArchiving frames.
Definition at line 353 of file sources/libs/nvmultiobjecttracker/include/modules/TrajectoryManager/NvTrajectoryManager.hpp.
The documentation for this class was generated from the following file: