Detailed Description
Definition at line 912 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_frame.hpp.
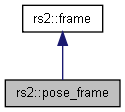
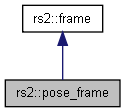
Public Member Functions | |
| pose_frame (const frame &f) | |
| Extends the frame class with additional pose related attributes and functions. More... | |
| rs2_pose | get_pose_data () const |
| Retrieve the pose data from T2xx position tracking sensor. More... | |
| pose_frame (const frame &f) | |
| Extends the frame class with additional pose related attributes and functions. More... | |
| rs2_pose | get_pose_data () const |
| Retrieve the pose data from T2xx position tracking sensor. More... | |
| void | swap (frame &other) |
| Swap the internal frame handle with the one in parameter. More... | |
| void | swap (frame &other) |
| Swap the internal frame handle with the one in parameter. More... | |
| void | keep () |
| keep the frame, otherwise if no refernce to the frame, the frame will be released. More... | |
| void | keep () |
| keep the frame, otherwise if no refernce to the frame, the frame will be released. More... | |
| operator bool () const | |
| Parenthesis operator check if internal frame handle is valid. More... | |
| operator bool () const | |
| Parenthesis operator check if internal frame handle is valid. More... | |
| rs2_sensor * | get_sensor () |
| rs2_sensor * | get_sensor () |
| double | get_timestamp () const |
| retrieve the time at which the frame was captured During the frame's lifetime it receives timestamps both at the device and host levels. More... | |
| double | get_timestamp () const |
| retrieve the time at which the frame was captured During the frame's lifetime it receives timestamps both at the device and host levels. More... | |
| rs2_timestamp_domain | get_frame_timestamp_domain () const |
| retrieve the timestamp domain More... | |
| rs2_timestamp_domain | get_frame_timestamp_domain () const |
| retrieve the timestamp domain More... | |
| rs2_metadata_type | get_frame_metadata (rs2_frame_metadata_value frame_metadata) const |
| retrieve the current value of a single frame_metadata More... | |
| rs2_metadata_type | get_frame_metadata (rs2_frame_metadata_value frame_metadata) const |
| retrieve the current value of a single frame_metadata More... | |
| bool | supports_frame_metadata (rs2_frame_metadata_value frame_metadata) const |
| determine if the device allows a specific metadata to be queried More... | |
| bool | supports_frame_metadata (rs2_frame_metadata_value frame_metadata) const |
| determine if the device allows a specific metadata to be queried More... | |
| unsigned long long | get_frame_number () const |
| retrieve frame number (from frame handle) More... | |
| unsigned long long | get_frame_number () const |
| retrieve frame number (from frame handle) More... | |
| const int | get_data_size () const |
| retrieve data size from frame handle More... | |
| const int | get_data_size () const |
| retrieve data size from frame handle More... | |
| const void * | get_data () const |
| retrieve data from frame handle More... | |
| const void * | get_data () const |
| retrieve data from frame handle More... | |
| stream_profile | get_profile () const |
| retrieve stream profile from frame handle More... | |
| stream_profile | get_profile () const |
| retrieve stream profile from frame handle More... | |
| template<class T > | |
| bool | is () const |
| Template function, checking if current instance is the type of another class. More... | |
| template<class T > | |
| bool | is () const |
| Template function, checking if current instance is the type of another class. More... | |
| template<class T > | |
| T | as () const |
| Template function, cast current instance as the type of another class. More... | |
| template<class T > | |
| T | as () const |
| Template function, cast current instance as the type of another class. More... | |
| rs2_frame * | get () const |
| Retrieve back the internal frame handle. More... | |
| rs2_frame * | get () const |
| Retrieve back the internal frame handle. More... | |
| operator rs2_frame * () | |
| operator rs2_frame * () | |
| frame | apply_filter (filter_interface &filter) |
| frame | apply_filter (filter_interface &filter) |
Protected Member Functions | |
| void | add_ref () const |
| add additional reference to a frame without duplicating frame data More... | |
| void | add_ref () const |
| add additional reference to a frame without duplicating frame data More... | |
| void | reset () |
| void | reset () |
Constructor & Destructor Documentation
◆ pose_frame() [1/2]
|
inline |
Extends the frame class with additional pose related attributes and functions.
- Parameters
-
[in] frame - existing frame instance
Definition at line 919 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_frame.hpp.
References rs2::frame::get(), rs2::error::handle(), rs2::frame::reset(), RS2_EXTENSION_POSE_FRAME, and rs2_is_frame_extendable_to().
◆ pose_frame() [2/2]
|
inline |
Extends the frame class with additional pose related attributes and functions.
- Parameters
-
[in] frame - existing frame instance
Definition at line 919 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_frame.hpp.
References rs2::error::handle(), rs2::frame::reset(), RS2_EXTENSION_POSE_FRAME, and rs2_is_frame_extendable_to().
Member Function Documentation
◆ add_ref() [1/2]
|
inlineprotectedinherited |
add additional reference to a frame without duplicating frame data
- Parameters
-
[out] result new frame reference, release by destructor
- Returns
- true if cloning was successful
Definition at line 604 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_frame.hpp.
References rs2::error::handle(), and rs2_frame_add_ref().
Referenced by rs2::frame::frame().
◆ add_ref() [2/2]
|
inlineprotectedinherited |
add additional reference to a frame without duplicating frame data
- Parameters
-
[out] result new frame reference, release by destructor
- Returns
- true if cloning was successful
Definition at line 604 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_frame.hpp.
References rs2::error::handle(), and rs2_frame_add_ref().
◆ apply_filter() [1/2]
|
inlineinherited |
Definition at line 593 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_frame.hpp.
References rs2::filter::process().
◆ apply_filter() [2/2]
|
inlineinherited |
Definition at line 593 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_frame.hpp.
References rs2::filter::process().
◆ as() [1/2]
|
inlineinherited |
Template function, cast current instance as the type of another class.
- Returns
- class instance.
Definition at line 580 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_frame.hpp.
Referenced by rs2::frameset::get_pose_frame().
◆ as() [2/2]
|
inlineinherited |
Template function, cast current instance as the type of another class.
- Returns
- class instance.
Definition at line 580 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_frame.hpp.
◆ get() [1/2]
|
inlineinherited |
Retrieve back the internal frame handle.
- Returns
- rs2_frame - internal frame handle.
Definition at line 590 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_frame.hpp.
◆ get() [2/2]
|
inlineinherited |
Retrieve back the internal frame handle.
- Returns
- rs2_frame - internal frame handle.
Definition at line 590 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_frame.hpp.
Referenced by rs2::frame_source::allocate_motion_frame(), rs2::frame_source::allocate_points(), rs2::frame_source::allocate_video_frame(), rs2::depth_frame::depth_frame(), rs2::disparity_frame::disparity_frame(), rs2::points::export_to_ply(), rs2::video_frame::extract_target_dimensions(), rs2::frameset::foreach_rs(), rs2::frame_source::frame_ready(), rs2::frameset::frameset(), rs2::disparity_frame::get_baseline(), rs2::video_frame::get_bits_per_pixel(), rs2::depth_frame::get_distance(), rs2::video_frame::get_height(), get_pose_data(), rs2::video_frame::get_stride_in_bytes(), rs2::points::get_texture_coordinates(), rs2::depth_frame::get_units(), rs2::points::get_vertices(), rs2::video_frame::get_width(), rs2::motion_frame::motion_frame(), rs2::frameset::operator[](), rs2::points::points(), pose_frame(), and rs2::video_frame::video_frame().
◆ get_data() [1/2]
|
inlineinherited |
retrieve data from frame handle
- Returns
- the pointer to the start of the frame data
Definition at line 545 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_frame.hpp.
References rs2::error::handle(), and rs2_get_frame_data().
Referenced by rs2::motion_frame::get_motion_data().
◆ get_data() [2/2]
|
inlineinherited |
retrieve data from frame handle
- Returns
- the pointer to the start of the frame data
Definition at line 545 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_frame.hpp.
References rs2::error::handle(), and rs2_get_frame_data().
◆ get_data_size() [1/2]
|
inlineinherited |
retrieve data size from frame handle
- Returns
- the number of bytes in frame
Definition at line 533 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_frame.hpp.
References rs2::error::handle(), and rs2_get_frame_data_size().
◆ get_data_size() [2/2]
|
inlineinherited |
retrieve data size from frame handle
- Returns
- the number of bytes in frame
Definition at line 533 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_frame.hpp.
References rs2::error::handle(), and rs2_get_frame_data_size().
◆ get_frame_metadata() [1/2]
|
inlineinherited |
retrieve the current value of a single frame_metadata
- Parameters
-
[in] frame_metadata the frame_metadata whose value should be retrieved
- Returns
- the value of the frame_metadata
Definition at line 497 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_frame.hpp.
References rs2::error::handle(), and rs2_get_frame_metadata().
◆ get_frame_metadata() [2/2]
|
inlineinherited |
retrieve the current value of a single frame_metadata
- Parameters
-
[in] frame_metadata the frame_metadata whose value should be retrieved
- Returns
- the value of the frame_metadata
Definition at line 497 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_frame.hpp.
References rs2::error::handle(), and rs2_get_frame_metadata().
◆ get_frame_number() [1/2]
|
inlineinherited |
retrieve frame number (from frame handle)
- Returns
- the frame number of the frame, in milliseconds since the device was started
Definition at line 521 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_frame.hpp.
References rs2::error::handle(), and rs2_get_frame_number().
◆ get_frame_number() [2/2]
|
inlineinherited |
retrieve frame number (from frame handle)
- Returns
- the frame number of the frame, in milliseconds since the device was started
Definition at line 521 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_frame.hpp.
References rs2::error::handle(), and rs2_get_frame_number().
◆ get_frame_timestamp_domain() [1/2]
|
inlineinherited |
retrieve the timestamp domain
- Returns
- timestamp domain (clock name) for timestamp values
Definition at line 485 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_frame.hpp.
References rs2::error::handle(), and rs2_get_frame_timestamp_domain().
◆ get_frame_timestamp_domain() [2/2]
|
inlineinherited |
retrieve the timestamp domain
- Returns
- timestamp domain (clock name) for timestamp values
Definition at line 485 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_frame.hpp.
References rs2::error::handle(), and rs2_get_frame_timestamp_domain().
◆ get_pose_data() [1/2]
|
inline |
Retrieve the pose data from T2xx position tracking sensor.
- Returns
- rs2_pose - orientation and velocity data.
Definition at line 933 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_frame.hpp.
References rs2::frame::get(), rs2::error::handle(), and rs2_pose_frame_get_pose_data().
◆ get_pose_data() [2/2]
|
inline |
Retrieve the pose data from T2xx position tracking sensor.
- Returns
- rs2_pose - orientation and velocity data.
Definition at line 933 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_frame.hpp.
References rs2::frame::get(), rs2::error::handle(), and rs2_pose_frame_get_pose_data().
◆ get_profile() [1/2]
|
inlineinherited |
retrieve stream profile from frame handle
- Returns
- stream_profile - the pointer to the stream profile
Definition at line 557 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_frame.hpp.
References rs2::error::handle(), and rs2_get_frame_stream_profile().
Referenced by rs2::frameset::first_or_default(), rs2::frameset::get_fisheye_frame(), rs2::frameset::get_infrared_frame(), rs2::frameset::get_pose_frame(), and rs2::pointcloud::map_to().
◆ get_profile() [2/2]
|
inlineinherited |
retrieve stream profile from frame handle
- Returns
- stream_profile - the pointer to the stream profile
Definition at line 557 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_frame.hpp.
References rs2::error::handle(), and rs2_get_frame_stream_profile().
◆ get_sensor() [1/2]
|
inlineinherited |
Definition at line 445 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_frame.hpp.
References rs2::error::handle(), and rs2_get_frame_sensor().
Referenced by rs2::sensor_from_frame().
◆ get_sensor() [2/2]
|
inlineinherited |
Definition at line 445 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_frame.hpp.
References rs2::error::handle(), and rs2_get_frame_sensor().
◆ get_timestamp() [1/2]
|
inlineinherited |
retrieve the time at which the frame was captured During the frame's lifetime it receives timestamps both at the device and host levels.
The different timestamps are gathered and managed under the frame's Metadata attributes. Chronologically the list of timestamps comprises of: SENSOR_TIMESTAMP - Device clock. For video sensors designates the middle of exposure. Requires metadata support. FRAME_TIMESTAMP - Device clock. Stamped at the beginning of frame readout and transfer. Requires metadata support. BACKEND_TIMESTAMP - Host (EPOCH) clock in Kernel space. Frame transfer from USB Controller to the USB Driver. TIME_OF_ARRIVAL - Host (EPOCH) clock in User space. Frame transfer from the USB Driver to Librealsense.
During runtime the SDK dynamically selects the most correct representaion, based on both device and host capabilities: In case the frame metadata is not configured:
- The function call provides the TIME_OF_ARRIVAL stamp. In case the metadata is available the function returns:
HW Timestamp(FRAME_TIMESTAMP), orGlobal TimestampHost-corrected derivative ofHW Timestamprequired for multi-sensor/device synchronization- The user can select between the unmodified and the host-calculated Hardware Timestamp by toggling the
RS2_OPTION_GLOBAL_TIME_ENABLEDoption. To query which of the three alternatives is active useget_frame_timestamp_domain()function call- Returns
- the timestamp of the frame, in milliseconds according to the elaborated flow
Definition at line 474 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_frame.hpp.
References rs2::error::handle(), and rs2_get_frame_timestamp().
◆ get_timestamp() [2/2]
|
inlineinherited |
retrieve the time at which the frame was captured During the frame's lifetime it receives timestamps both at the device and host levels.
The different timestamps are gathered and managed under the frame's Metadata attributes. Chronologically the list of timestamps comprises of: SENSOR_TIMESTAMP - Device clock. For video sensors designates the middle of exposure. Requires metadata support. FRAME_TIMESTAMP - Device clock. Stamped at the beginning of frame readout and transfer. Requires metadata support. BACKEND_TIMESTAMP - Host (EPOCH) clock in Kernel space. Frame transfer from USB Controller to the USB Driver. TIME_OF_ARRIVAL - Host (EPOCH) clock in User space. Frame transfer from the USB Driver to Librealsense.
During runtime the SDK dynamically selects the most correct representaion, based on both device and host capabilities: In case the frame metadata is not configured:
- The function call provides the TIME_OF_ARRIVAL stamp. In case the metadata is available the function returns:
HW Timestamp(FRAME_TIMESTAMP), orGlobal TimestampHost-corrected derivative ofHW Timestamprequired for multi-sensor/device synchronization- The user can select between the unmodified and the host-calculated Hardware Timestamp by toggling the
RS2_OPTION_GLOBAL_TIME_ENABLEDoption. To query which of the three alternatives is active useget_frame_timestamp_domain()function call- Returns
- the timestamp of the frame, in milliseconds according to the elaborated flow
Definition at line 474 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_frame.hpp.
References rs2::error::handle(), and rs2_get_frame_timestamp().
◆ is() [1/2]
|
inlineinherited |
Template function, checking if current instance is the type of another class.
- Returns
- bool - true or false.
Definition at line 570 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_frame.hpp.
◆ is() [2/2]
|
inlineinherited |
Template function, checking if current instance is the type of another class.
- Returns
- bool - true or false.
Definition at line 570 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_frame.hpp.
◆ keep() [1/2]
|
inlineinherited |
keep the frame, otherwise if no refernce to the frame, the frame will be released.
Definition at line 437 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_frame.hpp.
References rs2_keep_frame().
◆ keep() [2/2]
|
inlineinherited |
keep the frame, otherwise if no refernce to the frame, the frame will be released.
Definition at line 437 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_frame.hpp.
References rs2_keep_frame().
Referenced by rs2::frame_queue::enqueue().
◆ operator bool() [1/2]
|
inlineinherited |
Parenthesis operator check if internal frame handle is valid.
- Returns
- bool - true or false.
Definition at line 443 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_frame.hpp.
◆ operator bool() [2/2]
|
inlineinherited |
Parenthesis operator check if internal frame handle is valid.
- Returns
- bool - true or false.
Definition at line 443 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_frame.hpp.
◆ operator rs2_frame *() [1/2]
|
inlineexplicitinherited |
Definition at line 591 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_frame.hpp.
◆ operator rs2_frame *() [2/2]
|
inlineexplicitinherited |
Definition at line 591 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_frame.hpp.
◆ reset() [1/2]
|
inlineprotectedinherited |
Definition at line 611 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_frame.hpp.
References rs2_release_frame().
◆ reset() [2/2]
|
inlineprotectedinherited |
Definition at line 611 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_frame.hpp.
References rs2_release_frame().
Referenced by rs2::depth_frame::depth_frame(), rs2::disparity_frame::disparity_frame(), rs2::frameset::frameset(), rs2::motion_frame::motion_frame(), rs2::points::points(), pose_frame(), and rs2::video_frame::video_frame().
◆ supports_frame_metadata() [1/2]
|
inlineinherited |
determine if the device allows a specific metadata to be queried
- Parameters
-
[in] frame_metadata the frame_metadata to check for support
- Returns
- true if the frame_metadata can be queried
Definition at line 509 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_frame.hpp.
References rs2::error::handle(), and rs2_supports_frame_metadata().
◆ supports_frame_metadata() [2/2]
|
inlineinherited |
determine if the device allows a specific metadata to be queried
- Parameters
-
[in] frame_metadata the frame_metadata to check for support
- Returns
- true if the frame_metadata can be queried
Definition at line 509 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_frame.hpp.
References rs2::error::handle(), and rs2_supports_frame_metadata().
◆ swap() [1/2]
|
inlineinherited |
Swap the internal frame handle with the one in parameter.
- Parameters
-
[in] frame other - another frame instance to be swaped
Definition at line 413 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_frame.hpp.
References absl::swap_internal::swap().
Referenced by rs2::frame::operator=().
◆ swap() [2/2]
|
inlineinherited |
Swap the internal frame handle with the one in parameter.
- Parameters
-
[in] frame other - another frame instance to be swaped
Definition at line 413 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_frame.hpp.
References absl::swap_internal::swap().
The documentation for this class was generated from the following file: