

Frame Transformer
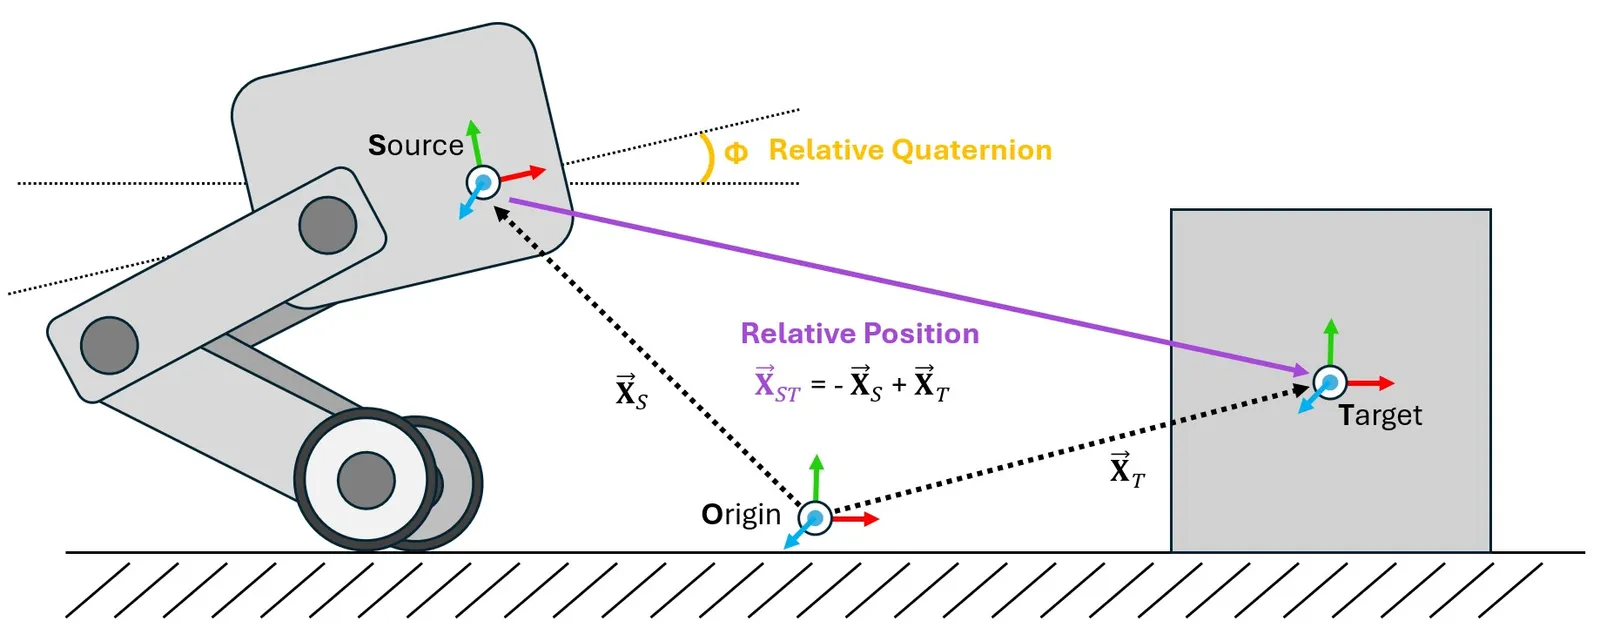
A FrameTransformer measures target poses relative to a source
frame across all environments. Use it to track a hand, foot, or object without
calculating each transform yourself.
Define frames
The sensor’s prim_path selects the source rigid body. Each
FrameCfg selects one or more target rigid bodies and can add a
fixed pose offset. Target paths accept regular expressions; the data order is recorded in
target_frame_names.
A target expression is inclusive. If it also matches the source body, the output includes the identity transform from the source to itself. Use a narrower expression when that entry is not wanted.
Read transforms
For E environments and T resolved target frames, positions have shape (E, T, 3),
quaternions have shape (E, T, 4), and combined poses have shape (E, T, 7). Quaternions use
(x, y, z, w) order.
target_*_source fields express targets in the configured source frame. target_*_w fields
express the offset target frames in the world frame. The corresponding source_*_w fields expose
the offset source frame in world coordinates. Positions are in meters; quaternions are unitless.
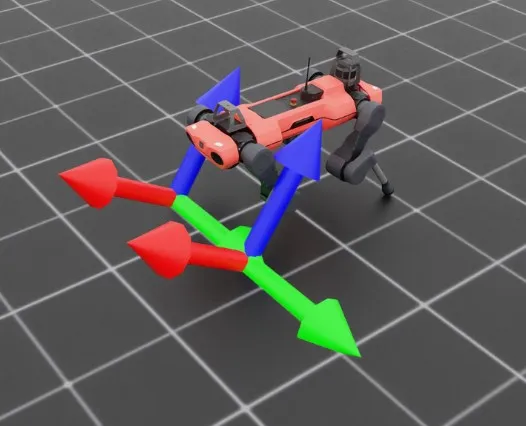
A complete runnable example is available as frame-transformer: