

Backends and Presets
An environment defines the robot, scene, sensors, and task. A backend runs the physics or rendering. A preset selects a named configuration, so you can switch backends or task modes without editing Python.
To select a physics preset, add it to your launch command:
The task stays Isaac-Cartpole-Direct. The preset changes the configuration
used to launch it.
What you can select
Tasks can expose three kinds of choices:
The asset, sensor, and scene APIs stay the same across supported backends. See Backend architecture for how Isaac Lab selects the implementation.
Physics, rendering, and visualization are separate choices. For example, a
camera environment can use Newton physics with the Newton Warp renderer, while
the visualizer is selected independently with --viz.
Find what a task supports
Check which presets a task supports with --help:
The help output groups names by physics=, renderer=, and presets=.
To list the combinations each registered environment can launch, run:
Each line lists a combination that passes configuration checks for a headless
launch; [default] marks the task default. Some combinations are incompatible:
OvPhysX and OVRTX cannot share a process with Isaac Sim / Kit, and tasks may impose
other restrictions. Use --keyword to narrow the search; checking every
combination takes a few seconds per task.
A task listed only with (defaults) uses its registered default
configuration and does not expose alternatives. Passing a name that a task does
not list is unsupported and fails during configuration validation.
Choose a selector
These are Hydra tokens, so append them without leading dashes. They work with training, playback, and environment scripts that use Isaac Lab’s task configuration launcher.
Selectors can be combined. This command chooses Newton with the MuJoCo-Warp solver, the Newton Warp renderer, and RGB observations:
Use values listed for the task. Incompatible physics, renderer, sensor, or observation settings fail configuration validation.
Common backend choices
The exact list depends on the environment, but these names follow shared conventions:
Automatic selectors such as physics=physx and renderer=rtx are opt-in.
Defaults are concrete so that running a task without selectors is predictable.
A solver is not a separate backend: newton_mjwarp and newton_kamino
both use Newton but configure different solvers.
Defaults, presets, and fine-tuning
A preset replaces the complete configuration section at its location; it does not merge fields from two alternatives. Isaac Lab resolves configuration in this order:
- Apply each preset config’s
defaultchoice. - Apply global choices from
presets=.... - Apply a preset targeted at a specific path, such as
env.sim.physics=newton_mjwarp. - Apply scalar Hydra overrides, such as
env.sim.dt=0.002.
To change one value after selecting a preset:
Use physics= and renderer= for backend choices. Use presets= for task
modes or to update several matching sections together. A path selector replaces
only the named section.
Keep behavior-changing presets the same when loading a checkpoint. An observation preset can change tensor shapes, and a policy trained with one observation mode may not load with another.
How task authors expose choices
Task authors define alternatives with PresetCfg and choose one as the default. For a multi-backend task, the preset wrapper belongs in SimulationCfg:
Keep backend-specific values inside named configurations whenever possible. This keeps task logic shared and makes every supported choice visible from the command line.
When backend selection must also change simulation-wide settings such as the
time step, a physics preset may instead contain complete SimulationCfg
alternatives. The physics= selector recognizes these bundles from their
physics field and applies the complete matching simulation configuration.
Backend architecture
Factories dispatch an object to the active backend implementation at construction time, so code can use the same public API without importing backend-specific modules directly.
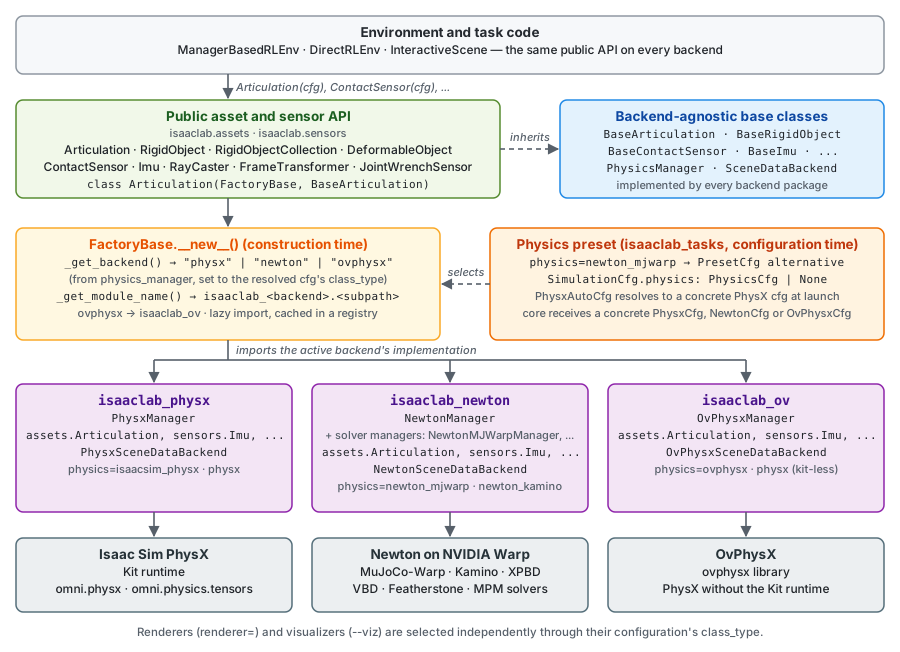
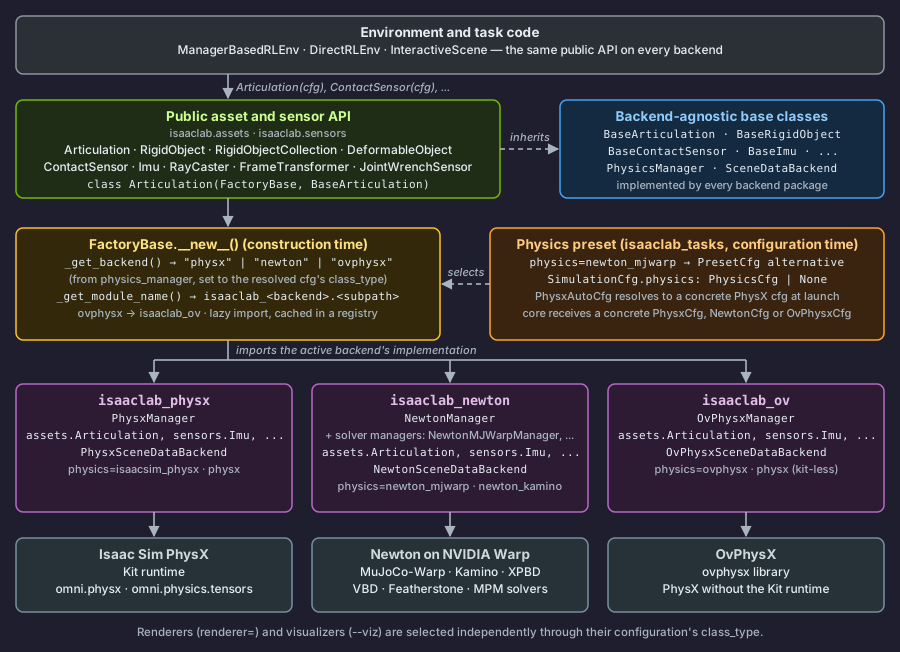
Factory dispatch
All factories inherit from FactoryBase. They select a backend key, then locate its implementation by module path:
- The name of
SimulationContext.physics_manageris mapped to one of the backend keys recognized byFactoryBase._get_backend(). Adding another physics backend requires extending this core selector. - The factory module path determines the backend module path. For example,
isaaclab.assets.articulationmaps toisaaclab_physx.assets.articulation,isaaclab_newton.assets.articulation, orisaaclab_ov.assets.articulation. The OvPhysX backend key uses the sharedisaaclab_ovintegration package. - The factory lazily imports the backend module and caches the implementation class in a registry.
Renderers and visualizers instead select their implementations through their
configuration’s class_type. Their selection is independent of physics;
renderer instances are shared through the simulation registry described below.
Physics manager lifecycle
Each backend implements PhysicsManager, the abstract
base class that owns its simulation lifecycle. Implementations initialize their
engine from a SimulationContext, update kinematics with
forward(), advance simulation with step(), reset state with reset(),
and release resources with close().
The manager exposes PhysicsEvent callbacks for
cross-backend lifecycle work. MODEL_INIT occurs during scene construction,
PHYSICS_READY after physics initialization, and STOP before native resources are replaced
or shut down.
The concrete close() implementation dispatches the STOP event.
SimulationContext keeps native resources and renderers in one registry.
get_or_create_backend(backend_cfg) reuses a resource when the configuration
and its concrete type match; otherwise it calls instantiate(backend_cfg).
BackendCfg defines resource settings and identity.
RendererCfg extends it for renderers; PhysicsCfg
selects the physics manager.
Finalize configurations before registration, then treat them and their nested values as read-only. Use a new configuration to request different settings.
close_backend(backend) closes the exact registered object after consumers
release their bindings. It does not compare configurations. Resources described
by BackendCfg must implement close(); plain construction configs hold
Python-owned data and need no teardown method. A failed close keeps the entry
for retry. During simulation teardown, physics first invalidates camera data,
then material writers, renderers, visualizers, and remaining native resources
close before the stage.
Managers and native renderers expose their borrowed resource through backend.
For example, NewtonManager.backend.model accesses the finalized native model.
Closing a renderer releases its bindings, not the shared native resource.
Exposing native handles does not replace SDP transport.
Clone contexts are registered separately as sim.clone_contexts[Context] = Context(...)
before plan dispatch. They apply the plan but do not own native runtime resources.
Newton has two resources with different lifetimes, not two interchangeable backends:
ModelBuilderholds mutable construction data. Cloning populates it and sensors declare requirements before finalization. It remains available for hard reset.NewtonBuilderCfgis a plain construction cfg, not aBackendCfg; the builder needs no nativeclose().NewtonBackendowns the finalized model and native buffers. Physics and render consumers borrow those handles. Closing it releases runtime allocations without closing the builder.
Both resources use the same registry:
Both configurations use the selected physics cfg; non-Newton physics selects a render-only
representation. SimulationContext has no backend-specific cfg fields, and consumers do not
access clone contexts. Consumers request body transforms and visual points directly through SDP.
Queries share the native resource’s BVHs but keep each consumer’s captured work separate.
Portable asset and sensor interfaces
Assets and sensors use the same layering as the factories:
- A base class in
isaaclabdefines the public contract, such asBaseArticulationorBaseContactSensor. - A factory class inherits from both FactoryBase and that base class.
- Backend packages provide the supported implementations.
Sensor data classes use the same pattern, for example
ContactSensorData(FactoryBase, BaseContactSensorData). Implementations expose
ProxyArray values through public asset and sensor
data properties. Each proxy wraps the underlying wp.array and provides
explicit .warp access to that array and cached, zero-copy .torch access
to a torch.Tensor view. Use those accessors when an API specifically
requires one representation. Passing a ProxyArray to wp.to_torch() is
supported only by a deprecated compatibility shim; new code should use
proxy_array.torch. Backend-native and internal storage may still use raw
Warp arrays. See /source/how-to/proxy_array for usage and buffer lifetime
guidance.
Portable renderer and scene-data interfaces
Rendering is selected independently from physics. Acquire implementations of the
BaseRenderer contract through
sim.get_or_create_backend(renderer_cfg). The
RenderContext coordinates their rendering lifecycle
through a filtered view of that registry, without a separate renderer cache or
renderer ownership. It validates global settings and registration timing, initializes
renderers after physics is ready, and coordinates stage preparation, scene updates,
and material writers. See
Renderers for renderer choices and usage.
Physics managers expose live simulation data through SceneDataBackend. The SceneDataProvider owned by the simulation context converts and remaps that data for backend-independent consumers:
This boundary lets renderers and visualizers consume a common Warp-native data path without knowing which physics engine owns the state. See /source/concepts/scene_data_providers for the complete data-flow model.
Native engine access boundary
The portable interfaces define the stable API boundary. Advanced code can use each engine’s native low-level data API, but those APIs intentionally keep their own ownership and synchronization semantics. See the backend guides for PhysX typed views, Newton model and state arrays, and OvPhysX tensor bindings.
Design principles
- Lazy loading: Backend modules are imported only when first instantiated, keeping startup fast and avoiding dependencies on unused backends.
- Recognized keys plus convention: Once the core selector recognizes a
backend key, module paths mirror the
isaaclab.X.Ystructure. OvPhysX maps toisaaclab_ov.X.Y; other recognized backends useisaaclab_<backend>.X.Yby default. - Independent selection: Physics backend, renderer, and visualizer are selected independently.
- Explicit data interop: Public asset and sensor data properties return
ProxyArray; its
.warpand.torchaccessors expose the required array representation without copying. - Zero runtime overhead: Selection occurs at instantiation time; it does not add dispatch logic to the simulation hot path.
Where to go next
- /source/isaaclab/environments lists environments and their supported presets.
- /source/features/hydra covers scalar overrides, preset authoring, conflict handling, and advanced configuration behavior.
- Physics Backends compares physics backend runtime requirements, runtime requirements, solver families, and intended uses.
- /source/concepts/renderers explains renderer selection and implementation details.