

Ecosystem
Isaac Lab is an open-source framework for training and testing robot-learning systems in GPU-parallel simulation. It supports reinforcement learning, imitation learning, teleoperation, and policy post-training.
Shared scene, asset, sensor, and task APIs let you use different physics engines, renderers, and learning libraries. Newton provides Warp-based simulation and CUDA graph support; OvPhysX and OvRTX provide standalone PhysX and RTX runtimes. Choose the combination your task needs. See /source/concepts/backends_and_presets for configuration and launch commands.
Modular Multi-Backend Physics and Rendering
Isaac Lab supports two physics backends, with PhysX support available through either a Kit-based Isaac Sim PhysX implementation and a standalone (Kit-less) OvPhysX implementation.
Additionally, Isaac Lab provides multiple rendering options through the Newton Tiled Camera sensor and RTX, available as a standalone library OvRTX, as well as Isaac Sim Kit-based Isaac Sim RTX.

Lightweight Warp sensor for tiled camera observations.

Kit-less RTX materials, lighting, and camera outputs.

Full RTX fidelity and camera-output coverage in Isaac Sim.
See Renderer outputs at a glance for the complete output gallery.
Physics, camera sensor rendering, and interactive visualization are separate choices. For example, Newton can use the lightweight Newton Tiled Camera Sensor or OvRTX for RTX image quality without Isaac Sim. See /source/concepts/physics_backends, /source/concepts/renderers, and https://isaac-sim.github.io/IsaacLab/release/3.0.0/source/concepts/visualization.html for current support matrices and preset commands.
Newton is included in the default installation and can run without Isaac Sim. See Installation for optional backends and renderers.
Capabilities in motion
These examples span real-to-sim reconstruction, vision-policy learning, and contact-rich material simulation. Explore the packaged demos and environment catalog for more examples.
NuRec turns real-world captures into simulation-ready scenes for policy training and evaluation. See COMPASS with NuRec .
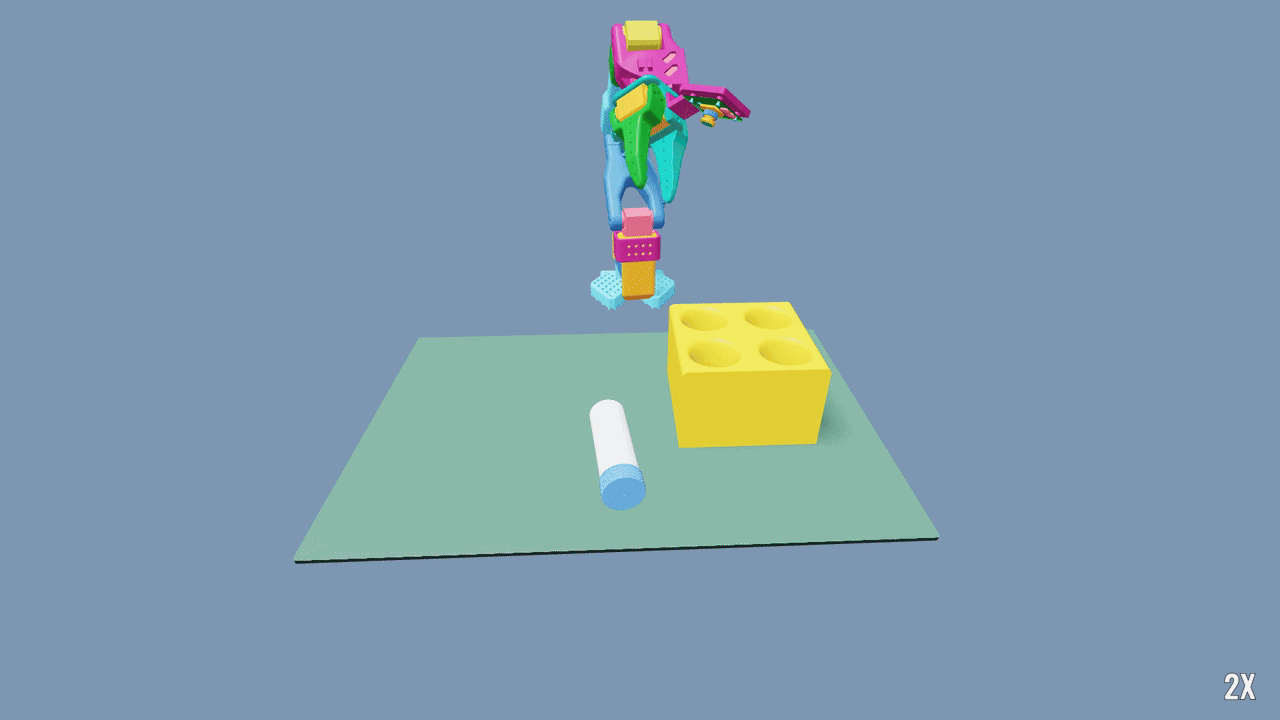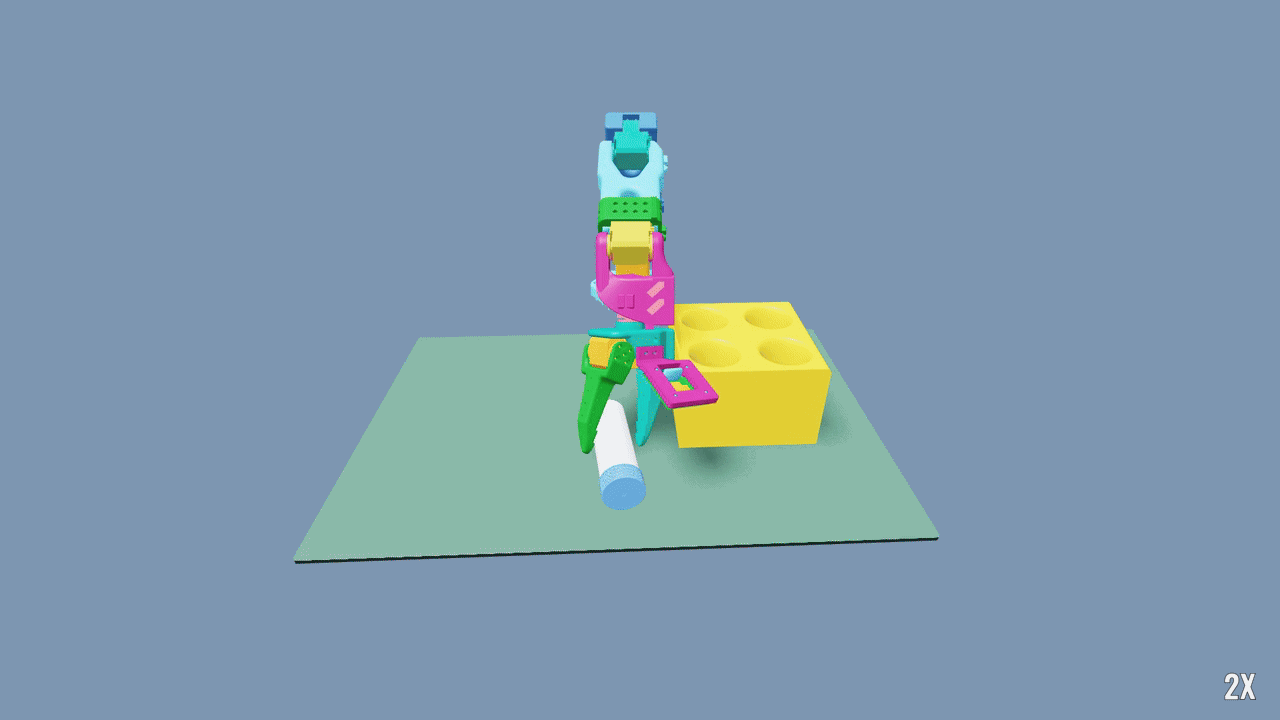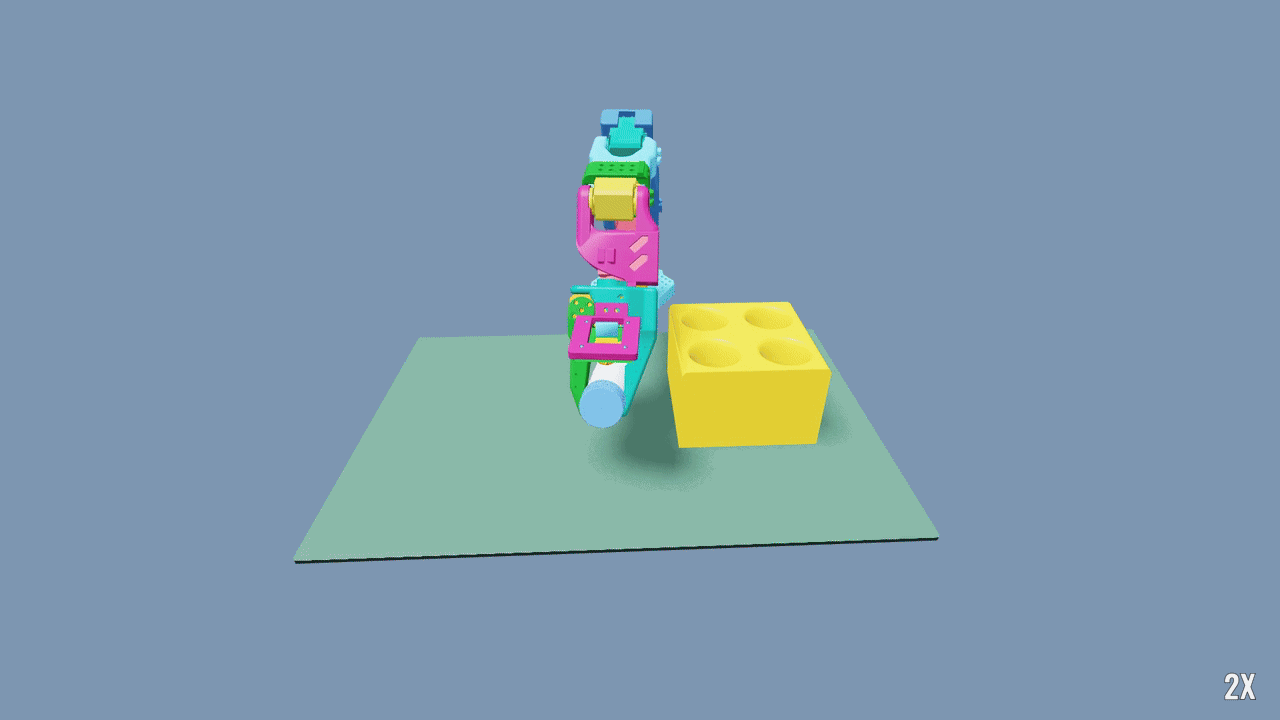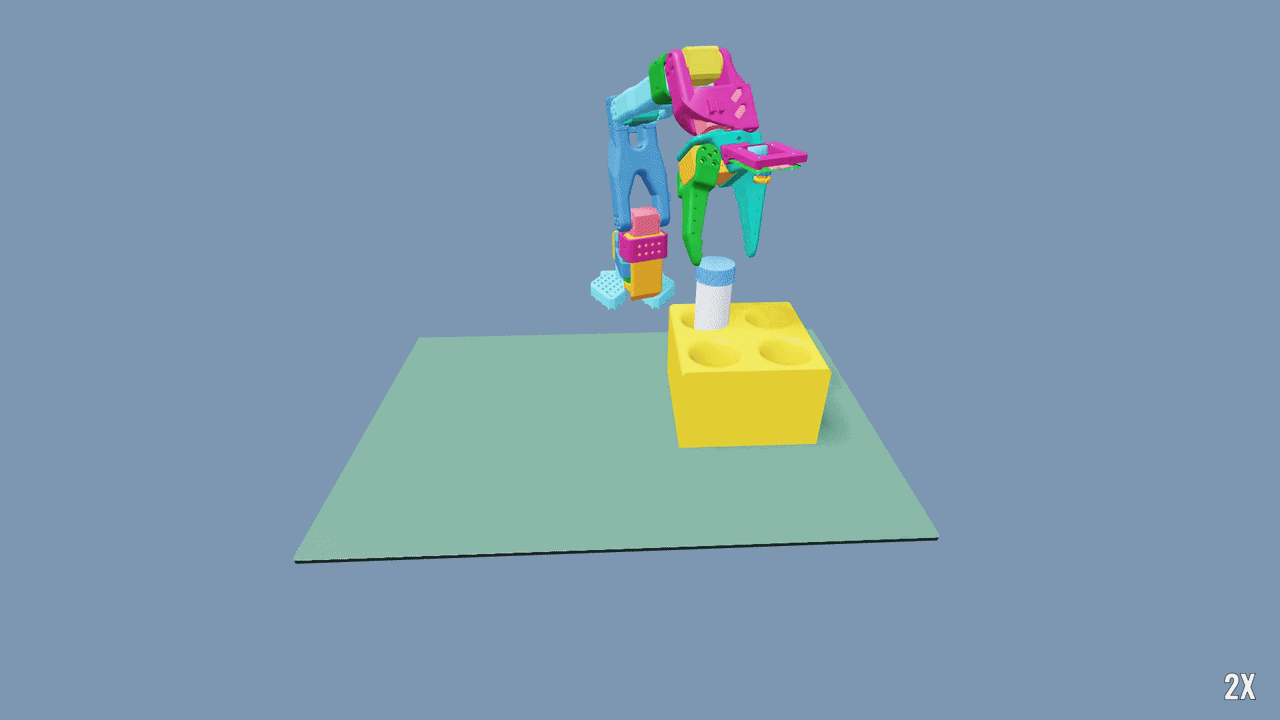
The SO-101 tutorial trains a state teacher and distills it into a wrist-camera policy for vial placement. See the SO-101 tutorial .
Is Isaac Lab a simulator?
At its core, Isaac Lab is not a robotics simulator; it is a framework for building robot learning applications on top of a simulator. An analogous example is RoboSuite, which is built on top of MuJoCo for fixed-base manipulation. Other examples include MuJoCo Playground (built on MJX) and Isaac Gym (built on PhysX).
Isaac Lab’s shared interfaces cover the Newton, Kit-based PhysX, and OvPhysX backends without requiring environment code to import backend-specific modules directly.
The framework addresses a recurring problem with standalone task implementations: because each task reimplements the observation, reward, termination, and randomization logic from scratch, large projects accumulate significant code duplication. Isaac Lab solves this with two complementary patterns:
-
Manager-based environments defer every behavioral concern to typed, composable manager objects (
ObservationManager,RewardManager,TerminationManager,EventManager,CurriculumManager,CommandManager,ActionManager,RecorderManager). Each manager is driven by small, reusable MDP term functions that live in isaaclab.envs.mdp. This makes it easy to mix and match terms across tasks and to test individual components in isolation. -
Direct environments implement
_get_observations,_get_rewards,_get_dones, and_reset_idxdirectly in a subclass, similar to the Isaac Gym style. They sacrifice some modularity for simplicity and are a natural starting point for rapid prototyping.
Both patterns expose a standard gymnasium Env interface with vectorized semantics,
so the same environment works unmodified with any of the supported RL libraries.
Configuration management uses Hydra with a preset system that allows selecting physics
backends and hyperparameter sweeps from the command line.
Why should I use Isaac Lab?
Isaac Lab provides an open-sourced platform for the community to build benchmarks and robot learning systems together. Sharing a common infrastructure lets teams reuse existing components, compare results on the same tasks, and focus on the research problems that matter rather than rebuilding simulation scaffolding from scratch.
Concretely, Isaac Lab offers:
- Two authoring patterns — manager-based for modular research and direct for rapid prototyping — with a shared InteractiveScene and sensor stack.
- Multi-backend simulation — select Newton, Kit-based PhysX or OvPhysX from the command line when the task provides the corresponding preset. Additionally, choose from Newton rendering sensor, Kit-based RTX, or OvRTX for rendering pipelines.
- Rich sensor suite — cameras, ray-casters, contact sensors, IMU, frame transformers, joint-wrench sensors, and visuo-tactile sensors.
- Imitation learning tooling —
isaaclab_mimicprovides cuRobo-based planners and a full dataset-generation pipeline for human demonstration collection. - Teleoperation and XR —
isaaclab_teleopsupports OpenXR, CloudXR, gamepads, spacemouses, and Haply devices with retargeters for manipulators and humanoids. - Hydra configuration management — hierarchical configs with command-line overrides and a preset system for multi-backend environment variants.
- RL library integrations — wrappers for RSL-RL, skrl, Stable Baselines 3, and RL Games
ship in
isaaclab_rl. Additionally, integration of RLinf provides RL post-training capabilities for fine-tuning large foundation models. - Kit-less deployment — run policies and simulations using the Newton backend without a
full Isaac Sim installation. URDF and MJCF command-line conversion can also run kit-less
when the standalone
isaacsim-asset-isolatedimporter wheel is installed.
Applications built on Isaac Lab
The framework also serves as the simulation and environment layer for higher-level applications. These projects have their own releases and installation requirements: