

Welcome to Isaac Lab!
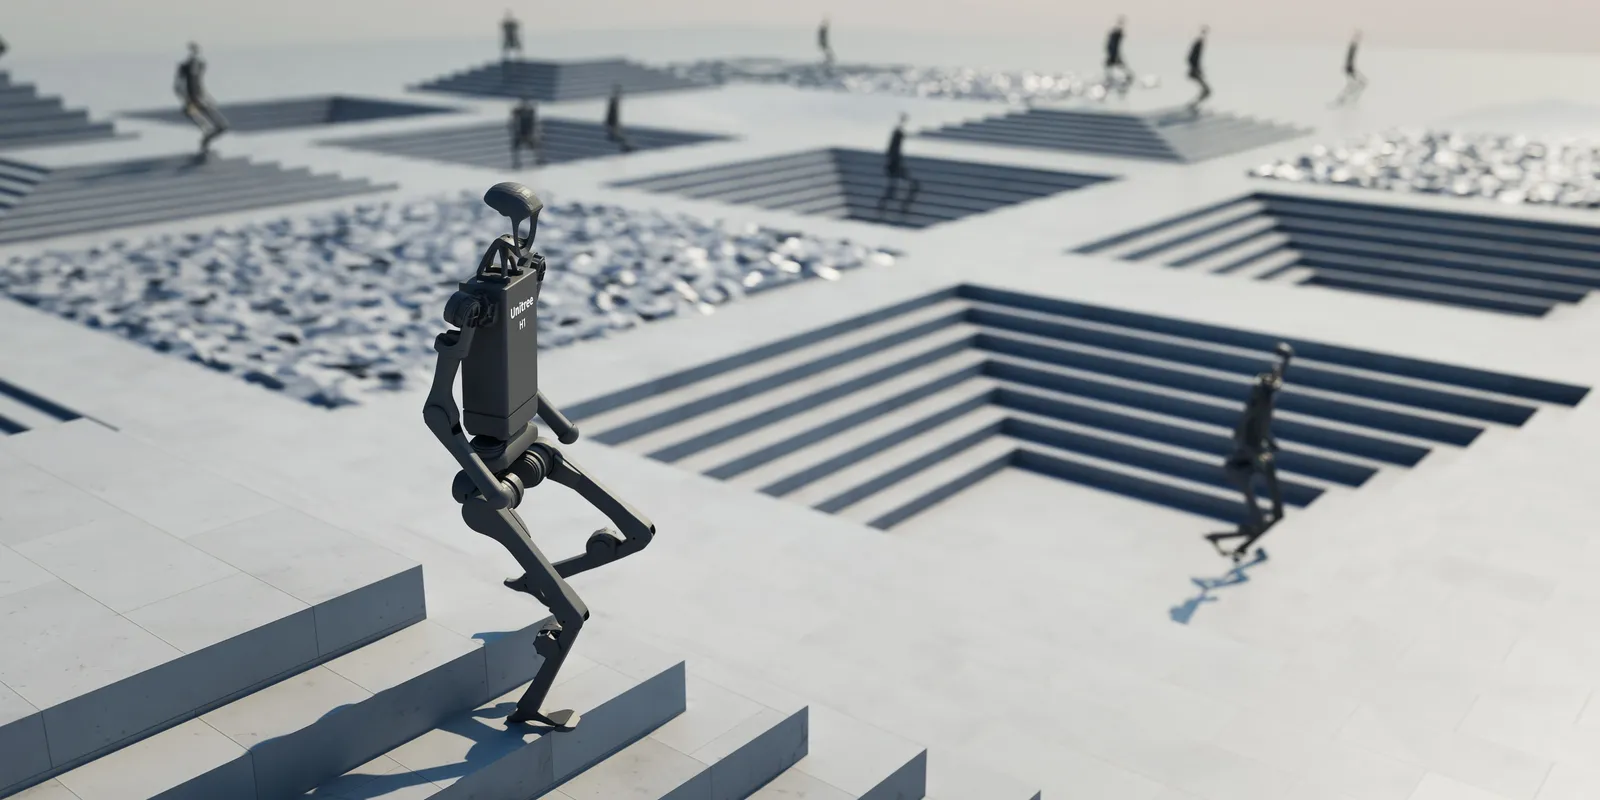
Isaac Lab is a unified and modular framework for robot learning that aims to simplify common workflows in robotics research (such as reinforcement learning, learning from demonstrations, and motion planning). It supports NVIDIA Isaac Sim for photo-realistic scenes and RTX rendering, and can also run standalone with the Newton physics backend for fast and efficient simulation without requiring a full Isaac Sim installation.
Isaac Lab 3.0 introduces a multi-backend architecture with shared asset, sensor, and scene APIs. Task presets let you select supported physics and rendering configurations, while visualization can be chosen independently.
The core objectives of the framework are:
- Modularity: Easily customize and add new environments, robots, and sensors.
- Agility: Adapt to the changing needs of the community.
- Openness: Remain open-sourced to allow the community to contribute and extend the framework.
- Batteries-included: Include a number of environments, sensors, and tasks that are ready to use.
Key features available in Isaac Lab include GPU-accelerated physics simulation with PhysX and Newton, the OvPhysX backend, vectorized camera rendering with Newton Warp and RTX renderers, domain randomization, and support for running in the cloud. Newton also supports soft bodies, cloth, and experimental cables through its VBD solver, along with experimental particle materials and coupled solvers for rigid—deformable interactions. See source/concepts/physics_backends for backend features and requirements.
Upgrading from Isaac Lab 2.x? See the Migrating To 3.0 guide for a full list of breaking changes and the new multi-backend architecture introduced in Isaac Lab 3.0.
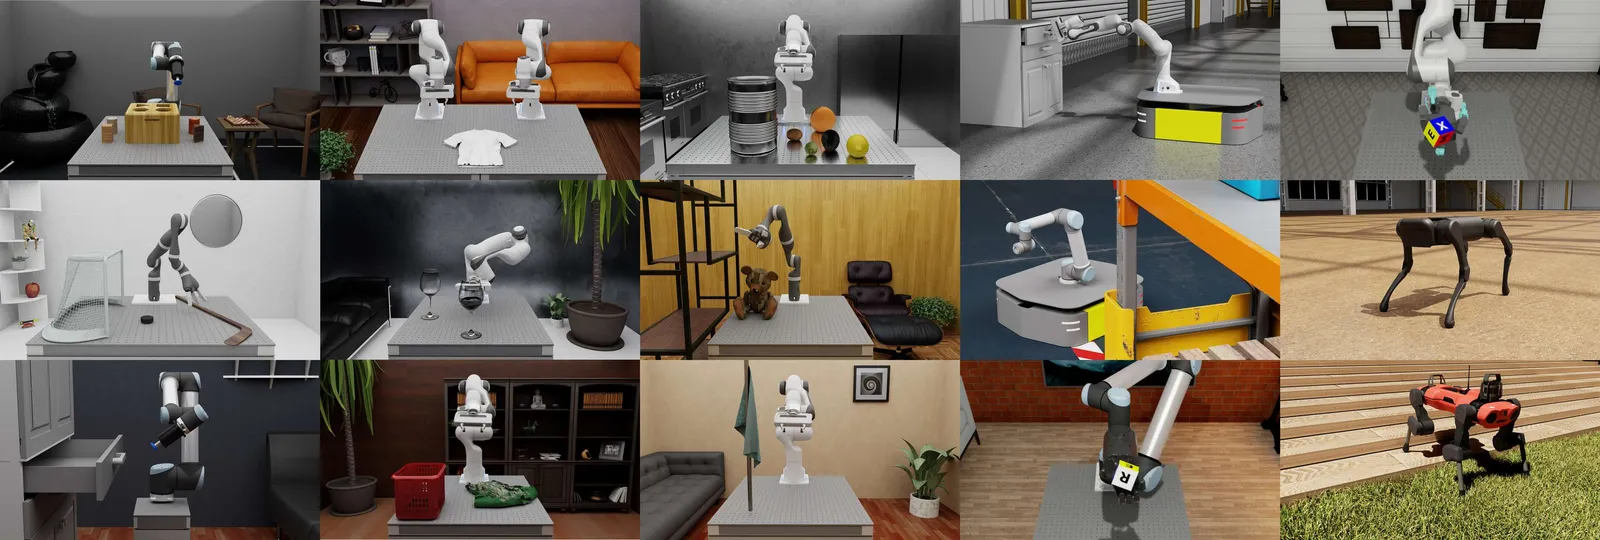
Additionally, Isaac Lab provides a variety of environments, and we are actively working on adding more environments to the list. These include classic control tasks, fixed-arm and dexterous manipulation tasks, legged locomotion tasks, and navigation tasks. Browse the registered tasks and build a command in the environment browser .
Isaac Lab is developed with specific robot assets that are now Batteries-included as part of the platform and are ready to learn! These robots include…
- Classic Cartpole, Humanoid, Ant
- Fixed-Arm and Hands: UR10, Franka, Allegro, Shadow Hand
- Quadrupeds: Anybotics AnymalB, AnymalC, AnymalD, Unitree A1, Unitree Go1, Unitree Go2, Boston Dynamics Spot
- Humanoids: Unitree H1, Unitree G1
- Quadcopter: Crazyflie
The platform is also designed so that you can add your own robots! Please refer to the How-to Guides section for details.
Working with a coding agent? Isaac Lab ships a library of agent skills for installation, environment creation, RL training, migration, and more. See source/developer-tools/agent_skills.
For more information about the framework, please refer to the technical report
mittal2025isaaclab. For clarifications on NVIDIA Isaac ecosystem, please check out the
Ecosystem section.
License
The Isaac Lab framework is open-sourced under the BSD-3-Clause license, with certain parts under Apache-2.0 license. Please refer to License for more details.
Citation
If you use Isaac Lab in your research, please cite our technical report:
Acknowledgement
Isaac Lab development initiated from the Orbit framework. We gratefully acknowledge the authors of Orbit for their foundational contributions.
Table of Contents
Indices and tables
- genindex
- modindex
- search