Detailed Description
Definition at line 324 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
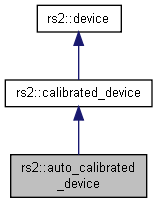
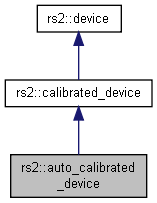
Public Member Functions | |
| auto_calibrated_device (device d) | |
| template<class T > | |
| calibration_table | run_on_chip_calibration (std::string json_content, float *health, T callback, int timeout_ms=5000) const |
| This will improve the depth noise. More... | |
| calibration_table | run_on_chip_calibration (std::string json_content, float *health, int timeout_ms=5000) const |
| This will improve the depth noise. More... | |
| template<class T > | |
| calibration_table | run_tare_calibration (float ground_truth_mm, std::string json_content, T callback, int timeout_ms=5000) const |
| This will adjust camera absolute distance to flat target. More... | |
| calibration_table | run_tare_calibration (float ground_truth_mm, std::string json_content, int timeout_ms=5000) const |
| This will adjust camera absolute distance to flat target. More... | |
| calibration_table | get_calibration_table () |
| Read current calibration table from flash. More... | |
| void | set_calibration_table (const calibration_table &calibration) |
| Set current table to dynamic area. More... | |
| void | write_calibration () const |
| Write calibration that was set by set_calibration_table to device's EEPROM. More... | |
| void | write_calibration () const |
| Write calibration that was set by set_calibration_table to device's EEPROM. More... | |
| void | reset_to_factory_calibration () |
| Reset device to factory calibration. More... | |
| void | reset_to_factory_calibration () |
| Reset device to factory calibration. More... | |
| std::vector< sensor > | query_sensors () const |
| returns the list of adjacent devices, sharing the same physical parent composite device More... | |
| std::vector< sensor > | query_sensors () const |
| returns the list of adjacent devices, sharing the same physical parent composite device More... | |
| template<class T > | |
| T | first () const |
| template<class T > | |
| T | first () const |
| bool | supports (rs2_camera_info info) const |
| check if specific camera info is supported More... | |
| bool | supports (rs2_camera_info info) const |
| check if specific camera info is supported More... | |
| const char * | get_info (rs2_camera_info info) const |
| retrieve camera specific information, like versions of various internal components More... | |
| const char * | get_info (rs2_camera_info info) const |
| retrieve camera specific information, like versions of various internal components More... | |
| void | hardware_reset () |
| send hardware reset request to the device More... | |
| void | hardware_reset () |
| send hardware reset request to the device More... | |
| operator bool () const | |
| operator bool () const | |
| const std::shared_ptr< rs2_device > & | get () const |
| const std::shared_ptr< rs2_device > & | get () const |
| template<class T > | |
| bool | is () const |
| template<class T > | |
| bool | is () const |
| template<class T > | |
| T | as () const |
| template<class T > | |
| T | as () const |
| operator std::shared_ptr< rs2_device > () | |
| operator std::shared_ptr< rs2_device > () | |
Protected Attributes | |
| std::shared_ptr< rs2_device > | _dev |
Constructor & Destructor Documentation
◆ auto_calibrated_device() [1/2]
|
inline |
Definition at line 327 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
References rs2::device::_dev, rs2::error::handle(), RS2_EXTENSION_AUTO_CALIBRATED_DEVICE, and rs2_is_device_extendable_to().
◆ auto_calibrated_device() [2/2]
|
inline |
Definition at line 327 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
References rs2::device::_dev, rs2::error::handle(), RS2_EXTENSION_AUTO_CALIBRATED_DEVICE, and rs2_is_device_extendable_to().
Member Function Documentation
◆ as() [1/2]
|
inlineinherited |
Definition at line 129 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
◆ as() [2/2]
|
inlineinherited |
Definition at line 129 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
◆ first() [1/2]
|
inlineinherited |
Definition at line 52 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
References rs2::device::query_sensors().
◆ first() [2/2]
|
inlineinherited |
Definition at line 52 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
References rs2::device::query_sensors().
◆ get() [1/2]
|
inlineinherited |
Definition at line 116 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
References rs2::device::_dev.
Referenced by rs2::device_list::contains(), rs2::device_calibration::device_calibration(), rs2::recorder::recorder(), rs2::event_information::was_added(), and rs2::event_information::was_removed().
◆ get() [2/2]
|
inlineinherited |
Definition at line 116 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
References rs2::device::_dev.
◆ get_calibration_table() [1/2]
|
inline |
Read current calibration table from flash.
- Returns
- Calibration table
Definition at line 531 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
References rs2::device::_dev, rs2::error::handle(), rs2_delete_raw_data(), rs2_get_calibration_table(), rs2_get_raw_data(), rs2_get_raw_data_size(), pydeepstreamdoc::tensor::TensorDoc::size, and pydeepstreamdoc::osd::ArrowHeadDoc::start.
◆ get_calibration_table() [2/2]
|
inline |
Read current calibration table from flash.
- Returns
- Calibration table
Definition at line 531 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
References rs2::device::_dev, rs2::error::handle(), rs2_delete_raw_data(), rs2_get_calibration_table(), rs2_get_raw_data(), rs2_get_raw_data_size(), pydeepstreamdoc::tensor::TensorDoc::size, and pydeepstreamdoc::osd::ArrowHeadDoc::start.
◆ get_info() [1/2]
|
inlineinherited |
retrieve camera specific information, like versions of various internal components
- Parameters
-
[in] info camera info type to retrieve
- Returns
- the requested camera info string, in a format specific to the device model
Definition at line 79 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
References rs2::device::_dev, rs2::error::handle(), and rs2_get_device_info().
◆ get_info() [2/2]
|
inlineinherited |
retrieve camera specific information, like versions of various internal components
- Parameters
-
[in] info camera info type to retrieve
- Returns
- the requested camera info string, in a format specific to the device model
Definition at line 79 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
References rs2::device::_dev, rs2::error::handle(), and rs2_get_device_info().
◆ hardware_reset() [1/2]
|
inlineinherited |
send hardware reset request to the device
Definition at line 90 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
References rs2::device::_dev, rs2::error::handle(), and rs2_hardware_reset().
◆ hardware_reset() [2/2]
|
inlineinherited |
send hardware reset request to the device
Definition at line 90 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
References rs2::device::_dev, rs2::error::handle(), and rs2_hardware_reset().
◆ is() [1/2]
|
inlineinherited |
Definition at line 122 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
◆ is() [2/2]
|
inlineinherited |
Definition at line 122 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
◆ operator bool() [1/2]
|
inlineinherited |
Definition at line 112 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
References rs2::device::_dev.
◆ operator bool() [2/2]
|
inlineinherited |
Definition at line 112 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
References rs2::device::_dev.
◆ operator std::shared_ptr< rs2_device >() [1/2]
|
inlineexplicitinherited |
Definition at line 138 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
References rs2::device::_dev.
◆ operator std::shared_ptr< rs2_device >() [2/2]
|
inlineexplicitinherited |
Definition at line 138 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
References rs2::device::_dev.
◆ query_sensors() [1/2]
|
inlineinherited |
returns the list of adjacent devices, sharing the same physical parent composite device
- Returns
- the list of adjacent devices
Definition at line 25 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
References rs2::device::_dev, rs2::error::handle(), rs2_create_sensor(), rs2_delete_sensor(), rs2_delete_sensor_list(), rs2_get_sensors_count(), rs2_query_sensors(), and pydeepstreamdoc::tensor::TensorDoc::size.
Referenced by rs2::device::first().
◆ query_sensors() [2/2]
|
inlineinherited |
returns the list of adjacent devices, sharing the same physical parent composite device
- Returns
- the list of adjacent devices
Definition at line 25 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
References rs2::device::_dev, rs2::error::handle(), rs2_create_sensor(), rs2_delete_sensor(), rs2_delete_sensor_list(), rs2_get_sensors_count(), rs2_query_sensors(), and pydeepstreamdoc::tensor::TensorDoc::size.
◆ reset_to_factory_calibration() [1/2]
|
inlineinherited |
Reset device to factory calibration.
Definition at line 316 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
References rs2::device::_dev, rs2::error::handle(), and rs2_reset_to_factory_calibration().
◆ reset_to_factory_calibration() [2/2]
|
inlineinherited |
Reset device to factory calibration.
Definition at line 316 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
References rs2::device::_dev, rs2::error::handle(), and rs2_reset_to_factory_calibration().
◆ run_on_chip_calibration() [1/4]
|
inline |
This will improve the depth noise.
- Parameters
-
[in] json_content Json string to configure regular speed on chip calibration parameters: { "focal length" : 0, "speed": 3, "scan parameter": 0, "adjust both sides": 0, "white wall mode": 0 } focal_length - calibraton type: 0 = regular, 1 = focal length, 2 = both regular and focal length in order speed - for regular calibration. value can be one of: Very fast = 0, Fast = 1, Medium = 2, Slow = 3, White wall = 4, default is Slow for type 0 and Fast for type 2 scan_parameter - for regular calibration. value can be one of: Py scan (default) = 0, Rx scan = 1 adjust_both_sides - for focal length calibration. value can be one of: 0 = adjust right only, 1 = adjust both sides white_wall_mode - white wall mode: 0 for normal mode and 1 for white wall mode if json is nullptr it will be ignored and calibration will use the default parameters [out] health The absolute value of regular calibration Health-Check captures how far camera calibration is from the optimal one [0, 0.25) - Good [0.25, 0.75) - Can be Improved [0.75, ) - Requires Calibration The absolute value of focal length calibration Health-Check captures how far camera calibration is from the optimal one [0, 0.15) - Good [0.15, 0.75) - Can be Improved [0.75, ) - Requires Calibration The two health numbers are encoded in one integer as follows for calib_type 2: Regular health number times 1000 are bits 0 to 11 Regular health number is negative if bit 24 is 1 Focal length health number times 1000 are bits 12 to 23 Focal length health number is negative if bit 25 is 1 [in] timeout_ms Timeout in ms
- Returns
- New calibration table
Definition at line 424 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
References rs2::device::_dev, rs2::error::handle(), rs2_delete_raw_data(), rs2_get_raw_data(), rs2_get_raw_data_size(), rs2_run_on_chip_calibration_cpp(), pydeepstreamdoc::tensor::TensorDoc::size, and pydeepstreamdoc::osd::ArrowHeadDoc::start.
◆ run_on_chip_calibration() [2/4]
|
inline |
This will improve the depth noise.
- Parameters
-
[in] json_content Json string to configure regular speed on chip calibration parameters: { "focal length" : 0, "speed": 3, "scan parameter": 0, "adjust both sides": 0, "white wall mode": 0 } focal_length - calibraton type: 0 = regular, 1 = focal length, 2 = both regular and focal length in order speed - for regular calibration. value can be one of: Very fast = 0, Fast = 1, Medium = 2, Slow = 3, White wall = 4, default is Slow for type 0 and Fast for type 2 scan_parameter - for regular calibration. value can be one of: Py scan (default) = 0, Rx scan = 1 adjust_both_sides - for focal length calibration. value can be one of: 0 = adjust right only, 1 = adjust both sides white_wall_mode - white wall mode: 0 for normal mode and 1 for white wall mode if json is nullptr it will be ignored and calibration will use the default parameters [out] health The absolute value of regular calibration Health-Check captures how far camera calibration is from the optimal one [0, 0.25) - Good [0.25, 0.75) - Can be Improved [0.75, ) - Requires Calibration The absolute value of focal length calibration Health-Check captures how far camera calibration is from the optimal one [0, 0.15) - Good [0.15, 0.75) - Can be Improved [0.75, ) - Requires Calibration The two health numbers are encoded in one integer as follows for calib_type 2: Regular health number times 1000 are bits 0 to 11 Regular health number is negative if bit 24 is 1 Focal length health number times 1000 are bits 12 to 23 Focal length health number is negative if bit 25 is 1 [in] timeout_ms Timeout in ms
- Returns
- New calibration table
Definition at line 424 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
References rs2::device::_dev, rs2::error::handle(), rs2_delete_raw_data(), rs2_get_raw_data(), rs2_get_raw_data_size(), rs2_run_on_chip_calibration_cpp(), pydeepstreamdoc::tensor::TensorDoc::size, and pydeepstreamdoc::osd::ArrowHeadDoc::start.
◆ run_on_chip_calibration() [3/4]
|
inline |
This will improve the depth noise.
- Parameters
-
[in] json_content Json string to configure regular speed on chip calibration parameters: { "calib type" : 0, "speed": 3, "scan parameter": 0, "adjust both sides": 0, "white wall mode": 0 } calib_type - calibraton type: 0 = regular, 1 = focal length, 2 = both regular and focal length in order speed - for regular calibration. value can be one of: Very fast = 0, Fast = 1, Medium = 2, Slow = 3, White wall = 4, default is Slow for type 0 and Fast for type 2 scan_parameter - for regular calibration. value can be one of: Py scan (default) = 0, Rx scan = 1 adjust_both_sides - for focal length calibration. value can be one of: 0 = adjust right only, 1 = adjust both sides white_wall_mode - white wall mode: 0 for normal mode and 1 for white wall mode if json is nullptr it will be ignored and calibration will use the default parameters [out] health The absolute value of regular calibration Health-Check captures how far camera calibration is from the optimal one [0, 0.25) - Good [0.25, 0.75) - Can be Improved [0.75, ) - Requires Calibration The absolute value of focal length calibration Health-Check captures how far camera calibration is from the optimal one [0, 0.15) - Good [0.15, 0.75) - Can be Improved [0.75, ) - Requires Calibration The two health numbers are encoded in one integer as follows for calib_type 2: Regular health number times 1000 are bits 0 to 11 Regular health number is negative if bit 24 is 1 Focal length health number times 1000 are bits 12 to 23 Focal length health number is negative if bit 25 is 1 [in] callback Optional callback to get progress notifications [in] timeout_ms Timeout in ms
- Returns
- New calibration table
Definition at line 372 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
References rs2::device::_dev, rs2::error::handle(), absl::move(), rs2_delete_raw_data(), rs2_get_raw_data(), rs2_get_raw_data_size(), rs2_run_on_chip_calibration_cpp(), pydeepstreamdoc::tensor::TensorDoc::size, and pydeepstreamdoc::osd::ArrowHeadDoc::start.
◆ run_on_chip_calibration() [4/4]
|
inline |
This will improve the depth noise.
- Parameters
-
[in] json_content Json string to configure regular speed on chip calibration parameters: { "calib type" : 0, "speed": 3, "scan parameter": 0, "adjust both sides": 0, "white wall mode": 0 } calib_type - calibraton type: 0 = regular, 1 = focal length, 2 = both regular and focal length in order speed - for regular calibration. value can be one of: Very fast = 0, Fast = 1, Medium = 2, Slow = 3, White wall = 4, default is Slow for type 0 and Fast for type 2 scan_parameter - for regular calibration. value can be one of: Py scan (default) = 0, Rx scan = 1 adjust_both_sides - for focal length calibration. value can be one of: 0 = adjust right only, 1 = adjust both sides white_wall_mode - white wall mode: 0 for normal mode and 1 for white wall mode if json is nullptr it will be ignored and calibration will use the default parameters [out] health The absolute value of regular calibration Health-Check captures how far camera calibration is from the optimal one [0, 0.25) - Good [0.25, 0.75) - Can be Improved [0.75, ) - Requires Calibration The absolute value of focal length calibration Health-Check captures how far camera calibration is from the optimal one [0, 0.15) - Good [0.15, 0.75) - Can be Improved [0.75, ) - Requires Calibration The two health numbers are encoded in one integer as follows for calib_type 2: Regular health number times 1000 are bits 0 to 11 Regular health number is negative if bit 24 is 1 Focal length health number times 1000 are bits 12 to 23 Focal length health number is negative if bit 25 is 1 [in] callback Optional callback to get progress notifications [in] timeout_ms Timeout in ms
- Returns
- New calibration table
Definition at line 372 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
References rs2::device::_dev, rs2::error::handle(), absl::move(), rs2_delete_raw_data(), rs2_get_raw_data(), rs2_get_raw_data_size(), rs2_run_on_chip_calibration_cpp(), pydeepstreamdoc::tensor::TensorDoc::size, and pydeepstreamdoc::osd::ArrowHeadDoc::start.
◆ run_tare_calibration() [1/4]
|
inline |
This will adjust camera absolute distance to flat target.
User needs to enter the known ground truth.
- Parameters
-
[in] ground_truth_mm Ground truth in mm must be between 60 and 10000 [in] json_content Json string to configure tare calibration parameters: { "average step count": 20, "step count": 20, "accuracy": 2, "scan parameter": 0, "data sampling": 0 } average step count - number of frames to average, must be between 1 - 30, default = 20 step count - max iteration steps, must be between 5 - 30, default = 10 accuracy - Subpixel accuracy level, value can be one of: Very high = 0 (0.025%), High = 1 (0.05%), Medium = 2 (0.1%), Low = 3 (0.2%), Default = Very high (0.025%), default is very high (0.025%) scan_parameter - value can be one of: Py scan (default) = 0, Rx scan = 1 data_sampling - value can be one of:polling data sampling = 0, interrupt data sampling = 1 if json is nullptr it will be ignored and calibration will use the default parameters [in] content_size Json string size if its 0 the json will be ignored and calibration will use the default parameters [in] timeout_ms Timeout in ms
- Returns
- New calibration table
Definition at line 507 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
References rs2::device::_dev, rs2::error::handle(), rs2_delete_raw_data(), rs2_get_raw_data(), rs2_get_raw_data_size(), rs2_run_tare_calibration_cpp(), pydeepstreamdoc::tensor::TensorDoc::size, and pydeepstreamdoc::osd::ArrowHeadDoc::start.
◆ run_tare_calibration() [2/4]
|
inline |
This will adjust camera absolute distance to flat target.
User needs to enter the known ground truth.
- Parameters
-
[in] ground_truth_mm Ground truth in mm must be between 60 and 10000 [in] json_content Json string to configure tare calibration parameters: { "average step count": 20, "step count": 20, "accuracy": 2, "scan parameter": 0, "data sampling": 0 } average step count - number of frames to average, must be between 1 - 30, default = 20 step count - max iteration steps, must be between 5 - 30, default = 10 accuracy - Subpixel accuracy level, value can be one of: Very high = 0 (0.025%), High = 1 (0.05%), Medium = 2 (0.1%), Low = 3 (0.2%), Default = Very high (0.025%), default is very high (0.025%) scan_parameter - value can be one of: Py scan (default) = 0, Rx scan = 1 data_sampling - value can be one of:polling data sampling = 0, interrupt data sampling = 1 if json is nullptr it will be ignored and calibration will use the default parameters [in] content_size Json string size if its 0 the json will be ignored and calibration will use the default parameters [in] timeout_ms Timeout in ms
- Returns
- New calibration table
Definition at line 507 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
References rs2::device::_dev, rs2::error::handle(), rs2_delete_raw_data(), rs2_get_raw_data(), rs2_get_raw_data_size(), rs2_run_tare_calibration_cpp(), pydeepstreamdoc::tensor::TensorDoc::size, and pydeepstreamdoc::osd::ArrowHeadDoc::start.
◆ run_tare_calibration() [3/4]
|
inline |
This will adjust camera absolute distance to flat target.
User needs to enter the known ground truth.
- Parameters
-
[in] ground_truth_mm Ground truth in mm must be between 60 and 10000 [in] json_content Json string to configure tare calibration parameters: { "average step count": 20, "step count": 20, "accuracy": 2, "scan parameter": 0, "data sampling": 0 } average step count - number of frames to average, must be between 1 - 30, default = 20 step count - max iteration steps, must be between 5 - 30, default = 10 accuracy - Subpixel accuracy level, value can be one of: Very high = 0 (0.025%), High = 1 (0.05%), Medium = 2 (0.1%), Low = 3 (0.2%), Default = Very high (0.025%), default is very high (0.025%) scan_parameter - value can be one of: Py scan (default) = 0, Rx scan = 1 data_sampling - value can be one of:polling data sampling = 0, interrupt data sampling = 1 if json is nullptr it will be ignored and calibration will use the default parameters [in] content_size Json string size if its 0 the json will be ignored and calibration will use the default parameters [in] callback Optional callback to get progress notifications [in] timeout_ms Timeout in ms
- Returns
- New calibration table
Definition at line 466 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
References rs2::device::_dev, rs2::error::handle(), absl::move(), rs2_delete_raw_data(), rs2_get_raw_data(), rs2_get_raw_data_size(), rs2_run_tare_calibration_cpp(), pydeepstreamdoc::tensor::TensorDoc::size, and pydeepstreamdoc::osd::ArrowHeadDoc::start.
◆ run_tare_calibration() [4/4]
|
inline |
This will adjust camera absolute distance to flat target.
User needs to enter the known ground truth.
- Parameters
-
[in] ground_truth_mm Ground truth in mm must be between 60 and 10000 [in] json_content Json string to configure tare calibration parameters: { "average step count": 20, "step count": 20, "accuracy": 2, "scan parameter": 0, "data sampling": 0 } average step count - number of frames to average, must be between 1 - 30, default = 20 step count - max iteration steps, must be between 5 - 30, default = 10 accuracy - Subpixel accuracy level, value can be one of: Very high = 0 (0.025%), High = 1 (0.05%), Medium = 2 (0.1%), Low = 3 (0.2%), Default = Very high (0.025%), default is very high (0.025%) scan_parameter - value can be one of: Py scan (default) = 0, Rx scan = 1 data_sampling - value can be one of:polling data sampling = 0, interrupt data sampling = 1 if json is nullptr it will be ignored and calibration will use the default parameters [in] content_size Json string size if its 0 the json will be ignored and calibration will use the default parameters [in] callback Optional callback to get progress notifications [in] timeout_ms Timeout in ms
- Returns
- New calibration table
Definition at line 466 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
References rs2::device::_dev, rs2::error::handle(), absl::move(), rs2_delete_raw_data(), rs2_get_raw_data(), rs2_get_raw_data_size(), rs2_run_tare_calibration_cpp(), pydeepstreamdoc::tensor::TensorDoc::size, and pydeepstreamdoc::osd::ArrowHeadDoc::start.
◆ set_calibration_table() [1/2]
|
inline |
Set current table to dynamic area.
- Parameters
-
[in] Calibration table
Definition at line 555 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
References rs2::device::_dev, rs2::error::handle(), and rs2_set_calibration_table().
◆ set_calibration_table() [2/2]
|
inline |
Set current table to dynamic area.
- Parameters
-
[in] Calibration table
Definition at line 555 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
References rs2::device::_dev, rs2::error::handle(), and rs2_set_calibration_table().
◆ supports() [1/2]
|
inlineinherited |
check if specific camera info is supported
- Parameters
-
[in] info the parameter to check for support
- Returns
- true if the parameter both exist and well-defined for the specific device
Definition at line 66 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
References rs2::device::_dev, rs2::error::handle(), and rs2_supports_device_info().
◆ supports() [2/2]
|
inlineinherited |
check if specific camera info is supported
- Parameters
-
[in] info the parameter to check for support
- Returns
- true if the parameter both exist and well-defined for the specific device
Definition at line 66 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
References rs2::device::_dev, rs2::error::handle(), and rs2_supports_device_info().
◆ write_calibration() [1/2]
|
inlineinherited |
Write calibration that was set by set_calibration_table to device's EEPROM.
Definition at line 306 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
References rs2::device::_dev, rs2::error::handle(), and rs2_write_calibration().
◆ write_calibration() [2/2]
|
inlineinherited |
Write calibration that was set by set_calibration_table to device's EEPROM.
Definition at line 306 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
References rs2::device::_dev, rs2::error::handle(), and rs2_write_calibration().
Field Documentation
◆ _dev
|
protectedinherited |
Definition at line 146 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
Referenced by rs2::software_device::add_sensor(), rs2::software_device::add_to(), rs400::advanced_mode::advanced_mode(), auto_calibrated_device(), rs2::calibration_change_device::calibration_change_device(), rs2::updatable::check_firmware_compatibility(), rs2::tm2::connect_controller(), rs2::updatable::create_flash_backup(), rs2::software_device::create_matcher(), rs2::firmware_logger::create_message(), rs2::firmware_logger::create_parsed_message(), rs2::playback::current_status(), rs2::debug_protocol::debug_protocol(), rs2::device_calibration::device_calibration(), rs2::tm2::disable_loopback(), rs2::tm2::disconnect_controller(), rs2::tm2::enable_loopback(), rs2::updatable::enter_update_state(), rs2::recorder::filename(), rs2::firmware_logger::firmware_logger(), rs2::device::get(), rs400::advanced_mode::get_ae_control(), rs400::advanced_mode::get_amp_factor(), get_calibration_table(), rs400::advanced_mode::get_census(), rs400::advanced_mode::get_color_control(), rs400::advanced_mode::get_color_correction(), rs400::advanced_mode::get_depth_control(), rs400::advanced_mode::get_depth_table(), rs2::playback::get_duration(), rs2::firmware_logger::get_firmware_log(), rs2::firmware_logger::get_flash_log(), rs400::advanced_mode::get_hdad(), rs2::device::get_info(), rs2::firmware_logger::get_number_of_fw_logs(), rs2::playback::get_position(), rs400::advanced_mode::get_rau_support_vector_control(), rs400::advanced_mode::get_rau_thresholds_control(), rs400::advanced_mode::get_rsm(), rs400::advanced_mode::get_slo_color_thresholds_control(), rs400::advanced_mode::get_slo_penalty_control(), rs2::device::hardware_reset(), rs2::firmware_logger::init_parser(), rs2::device_hub::is_connected(), rs400::advanced_mode::is_enabled(), rs2::tm2::is_loopback_enabled(), rs2::playback::is_real_time(), rs2::serializable_device::load_json(), rs2::device::operator bool(), rs2::device::operator std::shared_ptr< rs2_device >(), rs2::device::operator=(), rs2::firmware_logger::parse_log(), rs2::playback::pause(), rs2::recorder::pause(), rs2::playback::playback(), rs2::device::query_sensors(), rs2::recorder::recorder(), rs2::calibration_change_device::register_calibration_change_callback(), rs2::software_device::register_info(), rs2::calibrated_device::reset_to_factory_calibration(), rs2::playback::resume(), rs2::recorder::resume(), run_on_chip_calibration(), run_tare_calibration(), rs2::playback::seek(), rs2::debug_protocol::send_and_receive_raw_data(), rs2::serializable_device::serializable_device(), rs2::serializable_device::serialize_json(), rs400::advanced_mode::set_ae_control(), rs400::advanced_mode::set_amp_factor(), set_calibration_table(), rs400::advanced_mode::set_census(), rs400::advanced_mode::set_color_control(), rs400::advanced_mode::set_color_correction(), rs400::advanced_mode::set_depth_control(), rs400::advanced_mode::set_depth_table(), rs2::software_device::set_destruction_callback(), rs400::advanced_mode::set_hdad(), rs2::playback::set_playback_speed(), rs400::advanced_mode::set_rau_support_vector_control(), rs400::advanced_mode::set_rau_thresholds_control(), rs2::playback::set_real_time(), rs400::advanced_mode::set_rsm(), rs400::advanced_mode::set_slo_color_thresholds_control(), rs400::advanced_mode::set_slo_penalty_control(), rs2::playback::set_status_changed_callback(), rs2::playback::stop(), rs2::device::supports(), rs2::tm2::tm2(), rs400::advanced_mode::toggle_advanced_mode(), rs2::device_calibration::trigger_device_calibration(), rs2::updatable::updatable(), rs2::update_device::update(), rs2::update_device::update_device(), rs2::software_device::update_info(), rs2::updatable::update_unsigned(), and rs2::calibrated_device::write_calibration().
The documentation for this class was generated from the following file: