Detailed Description
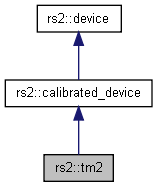
The tm2 class is an interface for T2XX devices, such as T265.
For T265, it provides RS2_STREAM_FISHEYE (2), RS2_STREAM_GYRO, RS2_STREAM_ACCEL, and RS2_STREAM_POSE streams, and contains the following sensors:
- pose_sensor: map and relocalization functions.
- wheel_odometer: input for odometry data.
Definition at line 796 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
Public Member Functions | |
| tm2 (device d) | |
| void | enable_loopback (const std::string &from_file) |
| Enter the given device into loopback operation mode that uses the given file as input for raw data. More... | |
| void | disable_loopback () |
| Restores the given device into normal operation mode. More... | |
| bool | is_loopback_enabled () const |
| Checks if the device is in loopback mode or not. More... | |
| void | connect_controller (const std::array< uint8_t, 6 > &mac_addr) |
| Connects to a given tm2 controller. More... | |
| void | disconnect_controller (int id) |
| Disconnects a given tm2 controller. More... | |
| void | set_intrinsics (int fisheye_sensor_id, const rs2_intrinsics &intrinsics) |
| Set tm2 camera intrinsics. More... | |
| void | set_extrinsics (rs2_stream from_stream, int from_id, rs2_stream to_stream, int to_id, rs2_extrinsics &extrinsics) |
| Set tm2 camera extrinsics. More... | |
| void | set_motion_device_intrinsics (rs2_stream stream_type, const rs2_motion_device_intrinsic &motion_intriniscs) |
| Set tm2 motion device intrinsics. More... | |
| void | write_calibration () const |
| Write calibration that was set by set_calibration_table to device's EEPROM. More... | |
| void | write_calibration () const |
| Write calibration that was set by set_calibration_table to device's EEPROM. More... | |
| void | reset_to_factory_calibration () |
| Reset device to factory calibration. More... | |
| void | reset_to_factory_calibration () |
| Reset device to factory calibration. More... | |
| std::vector< sensor > | query_sensors () const |
| returns the list of adjacent devices, sharing the same physical parent composite device More... | |
| std::vector< sensor > | query_sensors () const |
| returns the list of adjacent devices, sharing the same physical parent composite device More... | |
| template<class T > | |
| T | first () const |
| template<class T > | |
| T | first () const |
| bool | supports (rs2_camera_info info) const |
| check if specific camera info is supported More... | |
| bool | supports (rs2_camera_info info) const |
| check if specific camera info is supported More... | |
| const char * | get_info (rs2_camera_info info) const |
| retrieve camera specific information, like versions of various internal components More... | |
| const char * | get_info (rs2_camera_info info) const |
| retrieve camera specific information, like versions of various internal components More... | |
| void | hardware_reset () |
| send hardware reset request to the device More... | |
| void | hardware_reset () |
| send hardware reset request to the device More... | |
| operator bool () const | |
| operator bool () const | |
| const std::shared_ptr< rs2_device > & | get () const |
| const std::shared_ptr< rs2_device > & | get () const |
| template<class T > | |
| bool | is () const |
| template<class T > | |
| bool | is () const |
| template<class T > | |
| T | as () const |
| template<class T > | |
| T | as () const |
| operator std::shared_ptr< rs2_device > () | |
| operator std::shared_ptr< rs2_device > () | |
Protected Attributes | |
| std::shared_ptr< rs2_device > | _dev |
Constructor & Destructor Documentation
◆ tm2() [1/2]
|
inline |
Definition at line 799 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
References rs2::device::_dev, rs2::error::handle(), RS2_EXTENSION_TM2, and rs2_is_device_extendable_to().
◆ tm2() [2/2]
|
inline |
Definition at line 799 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
References rs2::device::_dev, rs2::error::handle(), RS2_EXTENSION_TM2, and rs2_is_device_extendable_to().
Member Function Documentation
◆ as() [1/2]
|
inlineinherited |
Definition at line 129 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
◆ as() [2/2]
|
inlineinherited |
Definition at line 129 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
◆ connect_controller() [1/2]
|
inline |
Connects to a given tm2 controller.
- Parameters
-
[in] mac_addr The MAC address of the desired controller
Definition at line 847 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
References rs2::device::_dev, rs2::error::handle(), and rs2_connect_tm2_controller().
◆ connect_controller() [2/2]
|
inline |
Connects to a given tm2 controller.
- Parameters
-
[in] mac_addr The MAC address of the desired controller
Definition at line 847 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
References rs2::device::_dev, rs2::error::handle(), and rs2_connect_tm2_controller().
◆ disable_loopback() [1/2]
|
inline |
Restores the given device into normal operation mode.
Definition at line 824 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
References rs2::device::_dev, rs2::error::handle(), and rs2_loopback_disable().
◆ disable_loopback() [2/2]
|
inline |
Restores the given device into normal operation mode.
Definition at line 824 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
References rs2::device::_dev, rs2::error::handle(), and rs2_loopback_disable().
◆ disconnect_controller() [1/2]
|
inline |
Disconnects a given tm2 controller.
- Parameters
-
[in] id The ID of the desired controller
Definition at line 858 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
References rs2::device::_dev, rs2::error::handle(), and rs2_disconnect_tm2_controller().
◆ disconnect_controller() [2/2]
|
inline |
Disconnects a given tm2 controller.
- Parameters
-
[in] id The ID of the desired controller
Definition at line 858 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
References rs2::device::_dev, rs2::error::handle(), and rs2_disconnect_tm2_controller().
◆ enable_loopback() [1/2]
|
inline |
Enter the given device into loopback operation mode that uses the given file as input for raw data.
- Parameters
-
[in] from_file Path to bag file with raw data for loopback
Definition at line 814 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
References rs2::device::_dev, rs2::error::handle(), and rs2_loopback_enable().
◆ enable_loopback() [2/2]
|
inline |
Enter the given device into loopback operation mode that uses the given file as input for raw data.
- Parameters
-
[in] from_file Path to bag file with raw data for loopback
Definition at line 814 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
References rs2::device::_dev, rs2::error::handle(), and rs2_loopback_enable().
◆ first() [1/2]
|
inlineinherited |
Definition at line 52 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
References rs2::device::query_sensors().
◆ first() [2/2]
|
inlineinherited |
Definition at line 52 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
References rs2::device::query_sensors().
◆ get() [1/2]
|
inlineinherited |
Definition at line 116 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
References rs2::device::_dev.
Referenced by rs2::device_list::contains(), rs2::device_calibration::device_calibration(), rs2::recorder::recorder(), rs2::event_information::was_added(), and rs2::event_information::was_removed().
◆ get() [2/2]
|
inlineinherited |
Definition at line 116 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
References rs2::device::_dev.
◆ get_info() [1/2]
|
inlineinherited |
retrieve camera specific information, like versions of various internal components
- Parameters
-
[in] info camera info type to retrieve
- Returns
- the requested camera info string, in a format specific to the device model
Definition at line 79 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
References rs2::device::_dev, rs2::error::handle(), and rs2_get_device_info().
◆ get_info() [2/2]
|
inlineinherited |
retrieve camera specific information, like versions of various internal components
- Parameters
-
[in] info camera info type to retrieve
- Returns
- the requested camera info string, in a format specific to the device model
Definition at line 79 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
References rs2::device::_dev, rs2::error::handle(), and rs2_get_device_info().
◆ hardware_reset() [1/2]
|
inlineinherited |
send hardware reset request to the device
Definition at line 90 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
References rs2::device::_dev, rs2::error::handle(), and rs2_hardware_reset().
◆ hardware_reset() [2/2]
|
inlineinherited |
send hardware reset request to the device
Definition at line 90 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
References rs2::device::_dev, rs2::error::handle(), and rs2_hardware_reset().
◆ is() [1/2]
|
inlineinherited |
Definition at line 122 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
◆ is() [2/2]
|
inlineinherited |
Definition at line 122 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
◆ is_loopback_enabled() [1/2]
|
inline |
Checks if the device is in loopback mode or not.
- Returns
- true if the device is in loopback operation mode
Definition at line 835 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
References rs2::device::_dev, rs2::error::handle(), and rs2_loopback_is_enabled().
◆ is_loopback_enabled() [2/2]
|
inline |
Checks if the device is in loopback mode or not.
- Returns
- true if the device is in loopback operation mode
Definition at line 835 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
References rs2::device::_dev, rs2::error::handle(), and rs2_loopback_is_enabled().
◆ operator bool() [1/2]
|
inlineinherited |
Definition at line 112 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
References rs2::device::_dev.
◆ operator bool() [2/2]
|
inlineinherited |
Definition at line 112 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
References rs2::device::_dev.
◆ operator std::shared_ptr< rs2_device >() [1/2]
|
inlineexplicitinherited |
Definition at line 138 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
References rs2::device::_dev.
◆ operator std::shared_ptr< rs2_device >() [2/2]
|
inlineexplicitinherited |
Definition at line 138 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
References rs2::device::_dev.
◆ query_sensors() [1/2]
|
inlineinherited |
returns the list of adjacent devices, sharing the same physical parent composite device
- Returns
- the list of adjacent devices
Definition at line 25 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
References rs2::device::_dev, rs2::error::handle(), rs2_create_sensor(), rs2_delete_sensor(), rs2_delete_sensor_list(), rs2_get_sensors_count(), rs2_query_sensors(), and pydeepstreamdoc::tensor::TensorDoc::size.
Referenced by rs2::device::first().
◆ query_sensors() [2/2]
|
inlineinherited |
returns the list of adjacent devices, sharing the same physical parent composite device
- Returns
- the list of adjacent devices
Definition at line 25 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
References rs2::device::_dev, rs2::error::handle(), rs2_create_sensor(), rs2_delete_sensor(), rs2_delete_sensor_list(), rs2_get_sensors_count(), rs2_query_sensors(), and pydeepstreamdoc::tensor::TensorDoc::size.
◆ reset_to_factory_calibration() [1/2]
|
inlineinherited |
Reset device to factory calibration.
Definition at line 316 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
References rs2::device::_dev, rs2::error::handle(), and rs2_reset_to_factory_calibration().
◆ reset_to_factory_calibration() [2/2]
|
inlineinherited |
Reset device to factory calibration.
Definition at line 316 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
References rs2::device::_dev, rs2::error::handle(), and rs2_reset_to_factory_calibration().
◆ set_extrinsics() [1/2]
|
inline |
Set tm2 camera extrinsics.
- Parameters
-
[in] from_stream only support RS2_STREAM_FISHEYE [in] from_id only support left fisheye = 1 [in] to_stream only support RS2_STREAM_FISHEYE [in] to_id only support right fisheye = 2 [in] extrinsics extrinsics value to be written to the device
Definition at line 886 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
References rs2::error::handle(), and rs2_set_extrinsics().
◆ set_extrinsics() [2/2]
|
inline |
Set tm2 camera extrinsics.
- Parameters
-
[in] from_stream only support RS2_STREAM_FISHEYE [in] from_id only support left fisheye = 1 [in] to_stream only support RS2_STREAM_FISHEYE [in] to_id only support right fisheye = 2 [in] extrinsics extrinsics value to be written to the device
Definition at line 886 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
References rs2::error::handle(), and rs2_set_extrinsics().
◆ set_intrinsics() [1/2]
|
inline |
Set tm2 camera intrinsics.
- Parameters
-
[in] fisheye_senor_id The ID of the fisheye sensor [in] intrinsics value to be written to the device
Definition at line 870 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
References rs2::sensor::get(), rs2::error::handle(), rs2_set_intrinsics(), and RS2_STREAM_FISHEYE.
◆ set_intrinsics() [2/2]
|
inline |
Set tm2 camera intrinsics.
- Parameters
-
[in] fisheye_senor_id The ID of the fisheye sensor [in] intrinsics value to be written to the device
Definition at line 870 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
References rs2::sensor::get(), rs2::error::handle(), rs2_set_intrinsics(), and RS2_STREAM_FISHEYE.
◆ set_motion_device_intrinsics() [1/2]
|
inline |
Set tm2 motion device intrinsics.
- Parameters
-
[in] stream_type stream type of the motion device [in] motion_intriniscs intrinsics value to be written to the device
Definition at line 900 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
References rs2::sensor::get(), rs2::error::handle(), and rs2_set_motion_device_intrinsics().
◆ set_motion_device_intrinsics() [2/2]
|
inline |
Set tm2 motion device intrinsics.
- Parameters
-
[in] stream_type stream type of the motion device [in] motion_intriniscs intrinsics value to be written to the device
Definition at line 900 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
References rs2::sensor::get(), rs2::error::handle(), and rs2_set_motion_device_intrinsics().
◆ supports() [1/2]
|
inlineinherited |
check if specific camera info is supported
- Parameters
-
[in] info the parameter to check for support
- Returns
- true if the parameter both exist and well-defined for the specific device
Definition at line 66 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
References rs2::device::_dev, rs2::error::handle(), and rs2_supports_device_info().
◆ supports() [2/2]
|
inlineinherited |
check if specific camera info is supported
- Parameters
-
[in] info the parameter to check for support
- Returns
- true if the parameter both exist and well-defined for the specific device
Definition at line 66 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
References rs2::device::_dev, rs2::error::handle(), and rs2_supports_device_info().
◆ write_calibration() [1/2]
|
inlineinherited |
Write calibration that was set by set_calibration_table to device's EEPROM.
Definition at line 306 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
References rs2::device::_dev, rs2::error::handle(), and rs2_write_calibration().
◆ write_calibration() [2/2]
|
inlineinherited |
Write calibration that was set by set_calibration_table to device's EEPROM.
Definition at line 306 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
References rs2::device::_dev, rs2::error::handle(), and rs2_write_calibration().
Field Documentation
◆ _dev
|
protectedinherited |
Definition at line 146 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_device.hpp.
Referenced by rs2::software_device::add_sensor(), rs2::software_device::add_to(), rs400::advanced_mode::advanced_mode(), rs2::auto_calibrated_device::auto_calibrated_device(), rs2::calibration_change_device::calibration_change_device(), rs2::updatable::check_firmware_compatibility(), connect_controller(), rs2::updatable::create_flash_backup(), rs2::software_device::create_matcher(), rs2::firmware_logger::create_message(), rs2::firmware_logger::create_parsed_message(), rs2::playback::current_status(), rs2::debug_protocol::debug_protocol(), rs2::device_calibration::device_calibration(), disable_loopback(), disconnect_controller(), enable_loopback(), rs2::updatable::enter_update_state(), rs2::recorder::filename(), rs2::firmware_logger::firmware_logger(), rs2::device::get(), rs400::advanced_mode::get_ae_control(), rs400::advanced_mode::get_amp_factor(), rs2::auto_calibrated_device::get_calibration_table(), rs400::advanced_mode::get_census(), rs400::advanced_mode::get_color_control(), rs400::advanced_mode::get_color_correction(), rs400::advanced_mode::get_depth_control(), rs400::advanced_mode::get_depth_table(), rs2::playback::get_duration(), rs2::firmware_logger::get_firmware_log(), rs2::firmware_logger::get_flash_log(), rs400::advanced_mode::get_hdad(), rs2::device::get_info(), rs2::firmware_logger::get_number_of_fw_logs(), rs2::playback::get_position(), rs400::advanced_mode::get_rau_support_vector_control(), rs400::advanced_mode::get_rau_thresholds_control(), rs400::advanced_mode::get_rsm(), rs400::advanced_mode::get_slo_color_thresholds_control(), rs400::advanced_mode::get_slo_penalty_control(), rs2::device::hardware_reset(), rs2::firmware_logger::init_parser(), rs2::device_hub::is_connected(), rs400::advanced_mode::is_enabled(), is_loopback_enabled(), rs2::playback::is_real_time(), rs2::serializable_device::load_json(), rs2::device::operator bool(), rs2::device::operator std::shared_ptr< rs2_device >(), rs2::device::operator=(), rs2::firmware_logger::parse_log(), rs2::playback::pause(), rs2::recorder::pause(), rs2::playback::playback(), rs2::device::query_sensors(), rs2::recorder::recorder(), rs2::calibration_change_device::register_calibration_change_callback(), rs2::software_device::register_info(), rs2::calibrated_device::reset_to_factory_calibration(), rs2::playback::resume(), rs2::recorder::resume(), rs2::auto_calibrated_device::run_on_chip_calibration(), rs2::auto_calibrated_device::run_tare_calibration(), rs2::playback::seek(), rs2::debug_protocol::send_and_receive_raw_data(), rs2::serializable_device::serializable_device(), rs2::serializable_device::serialize_json(), rs400::advanced_mode::set_ae_control(), rs400::advanced_mode::set_amp_factor(), rs2::auto_calibrated_device::set_calibration_table(), rs400::advanced_mode::set_census(), rs400::advanced_mode::set_color_control(), rs400::advanced_mode::set_color_correction(), rs400::advanced_mode::set_depth_control(), rs400::advanced_mode::set_depth_table(), rs2::software_device::set_destruction_callback(), rs400::advanced_mode::set_hdad(), rs2::playback::set_playback_speed(), rs400::advanced_mode::set_rau_support_vector_control(), rs400::advanced_mode::set_rau_thresholds_control(), rs2::playback::set_real_time(), rs400::advanced_mode::set_rsm(), rs400::advanced_mode::set_slo_color_thresholds_control(), rs400::advanced_mode::set_slo_penalty_control(), rs2::playback::set_status_changed_callback(), rs2::playback::stop(), rs2::device::supports(), tm2(), rs400::advanced_mode::toggle_advanced_mode(), rs2::device_calibration::trigger_device_calibration(), rs2::updatable::updatable(), rs2::update_device::update(), rs2::update_device::update_device(), rs2::software_device::update_info(), rs2::updatable::update_unsigned(), and rs2::calibrated_device::write_calibration().
The documentation for this class was generated from the following file: