Detailed Description
Definition at line 88 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_internal.hpp.
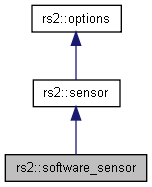
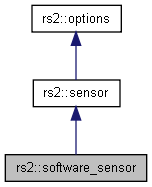
Public Member Functions | |
| stream_profile | add_video_stream (rs2_video_stream video_stream, bool is_default=false) |
| Add video stream to software sensor. More... | |
| stream_profile | add_motion_stream (rs2_motion_stream motion_stream, bool is_default=false) |
| Add motion stream to software sensor. More... | |
| stream_profile | add_pose_stream (rs2_pose_stream pose_stream, bool is_default=false) |
| Add pose stream to software sensor. More... | |
| void | on_video_frame (rs2_software_video_frame frame) |
| Inject video frame into the sensor. More... | |
| void | on_motion_frame (rs2_software_motion_frame frame) |
| Inject motion frame into the sensor. More... | |
| void | on_pose_frame (rs2_software_pose_frame frame) |
| Inject pose frame into the sensor. More... | |
| void | set_metadata (rs2_frame_metadata_value value, rs2_metadata_type type) |
| Set frame metadata for the upcoming frames. More... | |
| void | add_read_only_option (rs2_option option, float val) |
| Register read-only option that will be supported by the sensor. More... | |
| void | set_read_only_option (rs2_option option, float val) |
| Update value of registered read-only option. More... | |
| void | add_option (rs2_option option, const option_range &range, bool is_writable=true) |
| Register option that will be supported by the sensor. More... | |
| void | on_notification (rs2_software_notification notif) |
| void | detach () |
| Sensors hold the parent device in scope via a shared_ptr. More... | |
| void | open (const stream_profile &profile) const |
| open sensor for exclusive access, by committing to a configuration More... | |
| void | open (const std::vector< stream_profile > &profiles) const |
| open sensor for exclusive access, by committing to composite configuration, specifying one or more stream profiles this method should be used for interdependent streams, such as depth and infrared, that have to be configured together More... | |
| bool | supports (rs2_camera_info info) const |
| check if specific camera info is supported More... | |
| bool | supports (rs2_camera_info info) const |
| check if specific camera info is supported More... | |
| bool | supports (rs2_option option) const |
| check if particular option is supported More... | |
| bool | supports (rs2_option option) const |
| check if particular option is supported More... | |
| bool | supports (rs2_option option) const |
| check if particular option is supported More... | |
| bool | supports (rs2_option option) const |
| check if particular option is supported More... | |
| bool | supports (rs2_option option) const |
| check if particular option is supported More... | |
| const char * | get_info (rs2_camera_info info) const |
| retrieve camera specific information, like versions of various internal components More... | |
| const char * | get_info (rs2_camera_info info) const |
| retrieve camera specific information, like versions of various internal components More... | |
| void | close () const |
| close sensor for exclusive access this method should be used for releasing sensor resource More... | |
| void | close () const |
| close sensor for exclusive access this method should be used for releasing sensor resource More... | |
| template<class T > | |
| void | start (T callback) const |
| Start passing frames into user provided callback. More... | |
| template<class T > | |
| void | start (T callback) const |
| Start passing frames into user provided callback. More... | |
| void | stop () const |
| stop streaming More... | |
| void | stop () const |
| stop streaming More... | |
| template<class T > | |
| void | set_notifications_callback (T callback) const |
| register notifications callback More... | |
| template<class T > | |
| void | set_notifications_callback (T callback) const |
| register notifications callback More... | |
| std::vector< stream_profile > | get_stream_profiles () const |
| Retrieves the list of stream profiles supported by the sensor. More... | |
| std::vector< stream_profile > | get_stream_profiles () const |
| Retrieves the list of stream profiles supported by the sensor. More... | |
| std::vector< stream_profile > | get_active_streams () const |
| Retrieves the list of stream profiles currently streaming on the sensor. More... | |
| std::vector< stream_profile > | get_active_streams () const |
| Retrieves the list of stream profiles currently streaming on the sensor. More... | |
| std::vector< filter > | get_recommended_filters () const |
| get the recommended list of filters by the sensor More... | |
| std::vector< filter > | get_recommended_filters () const |
| get the recommended list of filters by the sensor More... | |
| operator bool () const | |
| operator bool () const | |
| const std::shared_ptr< rs2_sensor > & | get () const |
| const std::shared_ptr< rs2_sensor > & | get () const |
| template<class T > | |
| bool | is () const |
| template<class T > | |
| bool | is () const |
| template<class T > | |
| T | as () const |
| template<class T > | |
| T | as () const |
| operator std::shared_ptr< rs2_sensor > () | |
| operator std::shared_ptr< rs2_sensor > () | |
| const char * | get_option_description (rs2_option option) const |
| get option description More... | |
| const char * | get_option_description (rs2_option option) const |
| get option description More... | |
| const char * | get_option_name (rs2_option option) const |
| get option name More... | |
| const char * | get_option_name (rs2_option option) const |
| get option name More... | |
| const char * | get_option_value_description (rs2_option option, float val) const |
| get option value description (in case specific option value hold special meaning) More... | |
| const char * | get_option_value_description (rs2_option option, float val) const |
| get option value description (in case specific option value hold special meaning) More... | |
| float | get_option (rs2_option option) const |
| read option's value More... | |
| float | get_option (rs2_option option) const |
| read option's value More... | |
| option_range | get_option_range (rs2_option option) const |
| retrieve the available range of values of a supported option More... | |
| option_range | get_option_range (rs2_option option) const |
| retrieve the available range of values of a supported option More... | |
| void | set_option (rs2_option option, float value) const |
| write new value to the option More... | |
| void | set_option (rs2_option option, float value) const |
| write new value to the option More... | |
| bool | is_option_read_only (rs2_option option) const |
| check if particular option is read-only More... | |
| bool | is_option_read_only (rs2_option option) const |
| check if particular option is read-only More... | |
| std::vector< rs2_option > | get_supported_options () |
| std::vector< rs2_option > | get_supported_options () |
Protected Attributes | |
| friend | context |
| friend | device_list |
| friend | device |
| friend | device_base |
| friend | roi_sensor |
| std::shared_ptr< rs2_sensor > | _sensor |
Friends | |
| class | software_device |
Member Function Documentation
◆ add_motion_stream() [1/2]
|
inline |
Add motion stream to software sensor.
- Parameters
-
[in] motion all the parameters that required to defind motion stream
Definition at line 112 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_internal.hpp.
References rs2::sensor::_sensor, rs2::error::handle(), and rs2_software_sensor_add_motion_stream_ex().
◆ add_motion_stream() [2/2]
|
inline |
Add motion stream to software sensor.
- Parameters
-
[in] motion all the parameters that required to defind motion stream
Definition at line 112 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_internal.hpp.
References rs2::sensor::_sensor, rs2::error::handle(), and rs2_software_sensor_add_motion_stream_ex().
◆ add_option() [1/2]
|
inline |
Register option that will be supported by the sensor.
- Parameters
-
[in] option the option [in] range range data for the option. range.def will be used as the initial value
Definition at line 218 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_internal.hpp.
References rs2::sensor::_sensor, rs2::option_range::def, rs2::error::handle(), rs2::option_range::max, rs2::option_range::min, rs2_software_sensor_add_option(), and rs2::option_range::step.
◆ add_option() [2/2]
|
inline |
Register option that will be supported by the sensor.
- Parameters
-
[in] option the option [in] range range data for the option. range.def will be used as the initial value
Definition at line 218 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_internal.hpp.
References rs2::sensor::_sensor, rs2::option_range::def, rs2::error::handle(), rs2::option_range::max, rs2::option_range::min, rs2_software_sensor_add_option(), and rs2::option_range::step.
◆ add_pose_stream() [1/2]
|
inline |
Add pose stream to software sensor.
- Parameters
-
[in] pose all the parameters that required to defind pose stream
Definition at line 128 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_internal.hpp.
References rs2::sensor::_sensor, rs2::error::handle(), and rs2_software_sensor_add_pose_stream_ex().
◆ add_pose_stream() [2/2]
|
inline |
Add pose stream to software sensor.
- Parameters
-
[in] pose all the parameters that required to defind pose stream
Definition at line 128 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_internal.hpp.
References rs2::sensor::_sensor, rs2::error::handle(), and rs2_software_sensor_add_pose_stream_ex().
◆ add_read_only_option() [1/2]
|
inline |
Register read-only option that will be supported by the sensor.
- Parameters
-
[in] option the option [in] val the initial value
Definition at line 193 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_internal.hpp.
References rs2::sensor::_sensor, rs2::error::handle(), rs2_software_sensor_add_read_only_option(), and val.
◆ add_read_only_option() [2/2]
|
inline |
Register read-only option that will be supported by the sensor.
- Parameters
-
[in] option the option [in] val the initial value
Definition at line 193 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_internal.hpp.
References rs2::sensor::_sensor, rs2::error::handle(), rs2_software_sensor_add_read_only_option(), and val.
◆ add_video_stream() [1/2]
|
inline |
Add video stream to software sensor.
- Parameters
-
[in] video_stream all the parameters that required to defind video stream
Definition at line 96 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_internal.hpp.
References rs2::sensor::_sensor, rs2::error::handle(), and rs2_software_sensor_add_video_stream_ex().
◆ add_video_stream() [2/2]
|
inline |
Add video stream to software sensor.
- Parameters
-
[in] video_stream all the parameters that required to defind video stream
Definition at line 96 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_internal.hpp.
References rs2::sensor::_sensor, rs2::error::handle(), and rs2_software_sensor_add_video_stream_ex().
◆ as() [1/2]
|
inlineinherited |
Definition at line 333 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_sensor.hpp.
◆ as() [2/2]
|
inlineinherited |
Definition at line 333 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_sensor.hpp.
◆ close() [1/2]
|
inlineinherited |
close sensor for exclusive access this method should be used for releasing sensor resource
Definition at line 173 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_sensor.hpp.
References rs2::sensor::_sensor, rs2::error::handle(), and rs2_close().
◆ close() [2/2]
|
inlineinherited |
close sensor for exclusive access this method should be used for releasing sensor resource
Definition at line 173 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_sensor.hpp.
References rs2::sensor::_sensor, rs2::error::handle(), and rs2_close().
◆ detach() [1/2]
|
inline |
Sensors hold the parent device in scope via a shared_ptr.
This function detaches that so that the software sensor doesn't keep the software device alive. Note that this is dangerous as it opens the door to accessing freed memory if care isn't taken.
Definition at line 237 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_internal.hpp.
References rs2::sensor::_sensor, rs2::error::handle(), and rs2_software_sensor_detach().
◆ detach() [2/2]
|
inline |
Sensors hold the parent device in scope via a shared_ptr.
This function detaches that so that the software sensor doesn't keep the software device alive. Note that this is dangerous as it opens the door to accessing freed memory if care isn't taken.
Definition at line 237 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_internal.hpp.
References rs2::sensor::_sensor, rs2::error::handle(), and rs2_software_sensor_detach().
◆ get() [1/2]
|
inlineinherited |
Definition at line 320 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_sensor.hpp.
References rs2::sensor::_sensor.
Referenced by rs2::tm2::set_intrinsics(), and rs2::tm2::set_motion_device_intrinsics().
◆ get() [2/2]
|
inlineinherited |
Definition at line 320 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_sensor.hpp.
References rs2::sensor::_sensor.
◆ get_active_streams() [1/2]
|
inlineinherited |
Retrieves the list of stream profiles currently streaming on the sensor.
- Returns
- list of stream profiles that given sensor is streaming
Definition at line 246 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_sensor.hpp.
References rs2::sensor::_sensor, rs2::error::handle(), rs2_delete_stream_profiles_list(), rs2_get_active_streams(), rs2_get_stream_profile(), rs2_get_stream_profiles_count(), and pydeepstreamdoc::tensor::TensorDoc::size.
◆ get_active_streams() [2/2]
|
inlineinherited |
Retrieves the list of stream profiles currently streaming on the sensor.
- Returns
- list of stream profiles that given sensor is streaming
Definition at line 246 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_sensor.hpp.
References rs2::sensor::_sensor, rs2::error::handle(), rs2_delete_stream_profiles_list(), rs2_get_active_streams(), rs2_get_stream_profile(), rs2_get_stream_profiles_count(), and pydeepstreamdoc::tensor::TensorDoc::size.
◆ get_info() [1/2]
|
inlineinherited |
retrieve camera specific information, like versions of various internal components
- Parameters
-
[in] info camera info type to retrieve
- Returns
- the requested camera info string, in a format specific to the sensor model
Definition at line 138 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_sensor.hpp.
References rs2::sensor::_sensor, rs2::error::handle(), and rs2_get_sensor_info().
◆ get_info() [2/2]
|
inlineinherited |
retrieve camera specific information, like versions of various internal components
- Parameters
-
[in] info camera info type to retrieve
- Returns
- the requested camera info string, in a format specific to the sensor model
Definition at line 138 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_sensor.hpp.
References rs2::sensor::_sensor, rs2::error::handle(), and rs2_get_sensor_info().
Referenced by rs2::operator==().
◆ get_option() [1/2]
|
inlineinherited |
read option's value
- Parameters
-
[in] option option id to be queried
- Returns
- value of the option
Definition at line 72 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_options.hpp.
References rs2::error::handle(), and rs2_get_option().
◆ get_option() [2/2]
|
inlineinherited |
read option's value
- Parameters
-
[in] option option id to be queried
- Returns
- value of the option
Definition at line 72 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_options.hpp.
References rs2::error::handle(), and rs2_get_option().
◆ get_option_description() [1/2]
|
inlineinherited |
get option description
- Parameters
-
[in] option option id to be checked
- Returns
- human-readable option description
Definition at line 32 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_options.hpp.
References rs2::error::handle(), and rs2_get_option_description().
◆ get_option_description() [2/2]
|
inlineinherited |
get option description
- Parameters
-
[in] option option id to be checked
- Returns
- human-readable option description
Definition at line 32 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_options.hpp.
References rs2::error::handle(), and rs2_get_option_description().
◆ get_option_name() [1/2]
|
inlineinherited |
get option name
- Parameters
-
[in] option option id to be checked
- Returns
- human-readable option name
Definition at line 45 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_options.hpp.
References rs2::error::handle(), and rs2_get_option_name().
◆ get_option_name() [2/2]
|
inlineinherited |
get option name
- Parameters
-
[in] option option id to be checked
- Returns
- human-readable option name
Definition at line 45 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_options.hpp.
References rs2::error::handle(), and rs2_get_option_name().
◆ get_option_range() [1/2]
|
inlineinherited |
retrieve the available range of values of a supported option
- Returns
- option range containing minimum and maximum values, step and default value
Definition at line 84 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_options.hpp.
References rs2::option_range::def, rs2::error::handle(), rs2::option_range::max, rs2::option_range::min, rs2_get_option_range(), and rs2::option_range::step.
◆ get_option_range() [2/2]
|
inlineinherited |
retrieve the available range of values of a supported option
- Returns
- option range containing minimum and maximum values, step and default value
Definition at line 84 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_options.hpp.
References rs2::option_range::def, rs2::error::handle(), rs2::option_range::max, rs2::option_range::min, rs2_get_option_range(), and rs2::option_range::step.
◆ get_option_value_description() [1/2]
|
inlineinherited |
get option value description (in case specific option value hold special meaning)
- Parameters
-
[in] option option id to be checked [in] val value of the option
- Returns
- human-readable description of a specific value of an option or null if no special meaning
Definition at line 59 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_options.hpp.
References rs2::error::handle(), rs2_get_option_value_description(), and val.
◆ get_option_value_description() [2/2]
|
inlineinherited |
get option value description (in case specific option value hold special meaning)
- Parameters
-
[in] option option id to be checked [in] val value of the option
- Returns
- human-readable description of a specific value of an option or null if no special meaning
Definition at line 59 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_options.hpp.
References rs2::error::handle(), rs2_get_option_value_description(), and val.
◆ get_recommended_filters() [1/2]
|
inlineinherited |
get the recommended list of filters by the sensor
- Returns
- list of filters that recommended by sensor
Definition at line 273 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_sensor.hpp.
References rs2::sensor::_sensor, rs2::error::handle(), rs2_delete_processing_block(), rs2_delete_recommended_processing_blocks(), rs2_get_processing_block(), rs2_get_recommended_processing_blocks(), rs2_get_recommended_processing_blocks_count(), and pydeepstreamdoc::tensor::TensorDoc::size.
◆ get_recommended_filters() [2/2]
|
inlineinherited |
get the recommended list of filters by the sensor
- Returns
- list of filters that recommended by sensor
Definition at line 273 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_sensor.hpp.
References rs2::sensor::_sensor, rs2::error::handle(), rs2_delete_processing_block(), rs2_delete_recommended_processing_blocks(), rs2_get_processing_block(), rs2_get_recommended_processing_blocks(), rs2_get_recommended_processing_blocks_count(), and pydeepstreamdoc::tensor::TensorDoc::size.
◆ get_stream_profiles() [1/2]
|
inlineinherited |
Retrieves the list of stream profiles supported by the sensor.
- Returns
- list of stream profiles that given sensor can provide
Definition at line 219 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_sensor.hpp.
References rs2::sensor::_sensor, rs2::error::handle(), rs2_delete_stream_profiles_list(), rs2_get_stream_profile(), rs2_get_stream_profiles(), rs2_get_stream_profiles_count(), and pydeepstreamdoc::tensor::TensorDoc::size.
◆ get_stream_profiles() [2/2]
|
inlineinherited |
Retrieves the list of stream profiles supported by the sensor.
- Returns
- list of stream profiles that given sensor can provide
Definition at line 219 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_sensor.hpp.
References rs2::sensor::_sensor, rs2::error::handle(), rs2_delete_stream_profiles_list(), rs2_get_stream_profile(), rs2_get_stream_profiles(), rs2_get_stream_profiles_count(), and pydeepstreamdoc::tensor::TensorDoc::size.
◆ get_supported_options() [1/2]
|
inlineinherited |
Definition at line 119 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_options.hpp.
References rs2_delete_options_list(), rs2_get_option_from_list(), rs2_get_options_list(), and rs2_get_options_list_size().
◆ get_supported_options() [2/2]
|
inlineinherited |
Definition at line 119 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_options.hpp.
References rs2_delete_options_list(), rs2_get_option_from_list(), rs2_get_options_list(), and rs2_get_options_list_size().
◆ is() [1/2]
|
inlineinherited |
Definition at line 326 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_sensor.hpp.
◆ is() [2/2]
|
inlineinherited |
Definition at line 326 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_sensor.hpp.
◆ is_option_read_only() [1/2]
|
inlineinherited |
check if particular option is read-only
- Parameters
-
[in] option option id to be checked
- Returns
- true if option is read-only
Definition at line 111 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_options.hpp.
References rs2::error::handle(), and rs2_is_option_read_only().
◆ is_option_read_only() [2/2]
|
inlineinherited |
check if particular option is read-only
- Parameters
-
[in] option option id to be checked
- Returns
- true if option is read-only
Definition at line 111 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_options.hpp.
References rs2::error::handle(), and rs2_is_option_read_only().
◆ on_motion_frame() [1/2]
|
inline |
Inject motion frame into the sensor.
- Parameters
-
[in] frame all the parameters that required to define motion frame
Definition at line 156 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_internal.hpp.
References rs2::sensor::_sensor, rs2::error::handle(), and rs2_software_sensor_on_motion_frame().
◆ on_motion_frame() [2/2]
|
inline |
Inject motion frame into the sensor.
- Parameters
-
[in] frame all the parameters that required to define motion frame
Definition at line 156 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_internal.hpp.
References rs2::sensor::_sensor, rs2::error::handle(), and rs2_software_sensor_on_motion_frame().
◆ on_notification() [1/2]
|
inline |
Definition at line 226 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_internal.hpp.
References rs2::sensor::_sensor, rs2::error::handle(), and rs2_software_sensor_on_notification().
◆ on_notification() [2/2]
|
inline |
Definition at line 226 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_internal.hpp.
References rs2::sensor::_sensor, rs2::error::handle(), and rs2_software_sensor_on_notification().
◆ on_pose_frame() [1/2]
|
inline |
Inject pose frame into the sensor.
- Parameters
-
[in] frame all the parameters that required to define pose frame
Definition at line 168 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_internal.hpp.
References rs2::sensor::_sensor, rs2::error::handle(), and rs2_software_sensor_on_pose_frame().
◆ on_pose_frame() [2/2]
|
inline |
Inject pose frame into the sensor.
- Parameters
-
[in] frame all the parameters that required to define pose frame
Definition at line 168 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_internal.hpp.
References rs2::sensor::_sensor, rs2::error::handle(), and rs2_software_sensor_on_pose_frame().
◆ on_video_frame() [1/2]
|
inline |
Inject video frame into the sensor.
- Parameters
-
[in] frame all the parameters that required to define video frame
Definition at line 144 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_internal.hpp.
References rs2::sensor::_sensor, rs2::error::handle(), and rs2_software_sensor_on_video_frame().
◆ on_video_frame() [2/2]
|
inline |
Inject video frame into the sensor.
- Parameters
-
[in] frame all the parameters that required to define video frame
Definition at line 144 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_internal.hpp.
References rs2::sensor::_sensor, rs2::error::handle(), and rs2_software_sensor_on_video_frame().
◆ open() [1/4]
|
inlineinherited |
open sensor for exclusive access, by committing to composite configuration, specifying one or more stream profiles this method should be used for interdependent streams, such as depth and infrared, that have to be configured together
- Parameters
-
[in] profiles vector of configurations to be commited by the sensor
Definition at line 151 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_sensor.hpp.
References rs2::sensor::_sensor, rs2::error::handle(), and rs2_open_multiple().
◆ open() [2/4]
|
inlineinherited |
open sensor for exclusive access, by committing to composite configuration, specifying one or more stream profiles this method should be used for interdependent streams, such as depth and infrared, that have to be configured together
- Parameters
-
[in] profiles vector of configurations to be commited by the sensor
Definition at line 151 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_sensor.hpp.
References rs2::sensor::_sensor, rs2::error::handle(), and rs2_open_multiple().
◆ open() [3/4]
|
inlineinherited |
open sensor for exclusive access, by committing to a configuration
- Parameters
-
[in] profile configuration committed by the sensor
Definition at line 111 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_sensor.hpp.
References rs2::sensor::_sensor, rs2::stream_profile::get(), rs2::error::handle(), and rs2_open().
◆ open() [4/4]
|
inlineinherited |
open sensor for exclusive access, by committing to a configuration
- Parameters
-
[in] profile configuration committed by the sensor
Definition at line 111 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_sensor.hpp.
References rs2::sensor::_sensor, rs2::stream_profile::get(), rs2::error::handle(), and rs2_open().
◆ operator bool() [1/2]
|
inlineinherited |
Definition at line 315 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_sensor.hpp.
References rs2::sensor::_sensor.
◆ operator bool() [2/2]
|
inlineinherited |
Definition at line 315 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_sensor.hpp.
References rs2::sensor::_sensor.
◆ operator std::shared_ptr< rs2_sensor >() [1/2]
|
inlineexplicitinherited |
Definition at line 343 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_sensor.hpp.
References rs2::sensor::_sensor.
◆ operator std::shared_ptr< rs2_sensor >() [2/2]
|
inlineexplicitinherited |
Definition at line 343 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_sensor.hpp.
References rs2::sensor::_sensor.
◆ set_metadata() [1/2]
|
inline |
Set frame metadata for the upcoming frames.
- Parameters
-
[in] value metadata key to set [in] type metadata value
Definition at line 180 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_internal.hpp.
References rs2::sensor::_sensor, rs2::error::handle(), and rs2_software_sensor_set_metadata().
◆ set_metadata() [2/2]
|
inline |
Set frame metadata for the upcoming frames.
- Parameters
-
[in] value metadata key to set [in] type metadata value
Definition at line 180 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_internal.hpp.
References rs2::sensor::_sensor, rs2::error::handle(), and rs2_software_sensor_set_metadata().
◆ set_notifications_callback() [1/2]
|
inlineinherited |
register notifications callback
- Parameters
-
[in] callback notifications callback
Definition at line 207 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_sensor.hpp.
References rs2::sensor::_sensor, rs2::error::handle(), absl::move(), and rs2_set_notifications_callback_cpp().
◆ set_notifications_callback() [2/2]
|
inlineinherited |
register notifications callback
- Parameters
-
[in] callback notifications callback
Definition at line 207 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_sensor.hpp.
References rs2::sensor::_sensor, rs2::error::handle(), absl::move(), and rs2_set_notifications_callback_cpp().
◆ set_option() [1/2]
|
inlineinherited |
write new value to the option
- Parameters
-
[in] option option id to be queried [in] value new value for the option
Definition at line 99 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_options.hpp.
References rs2::error::handle(), and rs2_set_option().
◆ set_option() [2/2]
|
inlineinherited |
write new value to the option
- Parameters
-
[in] option option id to be queried [in] value new value for the option
Definition at line 99 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_options.hpp.
References rs2::error::handle(), and rs2_set_option().
Referenced by rs2::colorizer::colorizer(), rs2::decimation_filter::decimation_filter(), rs2::hole_filling_filter::hole_filling_filter(), rs2::pointcloud::map_to(), rs2::pointcloud::pointcloud(), rs2::sequence_id_filter::sequence_id_filter(), rs2::spatial_filter::spatial_filter(), rs2::temporal_filter::temporal_filter(), and rs2::threshold_filter::threshold_filter().
◆ set_read_only_option() [1/2]
|
inline |
Update value of registered read-only option.
- Parameters
-
[in] option the option [in] val the initial value
Definition at line 206 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_internal.hpp.
References rs2::sensor::_sensor, rs2::error::handle(), rs2_software_sensor_update_read_only_option(), and val.
◆ set_read_only_option() [2/2]
|
inline |
Update value of registered read-only option.
- Parameters
-
[in] option the option [in] val the initial value
Definition at line 206 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_internal.hpp.
References rs2::sensor::_sensor, rs2::error::handle(), rs2_software_sensor_update_read_only_option(), and val.
◆ start() [1/2]
|
inlineinherited |
Start passing frames into user provided callback.
- Parameters
-
[in] callback Stream callback, can be any callable object accepting rs2::frame
Definition at line 185 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_sensor.hpp.
References rs2::sensor::_sensor, rs2::error::handle(), absl::move(), and rs2_start_cpp().
◆ start() [2/2]
|
inlineinherited |
Start passing frames into user provided callback.
- Parameters
-
[in] callback Stream callback, can be any callable object accepting rs2::frame
Definition at line 185 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_sensor.hpp.
References rs2::sensor::_sensor, rs2::error::handle(), absl::move(), and rs2_start_cpp().
Referenced by rs2::pose_sensor::export_localization_map().
◆ stop() [1/2]
|
inlineinherited |
stop streaming
Definition at line 195 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_sensor.hpp.
References rs2::sensor::_sensor, rs2::error::handle(), and rs2_stop().
◆ stop() [2/2]
|
inlineinherited |
stop streaming
Definition at line 195 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_sensor.hpp.
References rs2::sensor::_sensor, rs2::error::handle(), and rs2_stop().
◆ supports() [1/7]
|
inlineinherited |
check if specific camera info is supported
- Parameters
-
[in] info the parameter to check for support
- Returns
- true if the parameter both exist and well-defined for the specific sensor
Definition at line 125 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_sensor.hpp.
References rs2::sensor::_sensor, rs2::error::handle(), and rs2_supports_sensor_info().
Referenced by rs2::operator==().
◆ supports() [2/7]
|
inlineinherited |
check if specific camera info is supported
- Parameters
-
[in] info the parameter to check for support
- Returns
- true if the parameter both exist and well-defined for the specific sensor
Definition at line 125 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_sensor.hpp.
References rs2::sensor::_sensor, rs2::error::handle(), and rs2_supports_sensor_info().
◆ supports() [3/7]
|
inlineinherited |
check if particular option is supported
- Parameters
-
[in] option option id to be checked
- Returns
- true if option is supported
Definition at line 19 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_options.hpp.
References rs2::error::handle(), and rs2_supports_option().
◆ supports() [4/7]
|
inlineinherited |
check if particular option is supported
- Parameters
-
[in] option option id to be checked
- Returns
- true if option is supported
Definition at line 19 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_options.hpp.
◆ supports() [5/7]
|
inlineinherited |
check if particular option is supported
- Parameters
-
[in] option option id to be checked
- Returns
- true if option is supported
Definition at line 19 of file 9.2/sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_options.hpp.
◆ supports() [6/7]
|
inlineinherited |
check if particular option is supported
- Parameters
-
[in] option option id to be checked
- Returns
- true if option is supported
Definition at line 19 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_options.hpp.
◆ supports() [7/7]
|
inlineinherited |
check if particular option is supported
- Parameters
-
[in] option option id to be checked
- Returns
- true if option is supported
Definition at line 19 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_options.hpp.
Friends And Related Function Documentation
◆ software_device
|
friend |
Definition at line 245 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_internal.hpp.
Field Documentation
◆ _sensor
|
protectedinherited |
Definition at line 352 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_sensor.hpp.
Referenced by add_motion_stream(), add_option(), add_pose_stream(), add_read_only_option(), add_video_stream(), rs2::calibrated_sensor::calibrated_sensor(), rs2::sensor::close(), rs2::color_sensor::color_sensor(), rs2::debug_stream_sensor::debug_stream_sensor(), rs2::depth_sensor::depth_sensor(), rs2::depth_stereo_sensor::depth_stereo_sensor(), detach(), rs2::pose_sensor::export_localization_map(), rs2::fisheye_sensor::fisheye_sensor(), rs2::sensor::get(), rs2::sensor::get_active_streams(), rs2::debug_stream_sensor::get_debug_stream_profiles(), rs2::depth_sensor::get_depth_scale(), rs2::calibrated_sensor::get_dsm_params(), rs2::sensor::get_info(), rs2::max_usable_range_sensor::get_max_usable_depth_range(), rs2::sensor::get_recommended_filters(), rs2::roi_sensor::get_region_of_interest(), rs2::context::get_sensor_parent(), rs2::pose_sensor::get_static_node(), rs2::depth_stereo_sensor::get_stereo_baseline(), rs2::sensor::get_stream_profiles(), rs2::pose_sensor::import_localization_map(), rs2::wheel_odometer::load_wheel_odometery_config(), rs2::max_usable_range_sensor::max_usable_range_sensor(), rs2::motion_sensor::motion_sensor(), on_motion_frame(), on_notification(), on_pose_frame(), on_video_frame(), rs2::sensor::open(), rs2::sensor::operator bool(), rs2::color_sensor::operator bool(), rs2::motion_sensor::operator bool(), rs2::fisheye_sensor::operator bool(), rs2::roi_sensor::operator bool(), rs2::depth_sensor::operator bool(), rs2::depth_stereo_sensor::operator bool(), rs2::pose_sensor::operator bool(), rs2::wheel_odometer::operator bool(), rs2::calibrated_sensor::operator bool(), rs2::max_usable_range_sensor::operator bool(), rs2::debug_stream_sensor::operator bool(), rs2::sensor::operator std::shared_ptr< rs2_sensor >(), rs2::sensor::operator=(), rs2::calibrated_sensor::override_dsm_params(), rs2::calibrated_sensor::override_extrinsics(), rs2::calibrated_sensor::override_intrinsics(), rs2::pose_sensor::pose_sensor(), rs2::pose_sensor::remove_static_node(), rs2::calibrated_sensor::reset_calibration(), rs2::roi_sensor::roi_sensor(), rs2::wheel_odometer::send_wheel_odometry(), set_metadata(), rs2::sensor::set_notifications_callback(), set_read_only_option(), rs2::roi_sensor::set_region_of_interest(), rs2::pose_sensor::set_static_node(), rs2::sensor::start(), rs2::sensor::stop(), rs2::sensor::supports(), and rs2::wheel_odometer::wheel_odometer().
◆ context
|
protectedinherited |
Definition at line 346 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_sensor.hpp.
◆ device
|
protectedinherited |
Definition at line 348 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_sensor.hpp.
◆ device_base
|
protectedinherited |
Definition at line 349 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_sensor.hpp.
◆ device_list
|
protectedinherited |
Definition at line 347 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_sensor.hpp.
◆ roi_sensor
|
protectedinherited |
Definition at line 350 of file sources/libs/ds3d/3rdparty/realsense2/include/librealsense2/hpp/rs_sensor.hpp.
The documentation for this class was generated from the following file: