

Isaac Sim Action Graphs
The ROS 2 Action Graphs that drive the SIL scene in Isaac Sim. Since Isaac Sim 6.0 these graphs are built at run time by Python builders (one module per graph under closed-loop-testing/isaac-sim/sil/scripts/action_graphs/) instead of being baked into the scene USD. Each builder is idempotent, reads its shape from robots.yaml / cameras.yaml, and creates a graph at a predictable /World/<Name>Graph path so operators can find it in the Stage panel.
Adding a robot or camera is a config change, not a code change — add a block to robots.yaml / cameras.yaml and the matching graph is built for it on the next run.
At load time, forklift_common.strip_baked_scene_graphs() deletes any residual baked graphs (e.g. /World/ActionGraph, ROS_Forklift_Control_Graph) so the Python builders are the single source of truth and no logic runs twice.
Graphs at a glance
The per-robot graphs (control, odometry, safety) are built once per robot in robots.yaml — the <name> in the path is the robot’s name (e.g. forklift_b_ControlGraph). Each block carries an enabled flag, so any graph can be turned off without removing its config.
Build order
The builders fire from run_actor_sdg.py after setup_simulation() and before timeline.play():
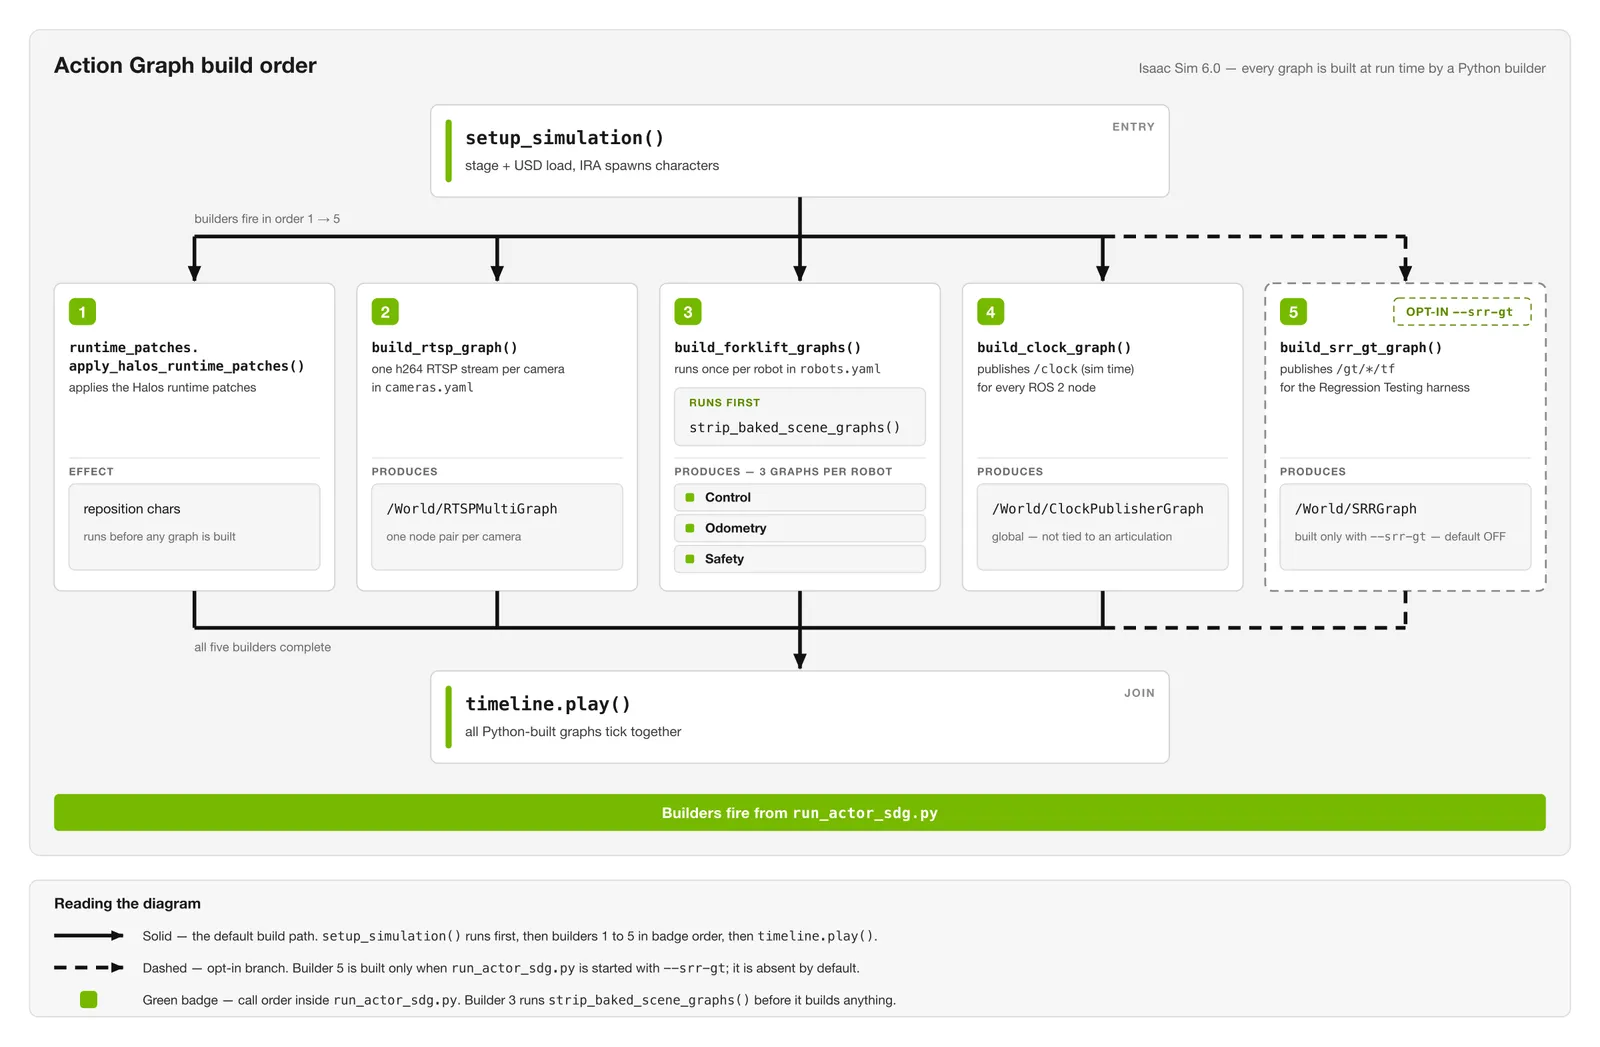
The five builders in call order, what each one produces, and the one that is built only with --srr-gt.
Clock Publisher Graph
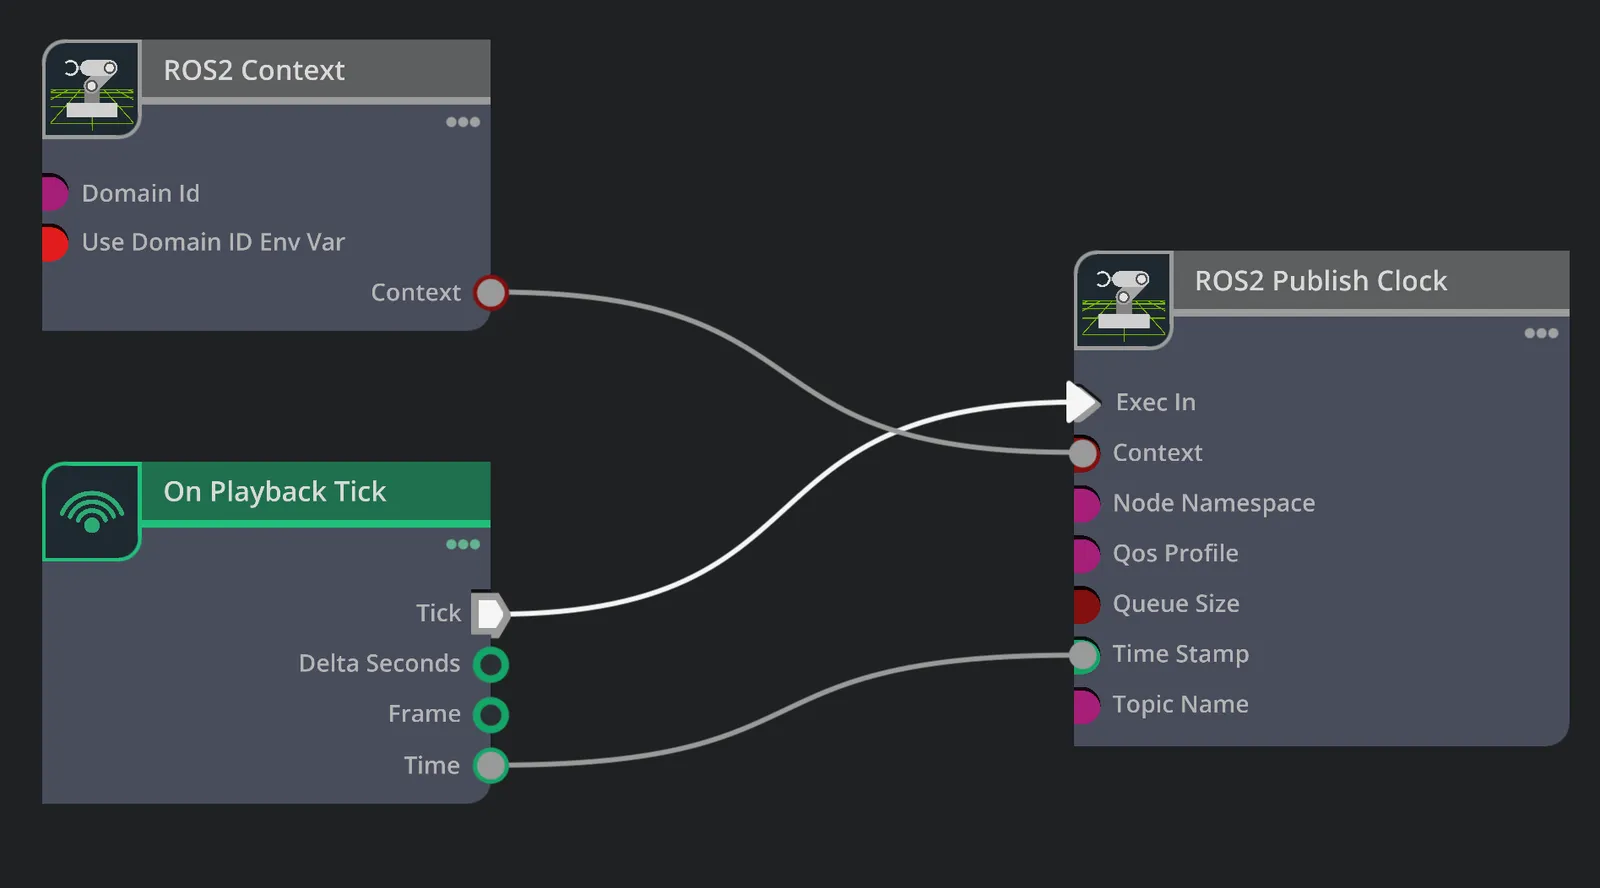
/World/ClockPublisherGraph — On Playback Tick + ROS2 Context drive ROS2 Publish Clock (tick → exec-in, time → time-stamp).
Publishes simulation time to /clock so every ROS 2 node in the stack shares the sim clock instead of wall-clock time. It is global (not tied to any articulation), so it lives in its own builder.
Config — the top-level clock: block of robots.yaml:
RTSP Multi-Camera Graph
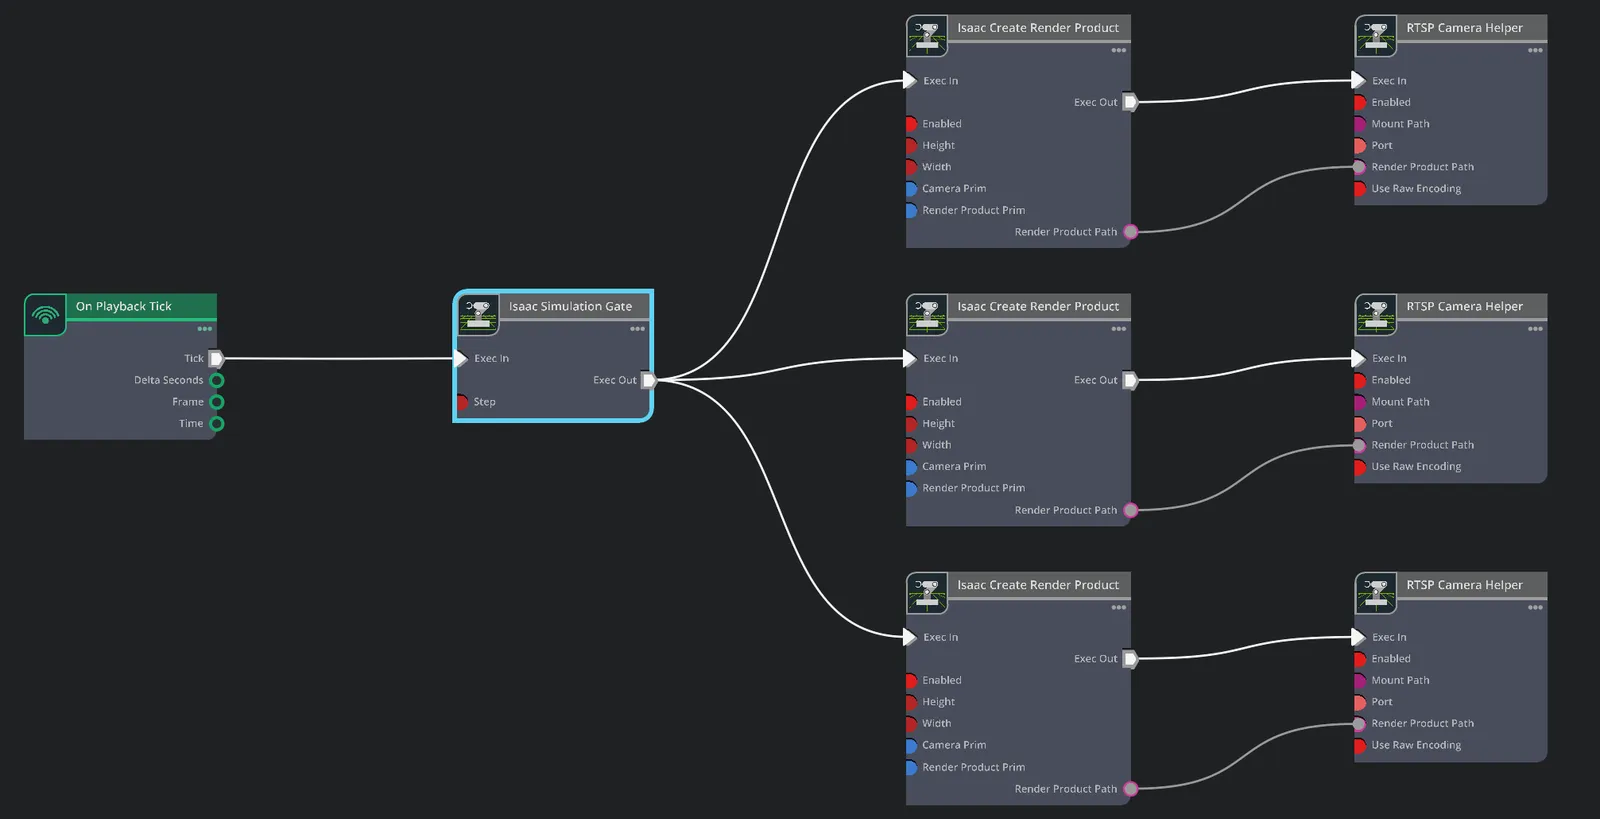
/World/RTSPMultiGraph — On Playback Tick → Isaac Simulation Gate fans out to one Isaac Create Render Product → RTSP Camera Helper pair per camera (three cameras shown).
Builds one shared OnPlaybackTick plus a pair of nodes (IsaacCreateRenderProduct + RTSPCameraHelper) for each camera in cameras.yaml. After Play, each camera self-hosts an in-process RTSP server on its own port and streams NVENC h264 (default 1920×1080) with per-frame SEI metadata.
The IsaacSimulationGate (rate divider) throttles the render-loop tick down to the sim/BT rate; without it the encoder duplicates frames on the wire and the downstream DeepStream/VST pipeline backlogs.
Config — the cameras: list in cameras.yaml (name, camera_prim, port, mount_path; optional spawn: block to create the camera prim at run time). The stream URL is rtsp://${HOST_IP}:<port><mount_path>.
Forklift Control Graph
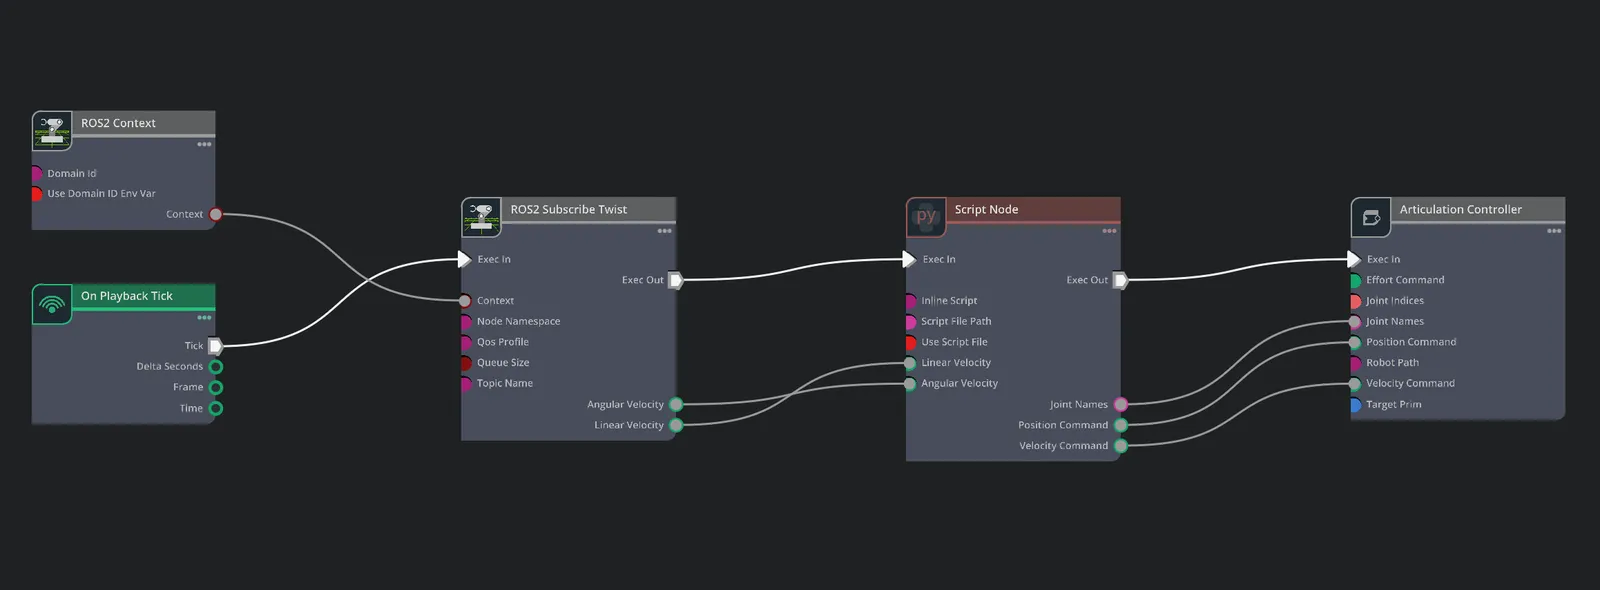
/World/forklift_b_ControlGraph — ROS2 Subscribe Twist (forklift_b/cmd_vel) → SwivelIK Script Node → Articulation Controller.
Turns velocity commands into forklift joint commands. It subscribes to the robot’s control.cmd_vel_topic (forklift_b/cmd_vel; geometry_msgs/Twist, published by the forklift-controller service, which reads the same key) and maps it through a single swivel-drive IK ScriptNode to the IsaacArticulationController.
Where does the motion come from? The control graph is reactive — it only converts whatever cmd_vel it receives. The route itself is authored outside Isaac Sim: the forklift-controller service follows a waypoint / segment path and publishes cmd_vel. See Forklift Controller for how it follows that path, and the Forklift Waypoint Generator for authoring curved routes.
SwivelIK ScriptNode
The IK math from the old baked ROS_Forklift_Control_Graph plus the downstream divide-by-wheel-radius and construct-array plumbing are folded into one ScriptNode (same math, far fewer fragile node-to-node connections). Build-time constants are prepended by the builder from the robot’s model block in robots.yaml (models.<model>).
The controller applies two joints: a velocity-controlled drive wheel and a position-controlled swivel (steer) wheel.
Forklift parameters
Defined once per model in robots.yaml models: (defaults shown); a robot block can override any of them:
Forklift Odometry Graph
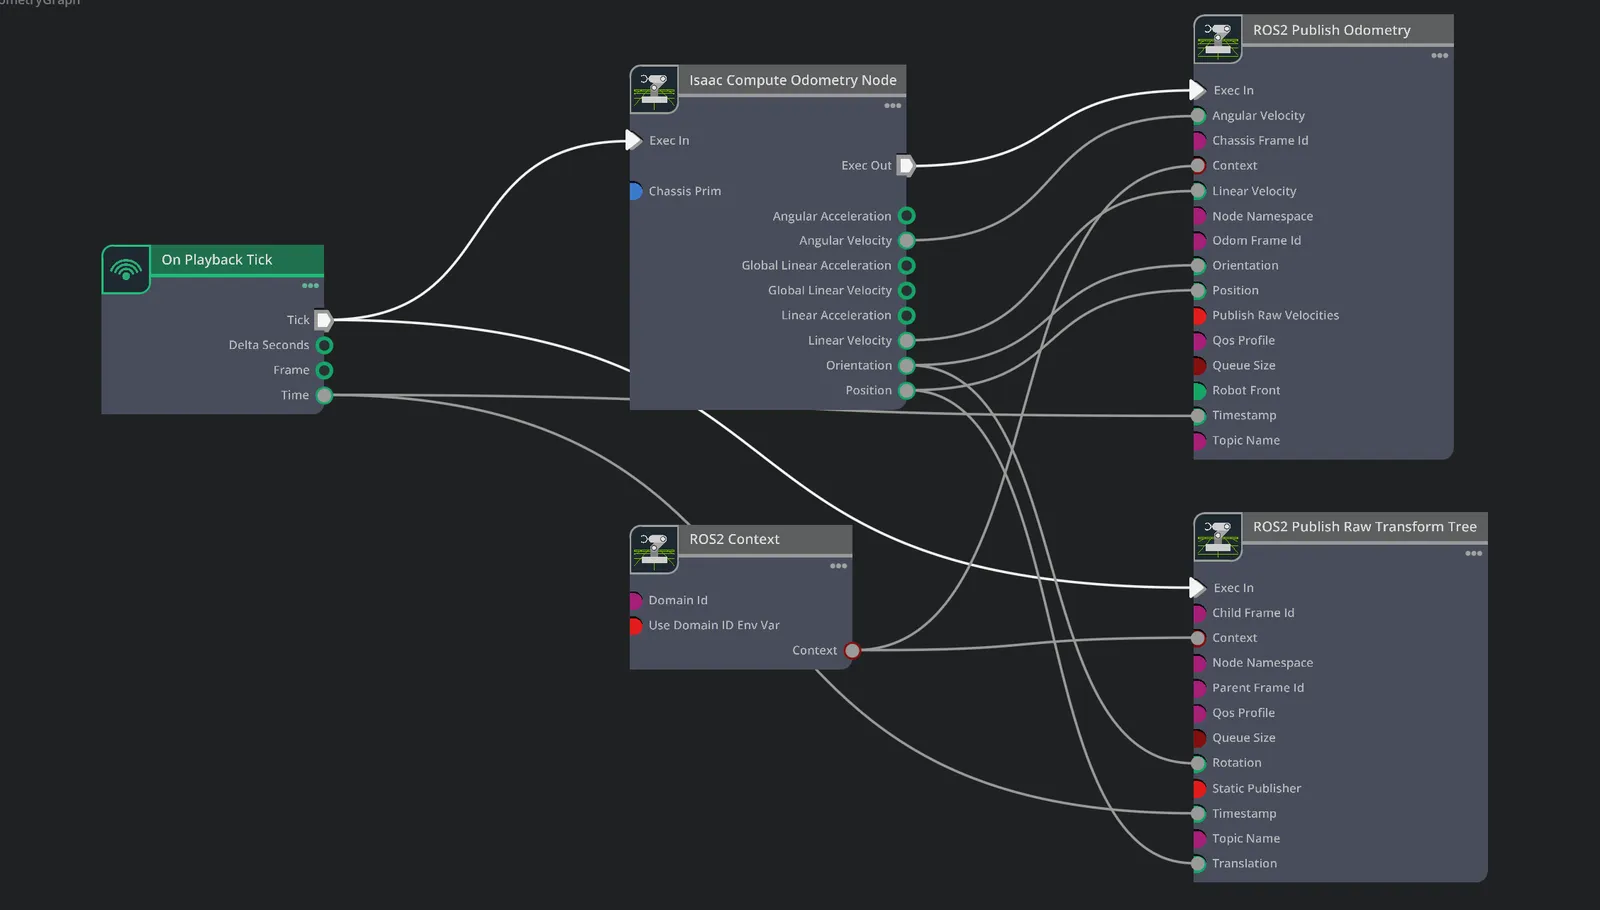
/World/forklift_b_OdometryGraph — Isaac Compute Odometry → ROS2 Publish Odometry (/forklift_b/odom) + ROS2 Publish Raw Transform Tree (TF).
Publishes the forklift’s odometry — where the robot thinks it is and how fast it is moving. IsaacComputeOdometry reads the chassis prim’s motion in the simulation and outputs position, orientation, and linear/angular velocity; two publishers then put that on the ROS 2 graph:
ROS2PublishOdometry→/forklift_b/odom(nav_msgs/Odometry)ROS2PublishRawTransformTree→ theforklift_b/odom→forklift_b/base_linkTF, so two trucks do not publish the same edge onto one/tf
Why it matters: downstream ROS 2 consumers (rviz, the forklift-controller’s closed-loop feedback, TF lookups) need a continuous pose + velocity estimate to know where the forklift is over time. Because this odometry is computed directly from the articulation transform in sim, it is clean pose feedback for the control loop — distinct from the Regression Testing Reporter ground truth on /gt/* (below), which exists to score perception against a known reference.
Config — the robots.yaml odometry: block:
robot_front tells IsaacComputeOdometry which local axis is the robot’s forward direction (the forklift asset’s forward is -X), so reported heading and velocity match the actual travel direction.
Safety Indicator Graph
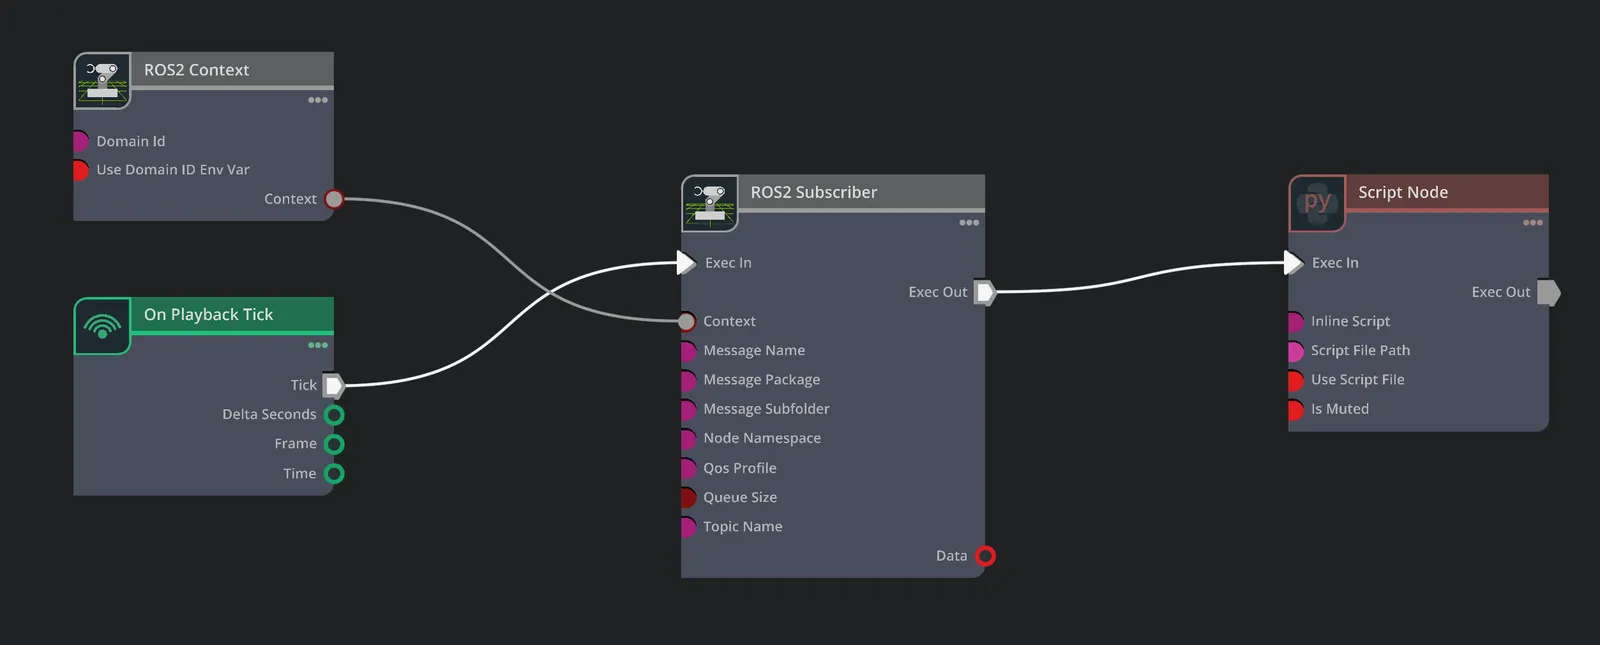
/World/forklift_b_SafetyGraph — ROS2 Subscriber (/safety/is_muted) → indicator Script Node that recolors the disk mesh.
Recolors the forklift’s indicator disc each tick from one of three sources. safety_indicator.source picks it, and defaults from PSF_APP:
The Script Node polls the subscriber’s outputs:data each tick rather than through a connection:
ROS2Subscriber creates that attribute dynamically, and a USD-authored connection to it is not
reliably bound by OmniGraph. Each color_* key in the block overrides a default.
The mute topic defaults to the per-robot /<name>/safety/is_muted, which the comm-layer publishes
for every robot in COMM_ROBOT_IDS; the shipped 20x20 fleet names the global /safety/is_muted
explicitly. With two ATL zones (atl-dual-override.yaml), the comm-layer publishes each robot’s
topic from the zone in its safety_indicator.zone (default 1).
Config — the robots.yaml safety_indicator: block (source, muted_topic, zone, color_*, indicator_prim; the disk defaults to <articulation_prim>/<indicator.parent_prim_rel>/safety_indicator from the model, and indicator_loader.py authors it, since no scene carries a baked one).
Difference from the VST overlay: this indicator is a 3D mesh in the simulation scene, visible to the cameras as part of the environment. It is separate from the VST/VIOS overlay (proximity bubble, Standard/Efficient Mode text) that VIOS renders on top of the video stream in the VST UI. The VST overlay is configured in VIOS config files and provides feedback in the monitoring interface; this indicator represents a simulated physical alarm light on the forklift.
Regression Testing Reporter Ground-Truth Graph (opt-in)
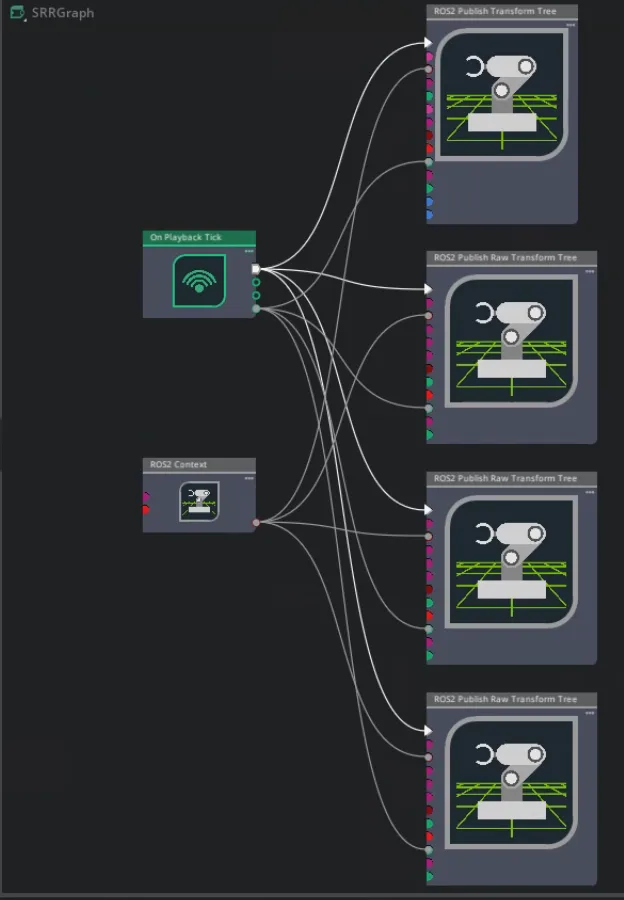
/World/SRRGraph — On Playback Tick + ROS2 Context drive four ROS2 Publish (Raw) Transform Tree nodes publishing /gt/*/tf.
Built only when run_actor_sdg.py is started with --srr-gt (default OFF). It publishes true poses on /gt/*/tf for the Regression Testing Reporter harness to score perception against:
- the forklift via
ROS2PublishTransformTree→/gt/forklift/tf - each pedestrian via
ROS2PublishRawTransformTree→/gt/character_<i>/tf, fed each frame from the character’s live Fabric world transform (the IRA-spawned characters walk in Fabric only, so the USD-authored transform stays frozen at the spawn pose).
On a normal Halos run the flag is absent and this module is never imported, so there is zero effect on the default pipeline. For how the ground truth is consumed, see Architecture.
Limitations
No lift control
The graphs control drive and steering only; the forks stay at a fixed height.
Customize for a new scene
Because shape lives in YAML, most changes are config-only:
- New robot — add a block to
robots.yaml(name,model,articulation_prim,spawn, and thecontrol/odometry/safety_indicatorsub-blocks you need) and a forklift-controller service naming itsROBOT_ID. No code change. - New camera — add an entry to
cameras.yamlwith a uniqueport. - Different forklift model — add a
models:entry with itsasset_path,wheelbase/wheel_radius/drive_joint/swivel_joint, and point the robot’smodelat it. - Relocated indicator mesh — set
safety_indicator.indicator_prim. - Turn a graph off — set
enabled: falseon that block.
See also
- Isaac Sim Configuration — scene, cameras, and motion authoring
- Forklift Controller — the service that publishes
cmd_veland consumes odometry - Extending the Fleet — add a truck, a drive type, or a scene
- Forklift Waypoint Generator — author curved forklift routes
- Architecture — how
/gt/*ground truth is scored