

Architecture
How the Regression Testing Reporter records the closed loop and turns it into a graded report. Read Overview first for the what and why.
Data flow (one scenario)
The Regression Testing Reporter runs three things in lockstep — Isaac Sim (ground truth + camera streams), the VSS + Safety Core stack (the decision), and the Regression Testing Reporter service (the recorder + scorer):
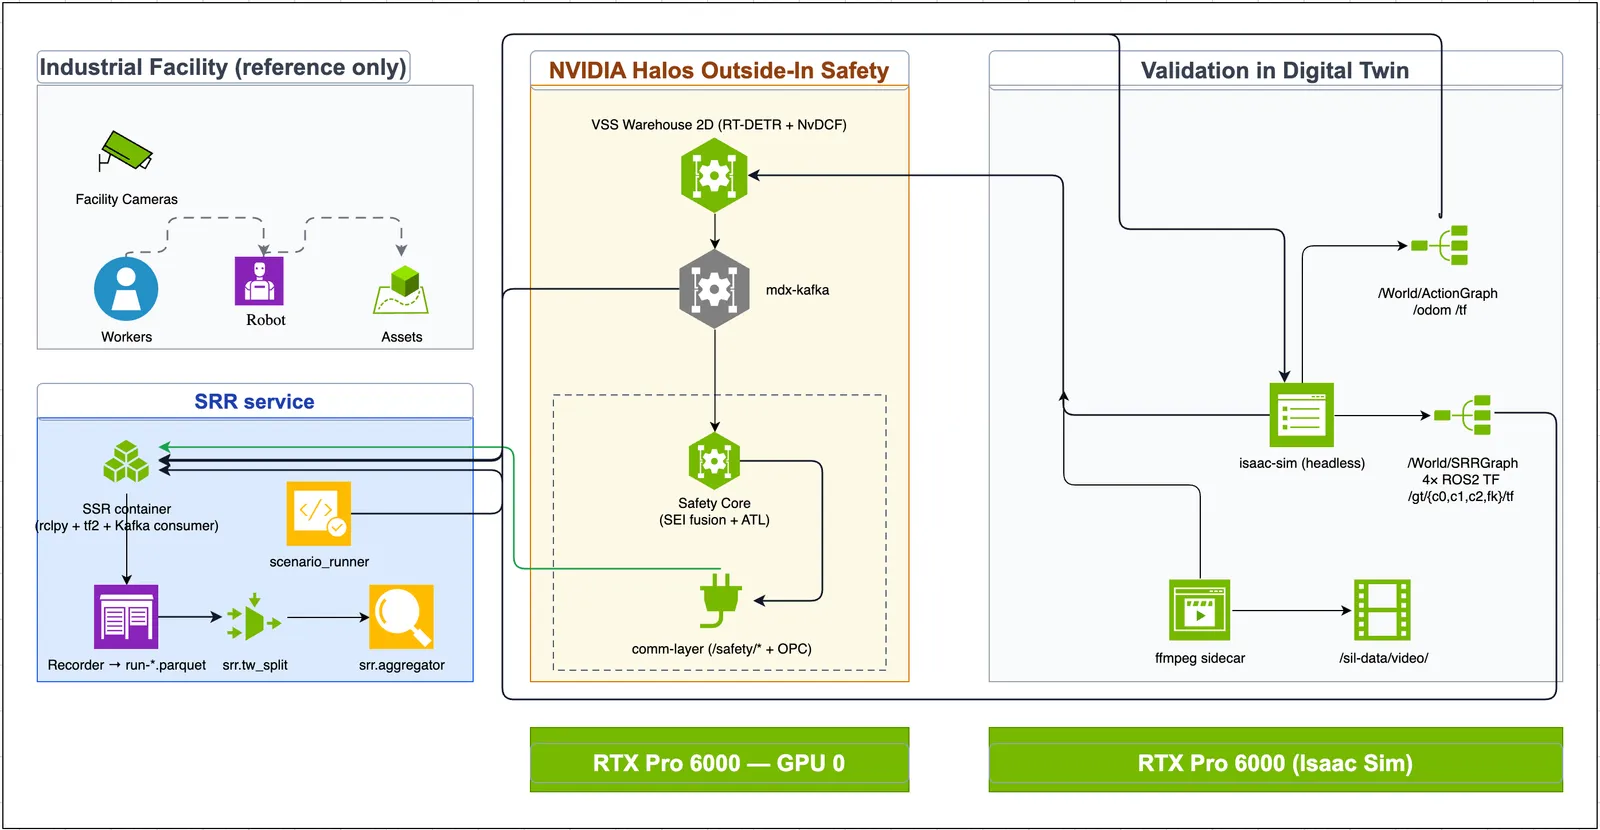
- Isaac Sim publishes true poses on
/gt/*(the reference, via the/World/SRRGraphROS 2 TF publishers — see Regression Testing Reporter Ground-Truth Graph (opt-in)) and hosts the three RTSP camera streams the perception stack consumes. - VSS turns those streams into Kafka events (
mdx-*); the Safety Core (PSF: SEI fusion + ATL) turns events into the MUTE / UNMUTE decision on/safety/*. - The Regression Testing Reporter service (rclpy + tf2 + Kafka consumers) records both the ground
truth and the decision into a single 30 Hz
parquetlog, thentw_splitandaggregatorsplit and score it.
In short: Regression Testing Reporter compares what the Safety Core decided (mute/unmute) against what ground truth said it should decide, and scores the perception feeding that decision.
The diagram labels perception as “VSS Warehouse 2D (RT-DETR + NvDCF)”. With the 3D profile, SIL deployments run VSS Warehouse 3.3 with Sparse4D 3D detections (mdx-bev / mdx-behavior), which is what enables the Phase 2 perception scores. A 2D-only feed still works and gives the Phase 1 safety-decision scores only.
Pipeline stages
A run advances through these stages per scenario:
- Restart — both the Halos and Regression Testing Reporter compose stacks are restarted for a fresh Safety Core state (counter drift otherwise carries across runs).
- Scene start — Isaac Sim loads the warehouse scene with
--srr-gt, which builds the/gt/*ground-truth publishers at run time (see Regression Testing Reporter Ground-Truth Graph (opt-in)). - Warm-up — a short settle so the first clip isn’t a cold-start outlier.
- Record —
/srr/record truestarts the 30 Hz capture;/srr/record falsestops it. One recording → onerun-*.parquet. - Split —
tw_splitcuts the recording into per-clip segments at each forklift trailer-tripwire crossing. - Aggregate — the aggregator scores each clip (Phase 1 + Phase 2) and
renders
summary.md,failures.json, and per-clipscn_*.md. - Video pull — per-clip review MP4s are pulled from VST.
Clip semantics
Each time the forklift’s x-coordinate crosses the trailer tripwire (TW_X, default 9.574) is a scene boundary. Consecutive boundaries delimit one clip (~40 s each). Roughly: a 5-minute recording → ~7 clips, 10 min → ~15, 20 min → ~30. The hazard (forklift entering/leaving the dock while people are near) forms around these crossings, which is why the Regression Testing Reporter centers clips on them.
Two scoring layers
Every recording is scored on two independent layers:
Phase 2 depends on the 3D pipeline (Sparse4D → mdx-bev + mdx-behavior) flowing. A 2D-only feed (only mdx-events) gives Phase 1 only — the Phase 2 section is simply omitted, which is expected, not a failure. See Interpreting the Report for what every metric means.
Recording schema
The recorder samples at 30 Hz (SAMPLE_HZ = 30). Enabling the 3D pipeline adds five nullable columns to the parquet, so a Phase-1-only deploy still records cleanly:
Setting the BEV_TOPIC or BEHAVIOR_TOPIC env to an empty string disables that consumer. Ground-truth, Safety Core state, and ba_events_json (ROI/TW) are always recorded (Phase 1).
Host and network layout
- Isaac Sim — digital twin, ground-truth publishers, and the three RTSP camera sources.
- VSS + Safety Core — perception (
vss-rtvi-cv), behavior analytics (vss-behavior-analytics), Kafka, and the Safety Core decision-maker. - Regression Testing Reporter service — a container that joins the host network so it can reach
ROS 2 (
/gt/*and/safety/*) and Kafka (mdx-*) directly.
All coordinates and zones come from the VSS calibration.json:
Fixture integration
The Regression Testing Reporter’s scenario fixtures (behavior trees + navmesh) must reach the isaac-sim container before Isaac launches. The default approach is a one-time sync (Pattern A): sync_to_halos.sh copies the canonical regression-reporter/scenarios/ fixtures (behavior trees + navmesh, plus the Script-Editor utilities and the default_config_ros.yaml template) into the Isaac SIL config tree. A planned follow-up (Pattern B) bind-mounts the scenarios/ dir into the container so edits appear without copying, so Pattern A is the default until it lands. The regression-reporter/scenarios/ copy is always canonical — edit there, then re-sync.
The sync command itself lives in the runbook — see Quick Start Guide Step 4 — and Test Scenarios for the fixtures themselves.
Orchestration: manual vs skill
The manual runner (scripts/run_multi.sh) executes every stage in sequence. The hoisa-generate-regression-report skill drives the same stages but inserts a readiness check between each phase boundary (instead of fixed sleeps) and prints a demo-friendly log. Its reference docs map to the pipeline stages:
The manual run_multi.sh always restarts both the Halos and Regression Testing Reporter compose stacks between scenarios, and the skill does the same. This cross-scenario isolation is required — Safety Core counter drift carries across runs and corrupts the next scenario’s results.
Next steps
- Test Scenarios — the pre-built test cases and how to regenerate them.
- Interpreting the Report — how to read the graded report.
- Debug Viewer — root-cause analysis for failing clips.