

Deploy AI Perception
This quick start guide covers setting up the environment and deploying the Halos Outside-In Safety Blueprint with sample data.
NVIDIA Halos Outside-In Blueprint Architecture
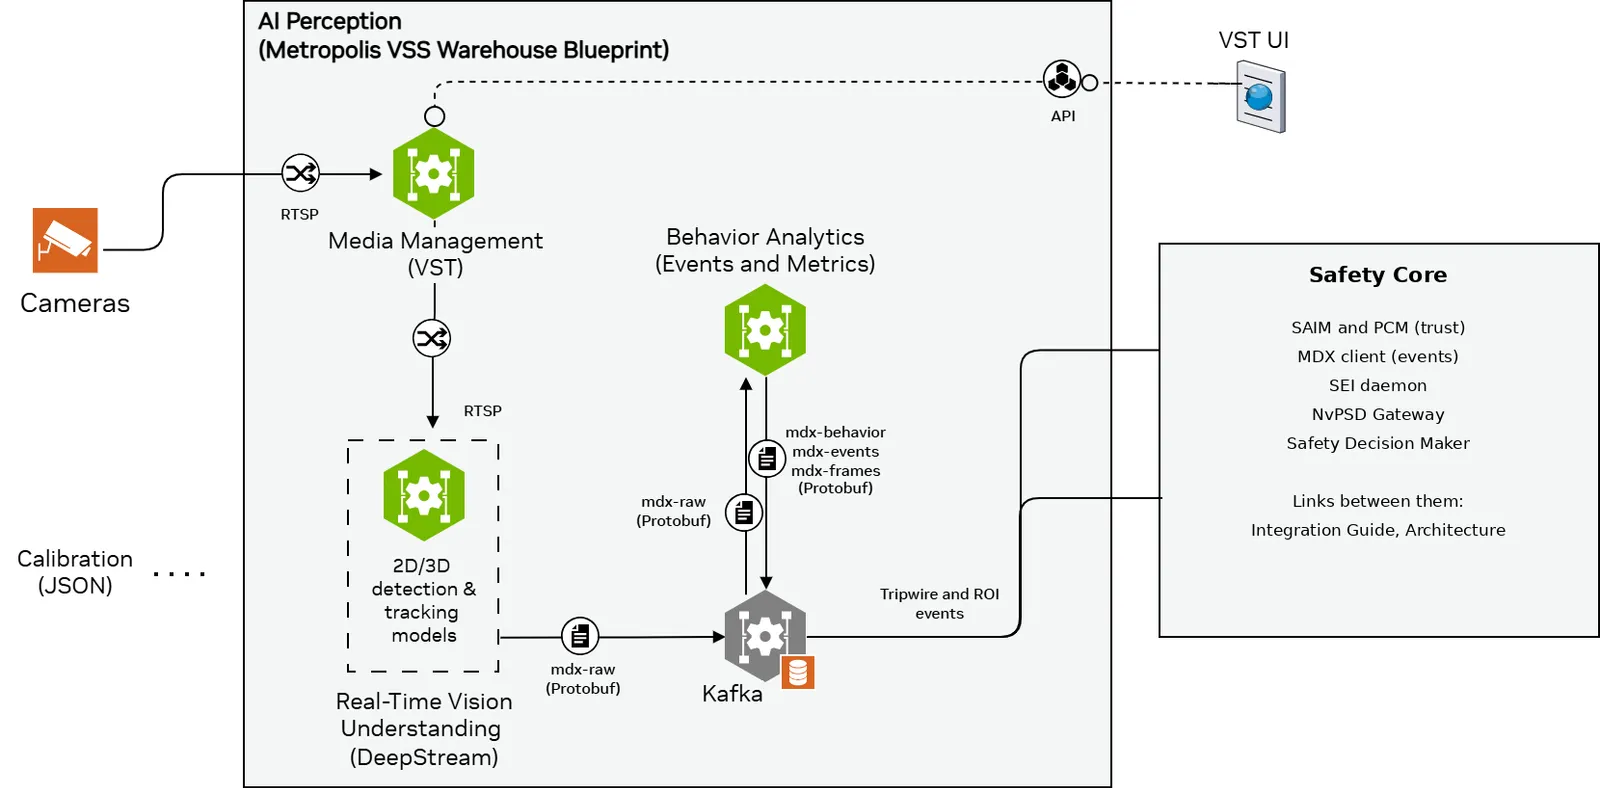
The current architecture consists of two main groups of components. This page uses the user-facing names. The Integration Guide describes the same system as architectural sub-elements, and the mapping is direct: AI Perception is the Sensor Input Processing Pipeline (SIPP), and Safety Core covers the Safety AI Monitor (SAIM), Perception Container Monitor (PCM), Safety Event Integrator (SEI), and Safety Decision Maker (SDM), along with the Safety Black Box (SBB) and Safety User Interface (SUI) that sit outside the mainstream data path.
This page covers AI Perception; the Safety Core components are introduced in Deploy the Safety Core.
AI Perception (Sensor Input Processing Pipeline)
This module detects safety events from 2D camera streams using advanced perception and behavior analytics tuned for warehouse environments. It continuously tracks people, forklifts, AMRs, and other moving assets and emits semantically rich events tied to safety zones and workflows. The system supports three primary event types:
- Region-of-interest (ROI) events: Triggered when objects enter or exit configured safety zones, enabling occupancy monitoring and enforcement of human‑free or equipment‑free areas.
- Tripwire events: Triggered when objects cross virtual lines placed at doors, dock edges, or aisle boundaries, enabling directional counting and presence inference in partially occluded or blind areas.
- Proximity events: Triggered when people and equipment come within unsafe distances, supporting pedestrian–vehicle collision avoidance and automatic slow‑down or stop behaviors.
Learn more about AI Perception component: VSS Warehouse Blueprint - 2D Vision AI and Perception Microservices Documentation.
Deploying Halos Outside-In
Halos Outside-In can be deployed in three levels:
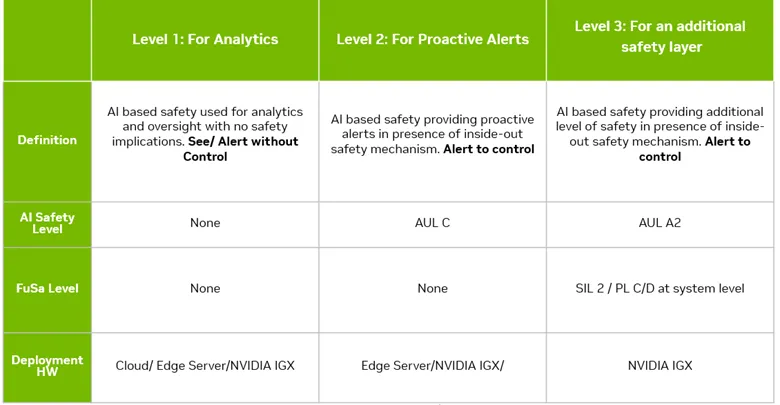
The deployment process includes these steps:
- Camera Selection, Placement and Calibration
- Installation of VSS Warehouse Blueprint
- Installation of Safety Event Integrator and Decision Maker
Camera Selection, Placement and Calibration Guidelines
(If you just want to try out Halos Outside-In with the sample videos packaged within the software, skip this step and proceed to the next step Installation of AI Perception.)
Camera model choice and configuration settings significantly impact detection latency. The method used to connect cameras to the compute platform greatly influences overall system latency.
Best Practices for Deployment
-
Use a Consistent Camera Model: Deploy the same camera model across all units to ensure uniform performance and predictable latency.
-
Standardize Camera Settings: Apply identical configuration settings to every camera in the deployment. This consistency is essential for reliable detection and optimal fusion of results by the safety supervisor, minimizing latency across the system.
-
Connection Method Matters: Ensure that all cameras connect to the compute platform using the same interface and topology to avoid introducing variable delays.
Optimal camera placement is crucial and should be tailored to your specific use case. Camera positioning significantly affects both accuracy and latency of safety event detection. For detailed guidance on camera positioning for best results, refer to the camera placement guide.
Once you place your camera, calibrate it by referring to the camera calibration guidelines.
Configuring Safety Zones and Tripwires is part of the camera calibration process and definitions of tripwires and zones are included in the calibration file.
Installation of AI Perception
System Requirements
The System and GPU requirement of AI Perception (VSS Warehouse Blueprint - 2D profile) is shown as below:
The stream counts are the 2D ceilings in the VSS blueprint configurator for each HARDWARE_PROFILE. The sample dataset used below has 3 cameras, which fits every row.
The minimum system requirements are:
- x86-64 architecture
- 18 core CPU
- 128 GB RAM
- 1 TB SSD
- 1 × 1 Gbps network interface
- 1 or 2 supported GPUs
For more details in hardware and software prerequisites please refer to VSS Warehouse Blueprint Prerequisites.
Installation Steps
1. Clone the VSS Warehouse repository
Halos Outside-In 1.4 runs on VSS Warehouse 3.3.0, GitHub release v3.3.0. Its container images are the release images in nvcr.io/nvidia/vss-core, tag 3.3.0; you need an NGC API key to pull them, for the sample data and for the models perception downloads at start. If you don’t have the NGC CLI installed, refer to the NGC CLI installation guide: https://org.ngc.nvidia.com/setup
The warehouse-operations profile, including the sample calibration data, lives under deploy/docker/industry-profiles/warehouse-operations/.
2. Download the sample data assets
Download the sample app data (videos and playback for the warehouse-loading-dock-3cams-synthetic dataset) from NGC and extract it:
Then prepare the data directories, the data-directory step of the VSS repository’s vss-build-vision-ai skill:
- Without
--org nvidia --team vss-warehouse, the NGC CLI stops atMissing org - If Authenticated, org is also required. - The archive extracts with mode
750, and the containers run as different non-root users: without this step Kafka exits withcluster_id: Permission deniedand Redis restarts in a loop onCan't open the log file: Permission denied. A directory still missing atupis created by Docker asroot, which those users cannot write. - The archive carries no models; perception downloads them into
models/at its first start.
3. Environment Settings
VSS 3.3 keeps the profile defaults in warehouse-operations/.env and the deployment settings in deploy/docker/industry-profiles/warehouse-operations/overrides.env, which Docker Compose reads last. Set these values in overrides.env; each comment gives the default where it differs:
Export two values in the shell that runs Docker Compose. containers.env expands the image tag before any env file is read, and perception reads the NGC key from the environment; never write the key into a file:
4. Deploy VSS Warehouse Blueprint
The two issues below have been observed only on safety-flashed
IGX Thor platforms (IGX Thor Developer Kit T7000 and Developer Kit Mini T5000): the
nvstreamer-2d container fails to start due to a missing NVIDIA
Container Runtime, and --pull always can intermittently fail
during image pulls. If you are deploying on one of these platforms,
apply the workarounds in Annex A before
running the deployment commands below.
The VSS 3.3.0 images are in nvcr.io/nvidia/vss-core and do not pull anonymously: log Docker in to nvcr.io with your NGC API key, the same login the Safety Core image needs. NGC CLI authentication only covers NGC resources, not Docker image pulls.
Validate the required VSS image pulls before starting Docker Compose:
Run Docker Compose from deploy/docker/ so the relative include paths resolve. The top-level compose.yml pulls in the shared infrastructure (Kafka, Redis), the perception app, and the warehouse-operations profile. Pass the three env files in this order; overrides.env must come last to win:
The VSS repository’s vss-build-vision-ai agent skill (warehouse profile) produces the same deployment from the answers above; see Agentic Deployment.
Verify the running VSS Warehouse Blueprint:
The _MINIMAL service list deploys no ELK/Kibana or monitoring. The Safety Core only needs the Kafka mdx-events and mdx-frames streams, so the VST dashboard and the mdx-events check below validate the perception feed. Use ${COMPOSE_PROFILES_WH_KAFKA_2D} instead for the extended deployment with the Kibana dashboard.
To render the safety decision as the on-video VST overlay, the same VST
config needs halo_safety_udp_port set — it ships disabled at -1.
See The VST safety overlay is on.
Before launching Safety Core, validate the streams and events that HOISA will consume:
VST sensor online status is not enough by itself. The exact
rtspUrl in sensor_config.conf must be playable before SAIM
and Safety Core are launched.
To relay validated ATL decision commands to VST, launch
atl_sdm_cmd_receiver with both --vst_ip <VST_IP> and
--vst_port <VST_PORT>. These options are paired: supplying only one
causes receiver startup to fail. The relay is optional; its delivery
failures do not interrupt command reception or acknowledgement. The
Proximity receiver has no VST relay and rejects both options. Continue
to use VST sensor status, RTSP playback, SAIM logs, Safety Core logs,
and Kafka events as deployment-health validation signals.
Stop VSS Warehouse Blueprint:
The models and the TensorRT engine stay under VSS_DATA_DIR/models/, so the next deployment reuses them.
Customization
It is supported to customize the VSS Warehouse Blueprint for user specific use cases, including adding new cameras, configuring different safety zones and tripwires, fine-tuning the AI perception models, etc.
For details please refer to the VSS Warehouse 2D Blueprint Customization Guide.
Installation of Safety Event Integrator and Decision Maker
Once the AI Perception is up and running, events are being generated from the input camera streams. To convert those events into actionable signals, continue with Deploy the Safety Core, which introduces the Safety Core components and walks the installation, launch, and verification steps.
Annex A: VSS Warehouse Blueprint deployment workarounds for safety-flashed IGX Thor
The two issues described in this annex have been observed only when deploying the VSS Warehouse Blueprint - 2D profile on safety-flashed IGX Thor systems (IGX Thor Developer Kit T7000 and Developer Kit Mini T5000). Deployment on other (non-safety-flashed) platforms is not affected.
Apply the corresponding workaround below before deploying on these systems. With these workarounds, VSS Warehouse 3.2.1 has been deployed successfully on safety-flashed IGX Thor systems. The IGX Thor flow has not been run on VSS 3.3 yet, so the commands in this annex are the VSS 3.2.1 ones (a single .env file).
a. nvstreamer-2d container fails to start (NVIDIA Container Runtime missing)
Issue: In the safety build with the Safety Extension Package (SEP),
runtime: nvidia is commented out in warehouse-2d-app.yml and the
NVIDIA Container Runtime is not selected automatically. As a result, the
nvstreamer-2d container fails to start with a runtime hook error.
Workaround: Add runtime: nvidia to the nvstreamer-2d service via a
Compose override. Create deploy/docker/docker-compose.override.yml with:
The deployment command passes -f compose.yml explicitly, which disables
auto-discovery of the override file, so add it with an extra -f flag when
starting the blueprint:
With this override, the nvstreamer-2d service (container
vss-vios-nvstreamer in docker ps) starts successfully.
b. Intermittent Docker image pull failures with —pull always
Issue: Deploying with --pull always re-fetches every service image on
each docker compose up and intermittently fails, blocking the deployment
during image pulls.
Workaround: Pre-pull the required images once while authenticated to
nvcr.io (see the Docker registry authentication step under
Installation of AI Perception), then start the blueprint without
--pull always so Docker Compose uses the locally cached images:
Prefer a local cache or an authenticated registry over anonymous Docker Hub pulls.