

RT-CV Performance
Overview
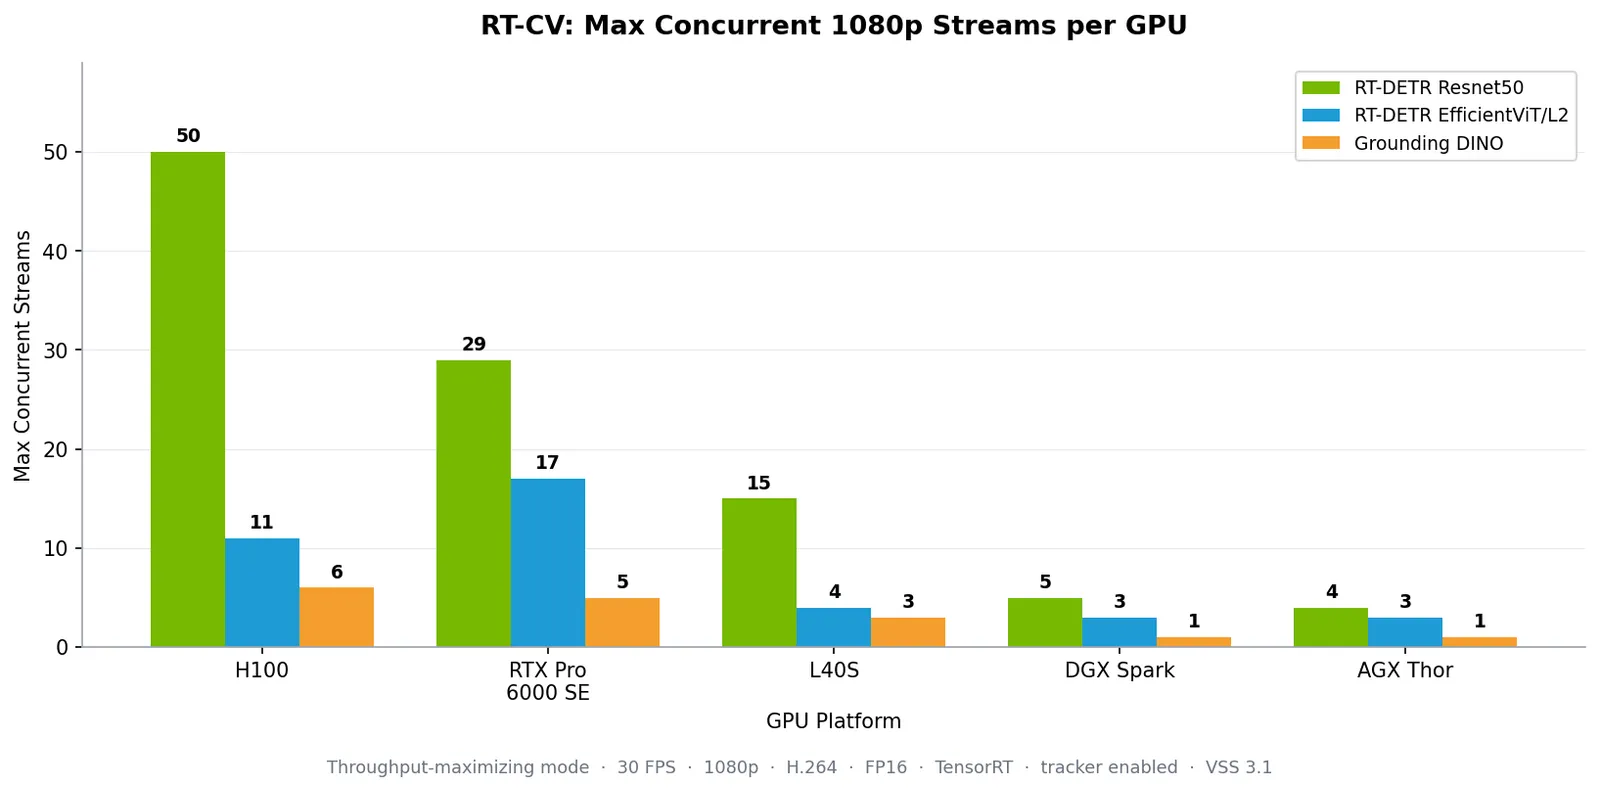
The Real-Time Computer Vision (RT-CV) microservice leverages the NVIDIA DeepStream SDK to perform continuous object detection and multi-object tracking on live RTSP streams. Benchmarks measure the maximum number of concurrent 1080p streams a single GPU can sustain at 30 FPS with object detection and tracker enabled.
Test Configuration
Performance by GPU
H100
RTX Pro 6000 SE
L40S
DGX Spark
AGX Thor
All benchmarks were measured at 30 FPS, 1080p, H.264 input, FP16 precision with TensorRT, and object tracker enabled. For production deployments, plan for 10–15% headroom below the maximum stream counts listed above.
* Grounding DINO on DGX Spark and AGX Thor is run with interval=1 — inference is
performed on every alternate frame to meet the reported stream counts.
Platform Limitations
Jetson Orin NX 8 GB (T234)
RT-DETR (Resnet50 backbone) at 1080p FP16 does not sustain 30 FPS on Jetson Orin NX 8 GB, even
with a single stream. A standalone TensorRT measurement (trtexec, batch size 1) on this
platform peaks at approximately 29 inferences per second, which is already below the 30 FPS
target before any decode, tracker, or message broker overhead is added. The perception pipeline
therefore reports 21–24 FPS for a single stream on this device.
To run the perception pipeline in real time on this platform, do one of the following:
- Set
interval=1in the[primary-gie]group of the DeepStream application configuration so that inference is performed on every alternate frame. The tracker maintains object continuity on the skipped frames, which halves the inference load and allows a 30 FPS input stream to be processed without frame drops. - Configure the source streams at 15 FPS instead of 30 FPS.
Jetson Orin NX 8 GB is not part of the validated platform list in Prerequisites. For 30 FPS deployments without an inference interval, use one of the validated platforms listed in the Performance by GPU tables above.
Jetson AGX Orin
The RT-CV container image is large relative to the storage typically available on a Jetson AGX
Orin device. The image is approximately 18 GB of compressed content and expands to approximately
48 GB on disk. When the filesystem that hosts the container storage root has less free space than
this, docker pull downloads all of the image layers and then fails during extraction with a
no space left on device error, and the RT-CV microservice does not start. Confirm that at
least 48 GB is free on that filesystem before deploying RT-CV on this platform. A reduction in
the RT-CV image size is planned for a future release.