

DeepStream-3D Multi-Modal V2XFusion Setup
The pipeline efficiently processes data from 4 cameras and 4 corresponding LiDARs, inferencing the 3D bboxes with a new model which combines the BEVFusion model and the BEVHeight model together to get more accurate detection result. This model is pre-trained by the DAIR-V2X dataset . The pipeline seamlessly employs ds3d::datafilter for triton inference. Ultimately, users can inferencing 4 cameras’ videos/images and the corresponding LiDARs’ data to detect 3D bboxes of different objects in road. The results can be visualized together with videos/images and projected LiDAR point clouds in different ways by different rendering configurations.
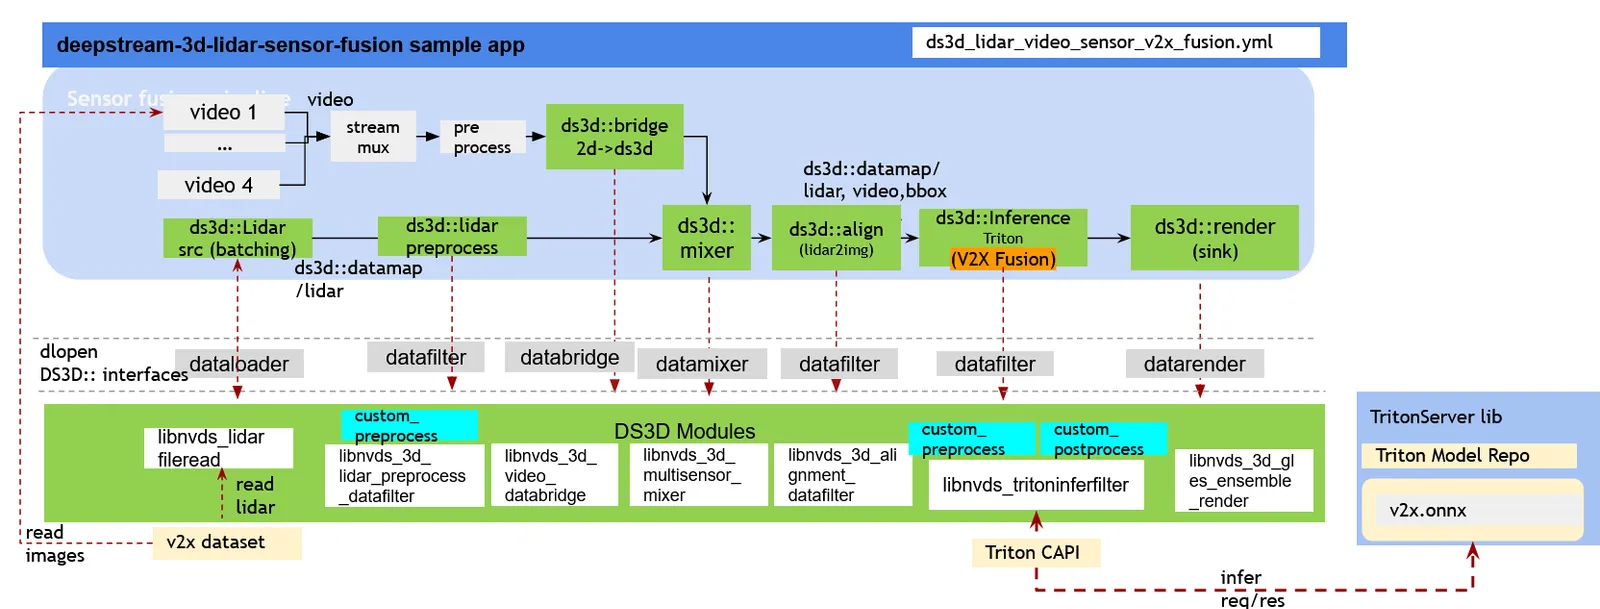
Prerequisites
Follow the instructions in the apps/sample_apps/deepstream-app/README file to install the prerequisites for common DeepStream SDK modules.
Follow the instructions in the samples/configs/deepstream-app-triton/README file to prepare the Triton Server environment.
The following development packages must be installed for DS3D sample apps:
- GStreamer-1.0
- GStreamer-1.0 Base Plugins
- GLES library
- libyaml-cpp-dev
Getting Started
Start the deepstream-triton base container for V2XFusion tests. Skip this step if users have installed Triton dependencies manually on Jetson host.
To get started, navigate to the following directory:
Download V2XFusion Models and Build TensorRT Engine Files
Download the pre-trained model from the V2XFusion pre-trained model download link and put it to the folder v2xfusion/models/v2xfusion.
Download the V2X-Seq-SPD (V2X-Seq Perception Dataset) example dataset from https://github.com/AIR-THU/DAIR-V2X and put the downloaded V2X-Seq-SPD-Example.zip in the v2xfusion/scripts folder.
Please ensure you have the latest python packages
Run the script to generate the model TensorRT engine file and ds3d required dataset.
Note: The example dataset is provided by https://github.com/AIR-THU/DAIR-V2X. For each dataset an user elects to use, the user is responsible for checking if the dataset license is fit for the intended purpose.
Start DS3D V2XFusion Pipeline
Build from source:
- To compile sample app deepstream-3d-lidar-sensor-fusion:
In Docker containers, sudo is not required for this install step.
NOTE: To compile the sources, run make with “sudo” or root permission.
- To compile the custom preprocessing and postprocessing libraries for the sample app deepstream-3d-lidar-sensor-fusion from source: