Skip to navigation

Interacting with a surface gripper

View as Markdown

This tutorial shows how to interact with an articulated robot with a surface gripper attached to its end-effector in the simulation. It is a continuation of the Interacting with an articulation tutorial, where we learned how to interact with an articulated robot. In Isaac Lab 3.0 with Isaac Sim 6.x, surface grippers support only CPU simulation. Run this tutorial with --device cpu.

The Code

The tutorial corresponds to the run_surface_gripper.py script in the scripts/tutorials/01_assets directory.

# Copyright (c) 2022-2026, The Isaac Lab Project Developers (https://github.com/isaac-sim/IsaacLab/blob/main/CONTRIBUTORS.md).
# All rights reserved.
#
# SPDX-License-Identifier: BSD-3-Clause
"""This script demonstrates how to spawn a pick-and-place robot equipped with a surface gripper and interact with it.
~~~bash
# Usage
uv run python scripts/tutorials/01_assets/run_surface_gripper.py --device=cpu
~~~
When running this script make sure the --device flag is set to cpu. This is because the surface gripper is
currently only supported on the CPU.
"""
"""Parse the command-line arguments first."""
import argparse
from isaaclab.app import add_launcher_args, launch_simulation
from isaaclab.utils import clone
# add argparse arguments
parser = argparse.ArgumentParser(description="Tutorial on spawning and interacting with a Surface Gripper.")
# append simulation launcher cli args
add_launcher_args(parser)
# tutorials should open Kit visualizer by default
parser.set_defaults(visualizer=["kit"])
# parse the arguments
args_cli = parser.parse_args()
"""Rest everything follows."""
import torch
import warp as wp
from isaaclab_physx.assets import SurfaceGripper, SurfaceGripperCfg
import isaaclab.sim as sim_utils
from isaaclab.assets import Articulation
from isaaclab.sim import SimulationContext
##
# Pre-defined configs
##
from isaaclab_assets import PICK_AND_PLACE_CFG # isort:skip
def design_scene():
"""Designs the scene."""
# Ground-plane
cfg = sim_utils.GroundPlaneCfg()
cfg.func("/World/defaultGroundPlane", cfg)
# Lights
cfg = sim_utils.DomeLightCfg(intensity=3000.0, color=(0.75, 0.75, 0.75))
cfg.func("/World/Light", cfg)
# Create separate groups called "Origin1", "Origin2"
# Each group will have a robot in it
origins = [[2.75, 0.0, 0.0], [-2.75, 0.0, 0.0]]
# Origin 1
sim_utils.create_prim("/World/Origin1", "Xform", translation=origins[0])
# Origin 2
sim_utils.create_prim("/World/Origin2", "Xform", translation=origins[1])
# Articulation: First we define the robot config
pick_and_place_robot_cfg = clone(PICK_AND_PLACE_CFG)
pick_and_place_robot_cfg.prim_path = "/World/Origin.*/Robot"
pick_and_place_robot = Articulation(cfg=pick_and_place_robot_cfg)
# Surface Gripper: Next we define the surface gripper config
surface_gripper_cfg = SurfaceGripperCfg()
# We need to tell the View which prim to use for the surface gripper
surface_gripper_cfg.prim_path = "/World/Origin.*/Robot/picker_head/SurfaceGripper"
# We can then set different parameters for the surface gripper, note that if these parameters are not set,
# the View will try to read them from the prim.
surface_gripper_cfg.max_grip_distance = 0.1 # [m] (Maximum distance at which the gripper can grasp an object)
surface_gripper_cfg.shear_force_limit = 500.0 # [N] (Force limit in the direction perpendicular direction)
surface_gripper_cfg.coaxial_force_limit = 500.0 # [N] (Force limit in the direction of the gripper's axis)
surface_gripper_cfg.retry_interval = 0.1 # seconds (Time the gripper will stay in a grasping state)
# We can now spawn the surface gripper
surface_gripper = SurfaceGripper(cfg=surface_gripper_cfg)
# return the scene information
scene_entities = {"pick_and_place_robot": pick_and_place_robot, "surface_gripper": surface_gripper}
return scene_entities, origins
def run_simulator(
sim: sim_utils.SimulationContext, entities: dict[str, Articulation | SurfaceGripper], origins: torch.Tensor
):
"""Runs the simulation loop."""
# Extract scene entities
robot: Articulation = entities["pick_and_place_robot"]
surface_gripper: SurfaceGripper = entities["surface_gripper"]
# Define simulation stepping
sim_dt = sim.get_physics_dt()
count = 0
# Simulation loop
while sim.is_running():
# Reset
if count % 500 == 0:
# reset counter
count = 0
# reset the scene entities
# root state
# we offset the root state by the origin since the states are written in simulation world frame
# if this is not done, then the robots will be spawned at the (0, 0, 0) of the simulation world
root_pose = robot.data.default_root_pose.torch.clone()
root_pose[:, :3] += origins
robot.write_root_pose_to_sim_index(root_pose=root_pose)
root_vel = robot.data.default_root_vel.torch.clone()
robot.write_root_velocity_to_sim_index(root_velocity=root_vel)
# set joint positions with some noise
joint_pos, joint_vel = (
robot.data.default_joint_pos.torch.clone(),
robot.data.default_joint_vel.torch.clone(),
)
joint_pos += torch.rand_like(joint_pos) * 0.1
robot.write_joint_position_to_sim_index(position=joint_pos)
robot.write_joint_velocity_to_sim_index(velocity=joint_vel)
# clear internal buffers
robot.reset()
print("[INFO]: Resetting robot state...")
# Opens the gripper and makes sure the gripper is in the open state
surface_gripper.reset()
print("[INFO]: Resetting gripper state...")
# Sample a random command between -1 and 1.
gripper_commands = torch.rand(surface_gripper.num_instances) * 2.0 - 1.0
# The gripper behavior is as follows:
# -1 < command < -0.3 --> Gripper is Opening
# -0.3 < command < 0.3 --> Gripper is Idle
# 0.3 < command < 1 --> Gripper is Closing
print(f"[INFO]: Gripper commands: {gripper_commands}")
mapped_commands = [
"Opening" if command < -0.3 else "Closing" if command > 0.3 else "Idle" for command in gripper_commands
]
print(f"[INFO]: Mapped commands: {mapped_commands}")
# Set the gripper command
surface_gripper.set_grippers_command(gripper_commands)
# Write data to sim
surface_gripper.write_data_to_sim()
# Perform step
sim.step()
# Increment counter
count += 1
# Read the gripper state from the simulation
surface_gripper.update(sim_dt)
# Read the gripper state from the buffer
surface_gripper_state = surface_gripper.state
# The gripper state is a list of integers that can be mapped to the following:
# -1 --> Open
# 0 --> Closing
# 1 --> Closed
# Print the gripper state
print(f"[INFO]: Gripper state: {surface_gripper_state}")
mapped_commands = [
"Open" if state == -1 else "Closing" if state == 0 else "Closed"
for state in wp.to_torch(surface_gripper_state).tolist()
]
print(f"[INFO]: Mapped commands: {mapped_commands}")
def main():
"""Main function."""
# Configure the simulation
sim_cfg = sim_utils.SimulationCfg(device=args_cli.device)
# Launch the simulator runtime that the configuration needs
with launch_simulation(sim_cfg, args_cli):
# Initialize the simulation context
sim = SimulationContext(sim_cfg)
# Set main camera
sim.set_camera_view([2.75, 7.5, 10.0], [2.75, 0.0, 0.0])
# Design scene
scene_entities, scene_origins = design_scene()
scene_origins = torch.tensor(scene_origins, device=sim.device)
# Play the simulator
sim.reset()
# Now we are ready!
print("[INFO]: Setup complete...")
# Run the simulator
run_simulator(sim, scene_entities, scene_origins)
if __name__ == "__main__":
# run the main function
main()

The Code Explained

Designing the scene

Similarly to the previous tutorial, we populate the scene with a ground plane and a distant light. Then, we spawn an articulation from its USD file. This time a pick-and-place robot is spawned. The pick-and-place robot is a simple robot with 3 driven axes, its gantry allows it to move along the x and y axes, as well as up and down along the z-axis. Furthermore, the robot end-effector is outfitted with a surface gripper. The USD file for the pick-and-place robot contains the robot’s geometry, joints, and other physical properties as well as the surface gripper. Before implementing a similar gripper on your own robot, we recommend to check out the USD file for the gripper found on Isaaclab’s Nucleus.

For the pick-and-place robot, we use its pre-defined configuration object, you can find out more about it in the Robot and articulation configuration tutorial. For the surface gripper, we also need to create a configuration object. This is done by instantiating a assets.SurfaceGripperCfg object and passing it the relevant parameters.

The available parameters are:

  • max_grip_distance: The maximum distance at which the gripper can grasp an object.
  • shear_force_limit: The maximum force the gripper can exert in the direction perpendicular to the gripper’s axis.
  • coaxial_force_limit: The maximum force the gripper can exert in the direction of the gripper’s axis.
  • retry_interval: The time the gripper will stay in a grasping state.

As seen in the previous tutorial, we can spawn the articulation into the scene in a similar fashion by creating an instance of the assets.Articulation class by passing the configuration object to its constructor. The same principle applies to the surface gripper. By passing the configuration object to the assets.SurfaceGripper constructor, the surface gripper is created and can be added to the scene. In practice, the object will only be initialized when the play button is pressed.

# Create separate groups called "Origin1", "Origin2"
# Each group will have a robot in it
origins = [[2.75, 0.0, 0.0], [-2.75, 0.0, 0.0]]
# Origin 1
sim_utils.create_prim("/World/Origin1", "Xform", translation=origins[0])
# Origin 2
sim_utils.create_prim("/World/Origin2", "Xform", translation=origins[1])
# Articulation: First we define the robot config
pick_and_place_robot_cfg = clone(PICK_AND_PLACE_CFG)
pick_and_place_robot_cfg.prim_path = "/World/Origin.*/Robot"
pick_and_place_robot = Articulation(cfg=pick_and_place_robot_cfg)
# Surface Gripper: Next we define the surface gripper config
surface_gripper_cfg = SurfaceGripperCfg()
# We need to tell the View which prim to use for the surface gripper
surface_gripper_cfg.prim_path = "/World/Origin.*/Robot/picker_head/SurfaceGripper"
# We can then set different parameters for the surface gripper, note that if these parameters are not set,
# the View will try to read them from the prim.
surface_gripper_cfg.max_grip_distance = 0.1 # [m] (Maximum distance at which the gripper can grasp an object)
surface_gripper_cfg.shear_force_limit = 500.0 # [N] (Force limit in the direction perpendicular direction)
surface_gripper_cfg.coaxial_force_limit = 500.0 # [N] (Force limit in the direction of the gripper's axis)
surface_gripper_cfg.retry_interval = 0.1 # seconds (Time the gripper will stay in a grasping state)
# We can now spawn the surface gripper
surface_gripper = SurfaceGripper(cfg=surface_gripper_cfg)

Running the simulation loop

Continuing from the previous tutorial, we reset the simulation at regular intervals, set commands to the articulation, step the simulation, and update the articulation’s internal buffers.

Resetting the simulation

To reset the surface gripper, we only need to call the SurfaceGripper.reset method which will reset the internal buffers and caches.

# Opens the gripper and makes sure the gripper is in the open state
surface_gripper.reset()

Stepping the simulation

Applying commands to the surface gripper involves two steps:

  1. Setting the desired commands: This sets the desired gripper commands (Open, Close, or Idle).
  2. Writing the data to the simulation: Based on the surface gripper’s configuration, this step handles writes the converted values to the PhysX buffer.

In this tutorial, we use a random command to set the gripper’s command. The gripper behavior is as follows:

  • -1 < command < -0.3 —> Gripper is Opening
  • -0.3 < command < 0.3 —> Gripper is Idle
  • 0.3 < command < 1 —> Gripper is Closing

At every step, we randomly sample commands and set them to the gripper by calling the SurfaceGripper.set_grippers_command method. After setting the commands, we call the SurfaceGripper.write_data_to_sim method to write the data to the PhysX buffer. Finally, we step the simulation.

# Sample a random command between -1 and 1.
gripper_commands = torch.rand(surface_gripper.num_instances) * 2.0 - 1.0
# The gripper behavior is as follows:
# -1 < command < -0.3 --> Gripper is Opening
# -0.3 < command < 0.3 --> Gripper is Idle
# 0.3 < command < 1 --> Gripper is Closing
print(f"[INFO]: Gripper commands: {gripper_commands}")
mapped_commands = [
"Opening" if command < -0.3 else "Closing" if command > 0.3 else "Idle" for command in gripper_commands
]
print(f"[INFO]: Mapped commands: {mapped_commands}")
# Set the gripper command
surface_gripper.set_grippers_command(gripper_commands)
# Write data to sim
surface_gripper.write_data_to_sim()

Updating the state

To know the current state of the surface gripper, we can query the assets.SurfaceGripper.state property. This property returns a tensor of size [num_envs] where each element is either -1, 0, or 1 corresponding to the gripper state. This property is updated every time the assets.SurfaceGripper.update method is called.

  • -1 —> Gripper is Open
  • 0 —> Gripper is Closing
  • 1 —> Gripper is Closed
# Read the gripper state from the simulation
surface_gripper.update(sim_dt)
# Read the gripper state from the buffer
surface_gripper_state = surface_gripper.state

The Code Execution

To run the code and see the results, let’s run the script from the terminal:

This command should open a stage with a ground plane, lights, and two pick-and-place robots. In the terminal, you should see the gripper state and the command being printed. To stop the simulation, you can either close the window, or press Ctrl+C in the terminal.
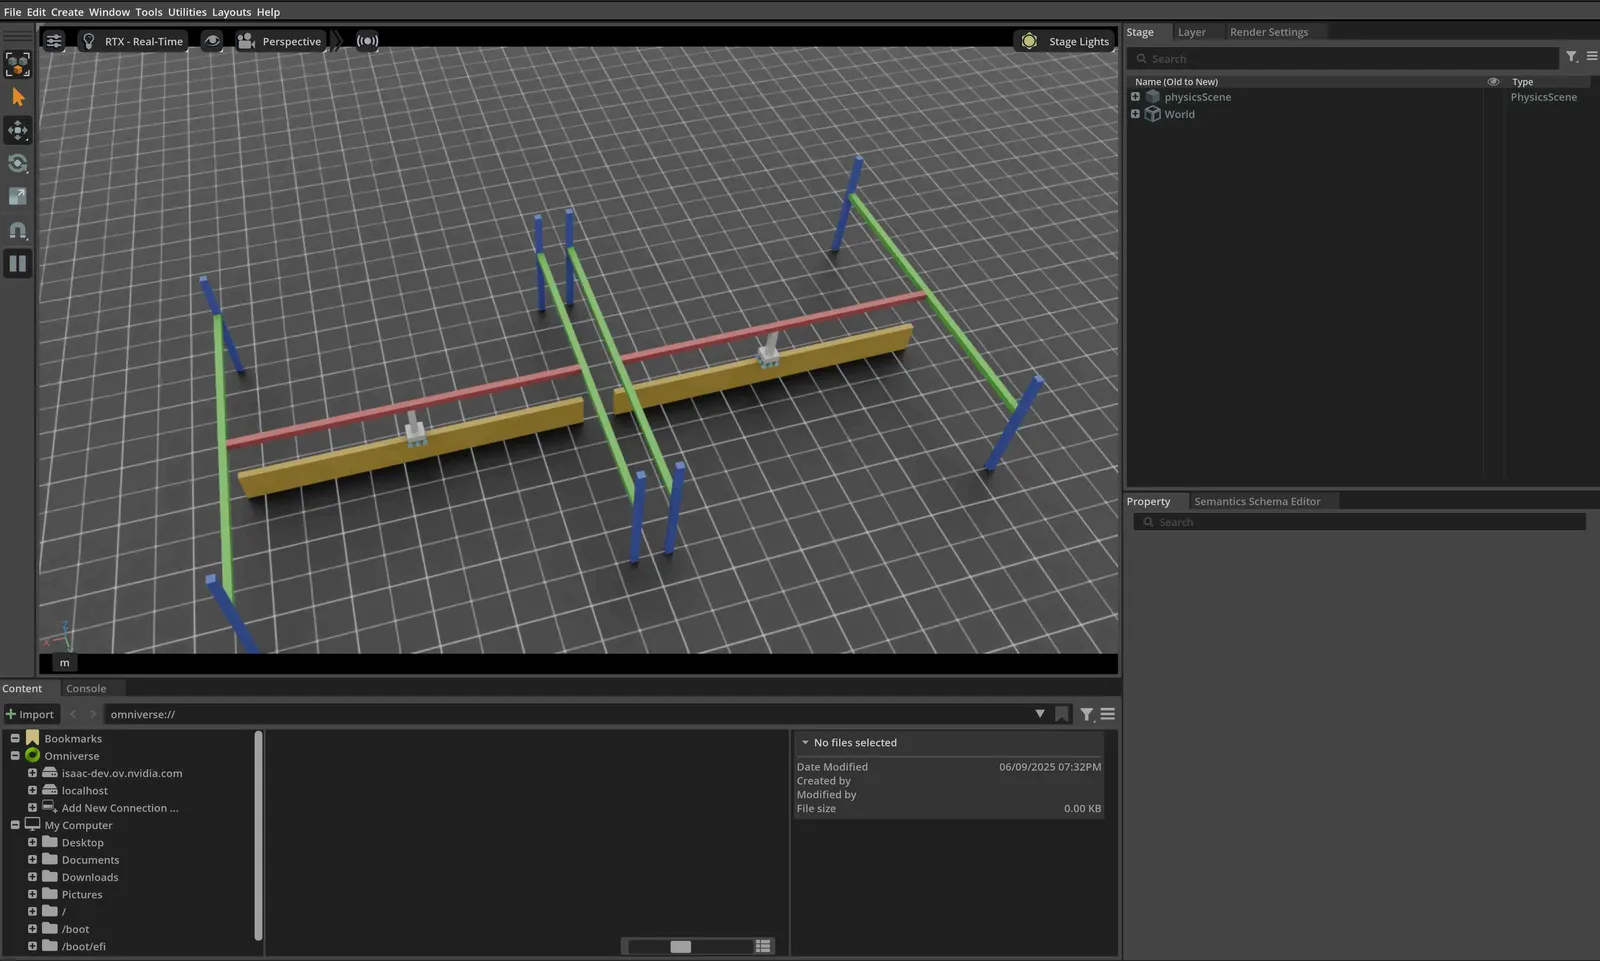
result of run_surface_gripper.py

In this tutorial, we learned how to create and interact with a surface gripper. We saw how to set commands and query the gripper state. We also saw how to update its buffers to read the latest state from the simulation.

In addition to this tutorial, we also provide a few other scripts that spawn different robots. These are included through the packaged demo command. You can run it as:

Note that in practice, the users would be expected to register their assets.SurfaceGripper instances inside a isaaclab.InteractiveScene object, which will automatically handle the calls to the assets.SurfaceGripper.write_data_to_sim and assets.SurfaceGripper.update methods.

# Create a scene
scene = InteractiveScene()
# Register the surface gripper
scene.surface_grippers["gripper"] = surface_gripper