Skip to navigation

Using an operational space controller

View as Markdown

Sometimes, controlling the end-effector pose of the robot using a differential IK controller is not sufficient. For example, we might want to enforce a very specific pose tracking error dynamics in the task space, actuate the robot with joint effort/torque commands, or apply a contact force at a specific direction while controlling the motion of the other directions (e.g., washing the surface of the table with a cloth). In such tasks, we can use an operational space controller (OSC).

References for the operational space control:

  1. O Khatib. A unified approach for motion and force control of robot manipulators: The operational space formulation. IEEE Journal of Robotics and Automation, 3(1):43–53, 1987. URL http://dx.doi.org/10.1109/JRA.1987.1087068.

  2. Robot Dynamics Lecture Notes by Marco Hutter (ETH Zurich). URL https://ethz.ch/content/dam/ethz/special-interest/mavt/robotics-n-intelligent-systems/rsl-dam/documents/RobotDynamics2017/RD_HS2017script.pdf

In this tutorial, we will learn how to use an OSC to control the robot. We will use the controllers.OperationalSpaceController class to apply a constant force perpendicular to a tilted wall surface while tracking a desired end-effector pose in all the other directions.

This tutorial uses Isaac Sim PhysX and requires an Isaac Sim installation. The target quaternions use (x, y, z, w) order and orient the end-effector toward the tilted wall. For controller selection and the control-loop walkthrough, see ../concepts/motion_generators.

The Code

The tutorial corresponds to the run_osc.py script in the scripts/tutorials/05_controllers directory.

# Copyright (c) 2022-2026, The Isaac Lab Project Developers (https://github.com/isaac-sim/IsaacLab/blob/main/CONTRIBUTORS.md).
# All rights reserved.
#
# SPDX-License-Identifier: BSD-3-Clause
"""
This script demonstrates how to use the operational space controller (OSC) with the simulator.
The OSC controller can be configured in different modes. It uses the dynamical quantities such as Jacobians and
mass matricescomputed by PhysX.
~~~bash
# Usage
uv run python scripts/tutorials/05_controllers/run_osc.py
~~~
"""
"""Parse the command-line arguments first."""
import argparse
from typing import TYPE_CHECKING
from isaaclab.app import add_launcher_args, launch_simulation
# add argparse arguments
parser = argparse.ArgumentParser(description="Tutorial on using the operational space controller.")
parser.add_argument("--num_envs", type=int, default=128, help="Number of environments to spawn.")
# append simulation launcher cli args
add_launcher_args(parser)
# parse the arguments
args_cli = parser.parse_args()
"""Rest everything follows."""
import torch
import isaaclab.sim as sim_utils
from isaaclab.assets import Articulation, AssetBaseCfg
from isaaclab.controllers import OperationalSpaceController, OperationalSpaceControllerCfg
from isaaclab.markers import VisualizationMarkers
from isaaclab.markers.config import FRAME_MARKER_CFG
from isaaclab.scene import InteractiveSceneCfg
from isaaclab.sensors import ContactSensorCfg
from isaaclab.utils import clone, configclass, instantiate, replace
from isaaclab.utils.math import (
combine_frame_transforms,
matrix_from_quat,
quat_apply_inverse,
quat_inv,
subtract_frame_transforms,
)
if TYPE_CHECKING:
from isaaclab.scene import InteractiveScene
##
# Pre-defined configs
##
from isaaclab_assets import FRANKA_PANDA_HIGH_PD_CFG # isort:skip
@configclass
class SceneCfg(InteractiveSceneCfg):
"""Configuration for a simple scene with a tilted wall."""
# ground plane
ground = AssetBaseCfg(
prim_path="/World/defaultGroundPlane",
spawn=sim_utils.GroundPlaneCfg(),
)
# lights
dome_light = AssetBaseCfg(
prim_path="/World/Light", spawn=sim_utils.DomeLightCfg(intensity=3000.0, color=(0.75, 0.75, 0.75))
)
# Tilted wall
tilted_wall = AssetBaseCfg(
prim_path="{ENV_REGEX_NS}/TiltedWall",
spawn=sim_utils.CuboidCfg(
size=(2.0, 1.5, 0.01),
collision_props=sim_utils.UsdPhysicsCollisionCfg(),
visual_material=sim_utils.PreviewSurfaceCfg(diffuse_color=(1.0, 0.0, 0.0), opacity=0.1),
rigid_props=sim_utils.UsdPhysicsRigidBodyCfg(kinematic_enabled=True),
activate_contact_sensors=True,
),
init_state=AssetBaseCfg.InitialStateCfg(
pos=(0.6 + 0.085, 0.0, 0.3), rot=(0.0, -0.3826834324, 0.0, 0.9238795325)
),
)
contact_forces = ContactSensorCfg(
prim_path="/World/envs/env_.*/TiltedWall",
update_period=0.0,
history_length=2,
debug_vis=False,
)
robot = replace(FRANKA_PANDA_HIGH_PD_CFG, prim_path="{ENV_REGEX_NS}/Robot")
robot.spawn.variants["Physics"] = "physx"
robot.actuators["panda_arm"].stiffness = 0.0
robot.actuators["panda_arm"].damping = 0.0
robot.spawn.rigid_props.disable_gravity = True
def run_simulator(sim: sim_utils.SimulationContext, scene: "InteractiveScene"):
"""Runs the simulation loop.
Args:
sim: (SimulationContext) Simulation context.
scene: (InteractiveScene) Interactive scene.
"""
# Extract scene entities for readability.
robot = scene["robot"]
contact_forces = scene["contact_forces"]
# Obtain indices for the end-effector and arm joints
ee_frame_name = "panda_leftfinger"
arm_joint_names = ["panda_joint.*"]
ee_frame_idx = robot.find_bodies(ee_frame_name)[0][0]
arm_joint_ids = robot.find_joints(arm_joint_names)[0]
# Create the OSC
osc_cfg = OperationalSpaceControllerCfg(
target_types=["pose_abs", "wrench_abs"],
impedance_mode="variable_kp",
inertial_dynamics_decoupling=True,
partial_inertial_dynamics_decoupling=False,
gravity_compensation=False,
motion_damping_ratio_task=1.0,
contact_wrench_stiffness_task=[0.0, 0.0, 0.1, 0.0, 0.0, 0.0],
motion_control_axes_task=[1, 1, 0, 1, 1, 1],
contact_wrench_control_axes_task=[0, 0, 1, 0, 0, 0],
nullspace_control="position",
)
osc = OperationalSpaceController(osc_cfg, num_envs=scene.num_envs, device=sim.device)
# Markers
frame_marker_cfg = clone(FRAME_MARKER_CFG)
frame_marker_cfg.markers["frame"].scale = (0.1, 0.1, 0.1)
ee_marker = VisualizationMarkers(replace(frame_marker_cfg, prim_path="/Visuals/ee_current"))
goal_marker = VisualizationMarkers(replace(frame_marker_cfg, prim_path="/Visuals/ee_goal"))
# Define targets for the arm (x,y,z,qx,qy,qz,qw)
ee_goal_pose_set_tilted_b = torch.tensor(
[
[0.6, 0.15, 0.3, 0.92387953, 0.0, 0.38268343, 0.0],
[0.6, -0.3, 0.3, 0.92387953, 0.0, 0.38268343, 0.0],
[0.8, 0.0, 0.5, 0.92387953, 0.0, 0.38268343, 0.0],
],
device=sim.device,
)
ee_goal_wrench_set_tilted_task = torch.tensor(
[
[0.0, 0.0, 10.0, 0.0, 0.0, 0.0],
[0.0, 0.0, 10.0, 0.0, 0.0, 0.0],
[0.0, 0.0, 10.0, 0.0, 0.0, 0.0],
],
device=sim.device,
)
kp_set_task = torch.tensor(
[
[360.0, 360.0, 360.0, 360.0, 360.0, 360.0],
[420.0, 420.0, 420.0, 420.0, 420.0, 420.0],
[320.0, 320.0, 320.0, 320.0, 320.0, 320.0],
],
device=sim.device,
)
ee_target_set = torch.cat([ee_goal_pose_set_tilted_b, ee_goal_wrench_set_tilted_task, kp_set_task], dim=-1)
# Define simulation stepping
sim_dt = sim.get_physics_dt()
# Update existing buffers
# Note: We need to update buffers before the first step for the controller.
robot.update(dt=sim_dt)
# Get the center of the robot soft joint limits
joint_centers = torch.mean(robot.data.soft_joint_pos_limits.torch[:, arm_joint_ids, :], dim=-1)
# get the updated states
(
jacobian_b,
mass_matrix,
gravity,
ee_pose_b,
ee_vel_b,
root_pose_w,
ee_pose_w,
ee_force_b,
joint_pos,
joint_vel,
) = update_states(sim, scene, robot, ee_frame_idx, arm_joint_ids, contact_forces)
# Track the given target command
current_goal_idx = 0 # Current goal index for the arm
command = torch.zeros(
scene.num_envs, osc.action_dim, device=sim.device
) # Generic target command, which can be pose, position, force, etc.
ee_target_pose_b = torch.zeros(scene.num_envs, 7, device=sim.device) # Target pose in the body frame
ee_target_pose_w = torch.zeros(scene.num_envs, 7, device=sim.device) # Target pose in the world frame (for marker)
# Set joint efforts to zero
zero_joint_efforts = torch.zeros(scene.num_envs, robot.num_joints, device=sim.device)
joint_efforts = torch.zeros(scene.num_envs, len(arm_joint_ids), device=sim.device)
count = 0
# Simulation loop
while sim.is_running():
# reset every 500 steps
if count % 500 == 0:
# reset joint state to default
default_joint_pos = robot.data.default_joint_pos.torch.clone()
default_joint_vel = robot.data.default_joint_vel.torch.clone()
robot.write_joint_position_to_sim_index(position=default_joint_pos)
robot.write_joint_velocity_to_sim_index(velocity=default_joint_vel)
robot.set_joint_effort_target_index(target=zero_joint_efforts) # Set zero torques in the initial step
robot.write_data_to_sim()
robot.reset()
# reset contact sensor
contact_forces.reset()
# reset target pose
robot.update(sim_dt)
_, _, _, ee_pose_b, _, _, _, _, _, _ = update_states(
sim, scene, robot, ee_frame_idx, arm_joint_ids, contact_forces
) # at reset, the jacobians are not updated to the latest state
command, ee_target_pose_b, ee_target_pose_w, current_goal_idx = update_target(
sim, scene, osc, root_pose_w, ee_target_set, current_goal_idx
)
# set the osc command
osc.reset()
command, task_frame_pose_b = convert_to_task_frame(osc, command=command, ee_target_pose_b=ee_target_pose_b)
osc.set_command(command=command, current_ee_pose_b=ee_pose_b, current_task_frame_pose_b=task_frame_pose_b)
else:
# get the updated states
(
jacobian_b,
mass_matrix,
gravity,
ee_pose_b,
ee_vel_b,
root_pose_w,
ee_pose_w,
ee_force_b,
joint_pos,
joint_vel,
) = update_states(sim, scene, robot, ee_frame_idx, arm_joint_ids, contact_forces)
# compute the joint commands
joint_efforts = osc.compute(
jacobian_b=jacobian_b,
current_ee_pose_b=ee_pose_b,
current_ee_vel_b=ee_vel_b,
current_ee_force_b=ee_force_b,
mass_matrix=mass_matrix,
gravity=gravity,
current_joint_pos=joint_pos,
current_joint_vel=joint_vel,
nullspace_joint_pos_target=joint_centers,
)
# apply actions
robot.set_joint_effort_target_index(target=joint_efforts, joint_ids=arm_joint_ids)
robot.write_data_to_sim()
# update marker positions
ee_marker.visualize(ee_pose_w[:, 0:3], ee_pose_w[:, 3:7])
goal_marker.visualize(ee_target_pose_w[:, 0:3], ee_target_pose_w[:, 3:7])
# perform step
sim.step(render=True)
# update robot buffers
robot.update(sim_dt)
# update buffers
scene.update(sim_dt)
# update sim-time
count += 1
# Update robot states
def update_states(
sim: sim_utils.SimulationContext,
scene: "InteractiveScene",
robot: Articulation,
ee_frame_idx: int,
arm_joint_ids: list[int],
contact_forces,
):
"""Update the robot states.
Args:
sim: (SimulationContext) Simulation context.
scene: (InteractiveScene) Interactive scene.
robot: (Articulation) Robot articulation.
ee_frame_idx: (int) End-effector frame index.
arm_joint_ids: (list[int]) Arm joint indices.
contact_forces: (ContactSensor) Contact sensor.
Returns:
jacobian_b (torch.tensor): Jacobian in the body frame.
mass_matrix (torch.tensor): Mass matrix.
gravity (torch.tensor): Gravity vector.
ee_pose_b (torch.tensor): End-effector pose in the body frame.
ee_vel_b (torch.tensor): End-effector velocity in the body frame.
root_pose_w (torch.tensor): Root pose in the world frame.
ee_pose_w (torch.tensor): End-effector pose in the world frame.
ee_force_b (torch.tensor): End-effector force in the body frame.
joint_pos (torch.tensor): The joint positions.
joint_vel (torch.tensor): The joint velocities.
Raises:
ValueError: Undefined target_type.
"""
# obtain dynamics related quantities from simulation
ee_jacobi_idx = ee_frame_idx - 1
# The J / M / g DoF axis prepends `num_base_dofs` floating-base columns
# (0 for fixed-base, 6 for floating-base); shift the actuated-joint ids by
# `num_base_dofs` to address the actuated-joint columns directly.
jacobi_joint_ids = [j + robot.num_base_dofs for j in arm_joint_ids]
jacobian_w = robot.data.body_link_jacobian_w.torch[:, ee_jacobi_idx, :, jacobi_joint_ids]
mass_matrix = robot.data.mass_matrix.torch[:, jacobi_joint_ids, :][:, :, jacobi_joint_ids]
gravity = robot.data.gravity_compensation_forces.torch[:, jacobi_joint_ids]
# Convert the Jacobian from world to root frame
jacobian_b = jacobian_w.clone()
root_rot_matrix = matrix_from_quat(quat_inv(robot.data.root_quat_w.torch))
jacobian_b[:, :3, :] = torch.bmm(root_rot_matrix, jacobian_b[:, :3, :])
jacobian_b[:, 3:, :] = torch.bmm(root_rot_matrix, jacobian_b[:, 3:, :])
# Compute current pose of the end-effector
root_pos_w = robot.data.root_pos_w.torch
root_quat_w = robot.data.root_quat_w.torch
ee_pos_w = robot.data.body_pos_w.torch[:, ee_frame_idx]
ee_quat_w = robot.data.body_quat_w.torch[:, ee_frame_idx]
ee_pos_b, ee_quat_b = subtract_frame_transforms(root_pos_w, root_quat_w, ee_pos_w, ee_quat_w)
root_pose_w = torch.cat([root_pos_w, root_quat_w], dim=-1)
ee_pose_w = torch.cat([ee_pos_w, ee_quat_w], dim=-1)
ee_pose_b = torch.cat([ee_pos_b, ee_quat_b], dim=-1)
# Compute the current velocity of the end-effector
ee_vel_w = robot.data.body_vel_w.torch[:, ee_frame_idx, :] # Extract end-effector velocity in the world frame
root_vel_w = robot.data.root_vel_w.torch # Extract root velocity in the world frame
relative_vel_w = ee_vel_w - root_vel_w # Compute the relative velocity in the world frame
ee_lin_vel_b = quat_apply_inverse(robot.data.root_quat_w.torch, relative_vel_w[:, 0:3]) # From world to root frame
ee_ang_vel_b = quat_apply_inverse(robot.data.root_quat_w.torch, relative_vel_w[:, 3:6])
ee_vel_b = torch.cat([ee_lin_vel_b, ee_ang_vel_b], dim=-1)
# Calculate the contact force
ee_force_w = torch.zeros(scene.num_envs, 3, device=sim.device)
sim_dt = sim.get_physics_dt()
contact_forces.update(sim_dt) # update contact sensor
# Calculate the contact force by averaging over last four time steps (i.e., to smoothen) and
# taking the max of three surfaces as only one should be the contact of interest
ee_force_w, _ = torch.max(torch.mean(contact_forces.data.net_normal_forces_w_history, dim=1), dim=1)
# This is a simplification, only for the sake of testing.
ee_force_b = ee_force_w
# Get joint positions and velocities
joint_pos = robot.data.joint_pos.torch[:, arm_joint_ids]
joint_vel = robot.data.joint_vel.torch[:, arm_joint_ids]
return (
jacobian_b,
mass_matrix,
gravity,
ee_pose_b,
ee_vel_b,
root_pose_w,
ee_pose_w,
ee_force_b,
joint_pos,
joint_vel,
)
# Update the target commands
def update_target(
sim: sim_utils.SimulationContext,
scene: "InteractiveScene",
osc: OperationalSpaceController,
root_pose_w: torch.tensor,
ee_target_set: torch.tensor,
current_goal_idx: int,
):
"""Update the targets for the operational space controller.
Args:
sim: (SimulationContext) Simulation context.
scene: (InteractiveScene) Interactive scene.
osc: (OperationalSpaceController) Operational space controller.
root_pose_w: (torch.tensor) Root pose in the world frame.
ee_target_set: (torch.tensor) End-effector target set.
current_goal_idx: (int) Current goal index.
Returns:
command (torch.tensor): Updated target command.
ee_target_pose_b (torch.tensor): Updated target pose in the body frame.
ee_target_pose_w (torch.tensor): Updated target pose in the world frame.
next_goal_idx (int): Next goal index.
Raises:
ValueError: Undefined target_type.
"""
# update the ee desired command
command = torch.zeros(scene.num_envs, osc.action_dim, device=sim.device)
command[:] = ee_target_set[current_goal_idx]
# update the ee desired pose
ee_target_pose_b = torch.zeros(scene.num_envs, 7, device=sim.device)
for target_type in osc.cfg.target_types:
if target_type == "pose_abs":
ee_target_pose_b[:] = command[:, :7]
elif target_type == "wrench_abs":
pass # ee_target_pose_b could stay at the root frame for force control, what matters is ee_target_b
else:
raise ValueError("Undefined target_type within update_target().")
# update the target desired pose in world frame (for marker)
ee_target_pos_w, ee_target_quat_w = combine_frame_transforms(
root_pose_w[:, 0:3], root_pose_w[:, 3:7], ee_target_pose_b[:, 0:3], ee_target_pose_b[:, 3:7]
)
ee_target_pose_w = torch.cat([ee_target_pos_w, ee_target_quat_w], dim=-1)
next_goal_idx = (current_goal_idx + 1) % len(ee_target_set)
return command, ee_target_pose_b, ee_target_pose_w, next_goal_idx
# Convert the target commands to the task frame
def convert_to_task_frame(osc: OperationalSpaceController, command: torch.tensor, ee_target_pose_b: torch.tensor):
"""Converts the target commands to the task frame.
Args:
osc: OperationalSpaceController object.
command: Command to be converted.
ee_target_pose_b: Target pose in the body frame.
Returns:
command (torch.tensor): Target command in the task frame.
task_frame_pose_b (torch.tensor): Target pose in the task frame.
Raises:
ValueError: Undefined target_type.
"""
command = command.clone()
task_frame_pose_b = ee_target_pose_b.clone()
cmd_idx = 0
for target_type in osc.cfg.target_types:
if target_type == "pose_abs":
command[:, :3], command[:, 3:7] = subtract_frame_transforms(
task_frame_pose_b[:, :3], task_frame_pose_b[:, 3:], command[:, :3], command[:, 3:7]
)
cmd_idx += 7
elif target_type == "wrench_abs":
# These are already defined in target frame for ee_goal_wrench_set_tilted_task (since it is
# easier), so not transforming
cmd_idx += 6
else:
raise ValueError("Undefined target_type within _convert_to_task_frame().")
return command, task_frame_pose_b
def main():
"""Main function."""
# Configure the simulation
sim_cfg = sim_utils.SimulationCfg(dt=0.01, device=args_cli.device)
# Launch the simulator runtime that the configuration needs
with launch_simulation(sim_cfg, args_cli):
# Initialize the simulation context
sim = sim_utils.SimulationContext(sim_cfg)
# Set main camera
sim.set_camera_view([2.5, 2.5, 2.5], [0.0, 0.0, 0.0])
# Design scene
scene_cfg = SceneCfg(num_envs=args_cli.num_envs, env_spacing=2.0)
scene = instantiate(scene_cfg)
# Play the simulator
sim.reset()
# Now we are ready!
print("[INFO]: Setup complete...")
# Run the simulator
run_simulator(sim, scene)
if __name__ == "__main__":
# run the main function
main()

Creating an Operational Space Controller

The ~controllers.OperationalSpaceController class computes the joint efforts/torques for a robot to do simultaneous motion and force control in task space.

The reference frame of this task space could be an arbitrary coordinate frame in Euclidean space. By default, it is the robot’s base frame. However, in certain cases, it could be easier to define target coordinates w.r.t. a different frame. In such cases, the pose of this task reference frame, w.r.t. to the robot’s base frame, should be provided in the set_command method’s current_task_frame_pose_b argument. For example, in this tutorial, it makes sense to define the target commands w.r.t. a frame that is parallel to the wall surface, as the force control direction would be then only nonzero in the z-axis of this frame. The target pose, which is set to have the same orientation as the wall surface, is such a candidate and is used as the task frame in this tutorial. Therefore, all the arguments to the ~controllers.OperationalSpaceControllerCfg should be set with this task reference frame in mind.

For the motion control, the task space targets could be given as absolute (i.e., defined w.r.t. the robot base, target_types: "pose_abs") or relative to the end-effector’s current pose (i.e., target_types: "pose_rel"). For the force control, the task space targets could be given as absolute (i.e., defined w.r.t. the robot base, target_types: "wrench_abs"). If it is desired to apply pose and force control simultaneously, the target_types should be a list such as ["pose_abs", "wrench_abs"] or ["pose_rel", "wrench_abs"].

The axes that the motion and force control will be applied can be specified using the motion_control_axes_task and contact_wrench_control_axes_task arguments, respectively. These lists should consist of 0/1 for all six axes (position and rotation) and be complementary to each other (e.g., for the x-axis, if the motion_control_axes_task is 0, the contact_wrench_control_axes_task should be 1).

For the motion control axes, desired stiffness, and damping ratio values can be specified using the motion_stiffness_task and motion_damping_ratio_task arguments, which can be a scalar (same value for all axes) or a list of six scalars, one value corresponding to each axis. If desired, the stiffness and damping ratio values could be a command parameter (e.g., to learn the values using RL or change them on the go). For this, impedance_mode should be either "variable_kp" to include the stiffness values within the command or "variable" to include both the stiffness and damping ratio values. In these cases, motion_stiffness_limits_task and motion_damping_ratio_limits_task should be set as well, which puts bounds on the stiffness and damping ratio values.

For contact force control, it is possible to apply an open-loop force control by not setting the contact_wrench_stiffness_task, or apply a closed-loop force control (with the feed-forward term) by setting the desired stiffness values using the contact_wrench_stiffness_task argument, which can be a scalar or a list of six scalars. Please note that, currently, only the linear part of the contact wrench (hence the first three elements of the contact_wrench_stiffness_task) is considered in the closed-loop control, as the rotational part cannot be measured with the contact sensors.

For the motion control, inertial_dynamics_decoupling should be set to True to use the robot’s inertia matrix to decouple the desired accelerations in the task space. This is important for the motion control to be accurate, especially for rapid movements. This inertial decoupling accounts for the coupling between all the six motion axes. If desired, the inertial coupling between the translational and rotational axes could be ignored by setting the partial_inertial_dynamics_decoupling to True.

If it is desired to include the gravity compensation in the operational space command, the gravity_compensation should be set to True.

A final consideration regarding the operational space control is what to do with the null-space of redundant robots. The null-space is the subspace of the joint space that does not affect the task space coordinates. If nothing is done to control the null-space, the robot joints will float without moving the end-effector. This might be undesired (e.g., the robot joints might get close to their limits), and one might want to control the robot behaviour within its null-space. One way to do is to set nullspace_control to "position" (by default it is "none") which integrates a null-space PD controller to attract the robot joints to desired targets without affecting the task space. The behaviour of this null-space controller can be defined using the nullspace_stiffness and nullspace_damping_ratio arguments. Please note that theoretical decoupling of the null-space and task space accelerations is only possible when inertial_dynamics_decoupling is set to True and partial_inertial_dynamics_decoupling is set to False.

The included OSC implementation performs the computation in a batched format and uses PyTorch operations.

In this tutorial, we will use "pose_abs" for controlling the motion in all axes except the z-axis and "wrench_abs" for controlling the force in the z-axis. Moreover, we will include the full inertia decoupling in the motion control and not include the gravity compensation, as the gravity is disabled from the robot configuration. We set the impedance mode to "variable_kp" to dynamically change the stiffness values (motion_damping_ratio_task is set to 1: the kd values adapt according to kp values to maintain a critically damped response). Finally, nullspace_control is set to use "position" where the joint set points are provided to be the center of the joint position limits.

# Create the OSC
osc_cfg = OperationalSpaceControllerCfg(
target_types=["pose_abs", "wrench_abs"],
impedance_mode="variable_kp",
inertial_dynamics_decoupling=True,
partial_inertial_dynamics_decoupling=False,
gravity_compensation=False,
motion_damping_ratio_task=1.0,
contact_wrench_stiffness_task=[0.0, 0.0, 0.1, 0.0, 0.0, 0.0],
motion_control_axes_task=[1, 1, 0, 1, 1, 1],
contact_wrench_control_axes_task=[0, 0, 1, 0, 0, 0],
nullspace_control="position",
)
osc = OperationalSpaceController(osc_cfg, num_envs=scene.num_envs, device=sim.device)

Updating the states of the robot

The OSC implementation is a computation-only class. Thus, it expects the user to provide the necessary information about the robot. This includes the robot’s Jacobian matrix, mass/inertia matrix, end-effector pose, velocity, contact force (all in the root frame), and finally, the joint positions and velocities. Moreover, the user should provide gravity compensation vector and null-space joint position targets if required.

# Update robot states
def update_states(
sim: sim_utils.SimulationContext,
scene: "InteractiveScene",
robot: Articulation,
ee_frame_idx: int,
arm_joint_ids: list[int],
contact_forces,
):
"""Update the robot states.
Args:
sim: (SimulationContext) Simulation context.
scene: (InteractiveScene) Interactive scene.
robot: (Articulation) Robot articulation.
ee_frame_idx: (int) End-effector frame index.
arm_joint_ids: (list[int]) Arm joint indices.
contact_forces: (ContactSensor) Contact sensor.
Returns:
jacobian_b (torch.tensor): Jacobian in the body frame.
mass_matrix (torch.tensor): Mass matrix.
gravity (torch.tensor): Gravity vector.
ee_pose_b (torch.tensor): End-effector pose in the body frame.
ee_vel_b (torch.tensor): End-effector velocity in the body frame.
root_pose_w (torch.tensor): Root pose in the world frame.
ee_pose_w (torch.tensor): End-effector pose in the world frame.
ee_force_b (torch.tensor): End-effector force in the body frame.
joint_pos (torch.tensor): The joint positions.
joint_vel (torch.tensor): The joint velocities.
Raises:
ValueError: Undefined target_type.
"""
# obtain dynamics related quantities from simulation
ee_jacobi_idx = ee_frame_idx - 1
# The J / M / g DoF axis prepends ``num_base_dofs`` floating-base columns
# (0 for fixed-base, 6 for floating-base); shift the actuated-joint ids by
# ``num_base_dofs`` to address the actuated-joint columns directly.
jacobi_joint_ids = [j + robot.num_base_dofs for j in arm_joint_ids]
jacobian_w = robot.data.body_link_jacobian_w.torch[:, ee_jacobi_idx, :, jacobi_joint_ids]
mass_matrix = robot.data.mass_matrix.torch[:, jacobi_joint_ids, :][:, :, jacobi_joint_ids]
gravity = robot.data.gravity_compensation_forces.torch[:, jacobi_joint_ids]
# Convert the Jacobian from world to root frame
jacobian_b = jacobian_w.clone()
root_rot_matrix = matrix_from_quat(quat_inv(robot.data.root_quat_w.torch))
jacobian_b[:, :3, :] = torch.bmm(root_rot_matrix, jacobian_b[:, :3, :])
jacobian_b[:, 3:, :] = torch.bmm(root_rot_matrix, jacobian_b[:, 3:, :])
# Compute current pose of the end-effector
root_pos_w = robot.data.root_pos_w.torch
root_quat_w = robot.data.root_quat_w.torch
ee_pos_w = robot.data.body_pos_w.torch[:, ee_frame_idx]
ee_quat_w = robot.data.body_quat_w.torch[:, ee_frame_idx]
ee_pos_b, ee_quat_b = subtract_frame_transforms(root_pos_w, root_quat_w, ee_pos_w, ee_quat_w)
root_pose_w = torch.cat([root_pos_w, root_quat_w], dim=-1)
ee_pose_w = torch.cat([ee_pos_w, ee_quat_w], dim=-1)
ee_pose_b = torch.cat([ee_pos_b, ee_quat_b], dim=-1)
# Compute the current velocity of the end-effector
ee_vel_w = robot.data.body_vel_w.torch[:, ee_frame_idx, :] # Extract end-effector velocity in the world frame
root_vel_w = robot.data.root_vel_w.torch # Extract root velocity in the world frame
relative_vel_w = ee_vel_w - root_vel_w # Compute the relative velocity in the world frame
ee_lin_vel_b = quat_apply_inverse(robot.data.root_quat_w.torch, relative_vel_w[:, 0:3]) # From world to root frame
ee_ang_vel_b = quat_apply_inverse(robot.data.root_quat_w.torch, relative_vel_w[:, 3:6])
ee_vel_b = torch.cat([ee_lin_vel_b, ee_ang_vel_b], dim=-1)
# Calculate the contact force
ee_force_w = torch.zeros(scene.num_envs, 3, device=sim.device)
sim_dt = sim.get_physics_dt()
contact_forces.update(sim_dt) # update contact sensor
# Calculate the contact force by averaging over last four time steps (i.e., to smoothen) and
# taking the max of three surfaces as only one should be the contact of interest
ee_force_w, _ = torch.max(torch.mean(contact_forces.data.net_normal_forces_w_history, dim=1), dim=1)
# This is a simplification, only for the sake of testing.
ee_force_b = ee_force_w
# Get joint positions and velocities
joint_pos = robot.data.joint_pos.torch[:, arm_joint_ids]
joint_vel = robot.data.joint_vel.torch[:, arm_joint_ids]
return (
jacobian_b,
mass_matrix,
gravity,
ee_pose_b,
ee_vel_b,
root_pose_w,
ee_pose_w,
ee_force_b,
joint_pos,
joint_vel,
)

Computing robot command

The OSC separates the operation of setting the desired command and computing the desired joint efforts. To set the desired command, the user should provide command vector, which includes the target commands (i.e., in the order they appear in the target_types argument of the OSC configuration), and the desired stiffness and damping ratio values if the impedance_mode is set to "variable_kp" or "variable". They should be all in the same coordinate frame as the task frame (e.g., indicated with _task subscript) and concatenated together.

In this tutorial, the desired wrench is already defined w.r.t. the task frame, and the desired pose is transformed to the task frame as the following:

# Convert the target commands to the task frame
def convert_to_task_frame(osc: OperationalSpaceController, command: torch.tensor, ee_target_pose_b: torch.tensor):
"""Converts the target commands to the task frame.
Args:
osc: OperationalSpaceController object.
command: Command to be converted.
ee_target_pose_b: Target pose in the body frame.
Returns:
command (torch.tensor): Target command in the task frame.
task_frame_pose_b (torch.tensor): Target pose in the task frame.
Raises:
ValueError: Undefined target_type.
"""
command = command.clone()
task_frame_pose_b = ee_target_pose_b.clone()
cmd_idx = 0
for target_type in osc.cfg.target_types:
if target_type == "pose_abs":
command[:, :3], command[:, 3:7] = subtract_frame_transforms(
task_frame_pose_b[:, :3], task_frame_pose_b[:, 3:], command[:, :3], command[:, 3:7]
)
cmd_idx += 7
elif target_type == "wrench_abs":
# These are already defined in target frame for ee_goal_wrench_set_tilted_task (since it is
# easier), so not transforming
cmd_idx += 6
else:
raise ValueError("Undefined target_type within _convert_to_task_frame().")
return command, task_frame_pose_b

The OSC command is set with the command vector in the task frame, the end-effector pose in the base frame, and the task (reference) frame pose in the base frame as the following. This information is needed, as the internal computations are done in the base frame.

# set the osc command
osc.reset()
command, task_frame_pose_b = convert_to_task_frame(osc, command=command, ee_target_pose_b=ee_target_pose_b)
osc.set_command(command=command, current_ee_pose_b=ee_pose_b, current_task_frame_pose_b=task_frame_pose_b)

The joint effort/torque values are computed using the provided robot states and the desired command as the following:

# compute the joint commands
joint_efforts = osc.compute(
jacobian_b=jacobian_b,
current_ee_pose_b=ee_pose_b,
current_ee_vel_b=ee_vel_b,
current_ee_force_b=ee_force_b,
mass_matrix=mass_matrix,
gravity=gravity,
current_joint_pos=joint_pos,
current_joint_vel=joint_vel,
nullspace_joint_pos_target=joint_centers,
)

The computed joint effort/torque targets can then be applied on the robot.

# apply actions
robot.set_joint_effort_target_index(target=joint_efforts, joint_ids=arm_joint_ids)
robot.write_data_to_sim()

The Code Execution

You can now run the script and see the result:

uv run isaaclab -p scripts/tutorials/05_controllers/run_osc.py --num_envs 128 --viz kit

The script will start a simulation with 128 robots. The robots will be controlled using the OSC. The current and desired end-effector poses should be displayed using frame markers in addition to the red tilted wall. You should see that the robot reaches the desired pose while applying a constant force perpendicular to the wall surface.
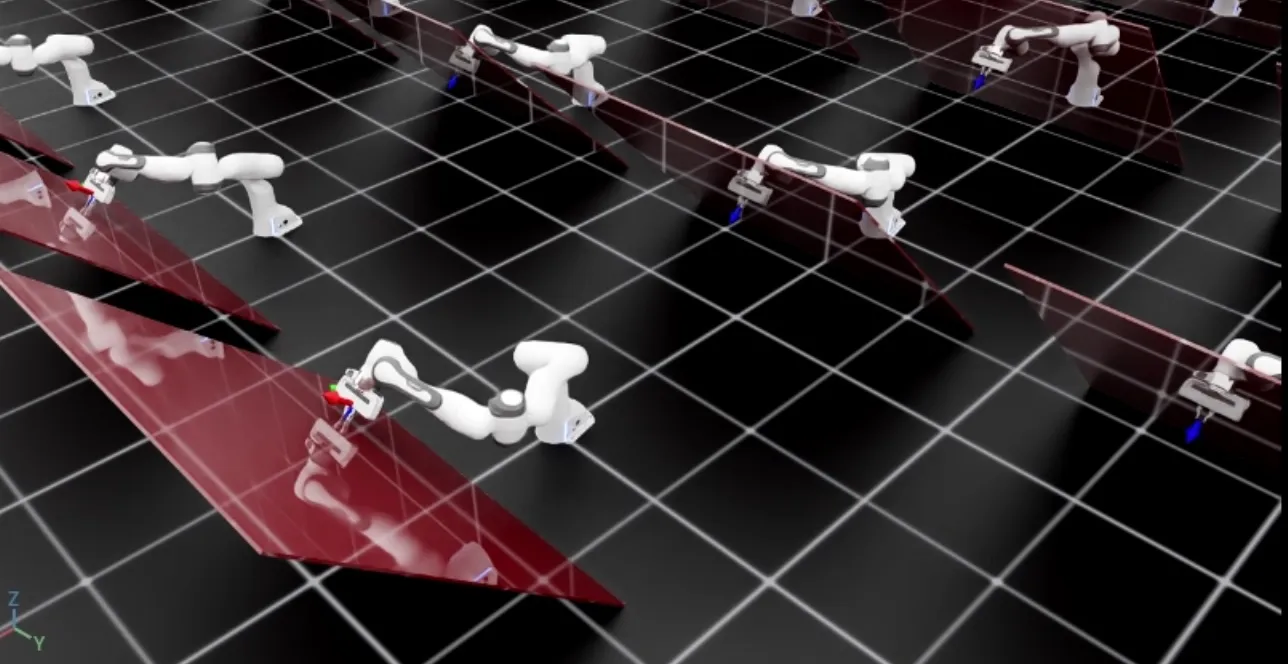
result of run_osc.py

Press Ctrl+C in the terminal to stop the simulation.